Stochastic resonance in the LIF models with input or threshold noise

Michele Barbi1, Lara Reale

  • 1Istituto di Biofisica del, CNR Via G. Moruzzi 1, 56124 Pisa, Italy. barbi@ib.pi.cnr.it

Bio Systems
|January 15, 2005
PubMed

Related Concept Videos

Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
Forced Oscillations01:06

Forced Oscillations

When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
Concept of Resonance and its Characteristics01:19

Concept of Resonance and its Characteristics

If a driven oscillator needs to resonate at a specific frequency, then very light damping is required. An example of light damping includes playing piano strings and many other musical instruments. Conversely, to achieve small-amplitude oscillations as in a car's suspension system, heavy damping is required. Heavy damping reduces the amplitude, but the tradeoff is that the system responds at more frequencies. Speed bumps and gravel roads prove that even a car's suspension system is not immune...
Modeling with Differential Equations01:25

Modeling with Differential Equations

Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...
Muscle Stimulation Frequency01:22

Muscle Stimulation Frequency

The contraction strength of muscles is regulated by motor neurons, which modulate the frequency of action potentials dispatched to the motor units based on the body's requirements. This process of varying the muscle stimulation frequency allows muscles to contract with a force that is precisely tailored to the needs of the moment, whether lifting a feather or a heavy box.
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
Types of Responses of Series RLC Circuits01:11

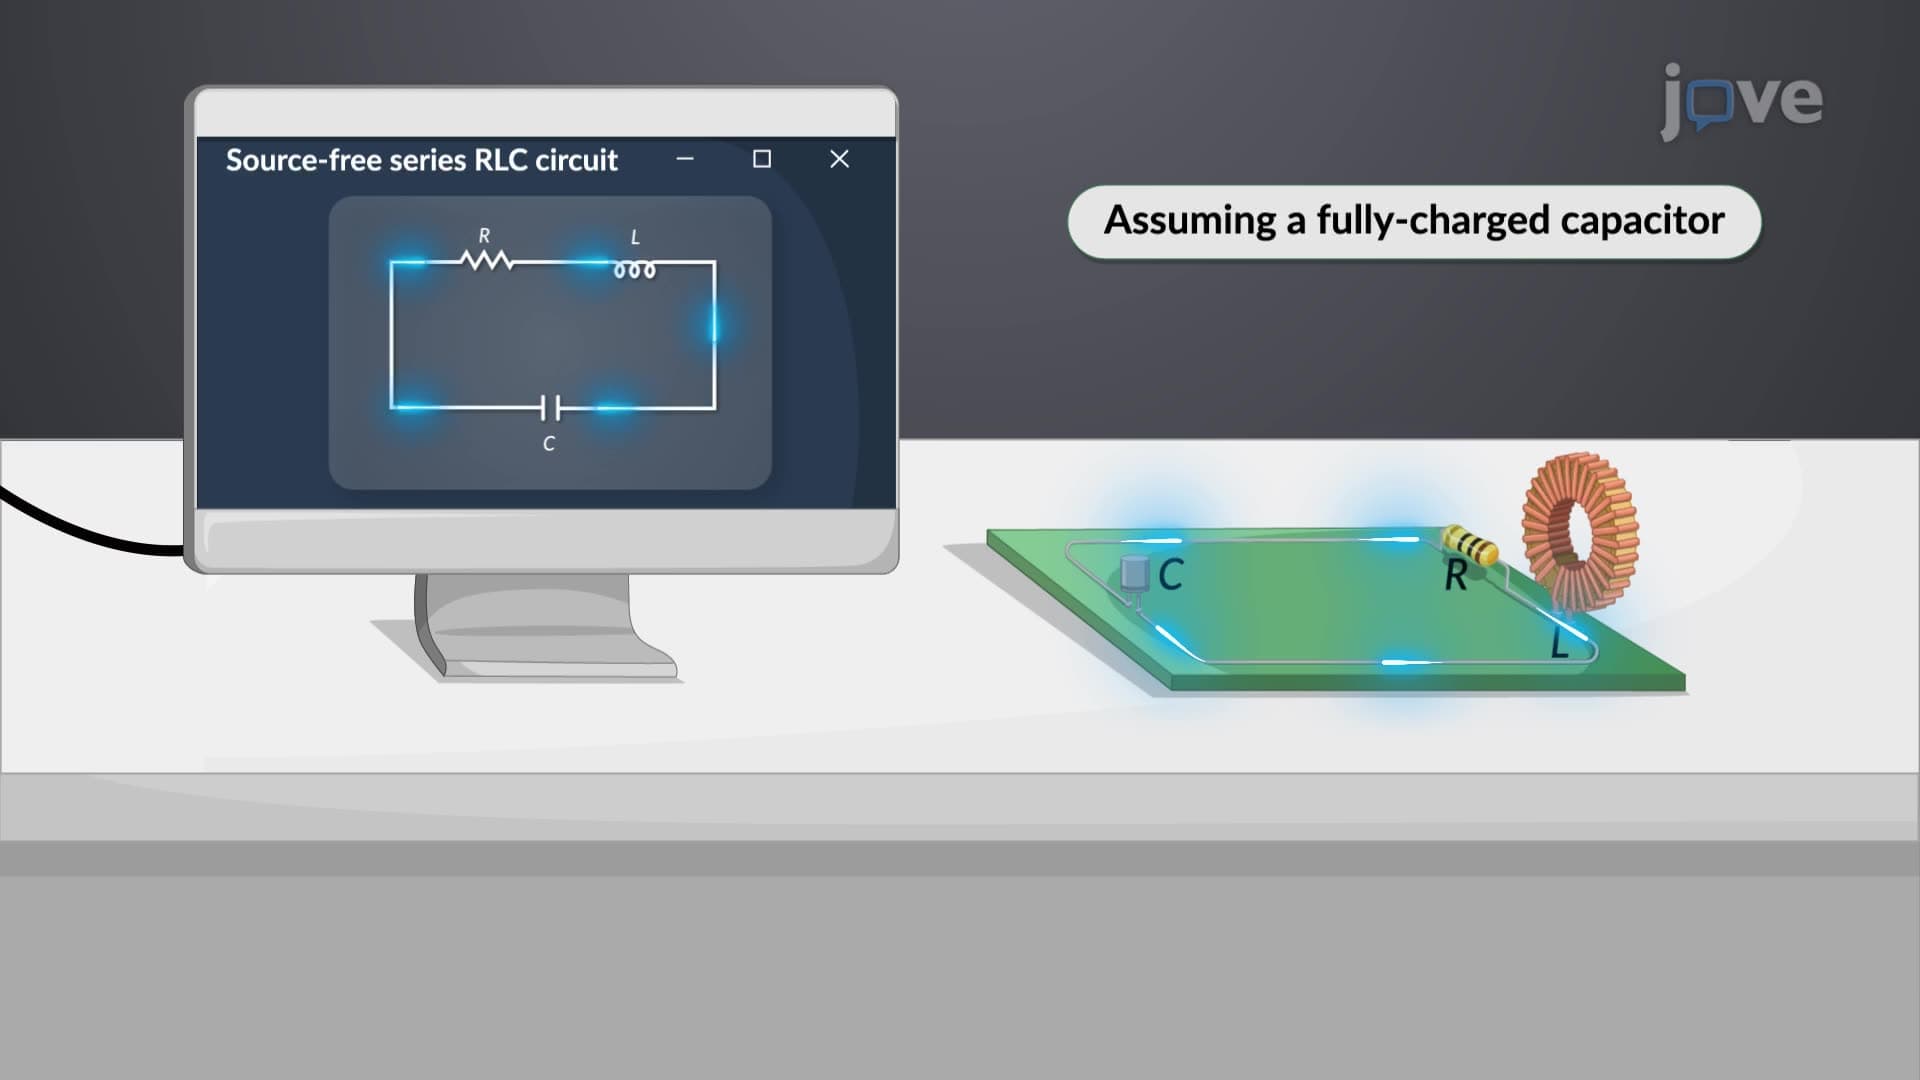
Types of Responses of Series RLC Circuits

A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.