Related Experiment Video
Updated: Aug 20, 2026
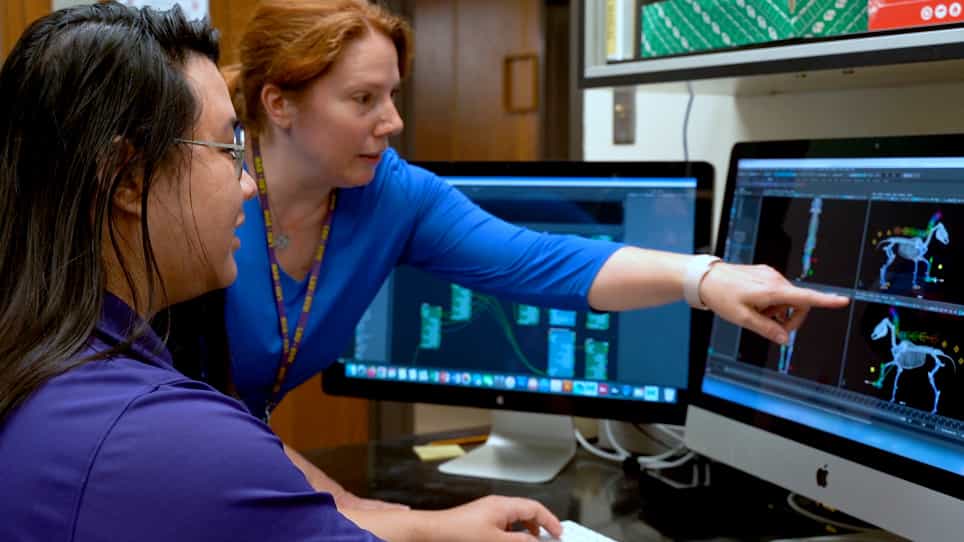
Construction of a Realistic, Whole-Body, Three-Dimensional Equine Skeletal Model using Computed Tomography Data
Published on: February 25, 2021
Three-dimensional kinematics of the equine distal forelimb: effects of a sharp turn at the walk
H Chateau1, C Degueurce, J M Denoix
1UMR INRA-ENVA de Biomécanique et Pathologie Locomotrice du Cheval, Ecole Nationale Vétérinaire d'Alfort, 7Avenue du GI de Gaulle, 94704 Maisons-Alfort, France.

Reasons For Performing Study:
Sharp turns are suspected to increase expression of several distal forelimb lamenesses even at the walk but the biomechanical consequences of such a movement remain unknown.
Objective:
To quantify the effects of a sharp turn at the walk on the 3-dimensional movements of the distal segments of the forelimb.
Methods:
Kinematics of the distal segments were measured in 4 healthy horses invasively with an ultrasonic system. Three-dimensional rotations of the digital joints were calculated by use of a joint coordinate system. Data obtained for a turn at the walk were compared to those obtained in a straight line.
Results:
During the stance phase in a turn, the inside forelimb underwent an adduction that induced lateromotion and medial rotation in the distal interphalangeal joint and medial rotation in the proximal interphalangeal joint. These movements were maximal at heel-off and decreased during breakover as the hoof underwent a sudden lateral rotation.
Conclusions:
Walking in a sharp turn affects the kinematics of the digital joints outside the sagittal plane.
Potential Relevance:
This knowledge offers the opportunity to derive hypotheses on biomechanical factors that could contribute to the pathogenesis of digital injuries and on consequences for rational shoeing.
Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
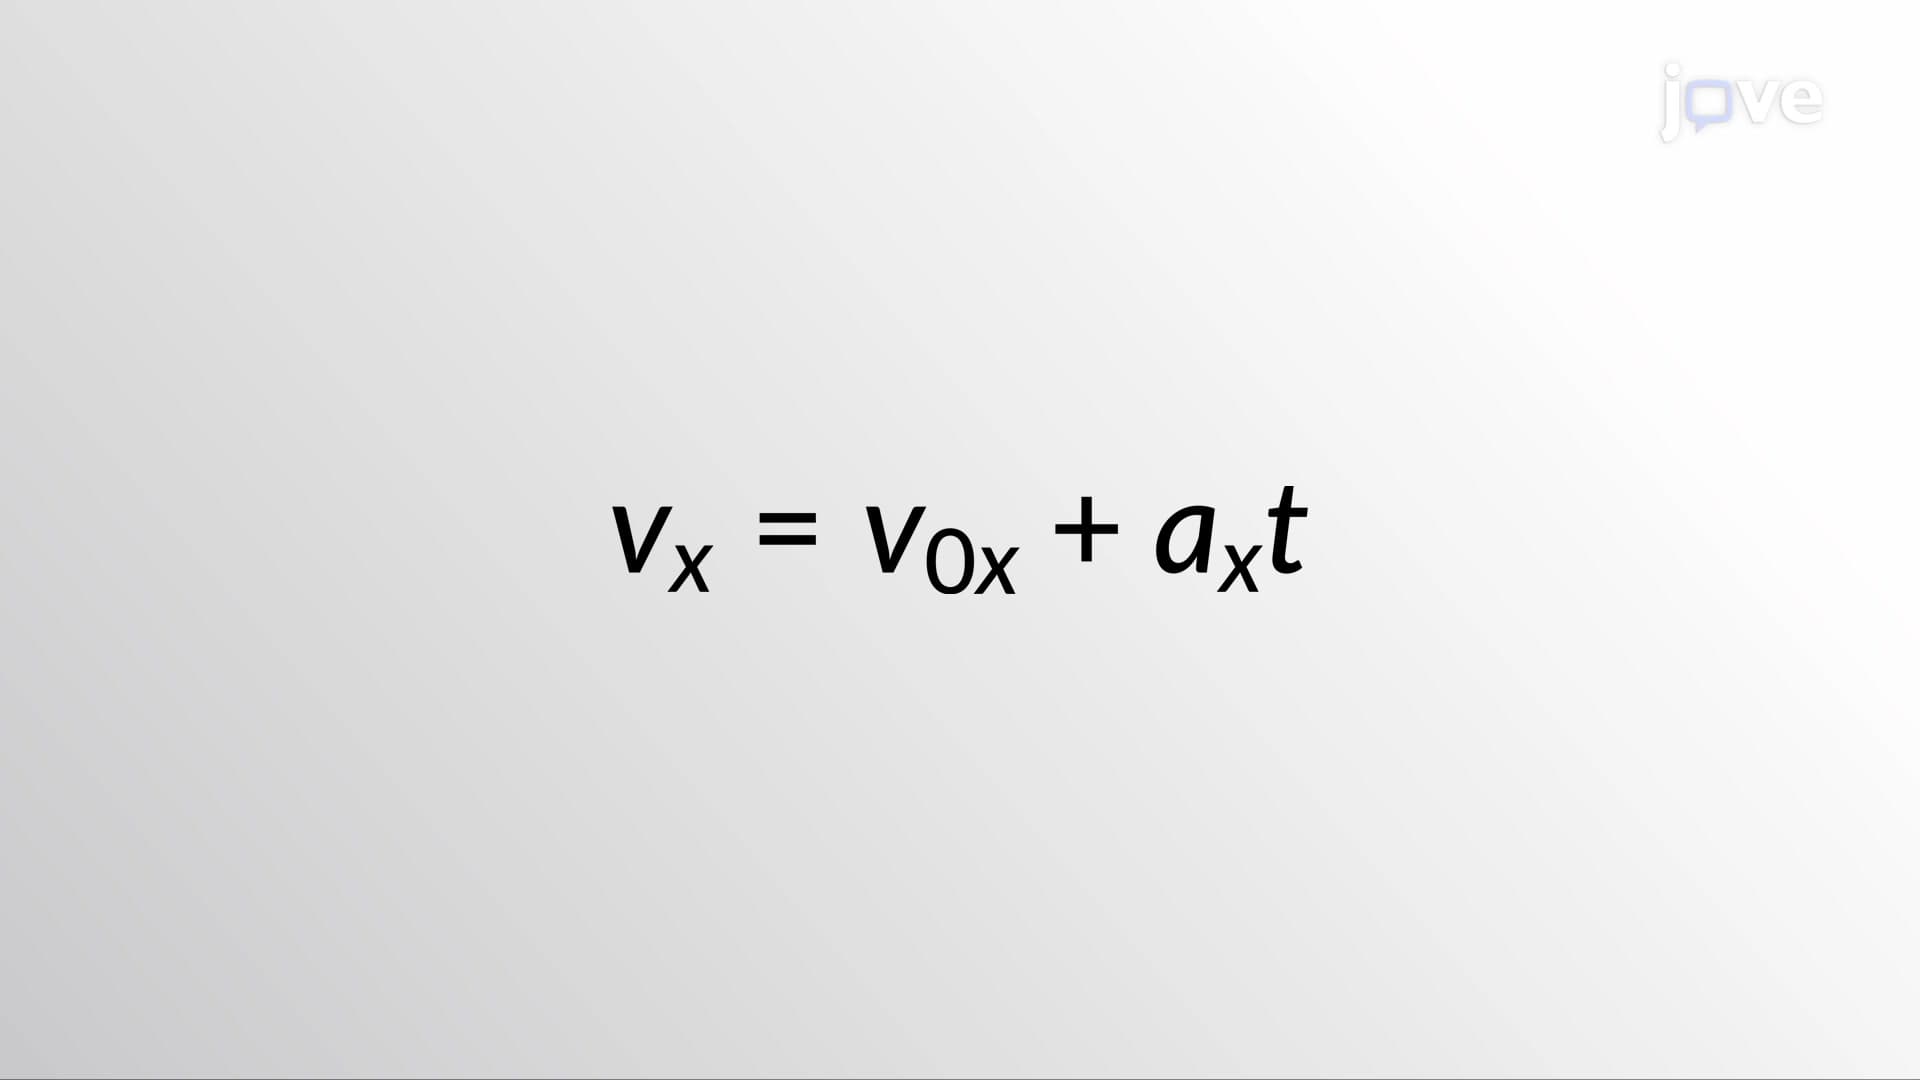 01:26
Kinematic Equations - I
 01:30
Equations of Equilibrium in Three Dimensions
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...