Design and analysis of controllers for a double inverted pendulum
Related Experiment Video
Updated: Aug 19, 2026
Online Virtual Reality Networked Control Laboratory Applied in Control Engineering Education
Published on: February 23, 2024
Henrik Niemann1, Jesper Kildegaard Poulsen
1Orsted-DTU, Automation, Technical University of Denmark, DK-2800 Lyngby, Denmark. hhn@oersted.dtu.dk

Abstract:
A physical control problem is studied with the Hinfinity, and the micro methodology. The issues of modeling, uncertainty modeling, performance specification, controller design, and laboratory implementation are discussed. The laboratory experiment is a double inverted pendulum placed on a cart. The limitations in the system with respect to performance are the limitation in the control signal and the limitation of the movement of the cart. It is shown how these performance limitations will effect the design of Hinfinity and micro controllers for the system.
Related Concept Videos
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
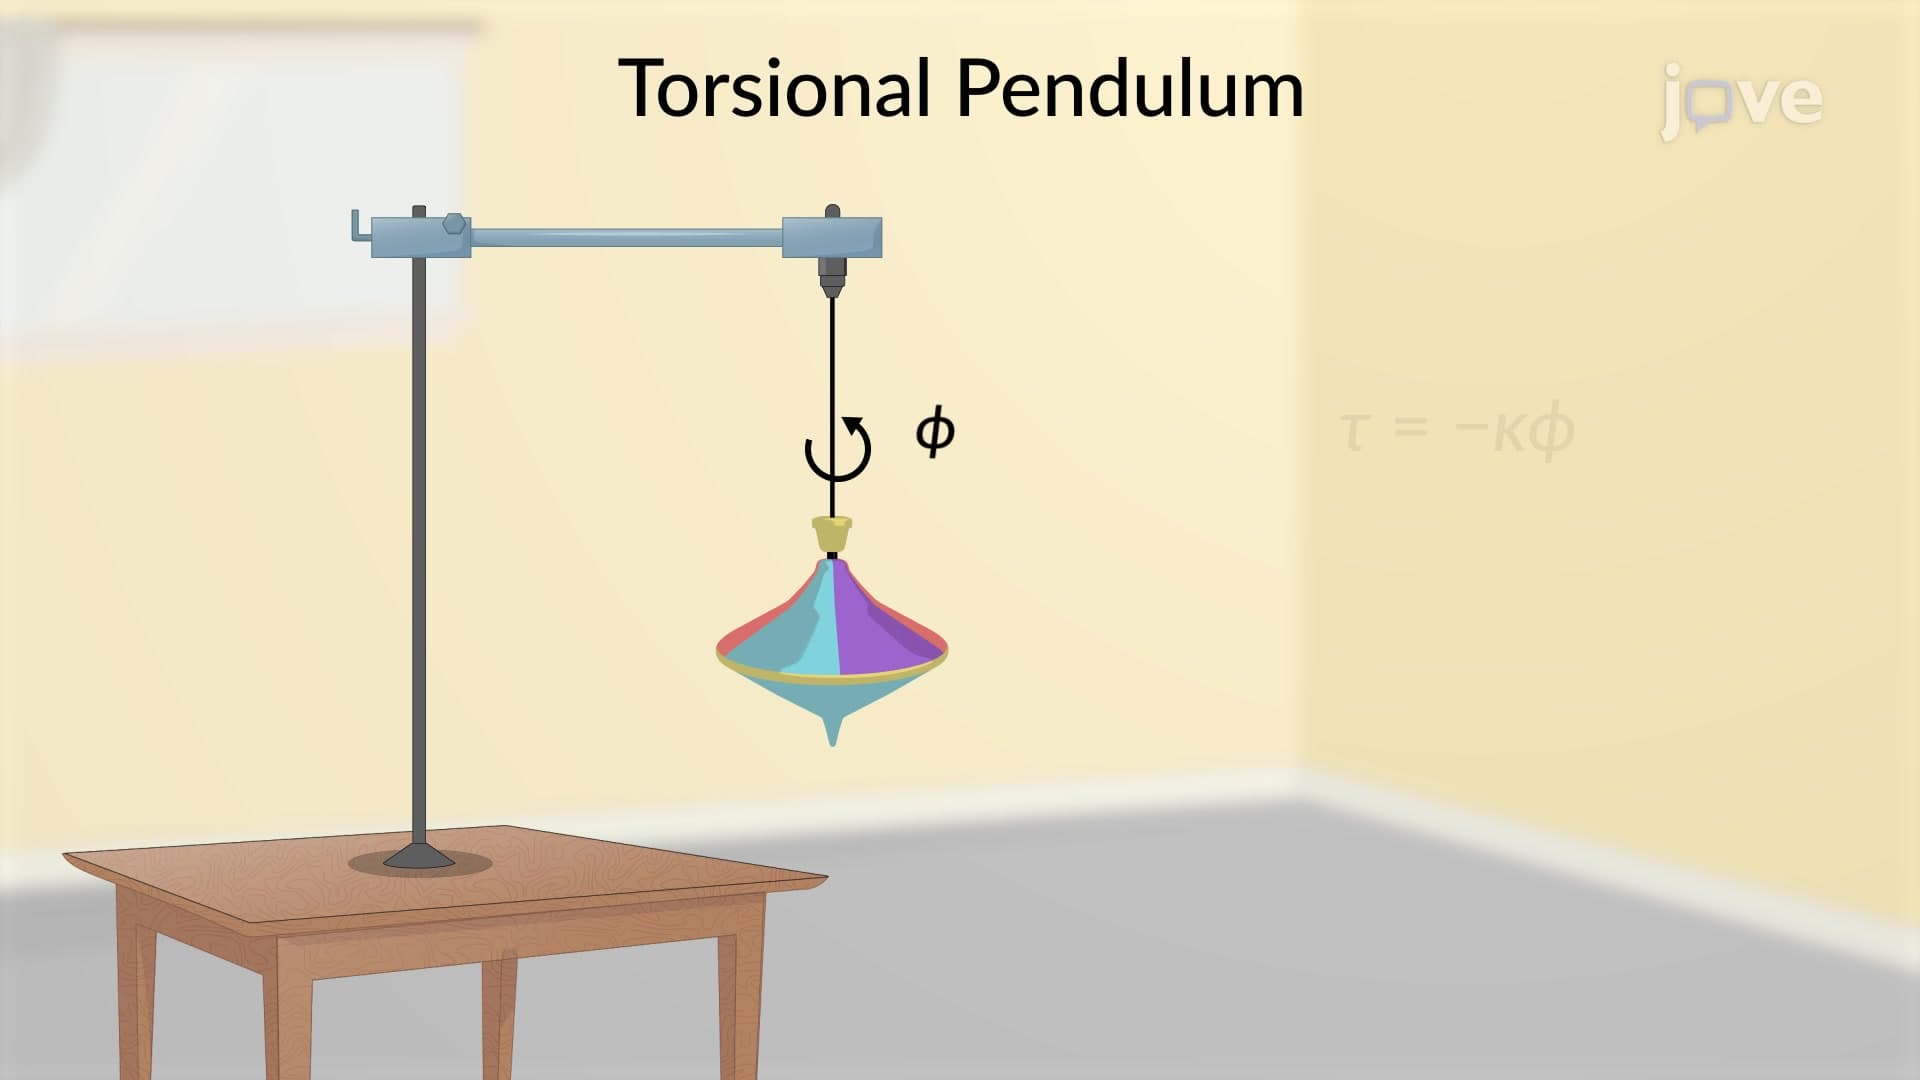 01:09
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
Real-World Applications of Power Series
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...