Spacetime stereo: a unifying framework for depth from triangulation
Related Experiment Video
Updated: Aug 19, 2026
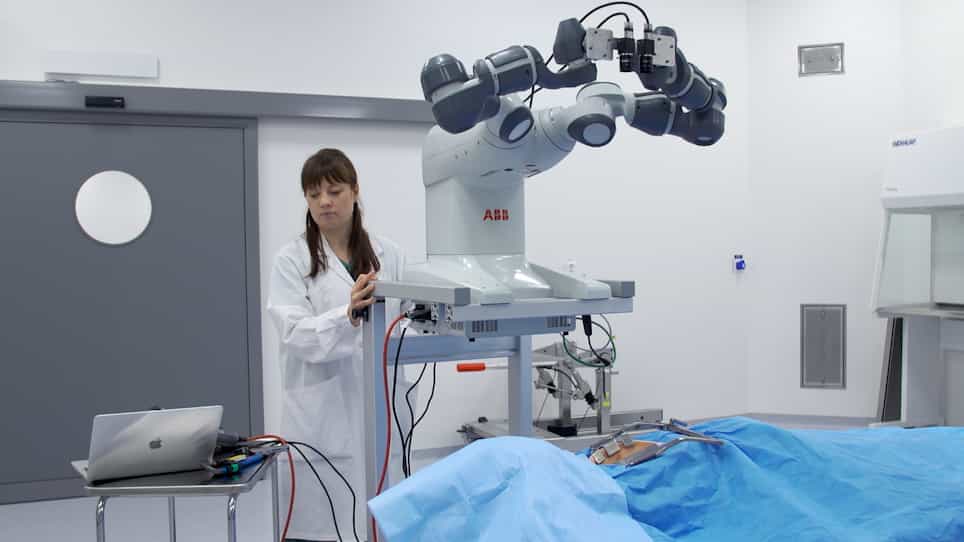
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
James Davis1, Diego Nehab, Ravi Ramamoorthi
1Honda Research Institute, Mountain View, CA 94041, USA. jedavis@ieee.org

Abstract:
Depth from triangulation has traditionally been investigated in a number of independent threads of research, with methods such as stereo, laser scanning, and coded structured light considered separately. In this paper, we propose a common framework called spacetime stereo that unifies and generalizes many of these previous methods. To show the practical utility of the framework, we develop two new algorithms for depth estimation: depth from unstructured illumination change and depth estimation in dynamic scenes. Based on our analysis, we show that methods derived from the spacetime stereo framework can be used to recover depth in situations in which existing methods perform poorly.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:28
Cylinders in Three-Dimensional Space
 01:20
Divergence Theorem in 3D Space
 01:18
Distance Measurements by Taping
 01:17
Space-Time Curvature and the General Theory of Relativity
This has been verified in many experiments. However, space and time are no longer absolute. Two observers moving relative to one another do not agree on the length of objects or the passage of time. The mechanics of objects based on Newton's laws of motion,...
 01:29
Three-Dimensional Analysis of Strain