Related Experiment Video
Updated: Jul 5, 2026
Kinematic History of a Salient-recess Junction Explored through a Combined Approach of Field Data and Analog Sandbox Modeling
Published on: August 5, 2016
Global azimuthal seismic anisotropy and the unique plate-motion deformation of Australia
Eric Debayle1, Brian Kennett, Keith Priestley
1Institut de Physique du Globe de Strasbourg, Ecole et Observatoire des Sciences de la Terre, Centre National de la Recherche Scientifique and Université Louis Pasteur, 61084 Strasbourg, Cedex, France. Eric.Debayle@eost.u-strasbg.fr

Abstract:
Differences in the thickness of the high-velocity lid underlying continents as imaged by seismic tomography, have fuelled a long debate on the origin of the 'roots' of continents. Some of these differences may be reconciled by observations of radial anisotropy between 250 and 300 km depth, with horizontally polarized shear waves travelling faster than vertically polarized ones. This azimuthally averaged anisotropy could arise from present-day deformation at the base of the plate, as has been found for shallower depths beneath ocean basins. Such deformation would also produce significant azimuthal variation, owing to the preferred alignment of highly anisotropic minerals. Here we report global observations of surface-wave azimuthal anisotropy, which indicate that only the continental portion of the Australian plate displays significant azimuthal anisotropy and strong correlation with present-day plate motion in the depth range 175-300 km. Beneath other continents, azimuthal anisotropy is only weakly correlated with plate motion and its depth location is similar to that found beneath oceans. We infer that the fast-moving Australian plate contains the only continental region with a sufficiently large deformation at its base to be transformed into azimuthal anisotropy. Simple shear leading to anisotropy with a plunging axis of symmetry may explain the smaller azimuthal anisotropy beneath other continents.
Related Concept Videos
 01:20
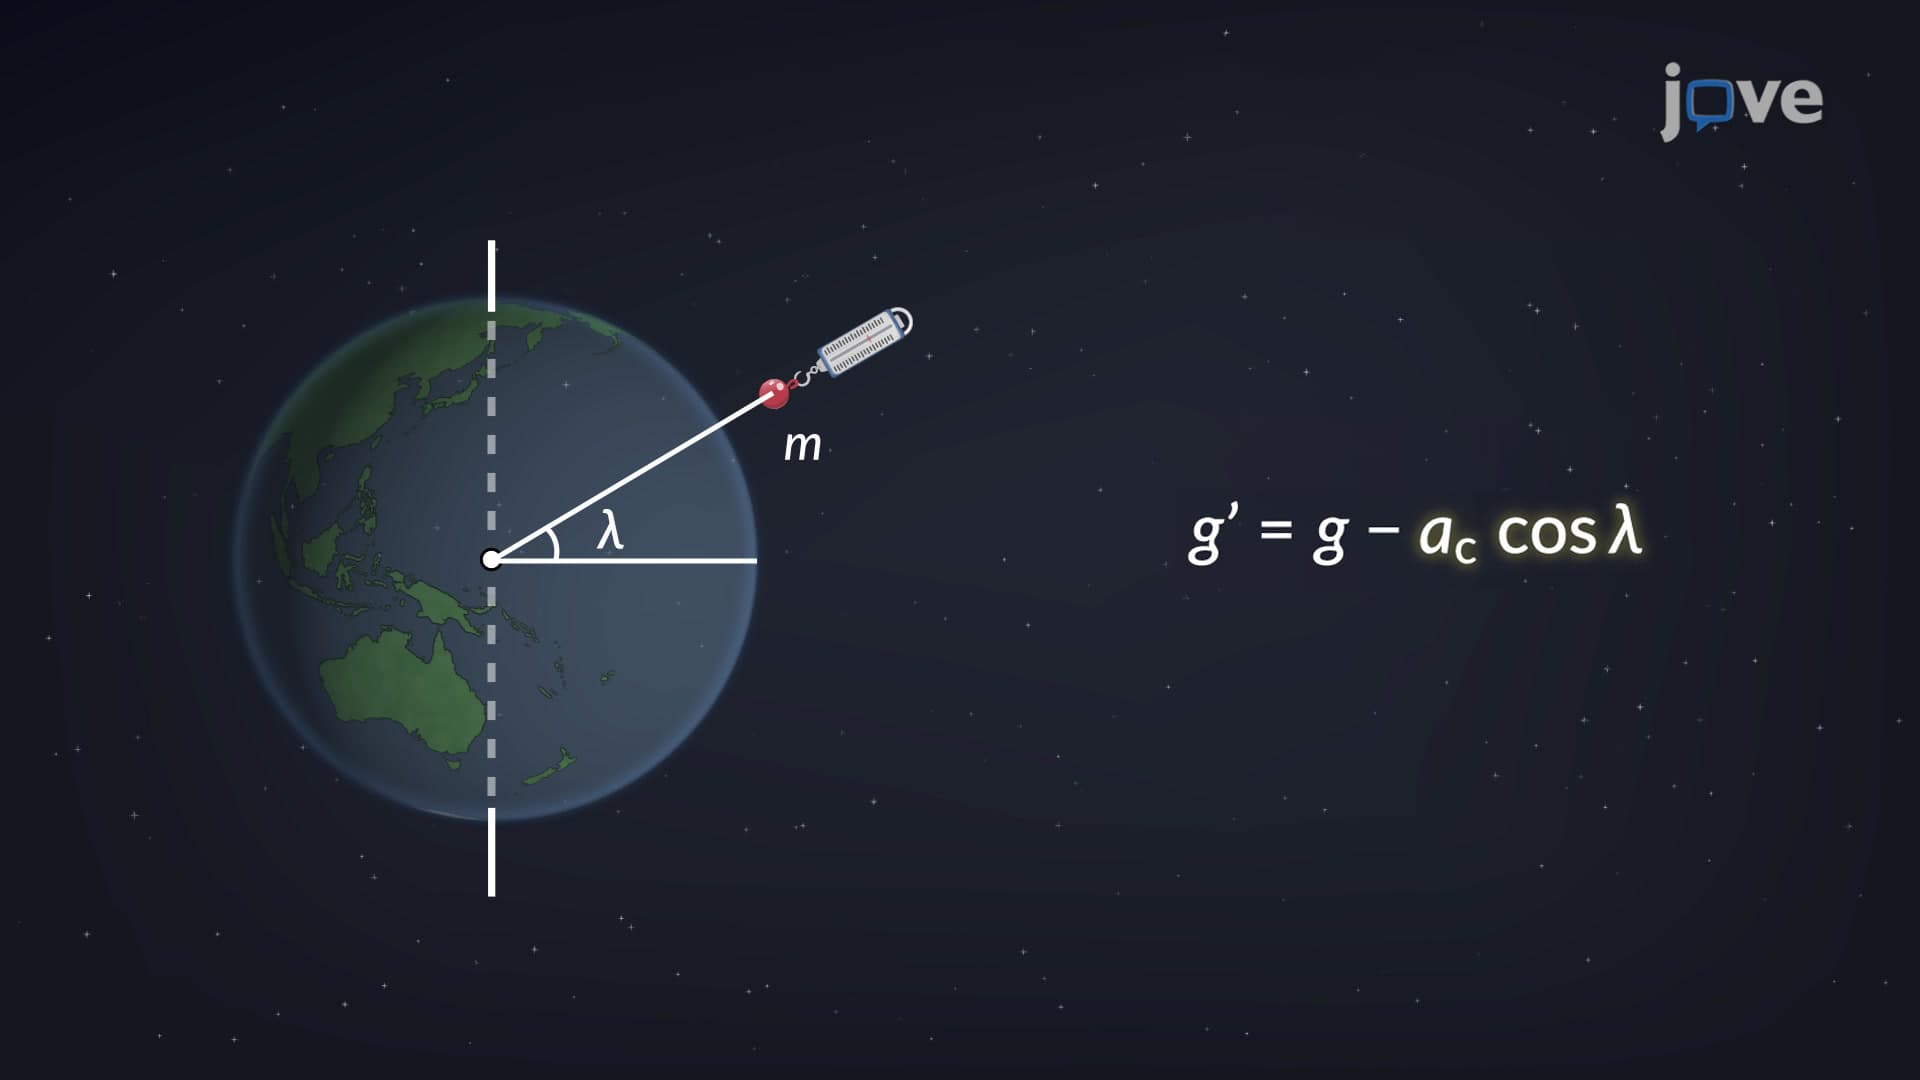
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:13
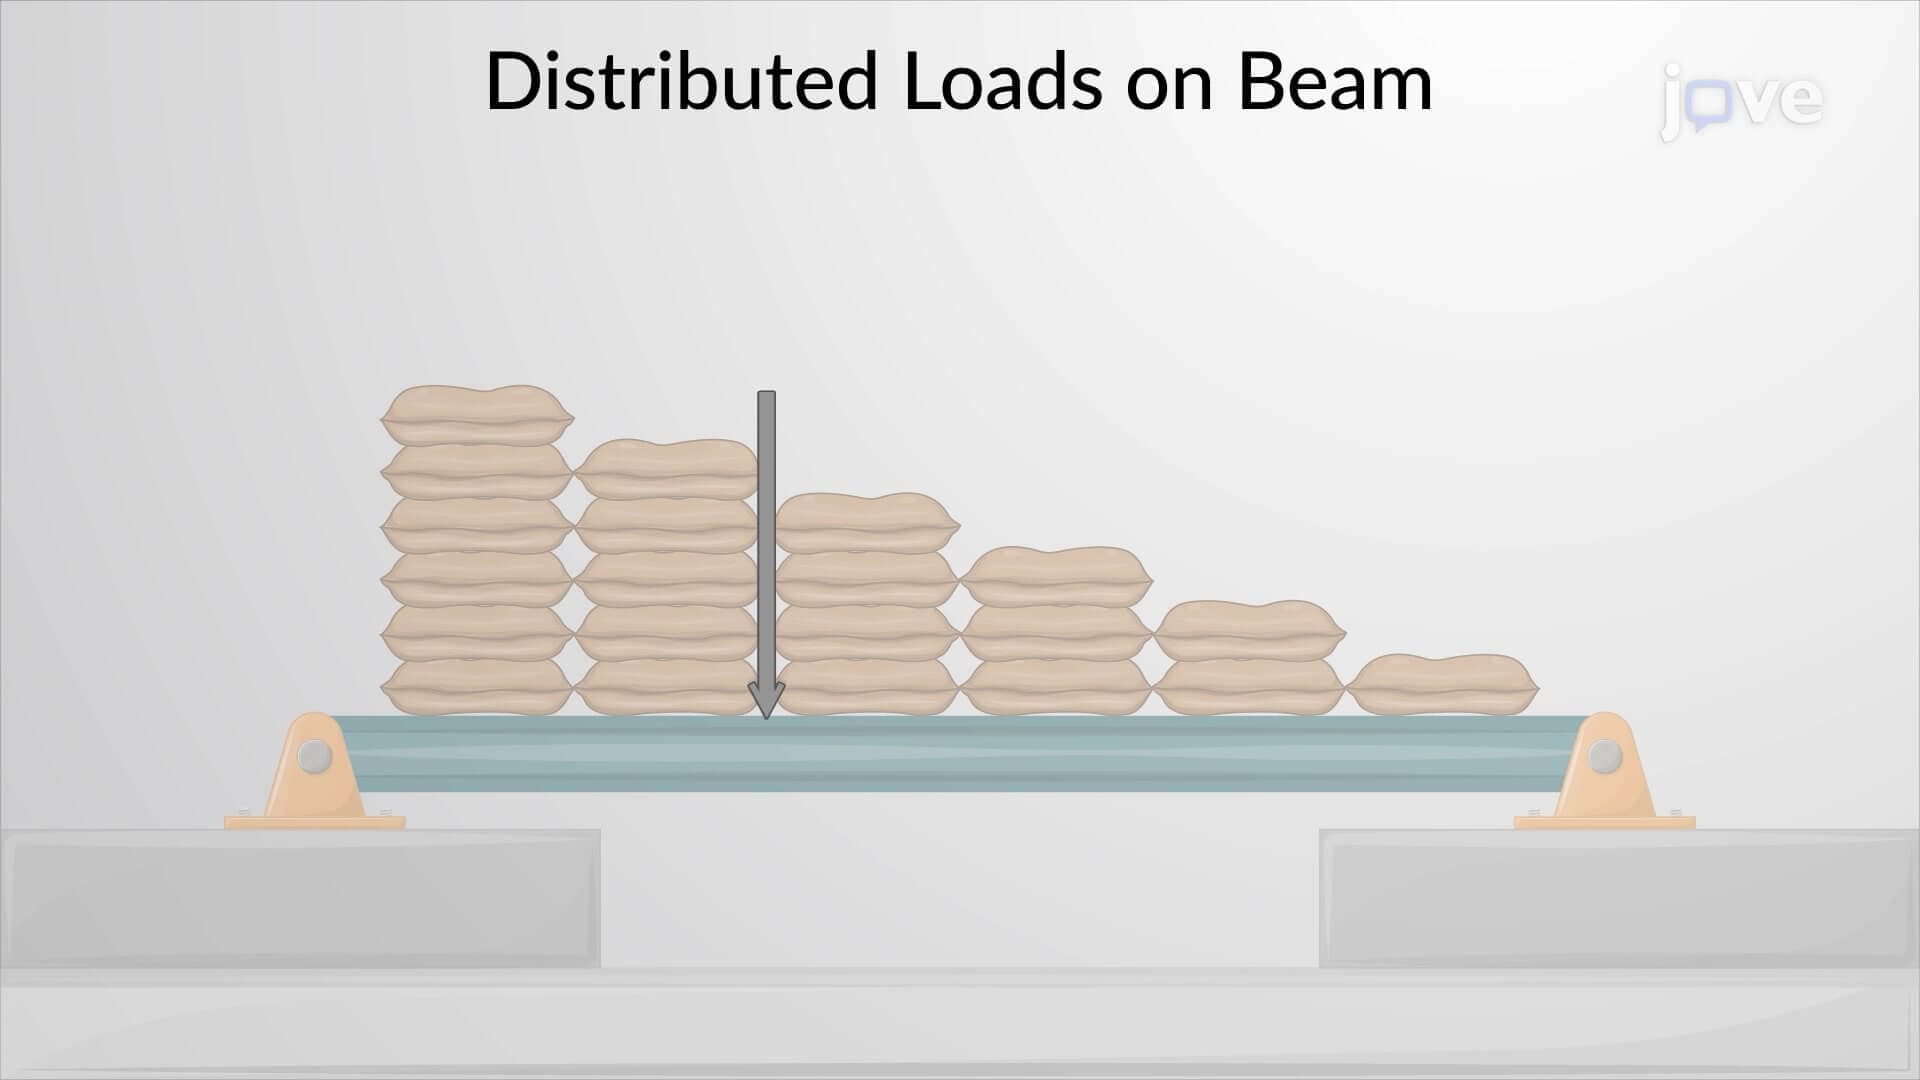
Resultant of a General Distributed Loading
Examples such as load distribution due to wind and load distribution on a bridge illustrate how this concept is used to analyze and design safe, reliable structures under variable loading conditions. Most structures, such as residential buildings, bridges, and towers, are...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:20
Elastic Strain Energy for Shearing Stresses
 01:18
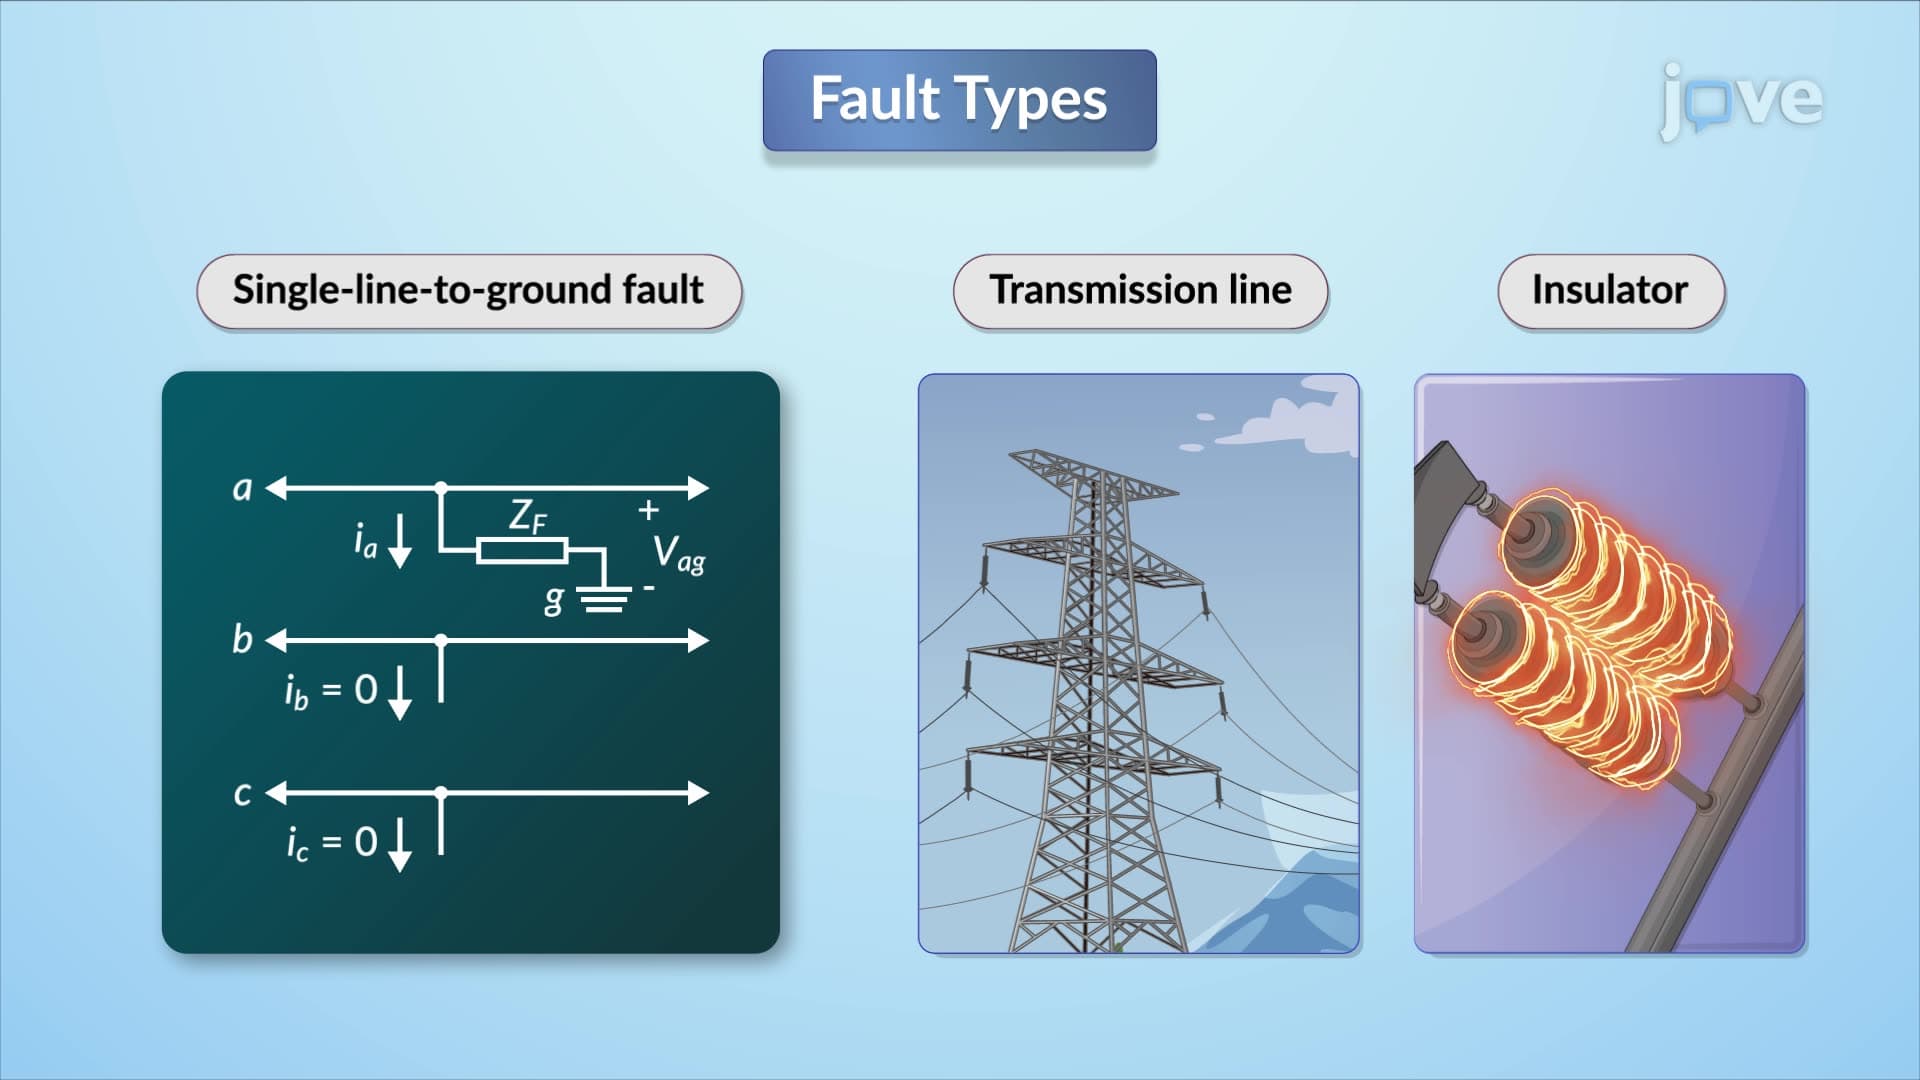
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:23
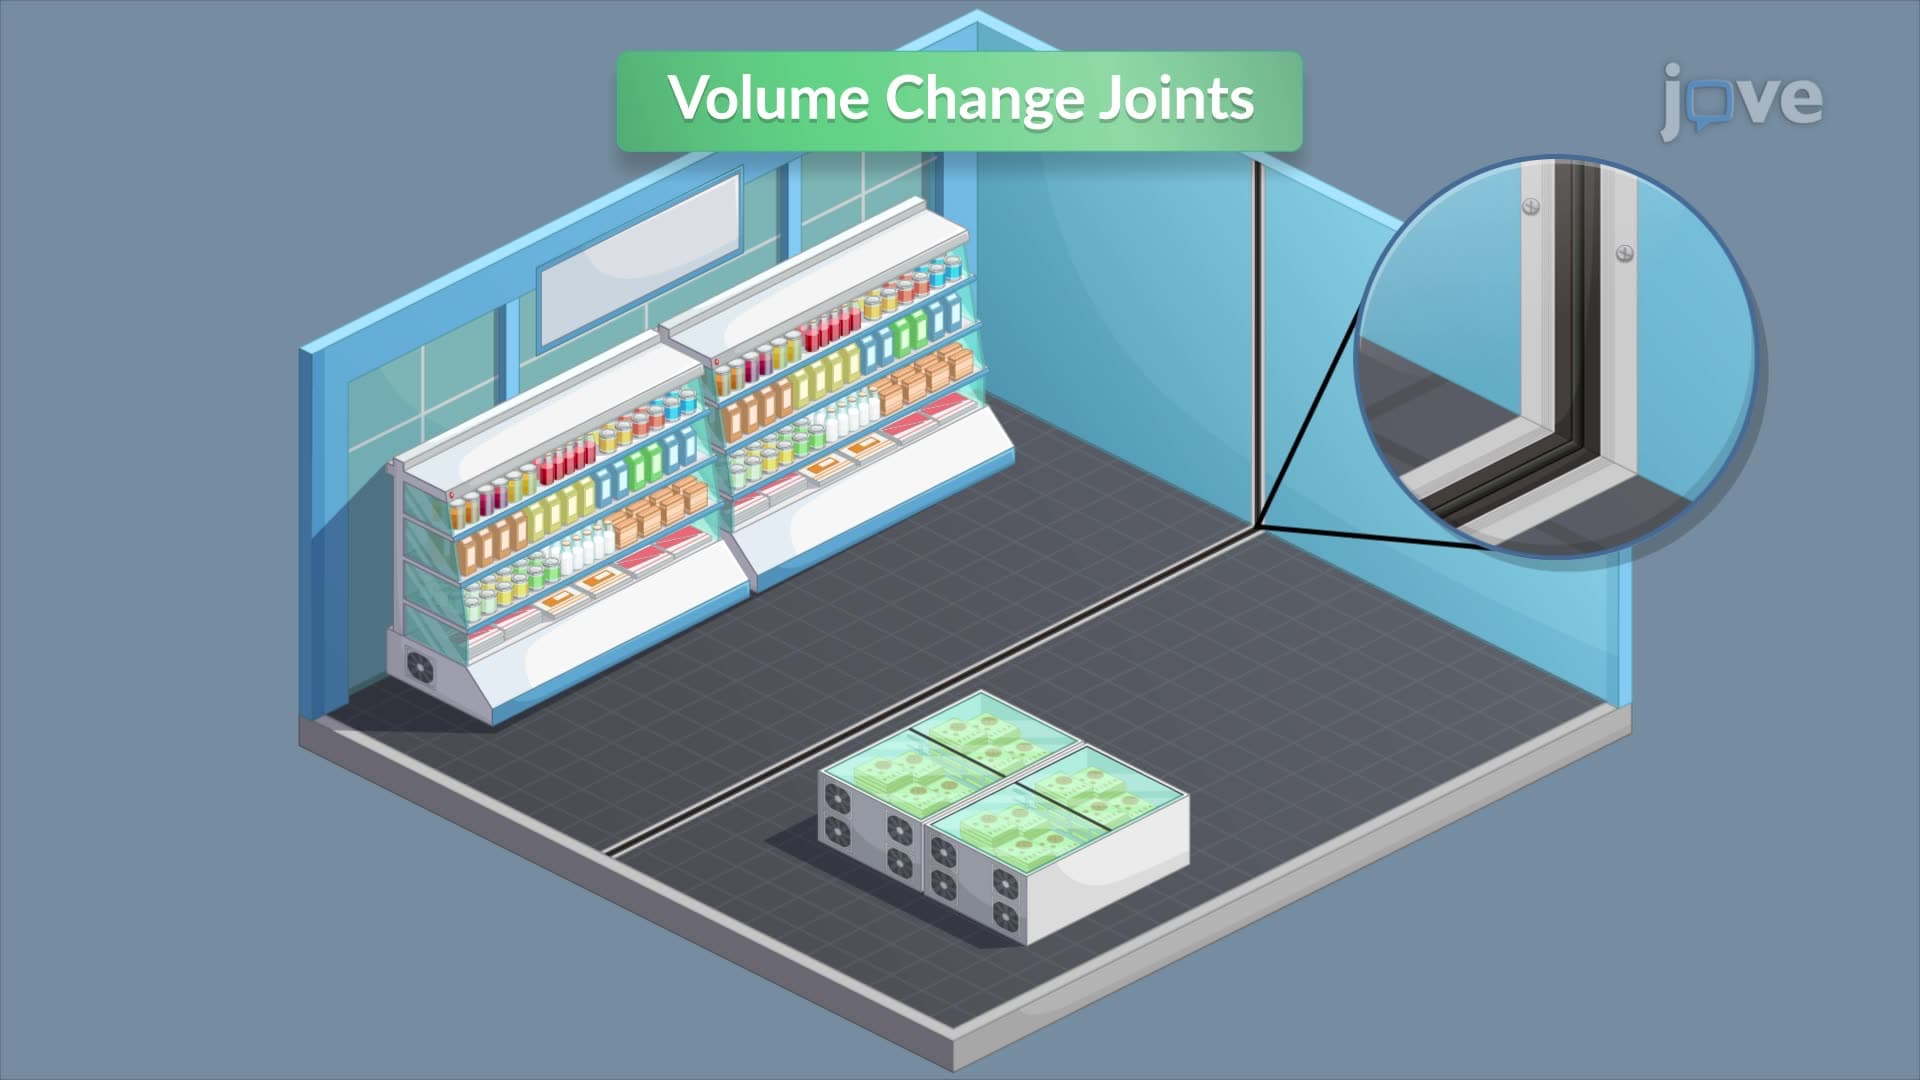
Types of Building Separation Joints
Volume-change joints address the effects of expansion and contraction due to temperature and moisture variations. They are strategically placed at discontinuities in a building's mass where cracking is most likely and are spaced about 150 to 200 feet...