Related Experiment Video
Updated: Aug 19, 2026

Utilizing a 3D Printed Laparoscopic Nissen Fundoplication Model to Shorten a Resident's Learning Curve
Published on: August 15, 2025
Control of laparoscopic instrument motion in an inanimate bench model: implications for the training and evaluation
David Gonzalez1, Heather Carnahan, Monate Praamsma
1Department of Kinesiology, University of Waterloo, Waterloo, Ontario, Canada.

Abstract:
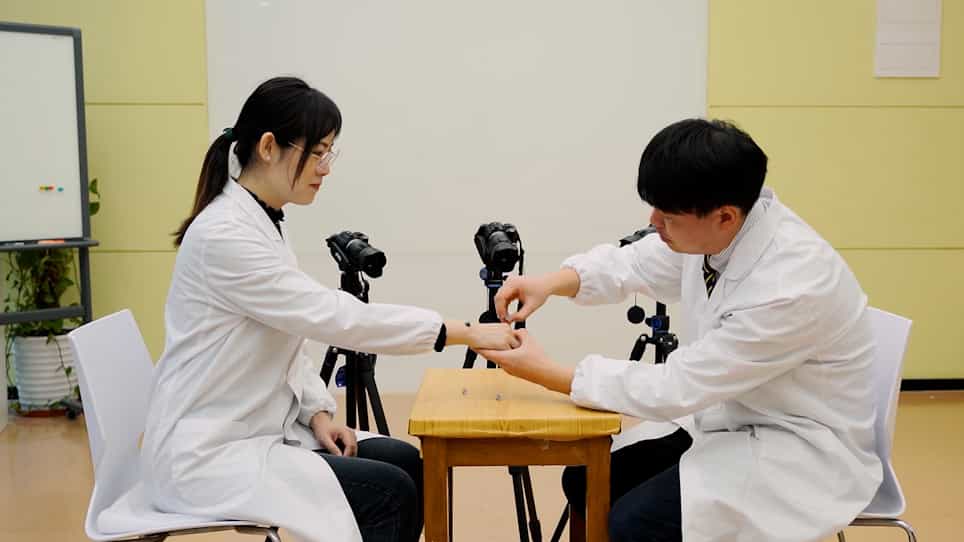
Laparoscopic surgery requires new methods of technical competency evaluation, as well as training. The first purpose was to assess the differences in motion characteristics between the tip of the instrument and the wrist. The second purpose was to determine whether similar control strategies are used to move instruments in virtual reality and bench model environments. Surgically naive participants were required to tap a laparoscopic instrument between two targets that differed in size and separation distance. Large amplitude movements were controlled with the movements of the wrist and small amplitude with the wrist and the fingers (p<.001). Participants utilized the flexibility of the skin of the laparoscopic trainer to facilitate their movements. These results suggest that monitoring the motions of the instrument tip is a more precise indication of its motions than are motions of the wrist when movements of small amplitudes are produced. Moreover, in order to increase fidelity, VR trainers should simulate the flexibility of the real structures around the insertion of the instrument.