Related Experiment Video
Updated: Aug 19, 2026
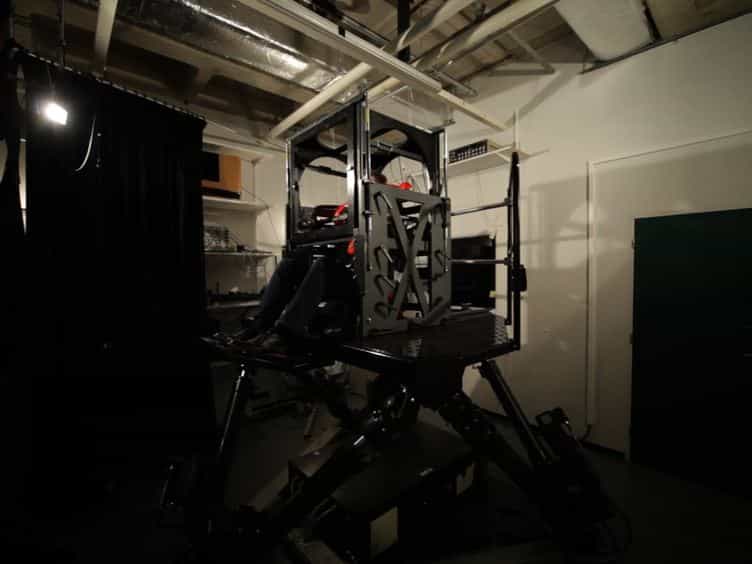

Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Vestibular coriolis effect differences modeled with three-dimensional linear-angular interactions
1Department of Mathematics, Colby College, Mayflower Hill Drive, Waterville, ME 04901, USA. jeholly@colby.edu

Abstract:
The vestibular coriolis (or "cross-coupling") effect is traditionally explained by cross-coupled angular vectors, which, however, do not explain the differences in perceptual disturbance under different acceleration conditions. For example, during head roll tilt in a rotating chair, the magnitude of perceptual disturbance is affected by a number of factors, including acceleration or deceleration of the chair rotation or a zero-g environment. Therefore, it has been suggested that linear-angular interactions play a role. The present research investigated whether these perceptual differences and others involving linear coriolis accelerations could be explained under one common framework: the laws of motion in three dimensions, which include all linear-angular interactions among all six components of motion (three angular and three linear). The results show that the three-dimensional laws of motion predict the differences in perceptual disturbance. No special properties of the vestibular system or nervous system are required. In addition, simulations were performed with angular, linear, and tilt time constants inserted into the model, giving the same predictions. Three-dimensional graphics were used to highlight the manner in which linear-angular interaction causes perceptual disturbance, and a crucial component is the Stretch Factor, which measures the "unexpected" linear component.
More Related Videos
 05:02
Using Unidirectional Rotations to Improve Vestibular System Asymmetry in Patients with Vestibular Dysfunction
Published on: August 30, 2019
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:23
Coriolis Force
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:37
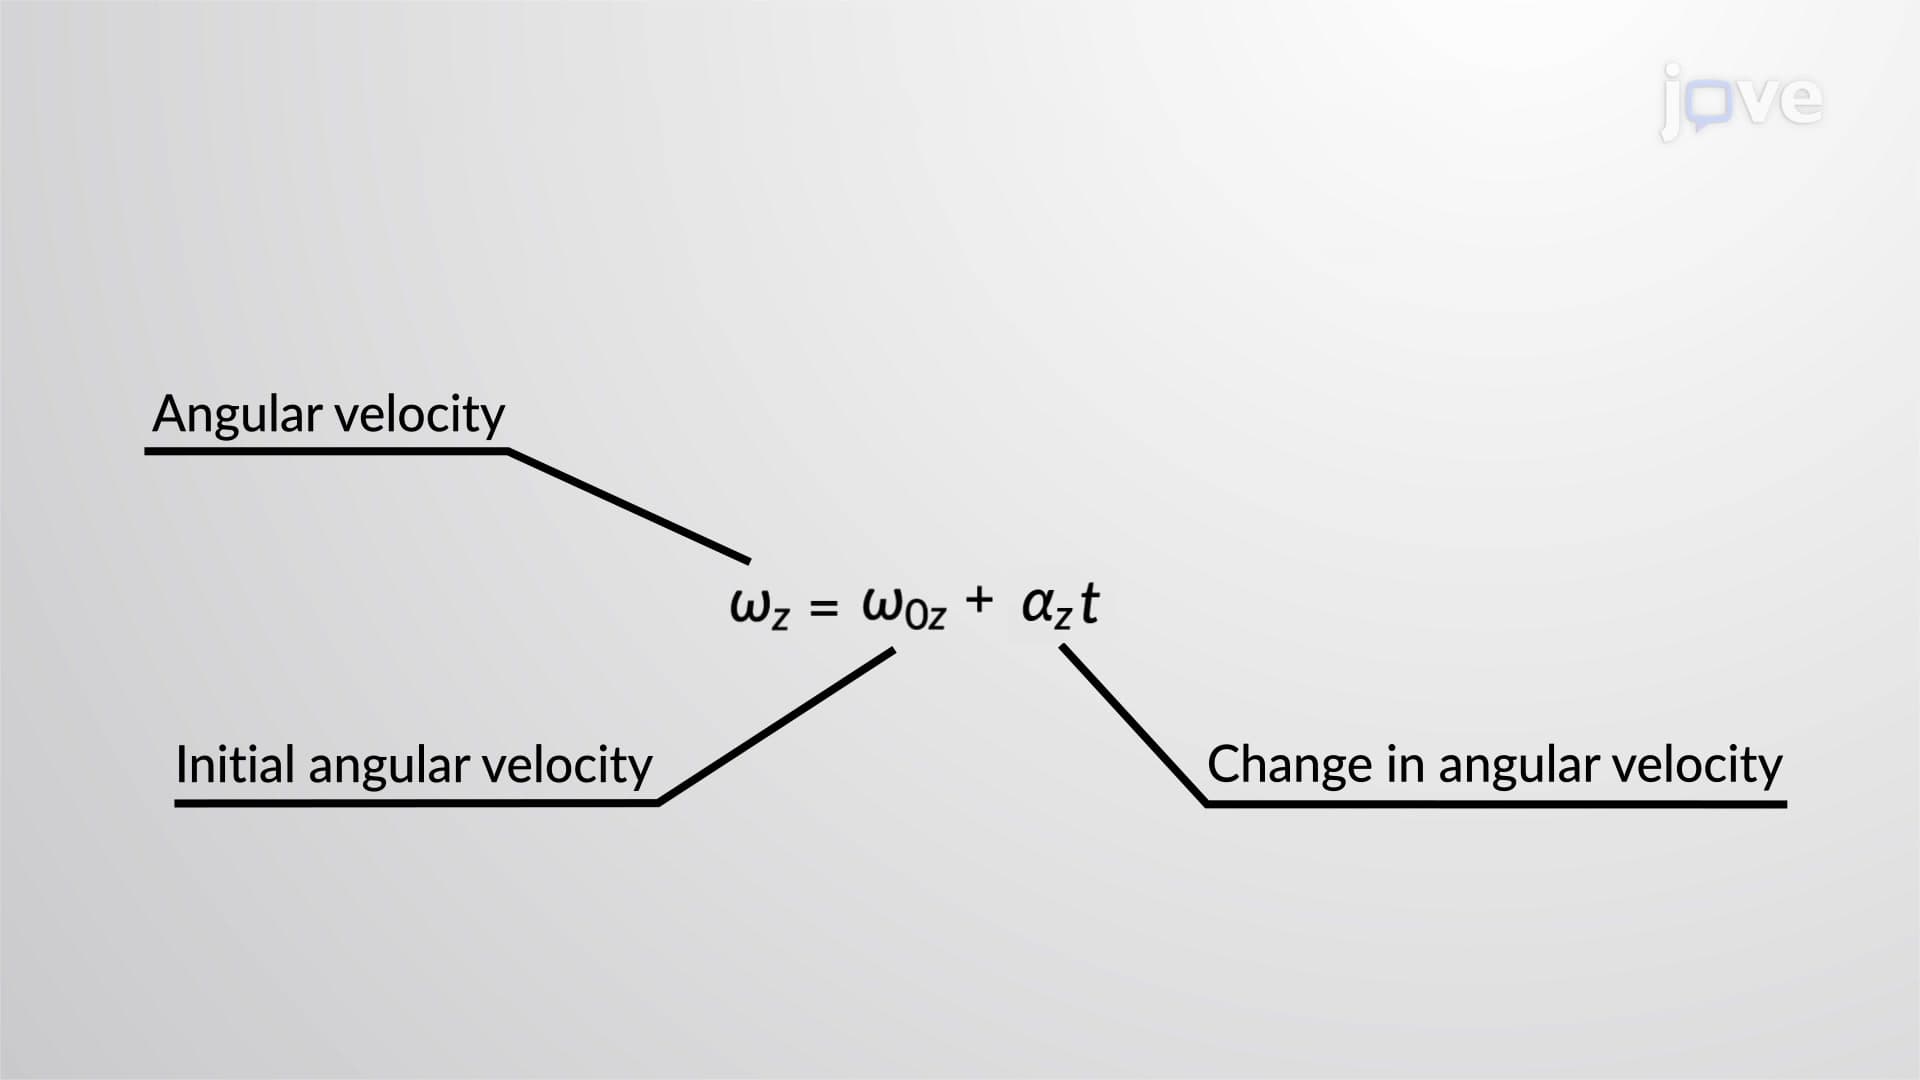
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:27
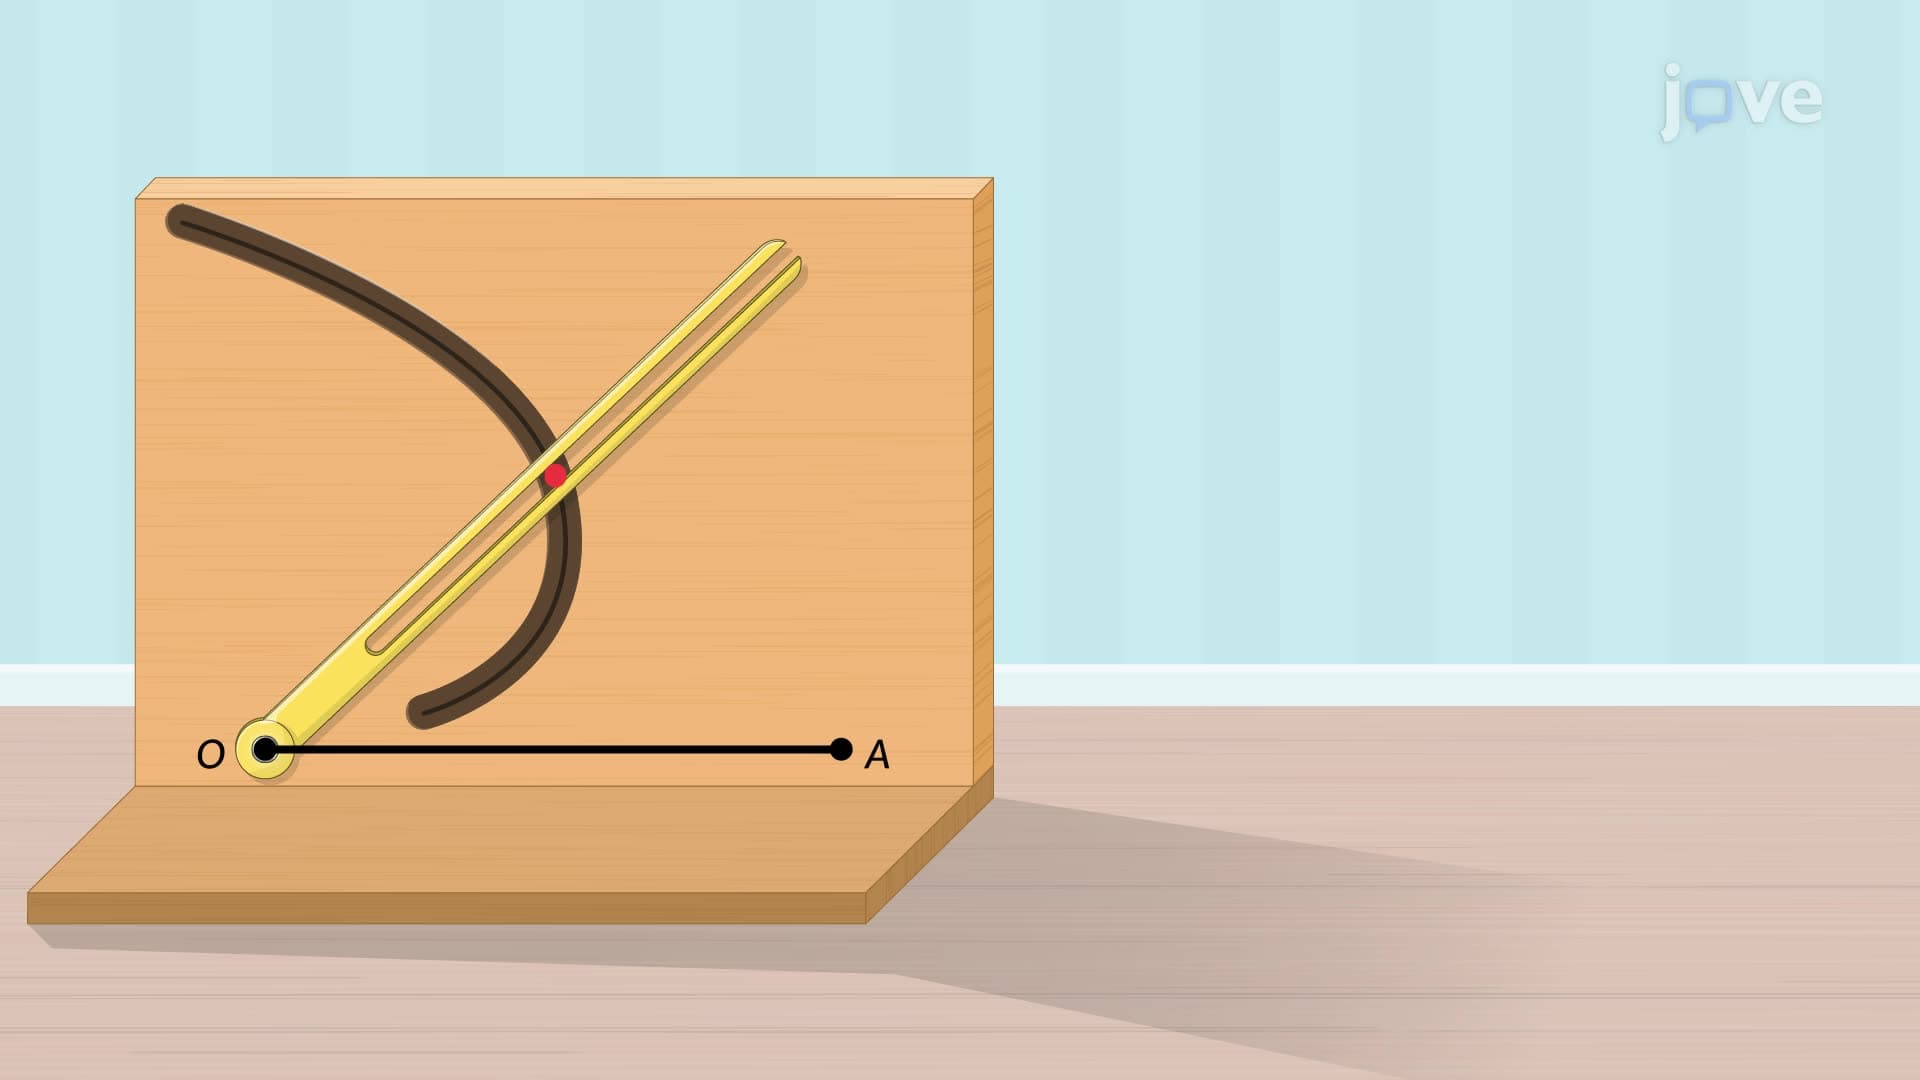
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...