Related Experiment Video
Updated: Aug 19, 2026
Three-dimensional Particle Tracking Velocimetry for Turbulence Applications: Case of a Jet Flow
Published on: February 27, 2016
Simultaneous two-view epipolar geometry estimation and motion segmentation by 4D tensor voting
Wai-Shun Tong1, Chi-Keung Tang, Gérard Medioni
1Department of Computer Science, Hong Kong University of Science & Technology, Clear Water Bay, Hong Kong. cstws@cs.ust.hk

Abstract:
We address the problem of simultaneous two-view epipolar geometry estimation and motion segmentation from nonstatic scenes. Given a set of noisy image pairs containing matches of n objects, we propose an unconventional, efficient, and robust method, 4D tensor voting, for estimating the unknown n epipolar geometries, and segmenting the static and motion matching pairs into n independent motions. By considering the 4D isotropic and orthogonal joint image space, only two tensor voting passes are needed, and a very high noise to signal ratio (up to five) can be tolerated. Epipolar geometries corresponding to multiple, rigid motions are extracted in succession. Only two uncalibrated frames are needed, and no simplifying assumption (such as affine camera model or homographic model between images) other than the pin-hole camera model is made. Our novel approach consists of propagating a local geometric smoothness constraint in the 4D joint image space, followed by global consistency enforcement for extracting the fundamental matrices corresponding to independent motions. We have performed extensive experiments to compare our method with some representative algorithms to show that better performance on nonstatic scenes are achieved. Results on challenging data sets are presented.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
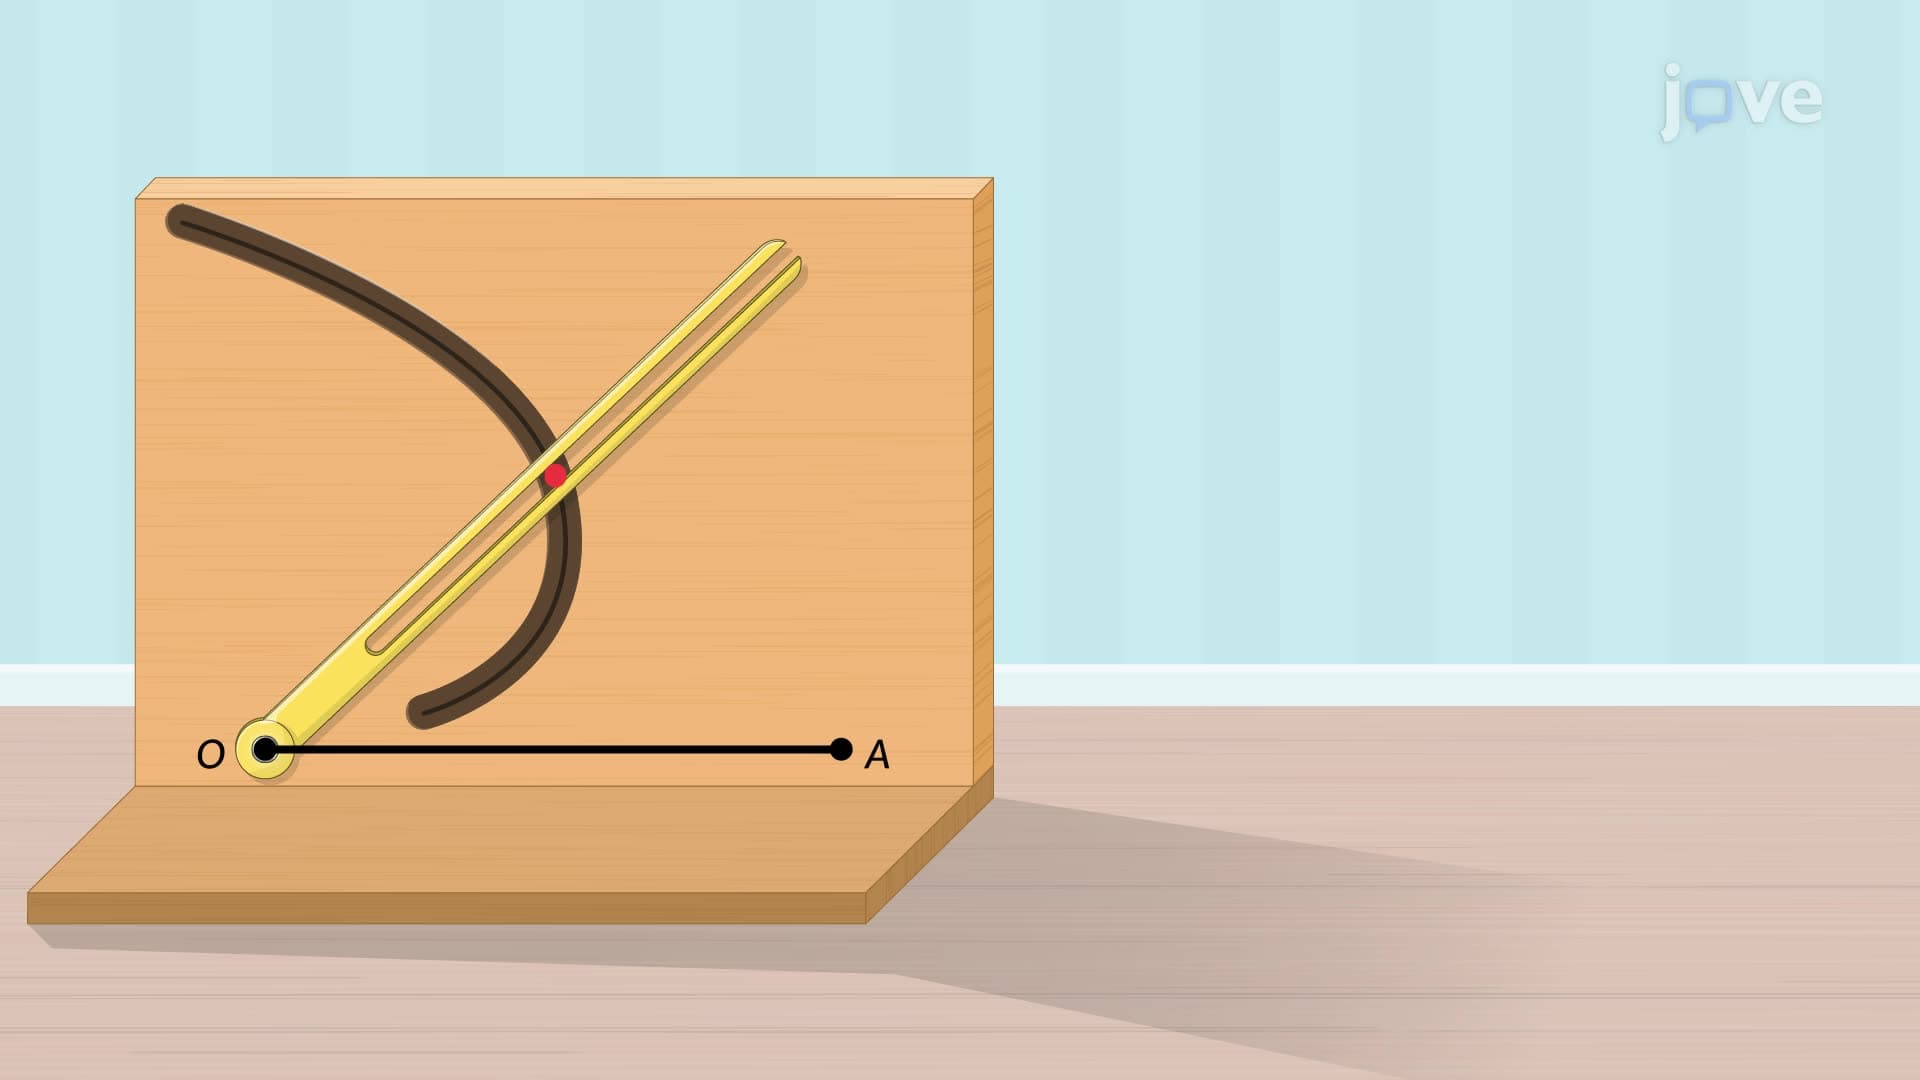
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:20
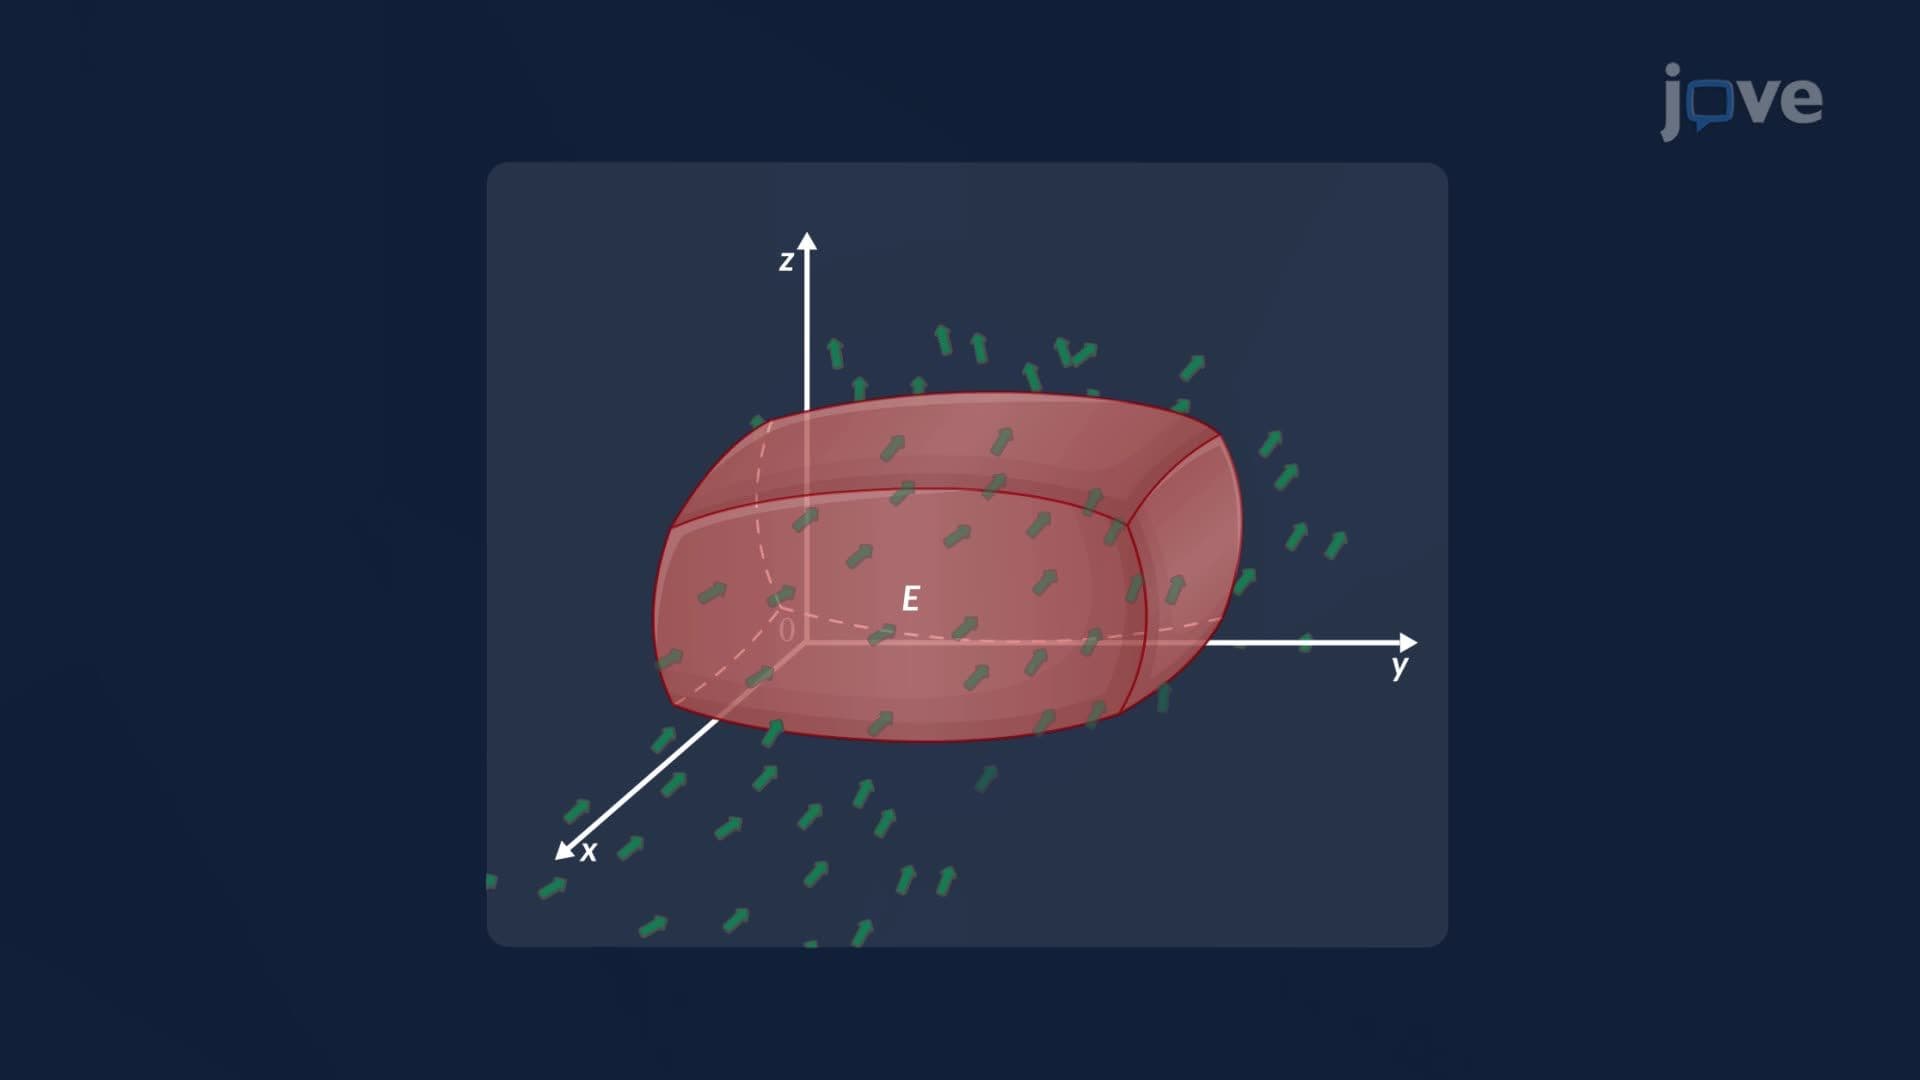
Divergence Theorem in 3D Space