Related Experiment Video
Updated: Aug 18, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Regularity in an environment produces an internal torque pattern for biped balance control
Satoshi Ito1, Haruhisa Kawasaki
1Department of human and information systems, Faculty of Engineering, Gifu University, Yanagido 1-1, Gifu, 501-1193, Japan. satoshi@cc.gifu-u.ac.jp

Abstract:
In this paper, we present a control method for achieving biped static balance under unknown periodic external forces whose periods are only known. In order to maintain static balance adaptively in an uncertain environment, it is essential to have information on the ground reaction forces. However, when the biped is exposed to a steady environment that provides an external force periodically, uncertain factors on the regularity with respect to a steady environment are gradually clarified using learning process, and finally a torque pattern for balancing motion is acquired. Consequently, static balance is maintained without feedback from ground reaction forces and achieved in a feedforward manner.
Related Concept Videos
 00:49
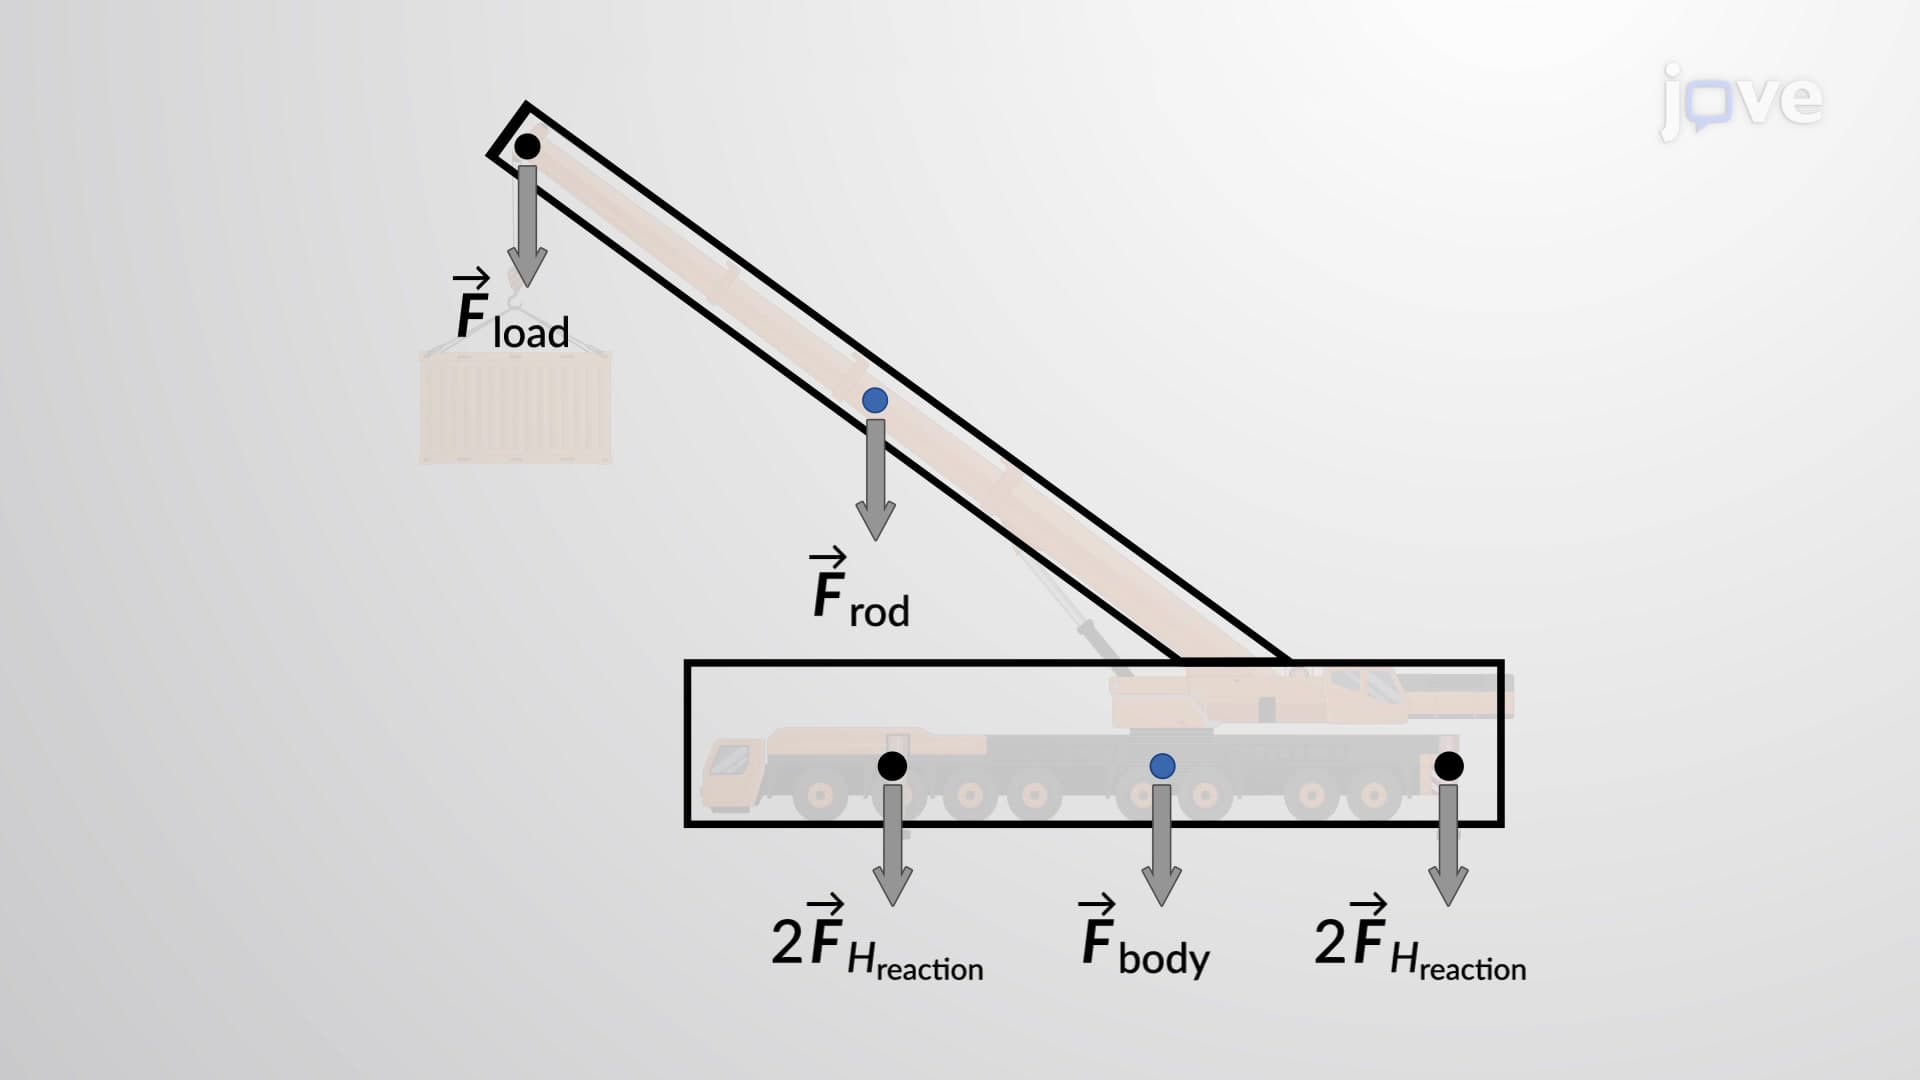
Rigid Body Equilibrium Problems - I
 01:15
Equilibrium and Balance
 01:10
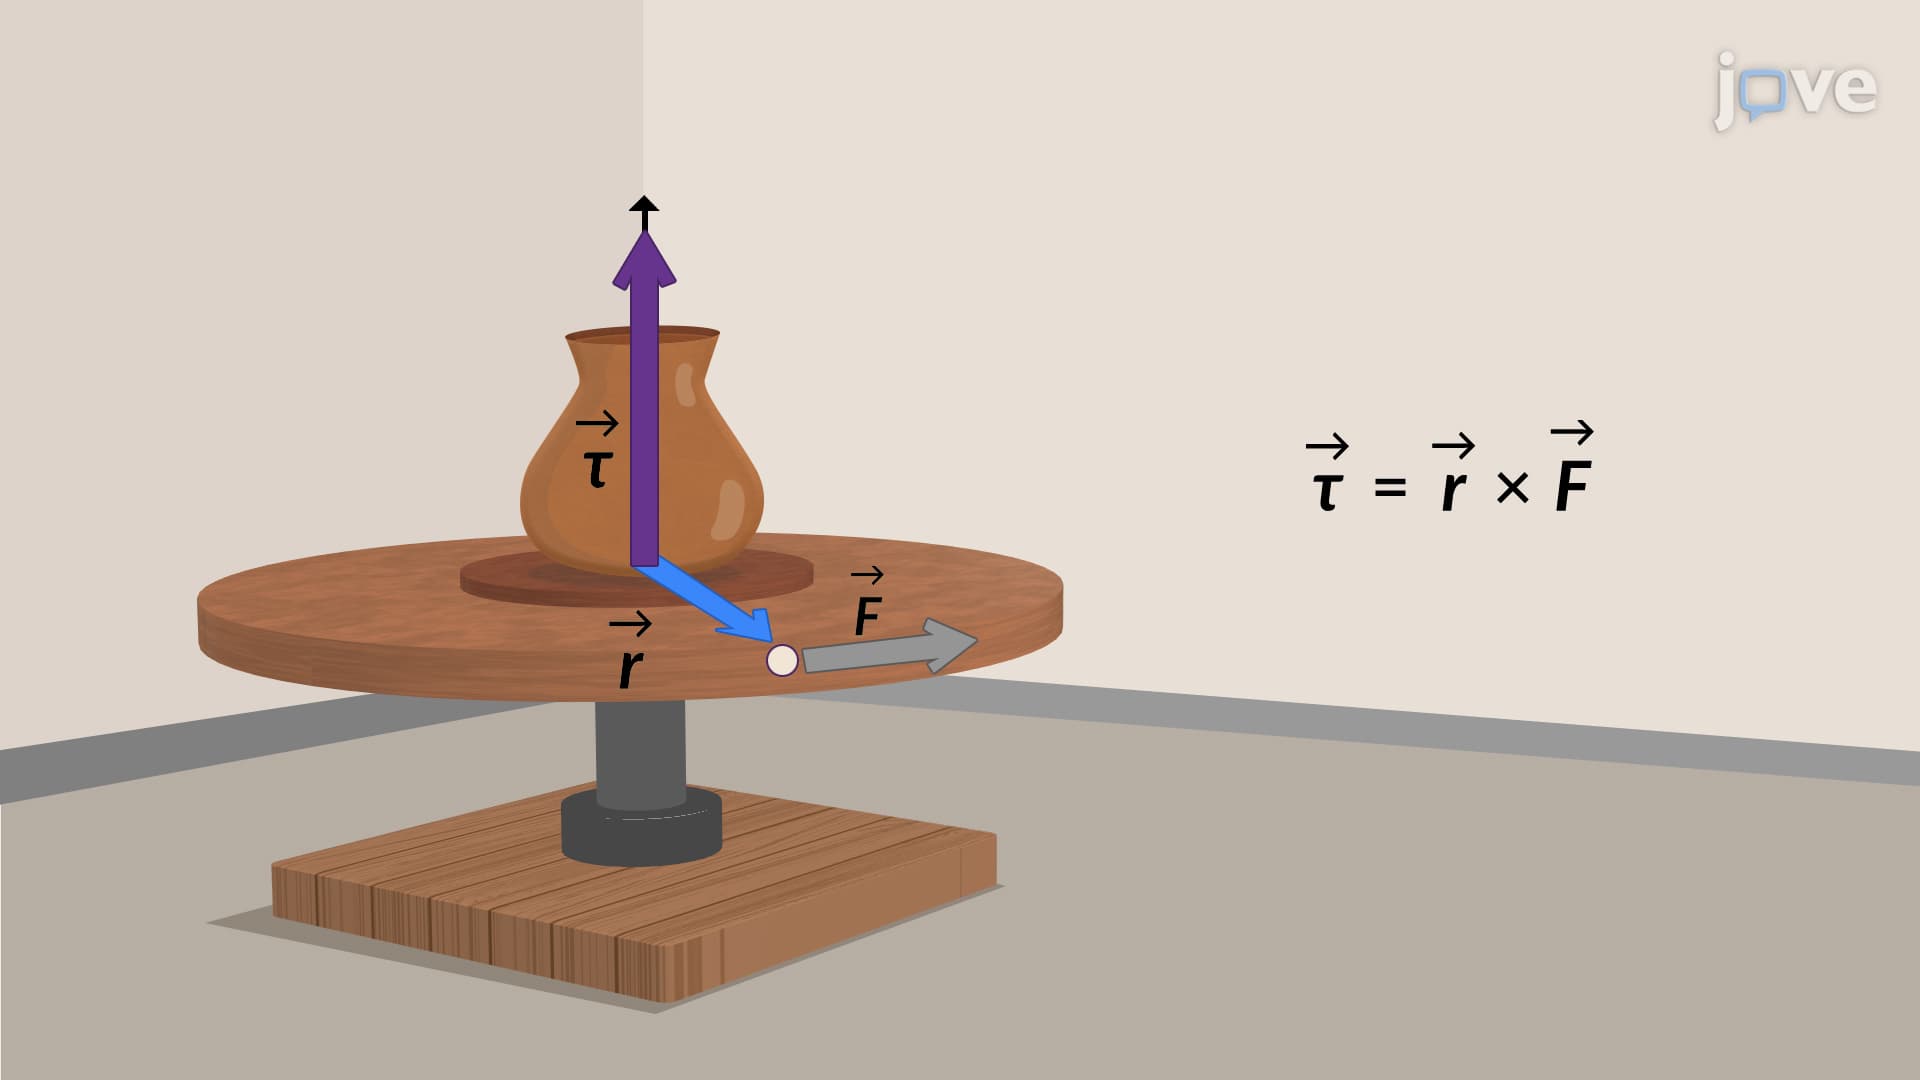
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:14
Stability of structures
 01:15
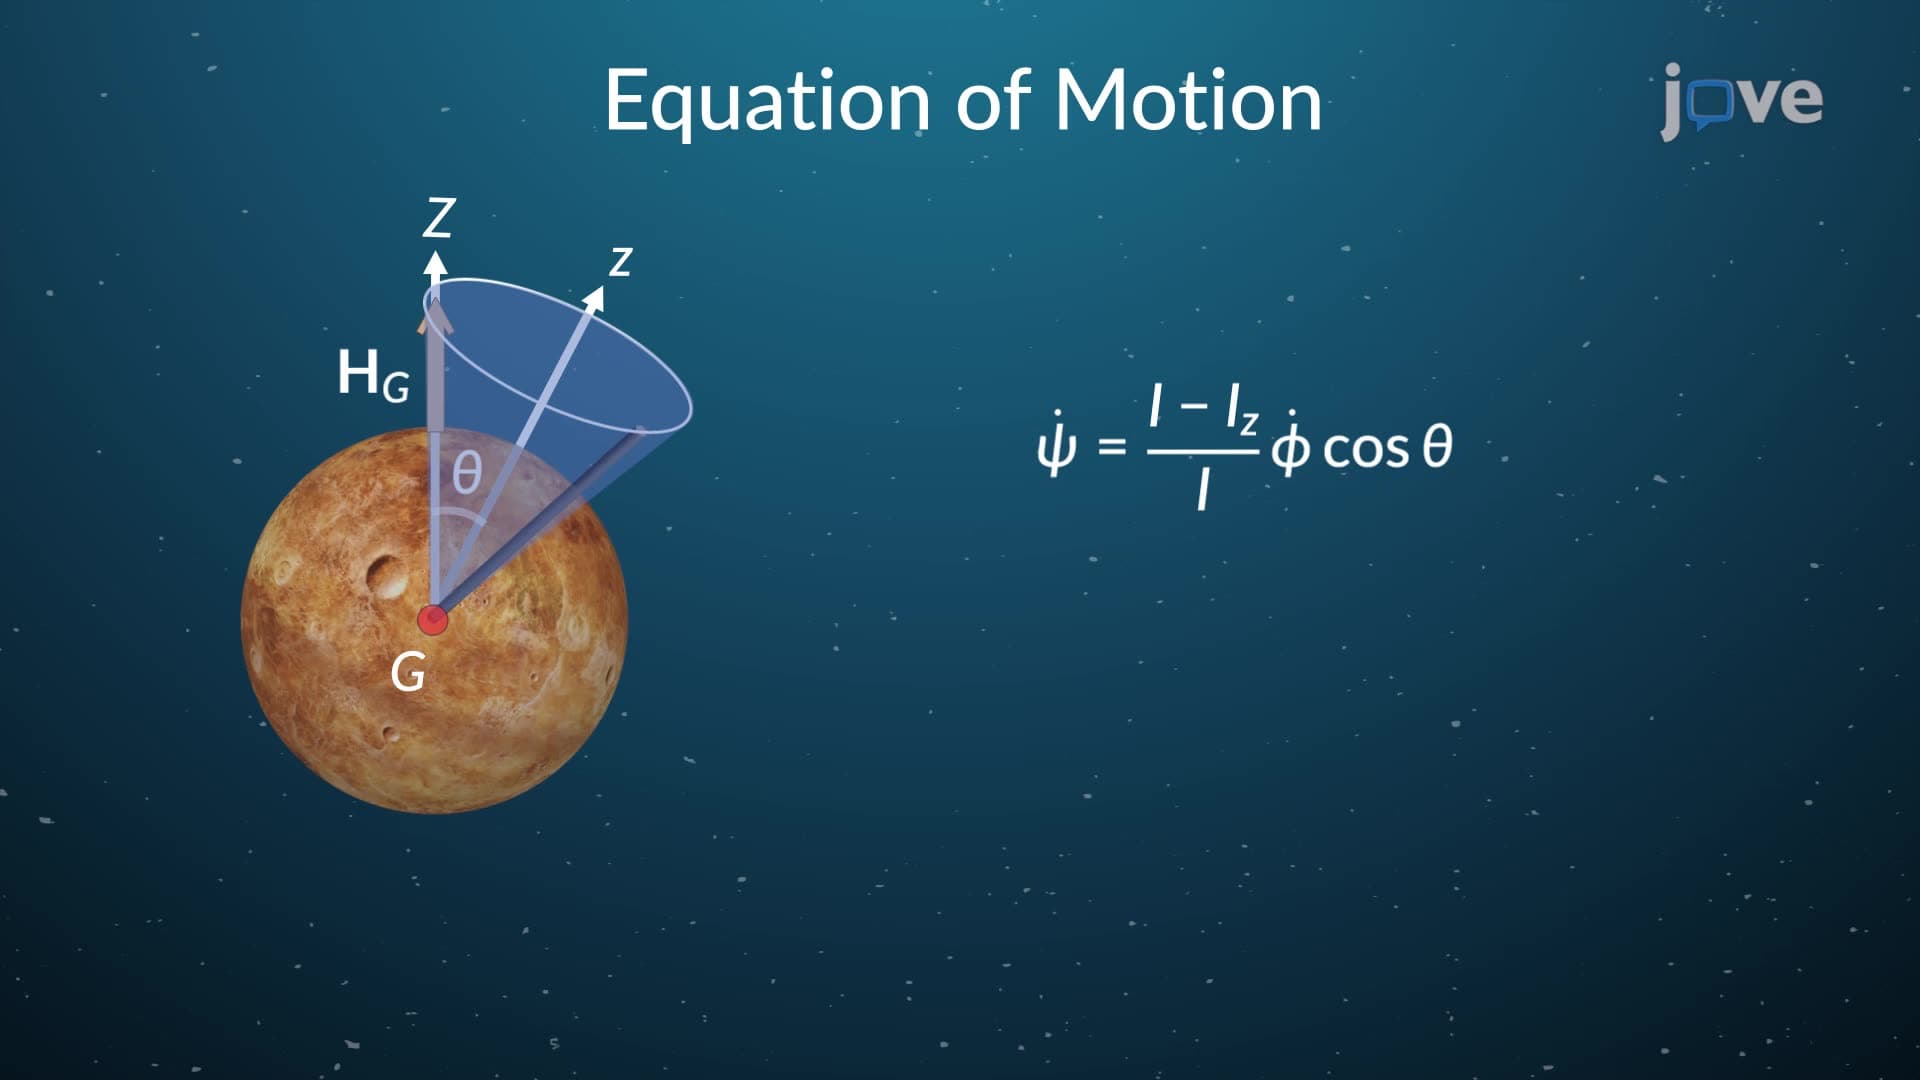
Torque Free Motion