Support torques during simulated sit-to-stand movements
Related Experiment Video
Updated: Aug 18, 2026
Quantifying Arms and Legs Contributions during Repetitive Electrically-Assisted Sit-To-Stand Exercise in Paraplegics: A Pilot Study
Published on: November 11, 2022
Jason C Gillette1, Catherine A Stevermer, Shashank Raina
1Department of Health and Human Performance, Iowa State University Ames, IA 50011-1160, USA.

Abstract:
Sit-to-stand movements are a fundamental daily activity and a prerequisite to upright posture. Previous simulations of spinal cord injured individuals using functional neuromuscular stimulation (FNS) suggested a forward foot placement would reduce hand-support forces. However, this recommendation has proved to be difficult for able-bodied individuals standing hands-free and for individuals with spinal cord injuries standing with a walker. This inverse model is a step towards the goal of using forward simulations to determine efficient sit-to-stand strategies. Initial seated postures varied from 80-110 degrees of knee flexion and 90-120 degrees of hip flexion. Realistic progressions of lower extremity joint angles including development of linear momentum were created using sigmoid functions. These kinematic values were used to estimate the required resultant joint torques to complete sit-to-stand. Joint torque values that act to raise the body were combined to indicate sit-to-stand difficulty from different seated postures. A representative foot-forward placement (knee 80 degrees, hip 90 degrees) resulted in a maximum combined torque of 544 Nm. In contrast, a representative foot-back placement (knee 110 degrees, hip 120 degrees) resulted in a maximum combined torque of 661 Nm. An intermediate seated posture (knee 97 degrees, hip 90 degrees) produced the lowest maximum combined torque of 401 Nm (2 Nm ankle plantarflexion, 201 Nm knee extension, 198 Nm hip extension). Foot-forward placement required substantial ankle dorsiflexion torques. The most efficient strategy appeared to be combining a foot back placement with momentum generation using hip flexion. By generalizing the sit-to-stand model beyond FNS-driven movements, further insight may be gained into other populations (i.e., elderly).
Related Concept Videos
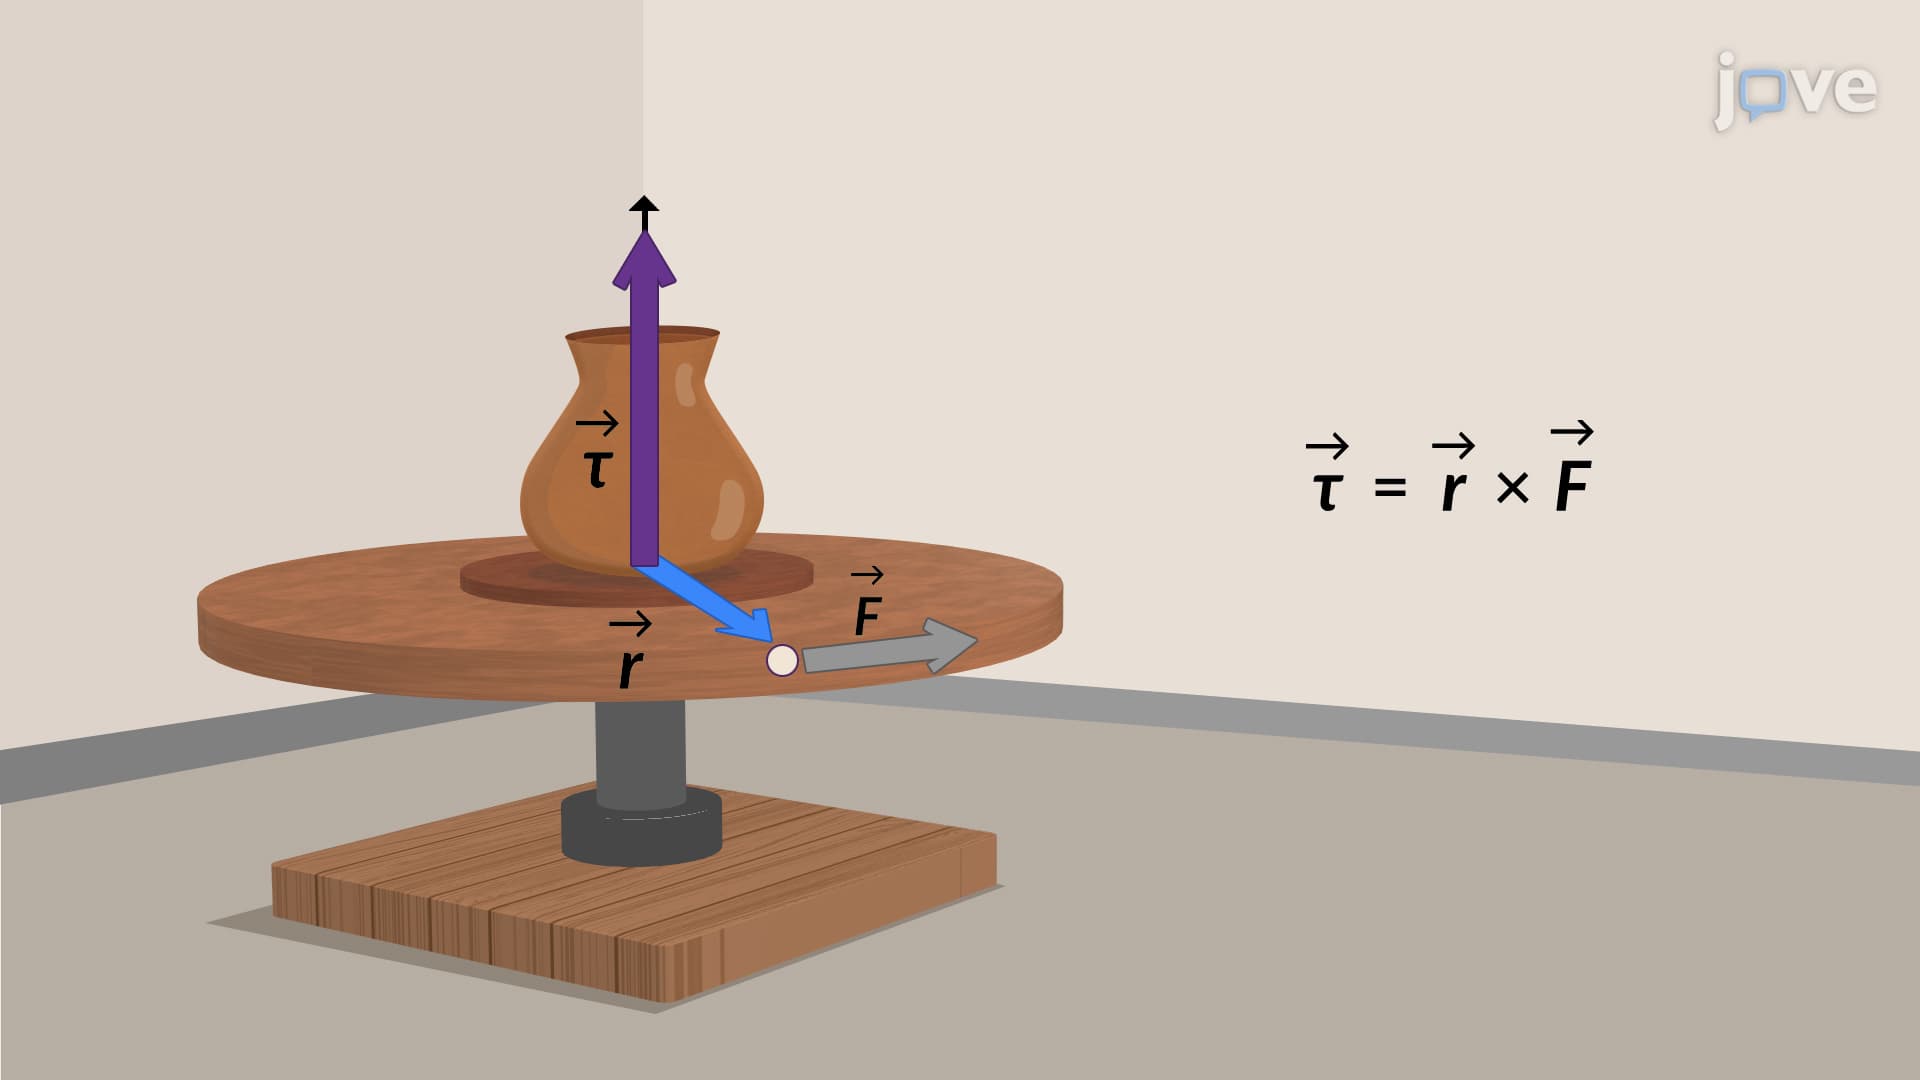 01:10
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:19
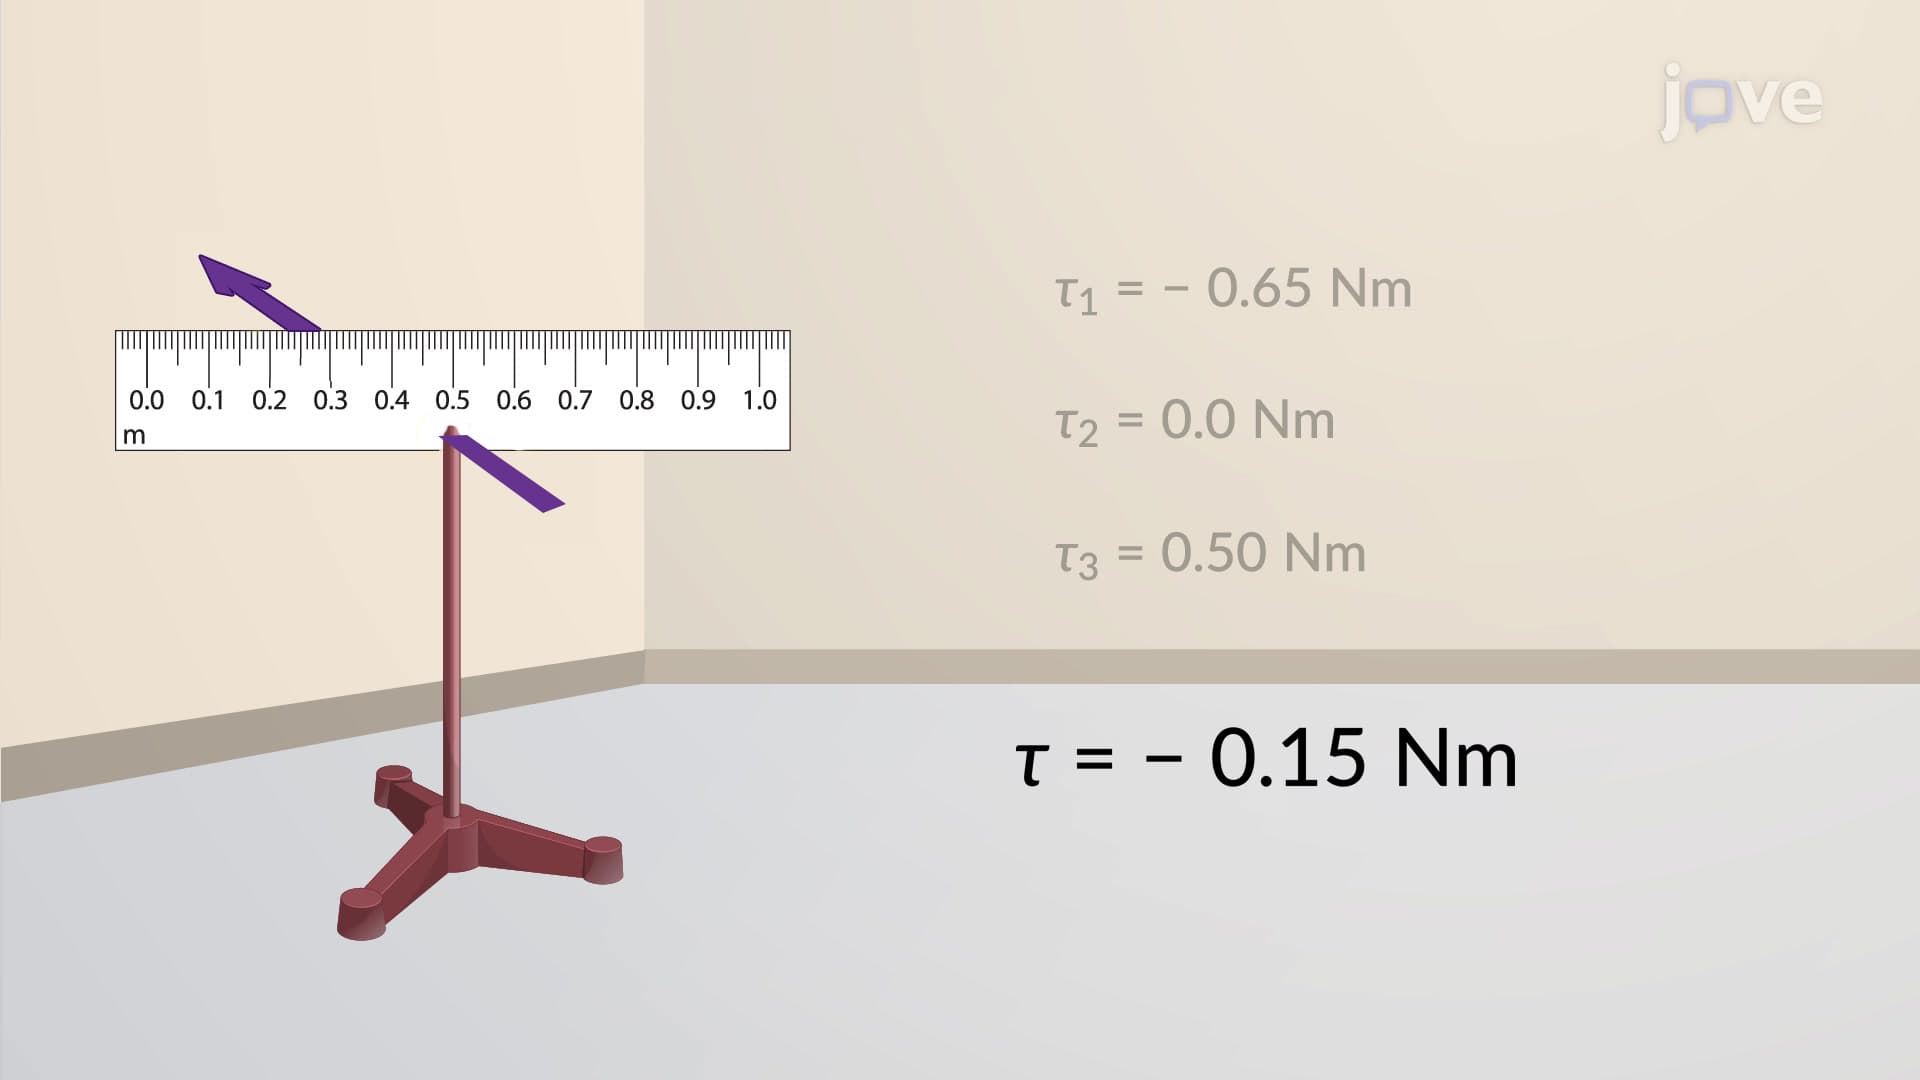
Net Torque Calculations
 01:15
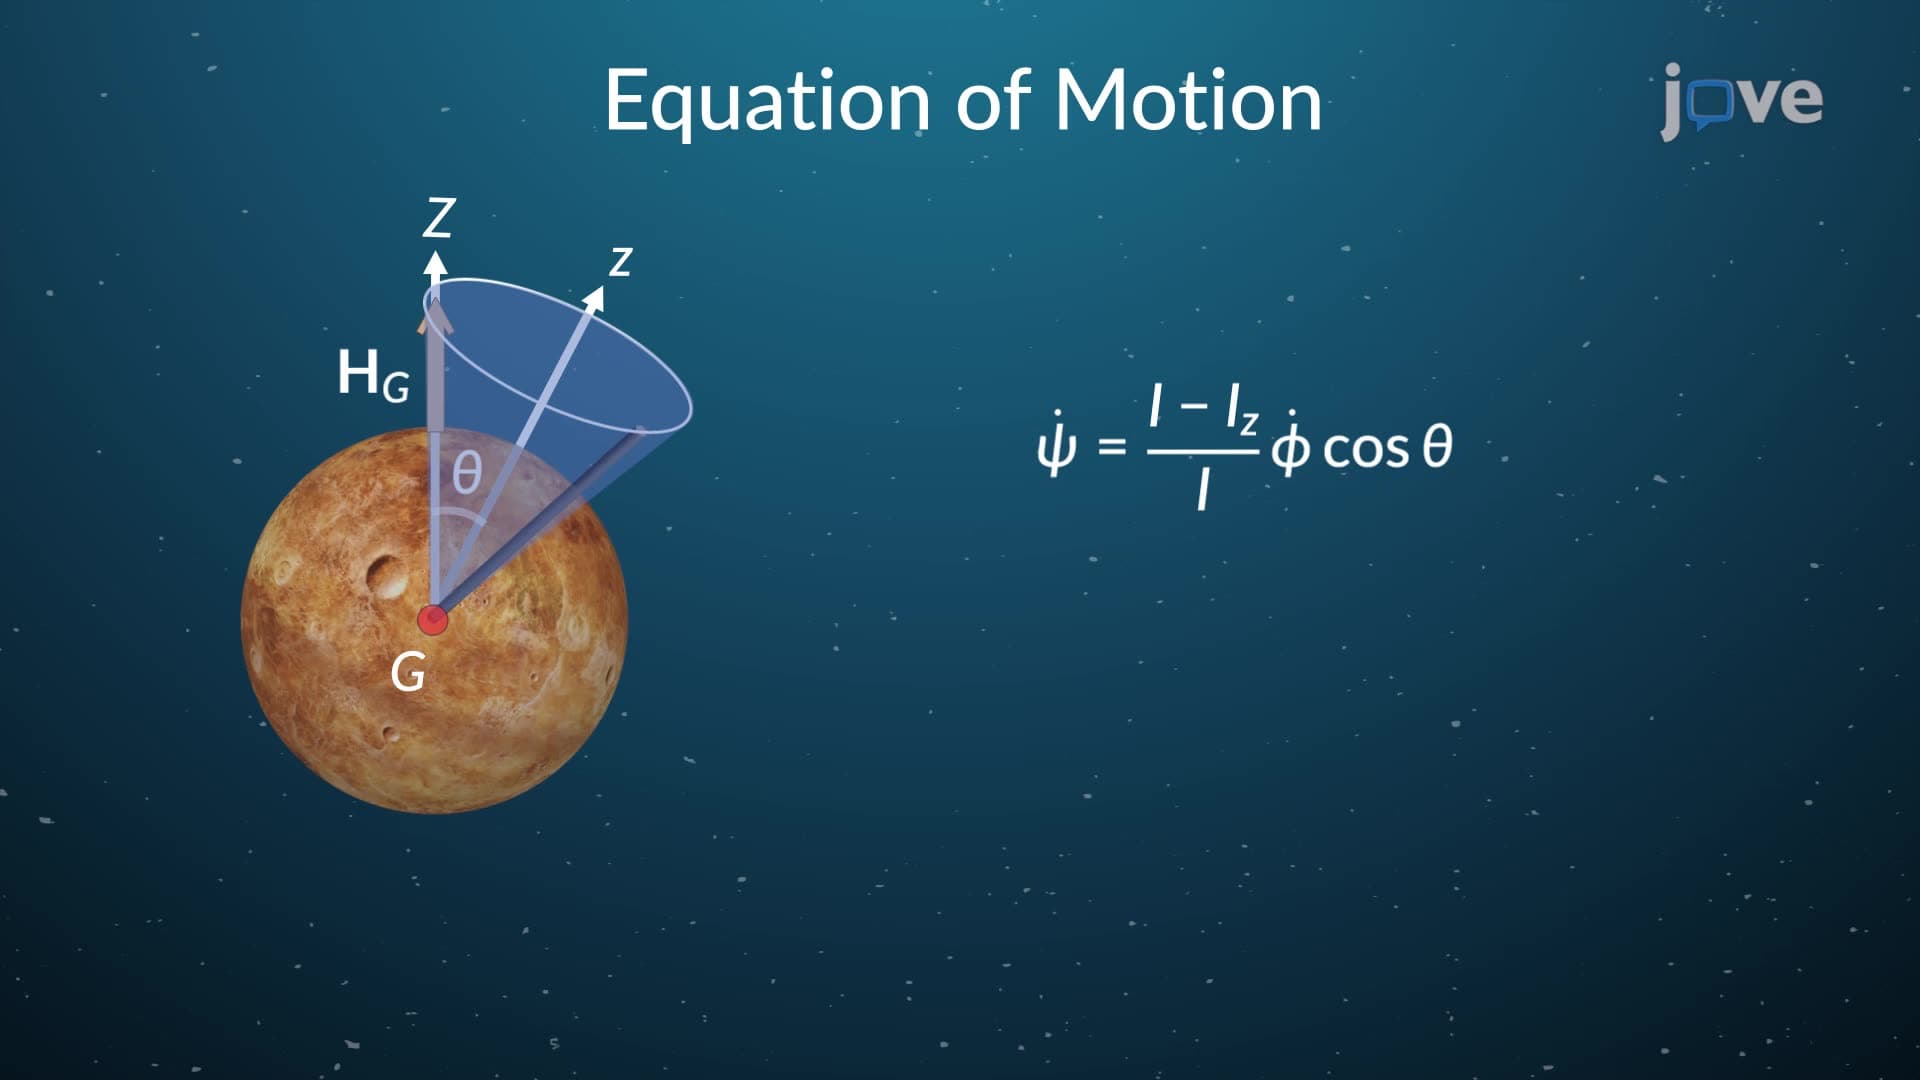
Torque Free Motion
 01:21
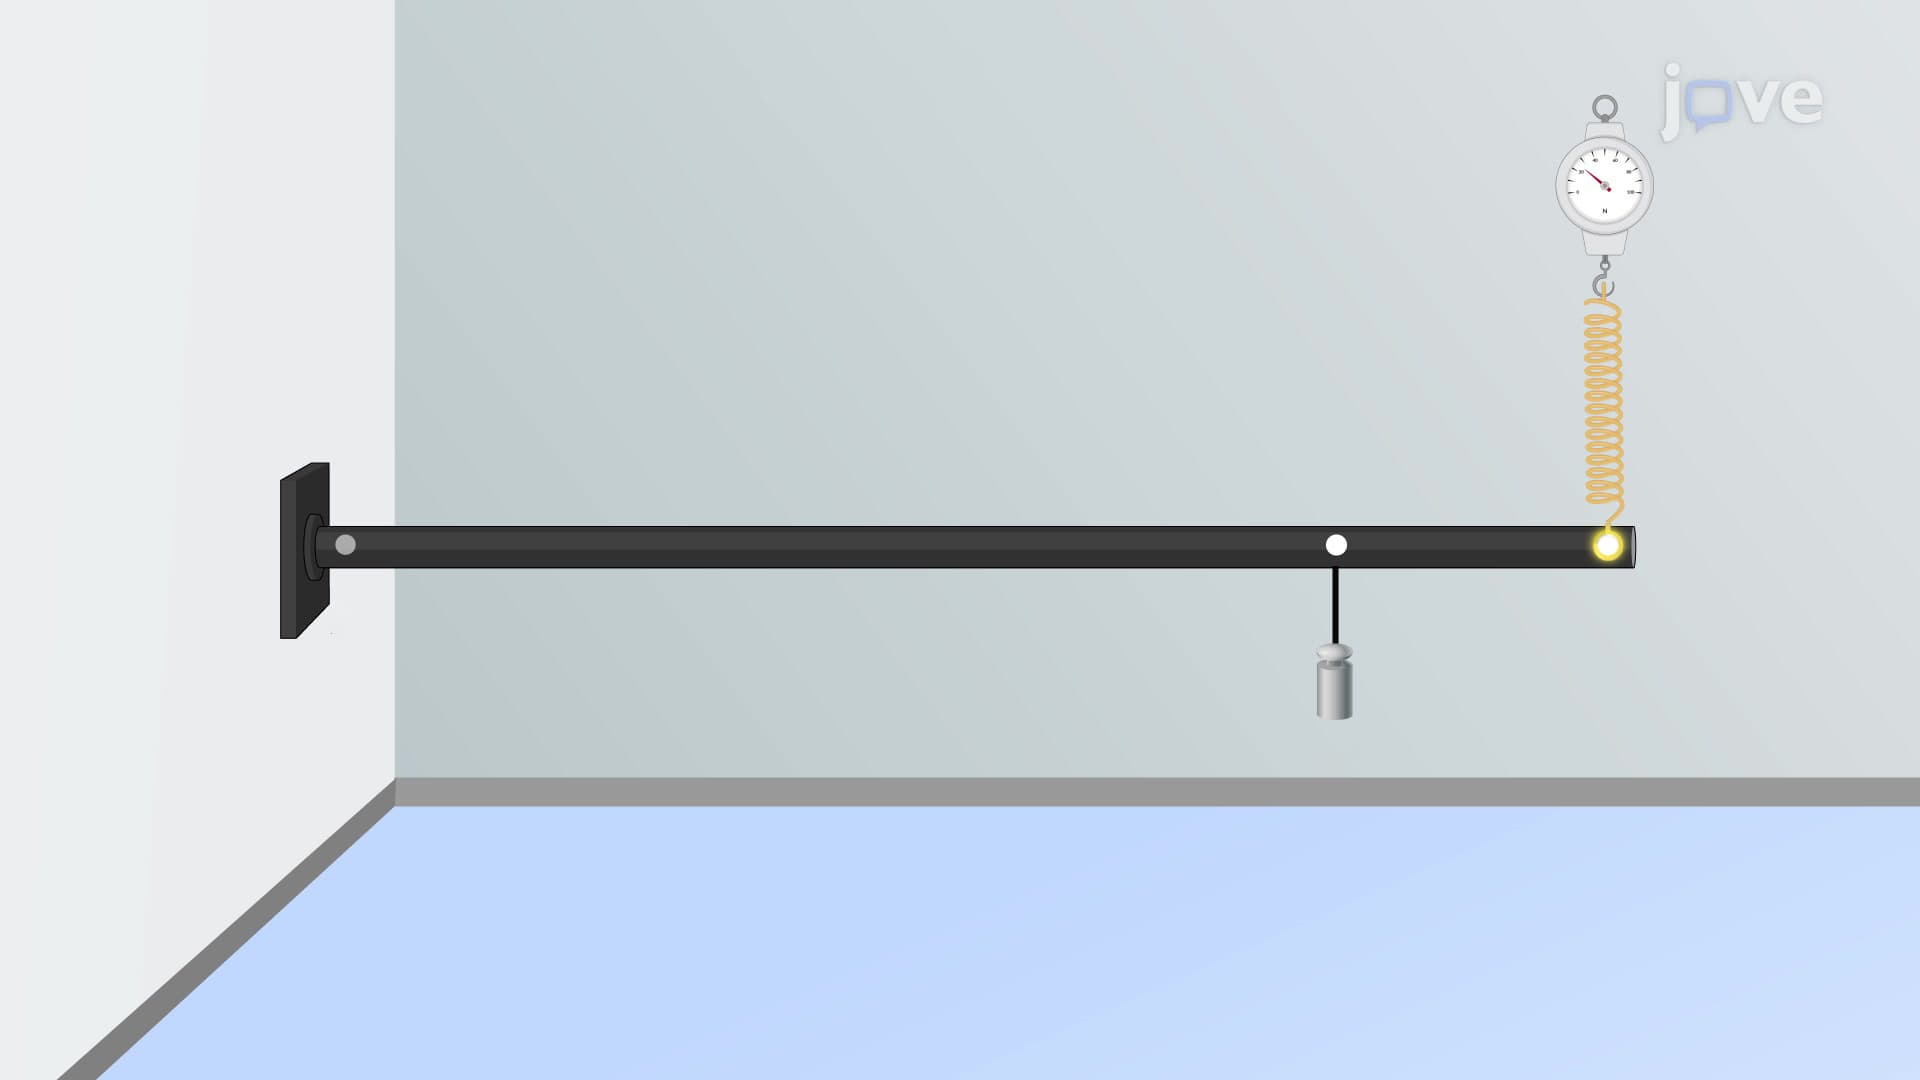
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Normal and Tangetial Components: Problem Solving