Related Experiment Video
Updated: Aug 18, 2026
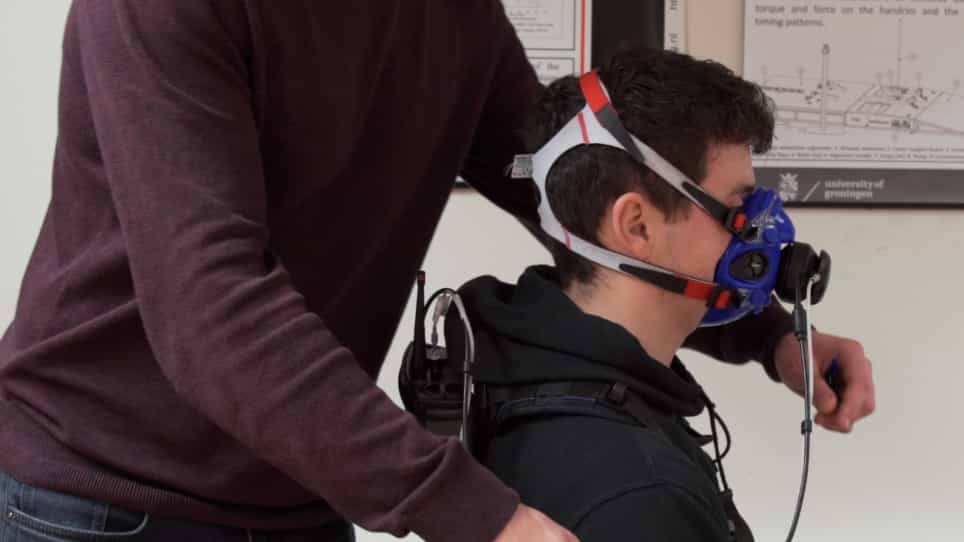
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Next generation autonomous wheelchair control
1Electrical and Computer Engineering Department, University of Wyoming, 1000 E. University Avenue, Laramie, WY 82071, USA. prince@uwyo.edu

Abstract:
Often times the physically challenged, limited to a wheelchair, also have difficulty with vision. In order to help, something must "see" for them. Therefore there must be some way for a wheelchair to know its environment, sense where it is, and where it must go. It also must be able to avoid any obstacles which are not normally part of the environment. An autonomous wheelchair will serve an important role by allowing users more freedom and independence. This design challenge is broken into four major steps: wheelchair control, environment recognition, route planning, and obstacle avoidance. The first step is to reverse engineer a wheelchair and rebuild the controls, which will be the main topic of discussion for this paper. Two big challenges with this step are high power motor control and joystick control. An H-bridge motor interface, controlled by a microprocessor, was designed for the motors. The joystick control is handled with the same microprocessor.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Rolling Resistance: Problem Solving
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 00:46
Motor Units
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...