Visuospatial memory computations during whole-body rotations in roll
Related Experiment Video
Updated: Aug 18, 2026
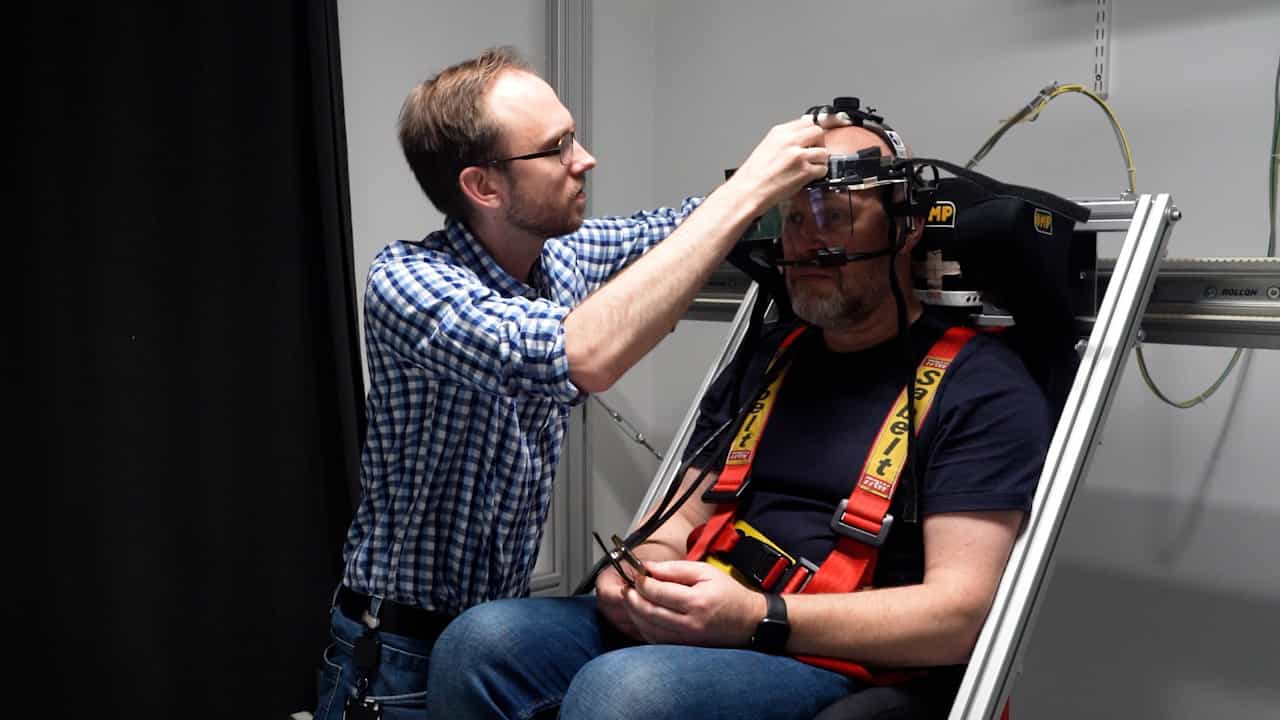
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
S Van Pelt1, J A M Van Gisbergen, W P Medendorp
1Nijmegen Institute for Cognition and Information, Radboud University Nijmegen, The Netherlands. s.vanpelt@nici.ru.nl

Abstract:
We used a memory-saccade task to test whether the location of a target, briefly presented before a whole-body rotation in roll, is stored in egocentric or in allocentric coordinates. To make this distinction, we exploited the fact that subjects, when tilted sideways in darkness, make systematic errors when indicating the direction of gravity (an allocentric task) even though they have a veridical percept of their self-orientation in space. We hypothesized that if spatial memory is coded allocentrically, these distortions affect the coding of remembered targets and their readout after a body rotation. Alternatively, if coding is egocentric, updating for body rotation becomes essential and errors in performance should be related to the amount of intervening rotation. Subjects (n = 6) were tested making saccades to remembered world-fixed targets after passive body tilts. Initial and final tilt angle ranged between -120 degrees CCW and 120 degrees CW. The results showed that subjects made large systematic directional errors in their saccades (up to 90 degrees ). These errors did not occur in the absence of intervening body rotation, ruling out a memory degradation effect. Regression analysis showed that the errors were closely related to the amount of subjective allocentric distortion at both the initial and final tilt angle, rather than to the amount of intervening rotation. We conclude that the brain uses an allocentric reference frame, possibly gravity-based, to code visuospatial memories during whole-body tilts. This supports the notion that the brain can define information in multiple frames of reference, depending on sensory inputs and task demands.
Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:16
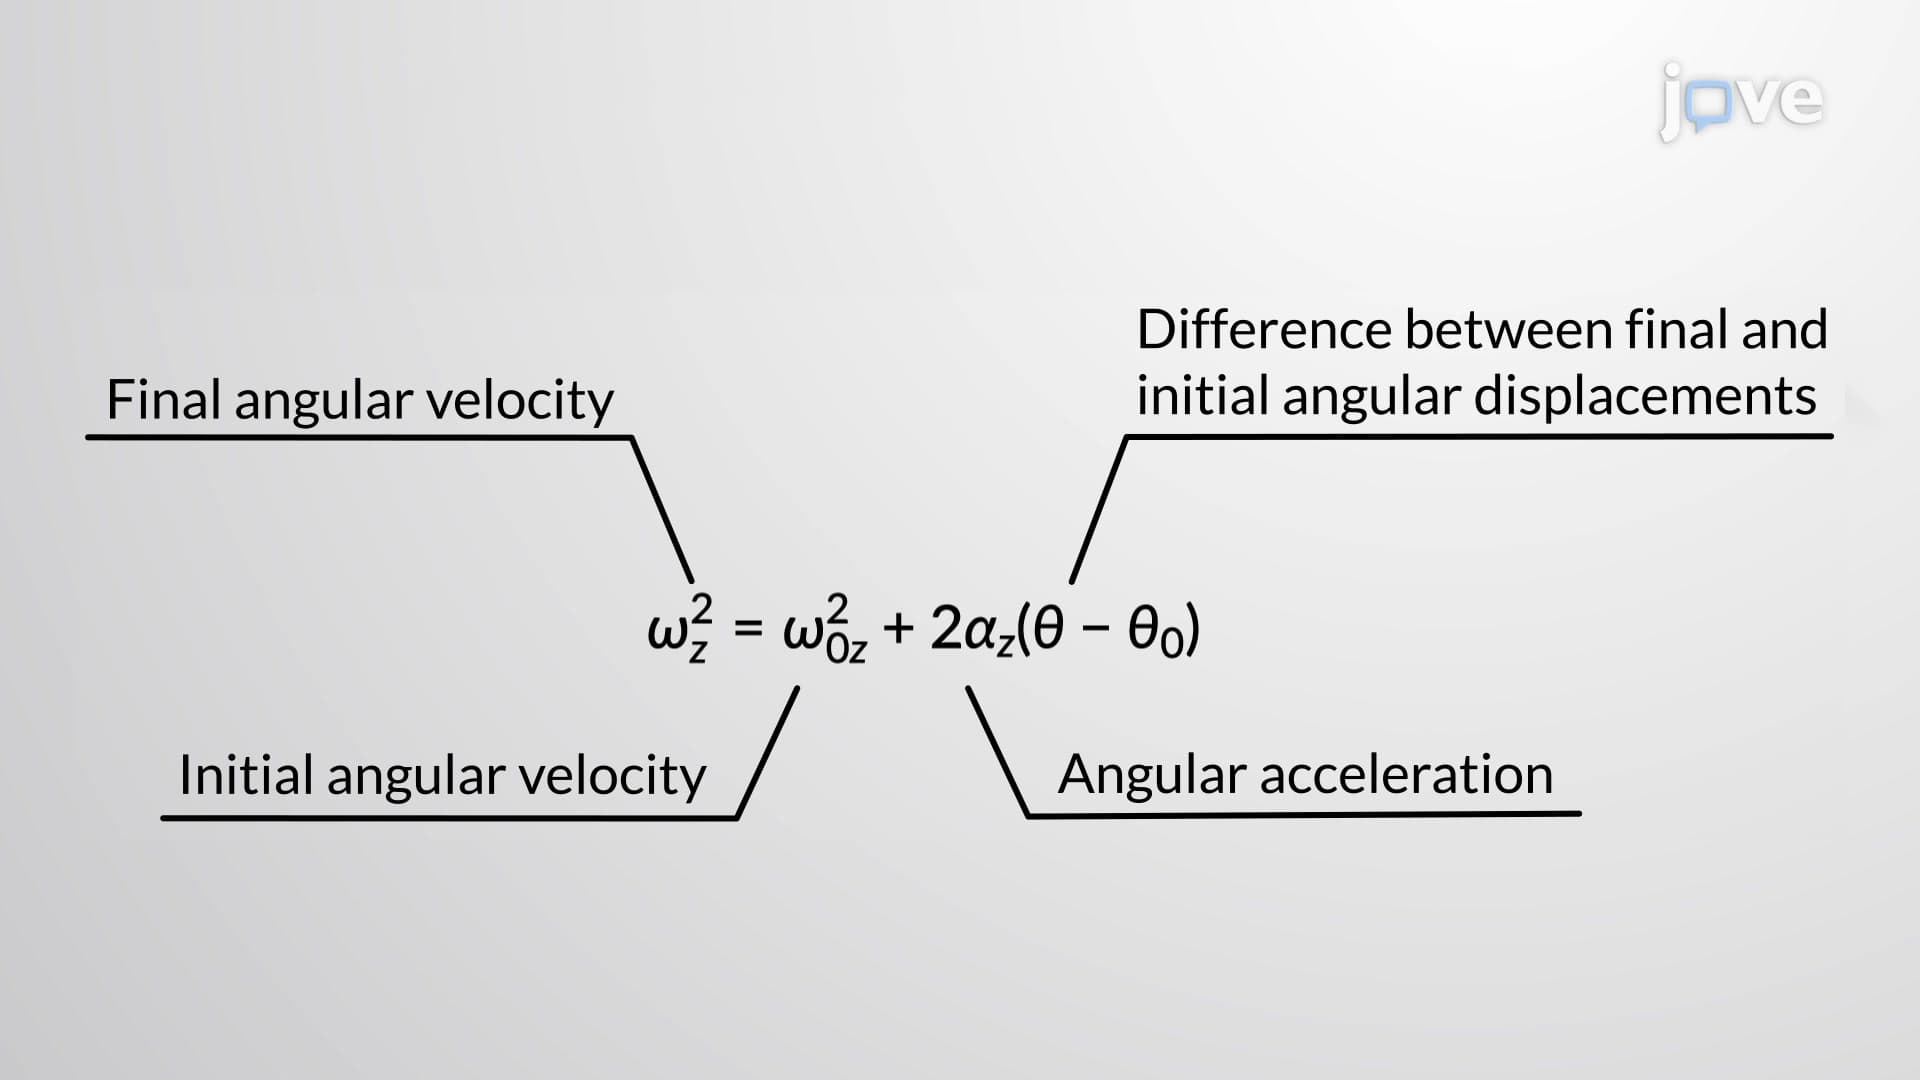
Rotation with Constant Angular Acceleration - II
The first...