Related Experiment Video
Updated: Aug 18, 2026
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Relationships between hoof-acceleration patterns of galloping horses and dynamic properties of the track
Marc H Ratzlaff1, Patrick D Wilson, David V Hutton
1Department of Veterinary and Comparative Anatomy, Pharmacology, and Physiology, College of Veterinary Medicine, Washington State University, Pullman, WA 99164, USA.

Objective:
To define relationships between hoof-acceleration patterns of galloping horses and dynamic properties of the track.
Animals:
8 Thoroughbred horses without lameness.
Procedure:
Acceleration-time curves were recorded by use of accelerometers attached to each hoof as each horse galloped over the track straightaway. Four sessions were conducted for each horse, with the track surface modified by sequentially adding water before each session. These acceleration-time curves were analyzed to determine peak accelerations during the support phase of the stride. Track dynamic properties (hardness, rebound, deceleration rate, rebound rate, and penetration) were recorded with a track-testing device. Moisture content and dry density were measured from soil samples. Stepwise multiple regression was used to identify relationships between hoof-acceleration variables and track dynamic properties.
Results:
Track rebound rate was most consistently related to hoof variables, especially through an inverse relationship with negative acceleration peaks for all hooves. Also, rebound rate was related to initial acceleration peak during propulsion of the hooves of the forelimb and the nonlead hind limb as well as to the second acceleration peak during propulsion of the lead hooves of the hind limb and nonlead forelimb.
Conclusions And Clinical Relevance:
The inverse relationship between track rebound rate and negative acceleration peaks for all hooves reflects the most important dynamic property of a track. Any factor that reduces negative acceleration of the hooves will increase stride efficiency by allowing smoother transition from retardation to propulsion and therefore may be important in determining the safety of racing surfaces.
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:27
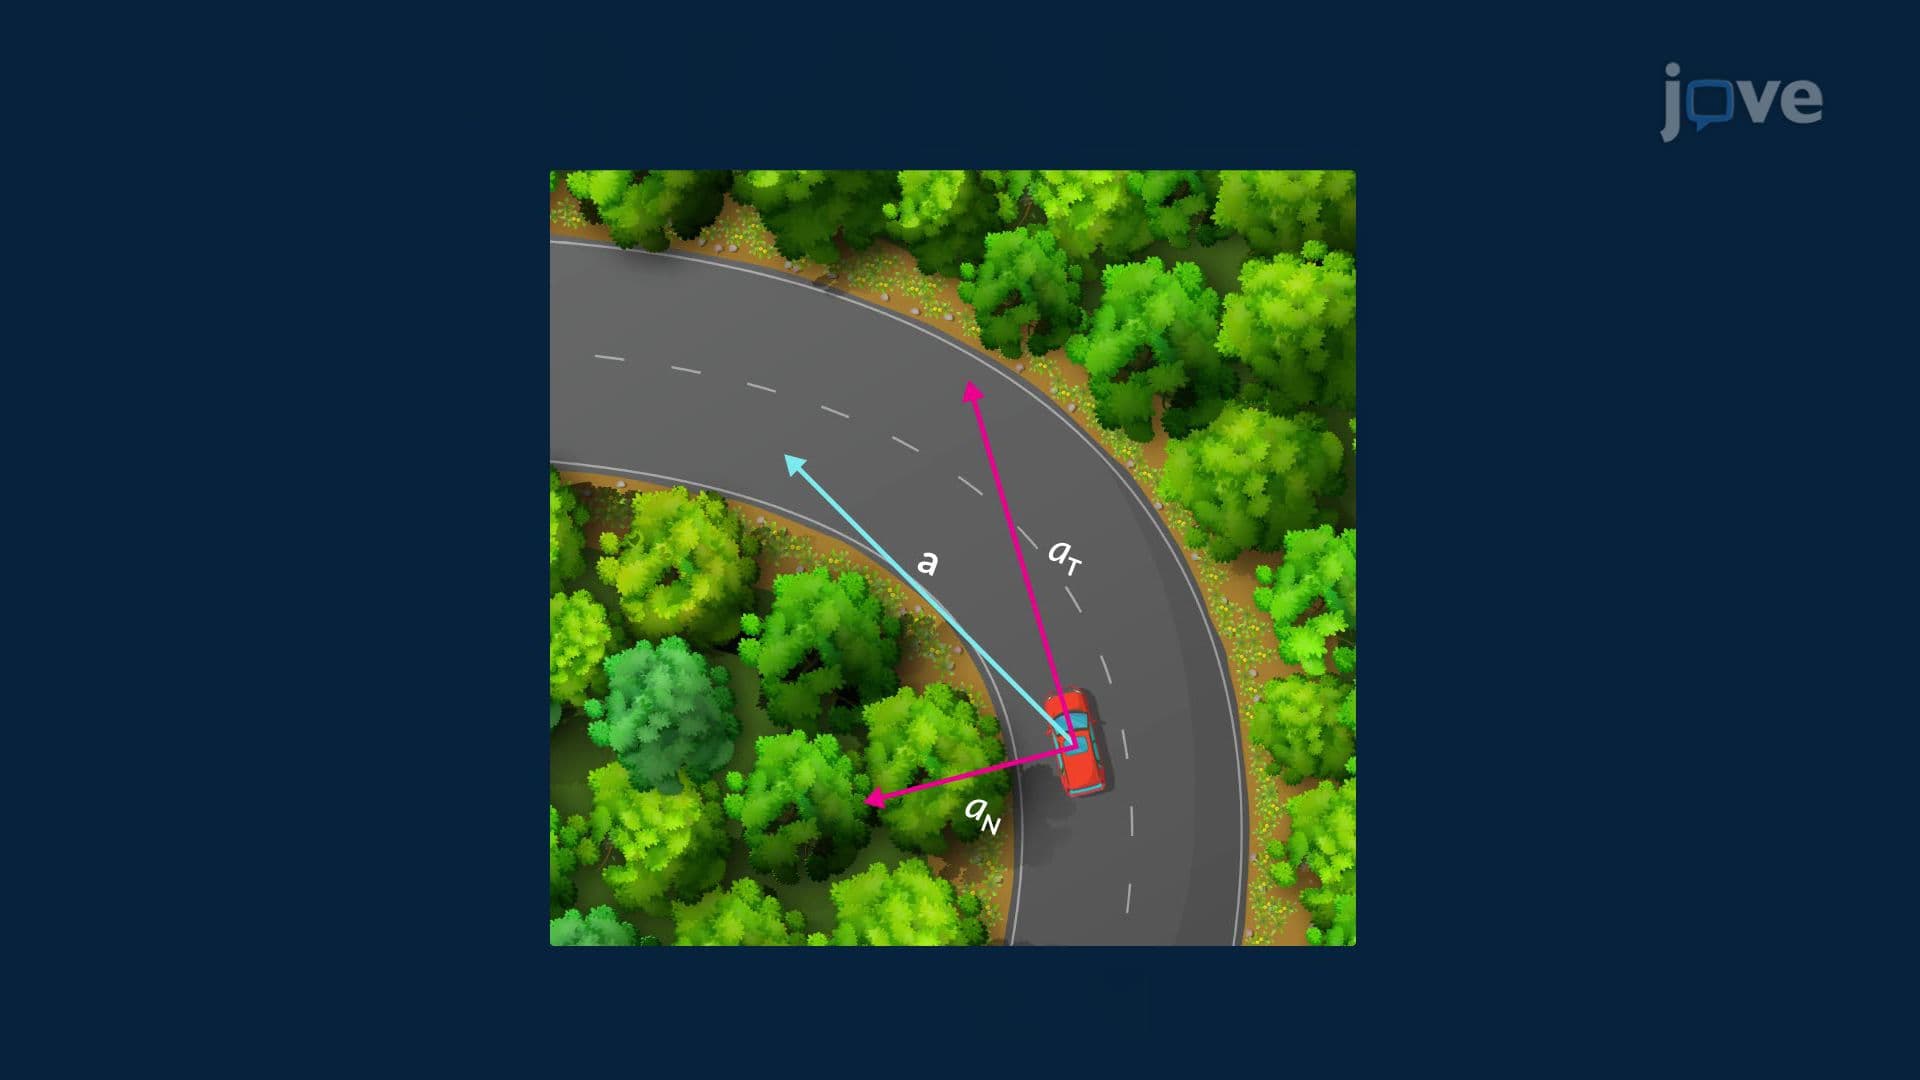
Tangential and Normal Components of Acceleration
 01:31
Motion in Space: Velocity and Acceleration
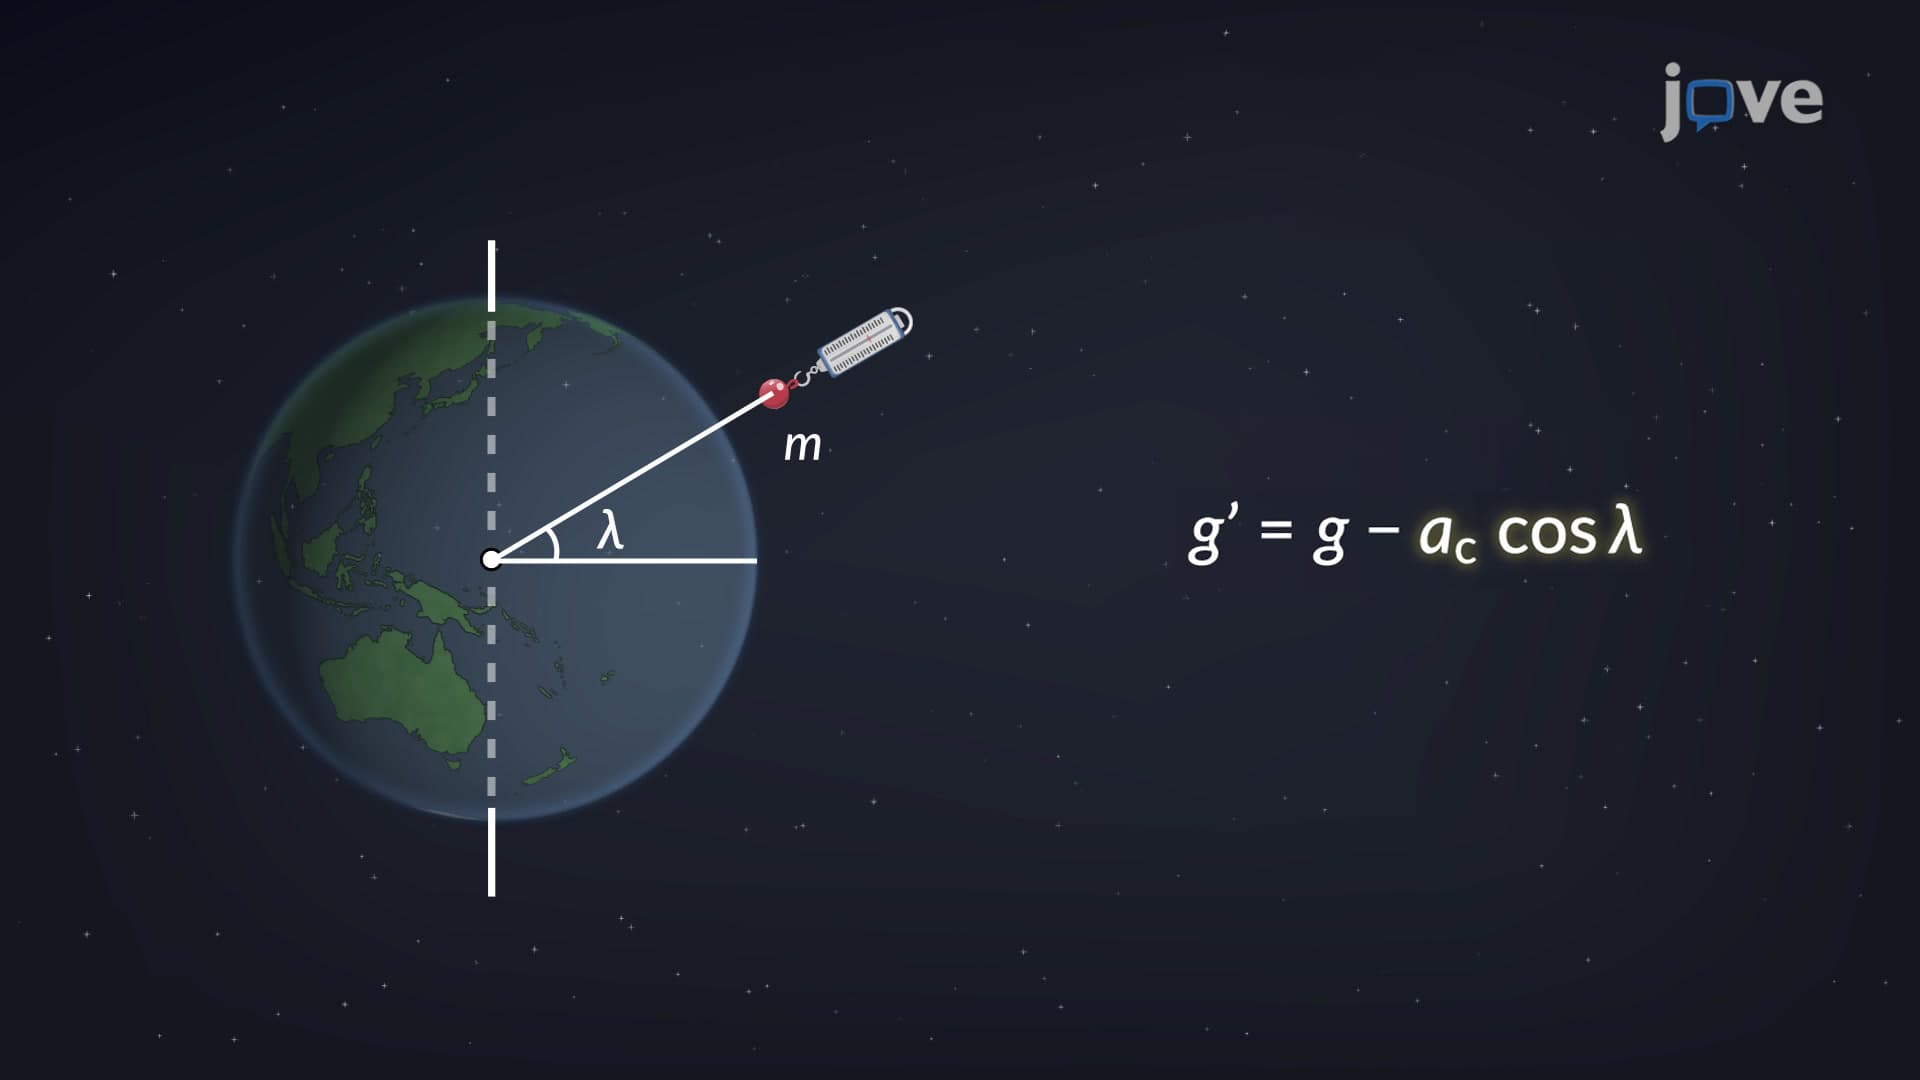 01:20
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:17
Dynamics Of Circular Motion: Applications