Related Experiment Video
Updated: Aug 17, 2026

Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Mechanical energy and effective foot mass during impact loading of walking and running
1Department of Biology, Duke University, Durham, NC 27708-0338, USA. kc12@duke.edu

Abstract:
The human heel pad is considered an important structure for attenuation of the transient force caused by heel-strike. Although the mechanical properties of heel pads are relatively well understood, the mechanical energy (Etot) absorbed by the heel pad during the impact phase has never been documented directly because data on the effective foot mass (Meff) was previously unavailable during normal forward locomotion. In this study, we use the impulse-momentum method (IMM) for calculating Meff from moving subjects. Mass-spring-damper models were developed to evaluate errors and to examine the effects of pad property, upper body mass, and effective leg spring on Meff. We simultaneously collected ground reaction forces, pad deformation, and lower limb kinematics during impact phase of barefoot walking, running, and crouched walking. The latter was included to examine the effect of knee angle on Meff. The magnitude of Meff as a percentage of body mass (M(B)) varies with knee angle at impact and significantly differs among gaits: 6.3%M(B) in walking, 5.3%M(B) in running, and 3.7%M(B) in crouched walking. Our modeling results suggested that Meff is insensitive to heel pad resilience and effective leg stiffness. At the instant prior to heel strike, Etot ranges from 0.24 to 3.99 J. The combination of video and forceplate data used in this study allows analyses of Etot and Etot as a function of heel-strike kinematics during normal locomotion. Relationship between Meff and knee angle provides insights into how changes in posture moderate impact transients at different gaits.

Related Concept Videos
 01:19
Impact Loading
In cases of elastic deformation,...
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:23
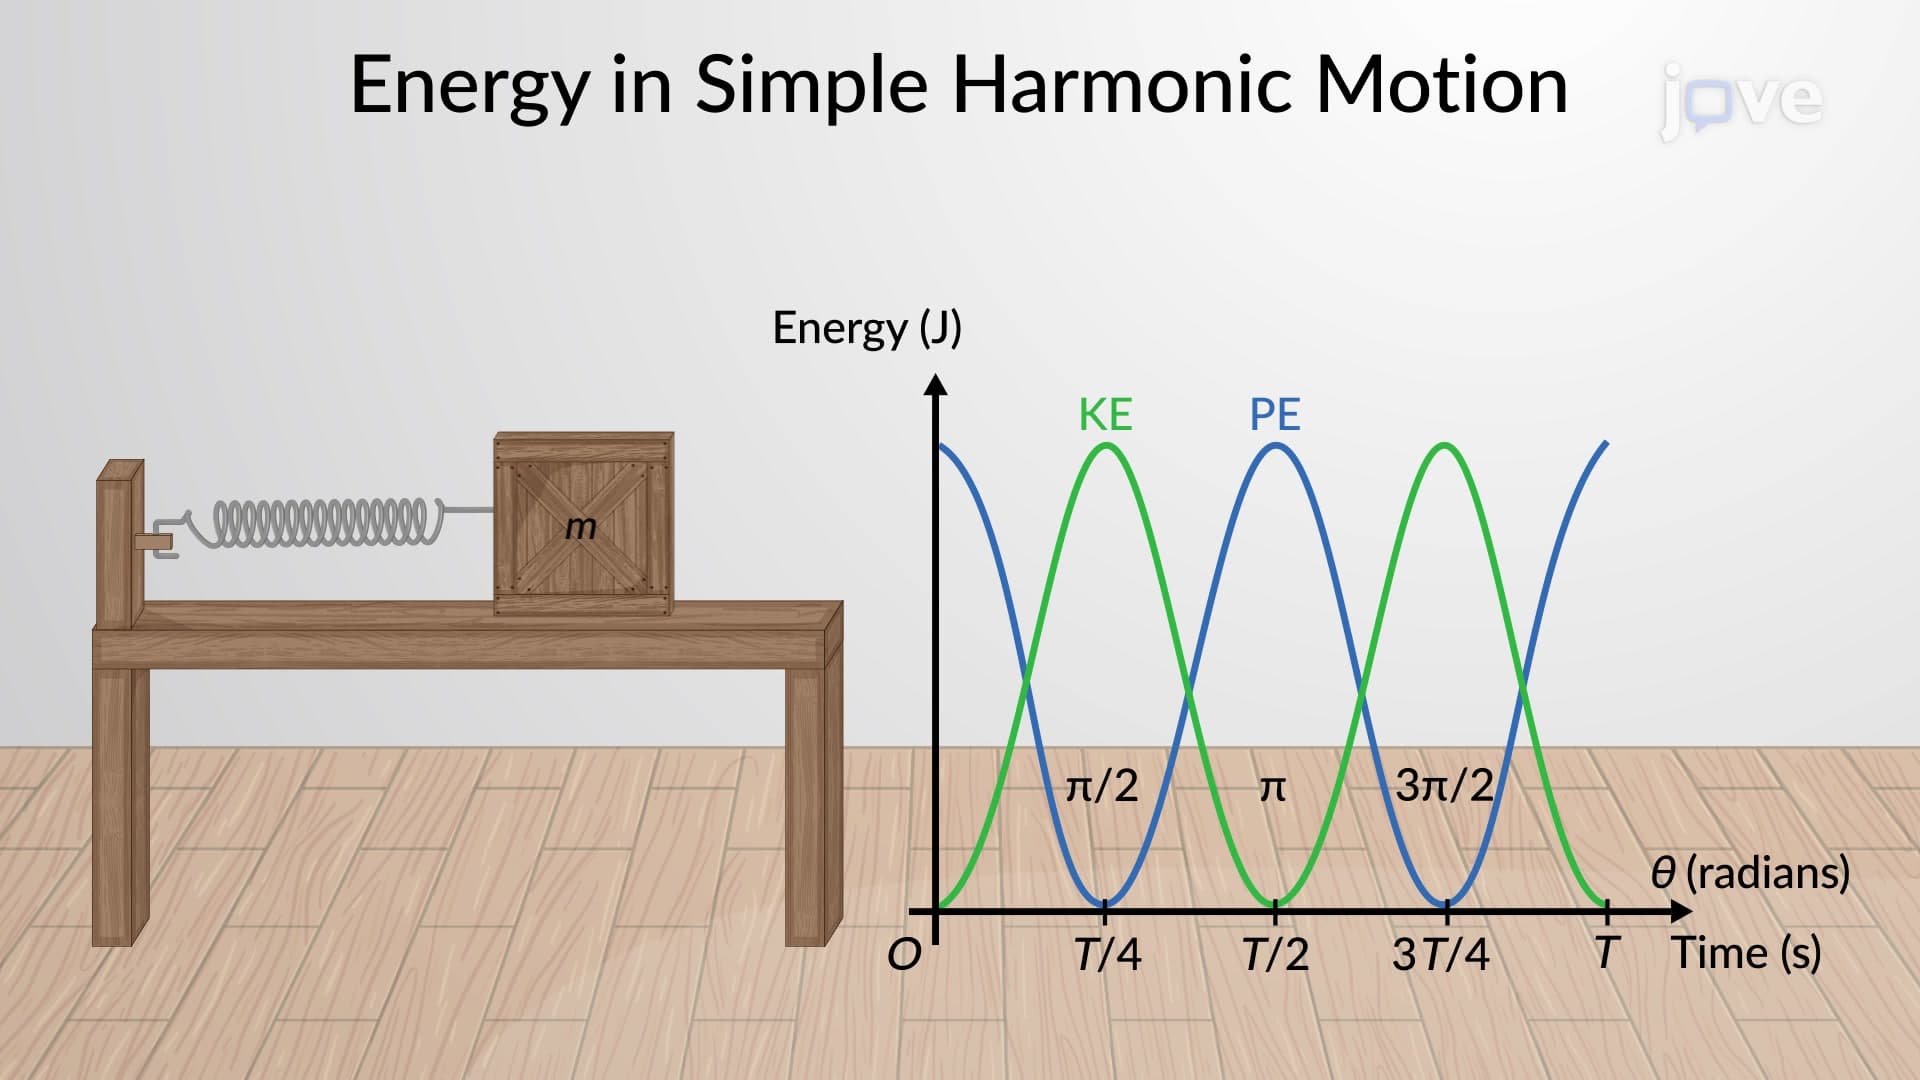
Energy in Simple Harmonic Motion