Related Experiment Video
Updated: Jul 2, 2026


A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Computer-navigated pedicle screw insertion in the lumbar spine
Richard Bostelmann1, Arnaldo Benini
1Wirbelsäulen- und Rückenmarkschirurgie, Schulthess-Klinik, Zürich, Schweiz. dr.bori@gmx.net

Objective:
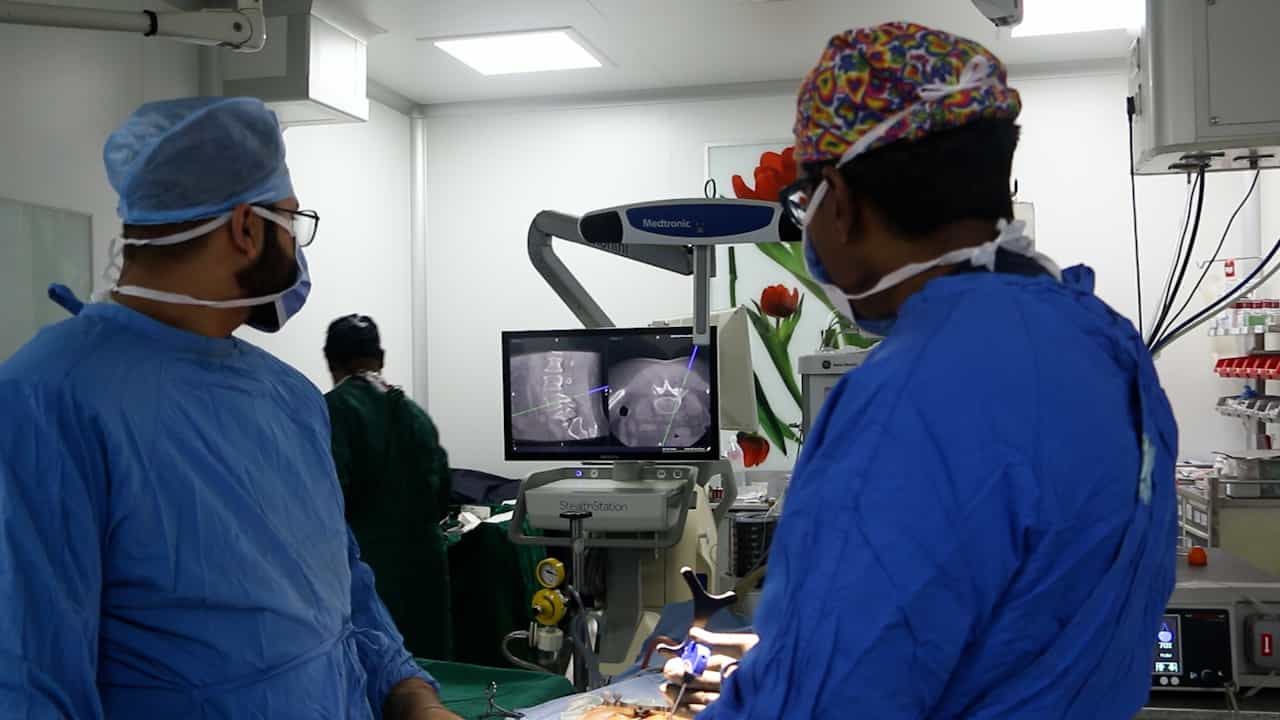
Decrease of surgical risks in transpedicular, lumbar spondylodesis by insertion of screws into the pedicle under continuous visual control of the screw channel in the sagittal, axial, and orthogonal planes in relation to the direction of screw insertion.
Indications:
All indications of a transpedicular lumbar spondylodesis performed for intervertebral instability, spinal stenosis, or displacement of vertebrae secondary to degenerative diseases.
Contraindications:
Previous surgery that does not permit the obligatory intraoperative matching. Usual contraindications for lumbar spondylodesis. Spondylolyses, as they rarely allow a satisfactory result of matching due to the mobility in the vertebral segment.
Surgical Technique:
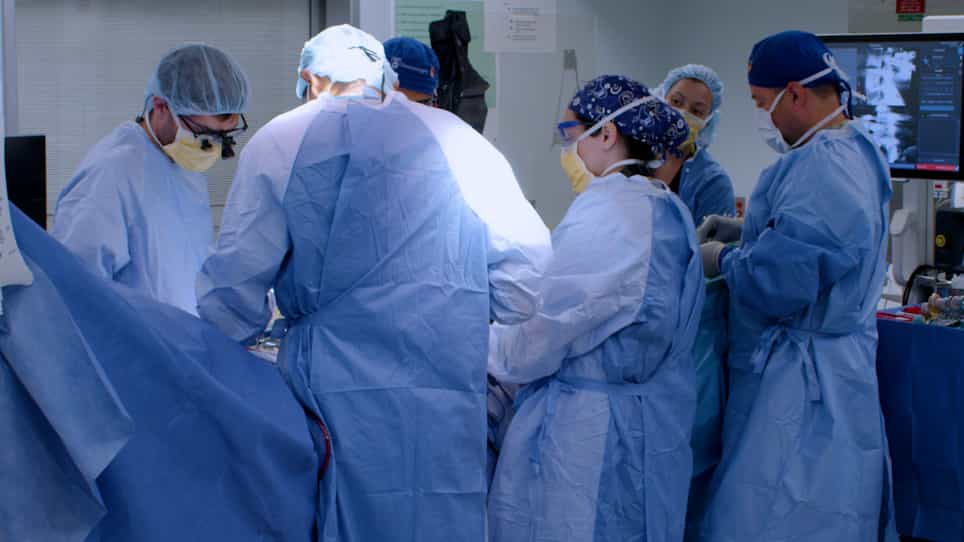
Preoperative multi-slice computed tomography (CT). Intraoperative matching of real and virtual views. On the monitor the instruments are controlled visually in their relation to the lumbar spine in almost real time. Opening of pedicles and insertion of screws. Only thereafter, treatment of the pathologic conditions either by decompression or realignment of the spine.
Results:
Between July 2000 and February 2002 this system was selected for 109 patients. No complications were observed and no revision became necessary. The screw length varied between 35 and 50 mm; the length of the screws does not affect the procedure. Intra- and postoperative radiographs (anteroposterior and lateral) were done in every patient. The first 48 patients underwent CT control that confirmed the optimal intrapedicular and intravertebral screw position. Thereafter, these controls were omitted for cost-saving.