Related Experiment Video
Updated: Aug 16, 2026
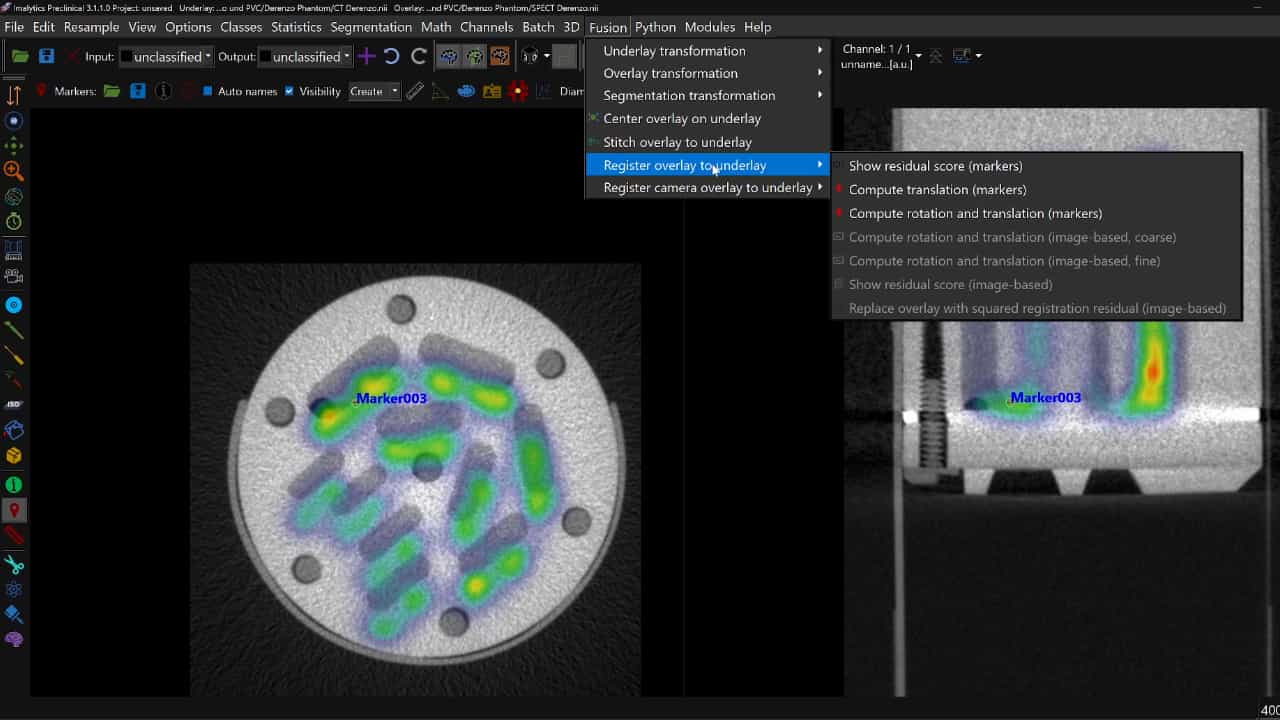

Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
Determining rigid body transformation parameters from ill-conditioned spatial marker co-ordinates
1School of Physiotherapy, University of Otago, Dunedin, New Zealand. allan.carman@otago.ac.nz

Abstract:
The three-dimensional location of a body-fixed axis system is described by position and orientation parameters that can be calculated knowing local and global coordinates of three or more body-fixed markers. However, marker distribution can become ill-conditioned when marker placement is symmetrical with respect to the mean of the markers. As symmetry and ill-conditioning increases, random errors in marker locations can affect the stability of orientation parameters as a result of the mathematical approach adopted. The present study investigates the methods of Veldpaus et al. [1988; Journal of Biomechanics 21, 45], Challis [1995; Biomechanics 28, 733] and Andriacchi et al. [1998; Journal of Biomedical Engineering 120, 743] for obtaining segment orientation parameters when segment markers ranged from well-defined to highly ill-conditioned depending on the symmetry of segment markers. A novel fourth approach is also presented that enabled comparisons of the root mean square error of reconstructed marker coordinates to verify that an optimal solution was obtained. No single method produced optimal results for all axis orientation parameters when reconstructing movement trials. The best performed was the method of Veldpaus et al. [1988; Journal of Biomechanics 21, 45] based on consistent results and ease of implementation. The fourth approach presented provided a reliable method in all but the highly ill-conditioned markers, however implementation was computationally difficult. The method of Challis [1995; Biomechanics 28, 733] was only suited to well-conditioned marker sets which avoided markers lying in a single plane with symmetries in marker distribution relative to the mean. The method of Andriacchi et al. [1998; Journal of Biomedical Engineering 120, 743] produced, at best, orientation parameters that approximated the results obtained by least squares methods.
More Related Videos

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...