Global shape coding for motion-defined radial-frequency contours
Related Experiment Video
Updated: Aug 16, 2026

Motion-Acuity Test for Visual Field Acuity Measurement with Motion-Defined Shapes
Published on: February 23, 2024
Stéphane J M Rainville1, Hugh R Wilson
1Center for Visual Neuroscience, Department of Psychology, North Dakota State University, Fargo, ND 58105-5075, USA. rainvill@yorku.ca

Abstract:
The visual system is highly skilled at recovering the shape of complex objects defined exclusively by motion cues. But while low-level and high-level mechanisms involved in shape-from-motion have been studied extensively, intermediate computational stages remain poorly understood. In the present study, we used motion-defined radial-frequency contours--or motion RFs--to probe intermediate stages involved in the computation of motion-defined shape. Motion RFs consisted of a virtual circle of Gabor elements whose carriers drifted at speeds determined by a sinusoidal function of polar angle. Motion RFs elicited vivid percepts of shape, and observers could detect and discriminate radial frequencies up to approximately five cycles. Randomizing Gabor speeds over a small contour segment impaired detection and discrimination performance significantly more than predicted by probability summation. Threshold comparisons between spatial-RF and motion-RF contours ruled out that motion-induced shifts in perceived position (i.e., the DeValois effect) determine shape perception in motion RFs. Together, results indicate that the shape of motion RFs is processed by synergistic mechanisms that perform a global analysis of motion cues over space. These results are integrated with data on perceptual interactions between motion RFs and spatial-RFs and are discussed in terms of cue-specific and cue-invariant representations of object shape in human vision.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:27
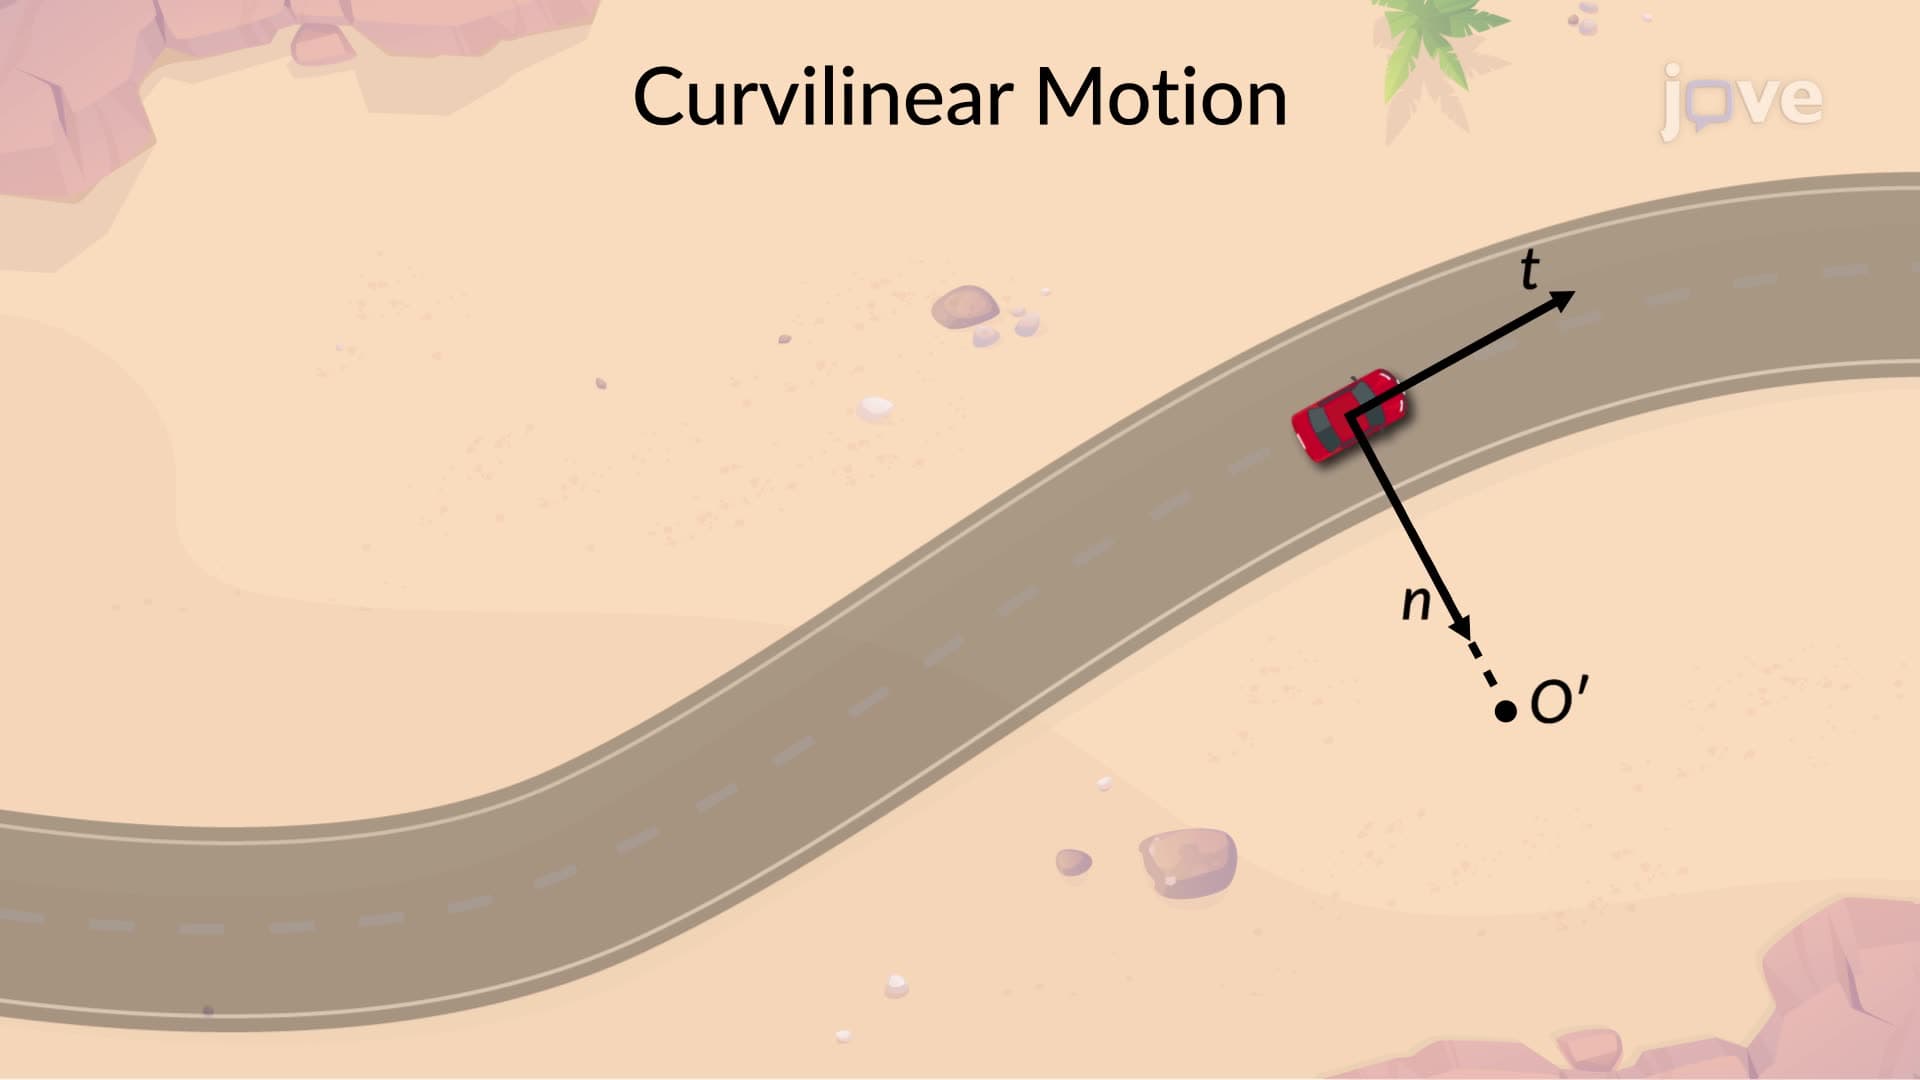
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:12
Radius of Gyration of an Area
 01:22
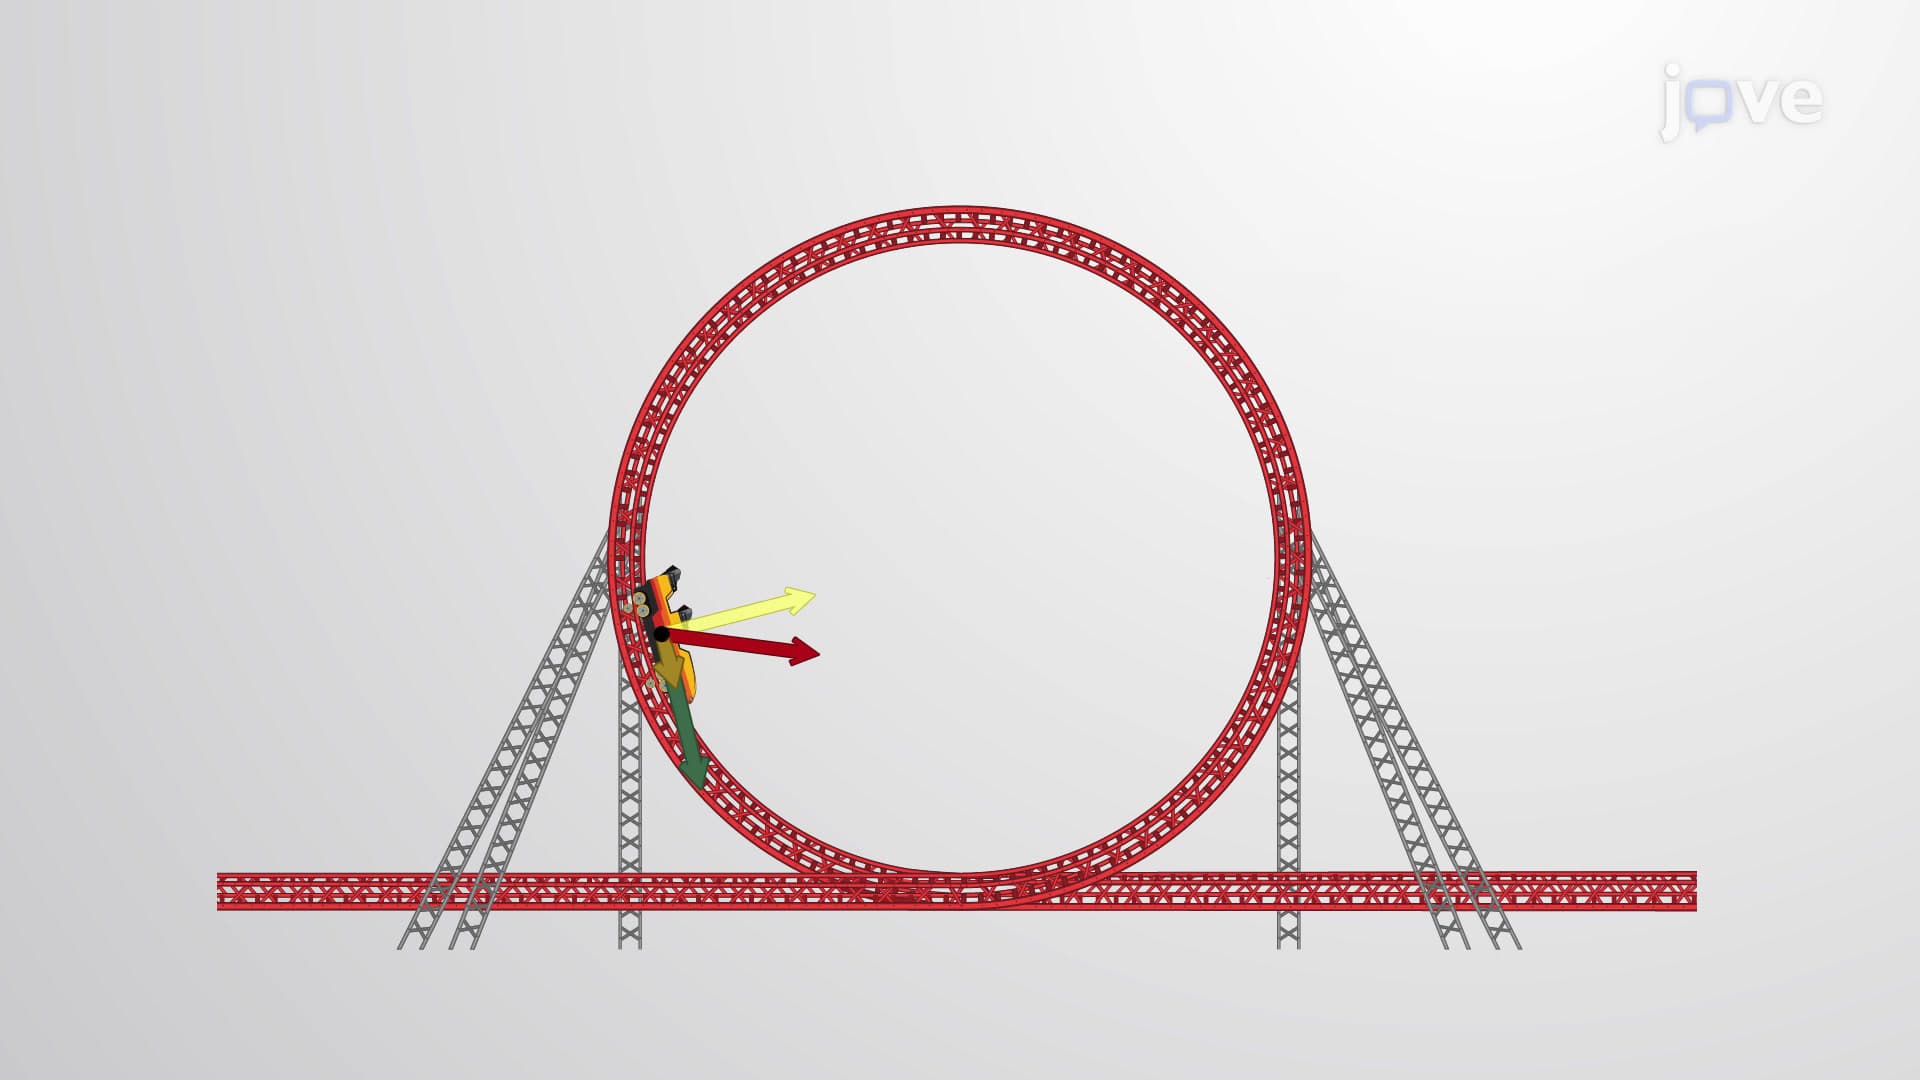
Non-uniform Circular Motion
For example, such accelerations...