Internal models in sensorimotor integration: perspectives from adaptive control theory
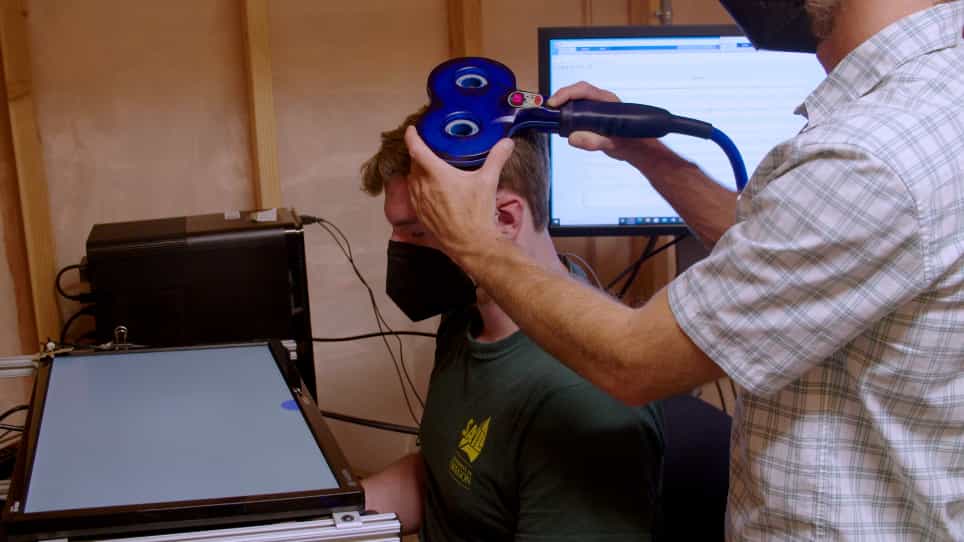
Related Experiment Video
Updated: Jul 30, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
1Department of Mechanical Engineering, Massachusetts Institute of Technology, Cambridge, MA 02139, USA.

Abstract:
Internal models and adaptive controls are empirical and mathematical paradigms that have evolved separately to describe learning control processes in brain systems and engineering systems, respectively. This paper presents a comprehensive appraisal of the correlation between these paradigms with a view to forging a unified theoretical framework that may benefit both disciplines. It is suggested that the classic equilibrium-point theory of impedance control of arm movement is analogous to continuous gain-scheduling or high-gain adaptive control within or across movement trials, respectively, and that the recently proposed inverse internal model is akin to adaptive sliding control originally for robotic manipulator applications. Modular internal models' architecture for multiple motor tasks is a form of multi-model adaptive control. Stochastic methods, such as generalized predictive control, reinforcement learning, Bayesian learning and Hebbian feedback covariance learning, are reviewed and their possible relevance to motor control is discussed. Possible applicability of a Luenberger observer and an extended Kalman filter to state estimation problems-such as sensorimotor prediction or the resolution of vestibular sensory ambiguity-is also discussed. The important role played by vestibular system identification in postural control suggests an indirect adaptive control scheme whereby system states or parameters are explicitly estimated prior to the implementation of control. This interdisciplinary framework should facilitate the experimental elucidation of the mechanisms of internal models in sensorimotor systems and the reverse engineering of such neural mechanisms into novel brain-inspired adaptive control paradigms in future.

Related Concept Videos
 01:28
Major Somatic Sensory Pathways
 01:18
Hierarchy of Motor Control
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Modeling in Therapy
Participant Modeling
Participant modeling involves therapists demonstrating calm and effective behaviors in situations...
 01:25
Self-Regulation