
Annihilation of limit-cycle oscillations by identification of critical perturbing stimuli via mixed-integer optimal

D Lebiedz1, S Sager, H G Bock

  • 1Interdisciplinary Center for Scientific Computing, Heidelberg, Germany. iebiedz@iwr.uni-heidelberg.de

Physical Review Letters
|October 4, 2005
PubMed

Related Concept Videos

Root-Locus Method01:19

Root-Locus Method

A cruise control system in a car is designed to maintain a specified speed automatically by adjusting the gas pedal. The system continuously measures the vehicle's speed and makes fine adjustments to the pedal to achieve this goal. The root locus method is particularly useful for understanding how the cruise control system's behavior changes under varying conditions, such as when the car goes uphill, downhill, or faces strong wind resistance.
This system can be represented by a block diagram,...
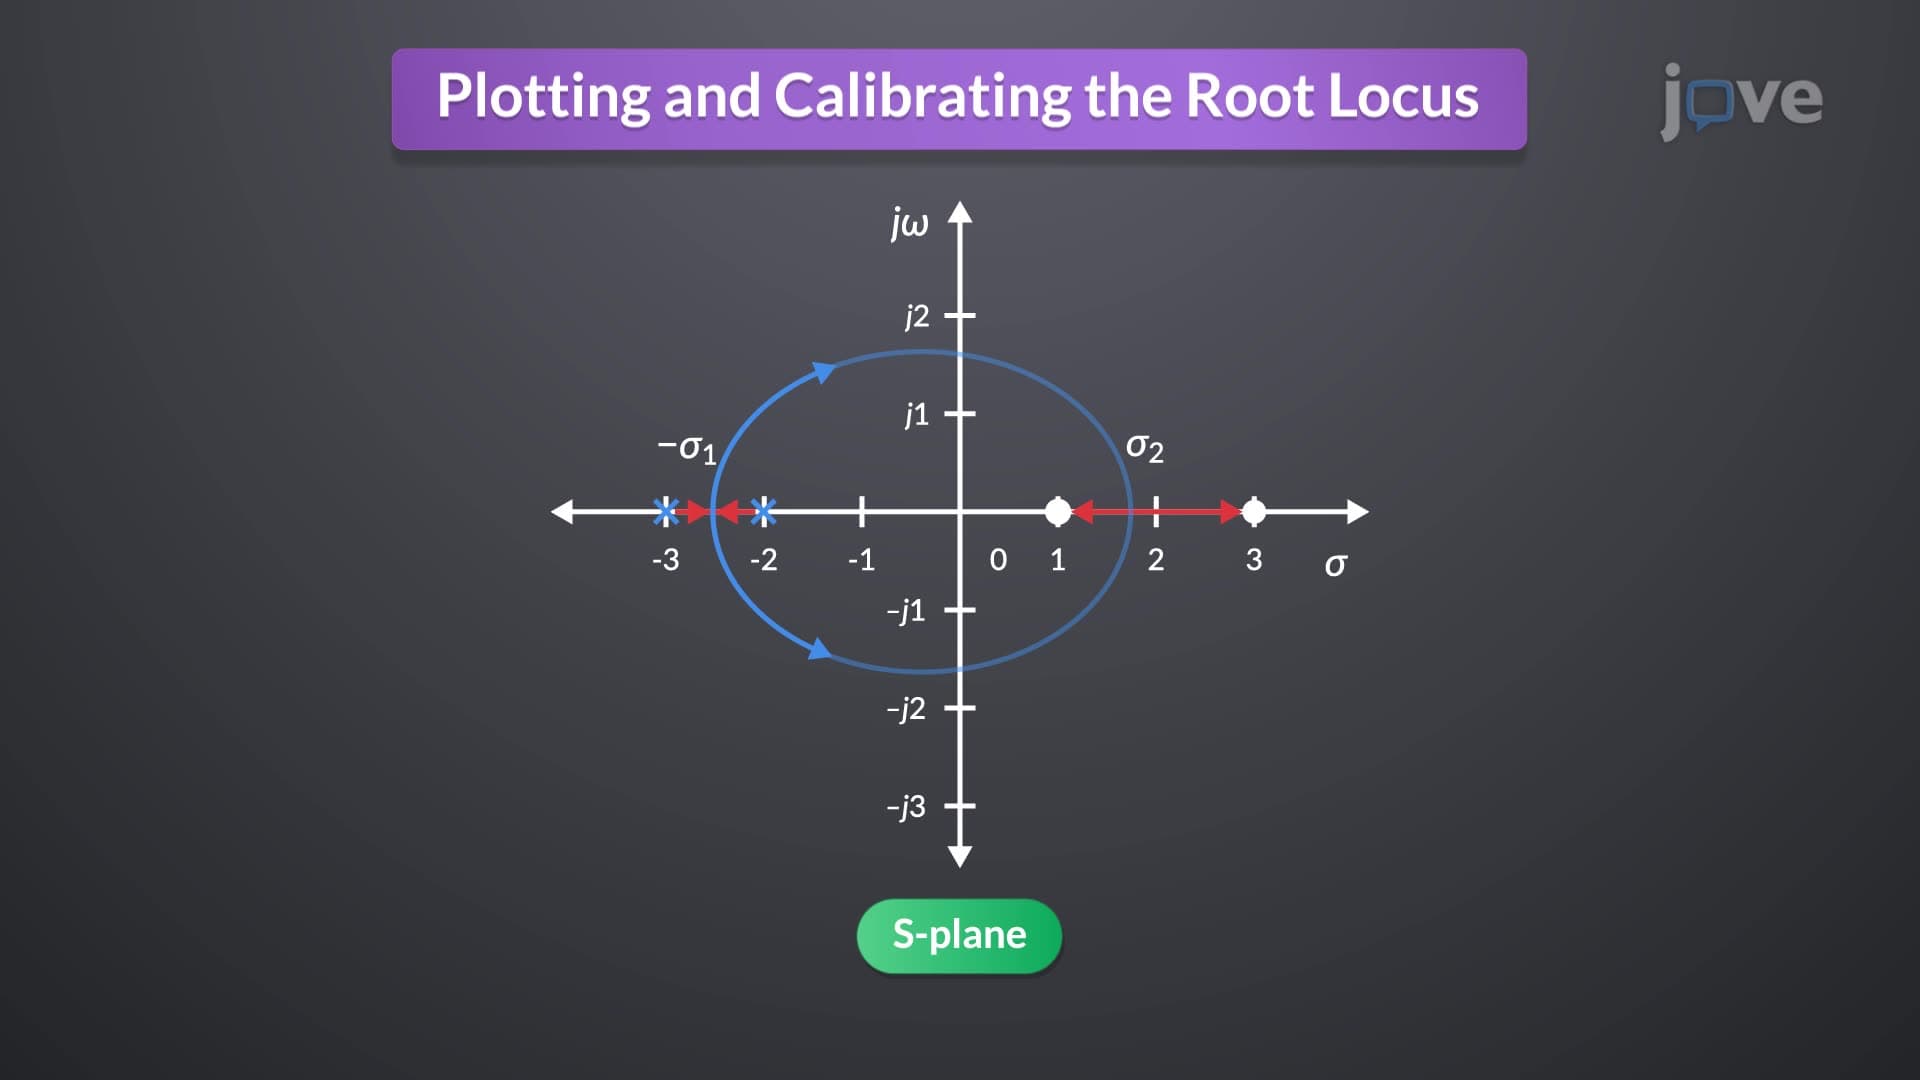
Plotting and Calibrating the Root Locus01:19

Plotting and Calibrating the Root Locus

Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
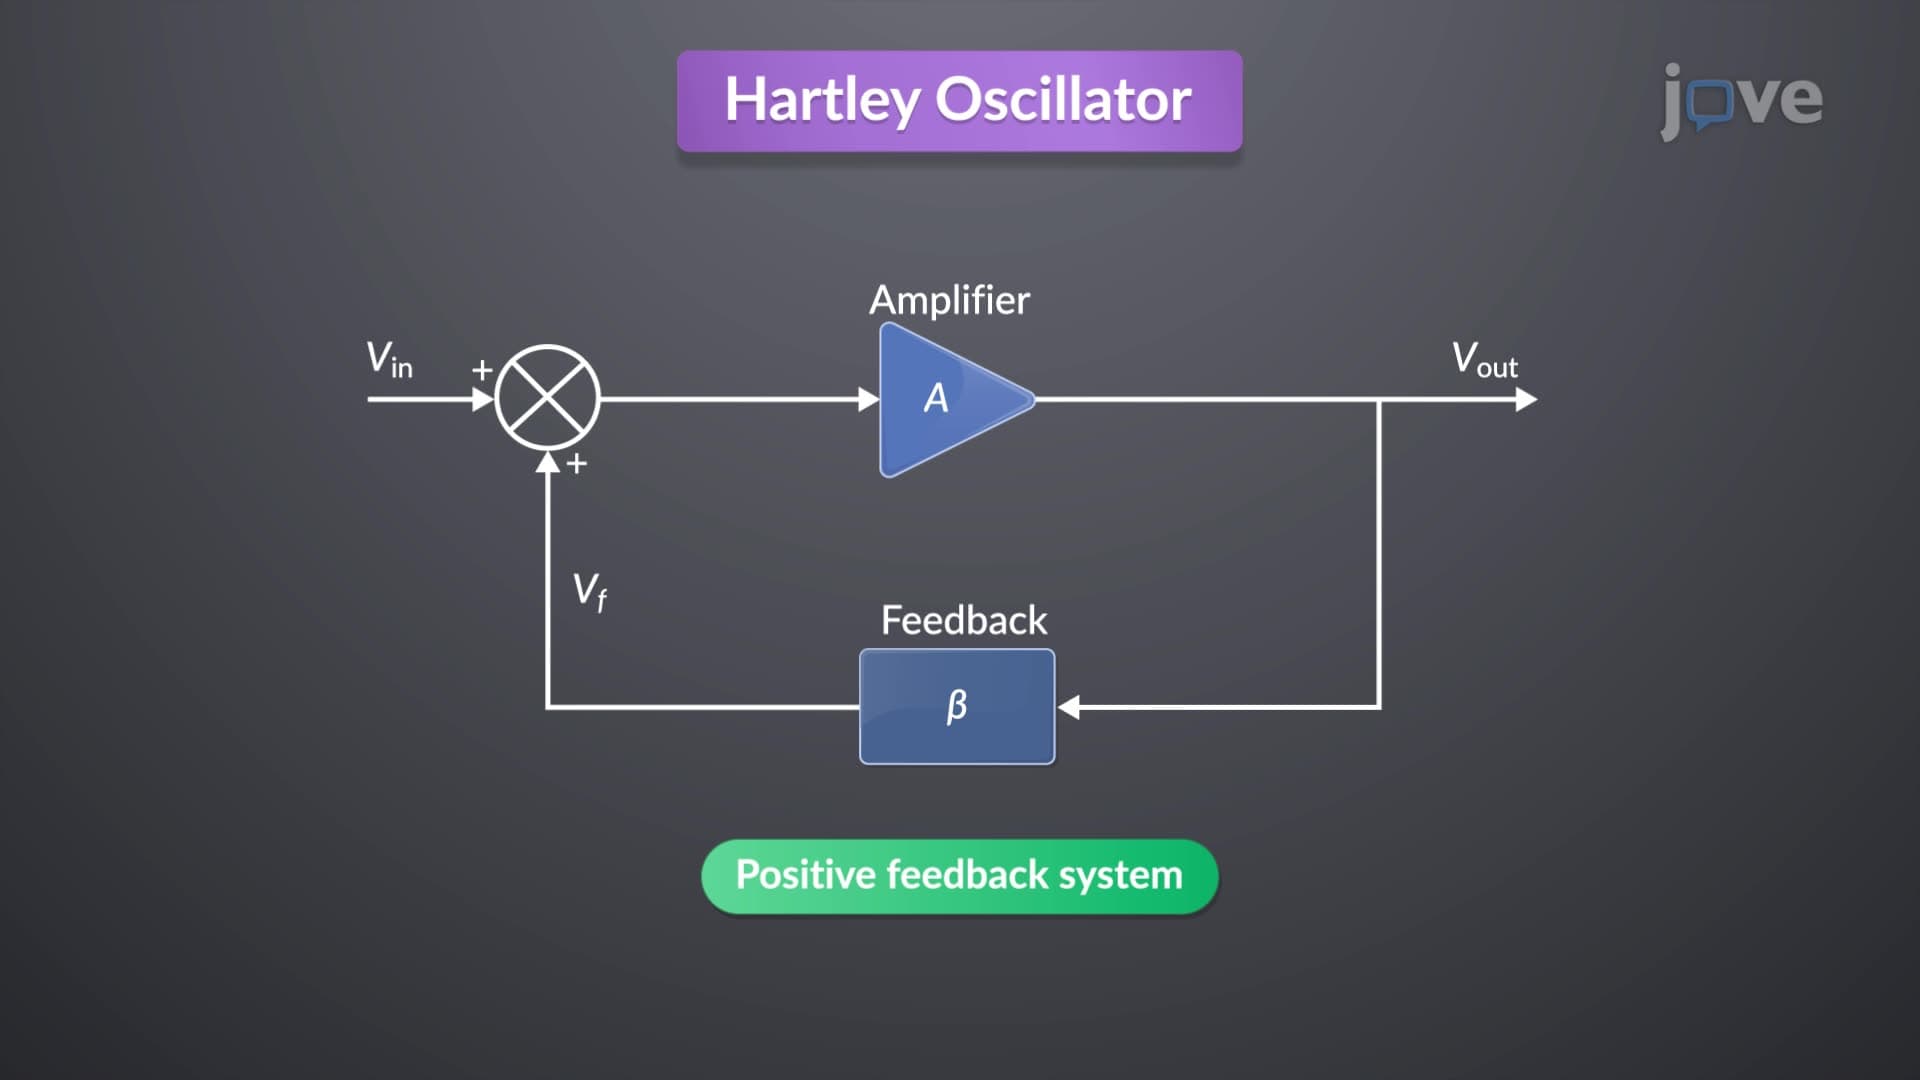
Root Loci for Positive-Feedback Systems01:23

Root Loci for Positive-Feedback Systems

The Hartley oscillator is a positive feedback system that sustains oscillations by feeding the output back to the input in phase, thereby reinforcing the signal. Positive feedback systems can be viewed as negative feedback systems with inverted feedback signals. In these systems, the root locus encompasses all points on the s-plane where the angle of the system transfer function equals 360 degrees.
The construction rules for the root locus in positive feedback systems are similar to those in...
Time-Domain Interpretation of PD Control01:07

Time-Domain Interpretation of PD Control

Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Time and frequency -Domain Interpretation of PI Control01:27

Time and frequency -Domain Interpretation of PI Control

Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
Limits with Oscillating Discontinuities01:19

Limits with Oscillating Discontinuities

An oscillating discontinuity is a type of discontinuity in which a function’s values fluctuate infinitely often as the input approaches a particular point. Unlike jump discontinuities, where the function suddenly shifts between two values, or infinite discontinuities, where the function diverges without bound, an oscillating discontinuity arises from rapid back-and-forth variation. Because the function never stabilizes toward a single value, no finite limit exists at that point.One of the most...

