Improving precise positioning of surgical robotic instruments by a three-side-view presentation system on telesurgery
Related Experiment Video
Updated: Aug 9, 2026
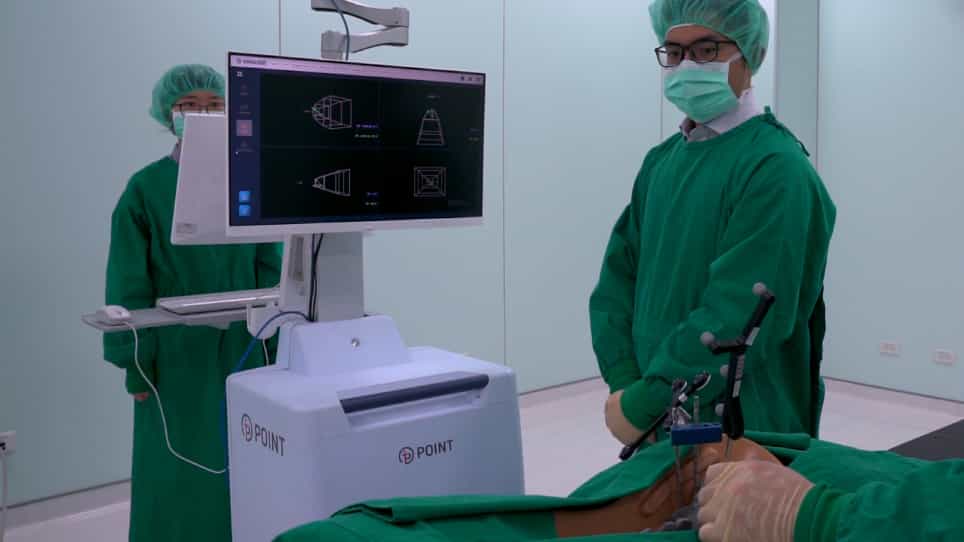
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Kenta Hori1, Tomohiro Kuroda, Hiroshi Oyama
1Graduate School of Informatics, Kyoto University, Kyoto, Japan. hori@biosim.med.kyoto-u.ac.jp

Abstract:
For faultless collaboration among the surgeon, surgical staffs, and surgical robots in telesurgery, communication must include environmental information of the remote operating room, such as behavior of robots and staffs, vital information of a patient, named supporting information, in addition to view of surgical field. "Surgical Cockpit System, " which is a telesurgery support system that has been developed by the authors, is mainly focused on supporting information exchange between remote sites. Live video presentation is important technology for Surgical Cockpit System. Visualization method to give precise location/posture of surgical instruments is indispensable for accurate control and faultless operation. In this paper, the authors propose three-side-view presentation method for precise location/posture control of surgical instruments in telesurgery. The experimental results show that the proposed method improved accurate positioning of a telemanipulator.