Determining natural arm configuration along a reaching trajectory
Related Experiment Video
Updated: Aug 13, 2026
An Objective and Child-friendly Assessment of Arm Function by Using a 3-D Sensor
Published on: February 12, 2018
Tao Kang1, Jiping He, Stephen I Helms Tillery
1The Biodesign Institute and Harrington Department of Bioengineering, Arizona State University, Tempe, AZ, USA.

Abstract:
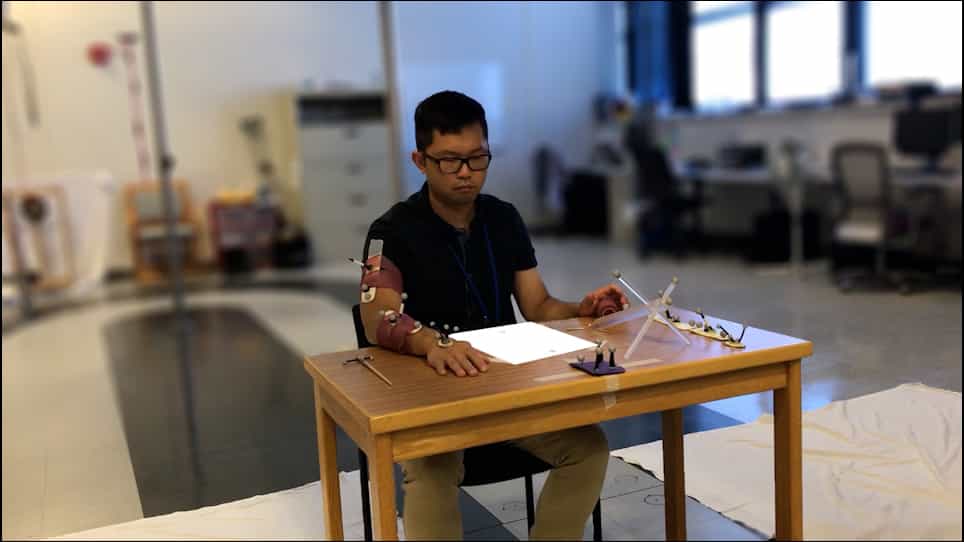
Owing to the flexibility and redundancy of neuromuscular and skeletal systems, humans can trace the same hand trajectory in space with various arm configurations. However, the joint trajectories of typical unrestrained movements tend to be consistent both within and across subjects. In this paper we propose a method to solve the 3-D inverse kinematics problem based on minimizing the magnitude of total work done by joint torques. We examined the fit of the joint-space trajectories against those observed from human performance in a variety of movement paths in 3-D workspace. The results showed that the joint-space trajectories produced by the method are in good agreement with the subjects' arm movements (r2>0.98), with the exception of shoulder adduction/abduction (where, in the worst case, r2 approximately 0.8). Comparison of humeral rotation predicted by our algorithm with other models showed that the correlation coefficient r2) between actual data and our predictions is extremely high (mostly >0.98, 11 out of 15 cases, with a few exceptions, 4 of 15, in the range of 0.8-0.9) and the slope of linear regression is much closer to one (<0.05 distortion in 12 out of 15 cases, with only one case >0.15). However, the discrepancy in shoulder adduction/abduction indicated that when only the hand path is known, additional constraint(s) may be required to generate a complete match with human performance.
More Related Videos
Related Concept Videos
 01:26
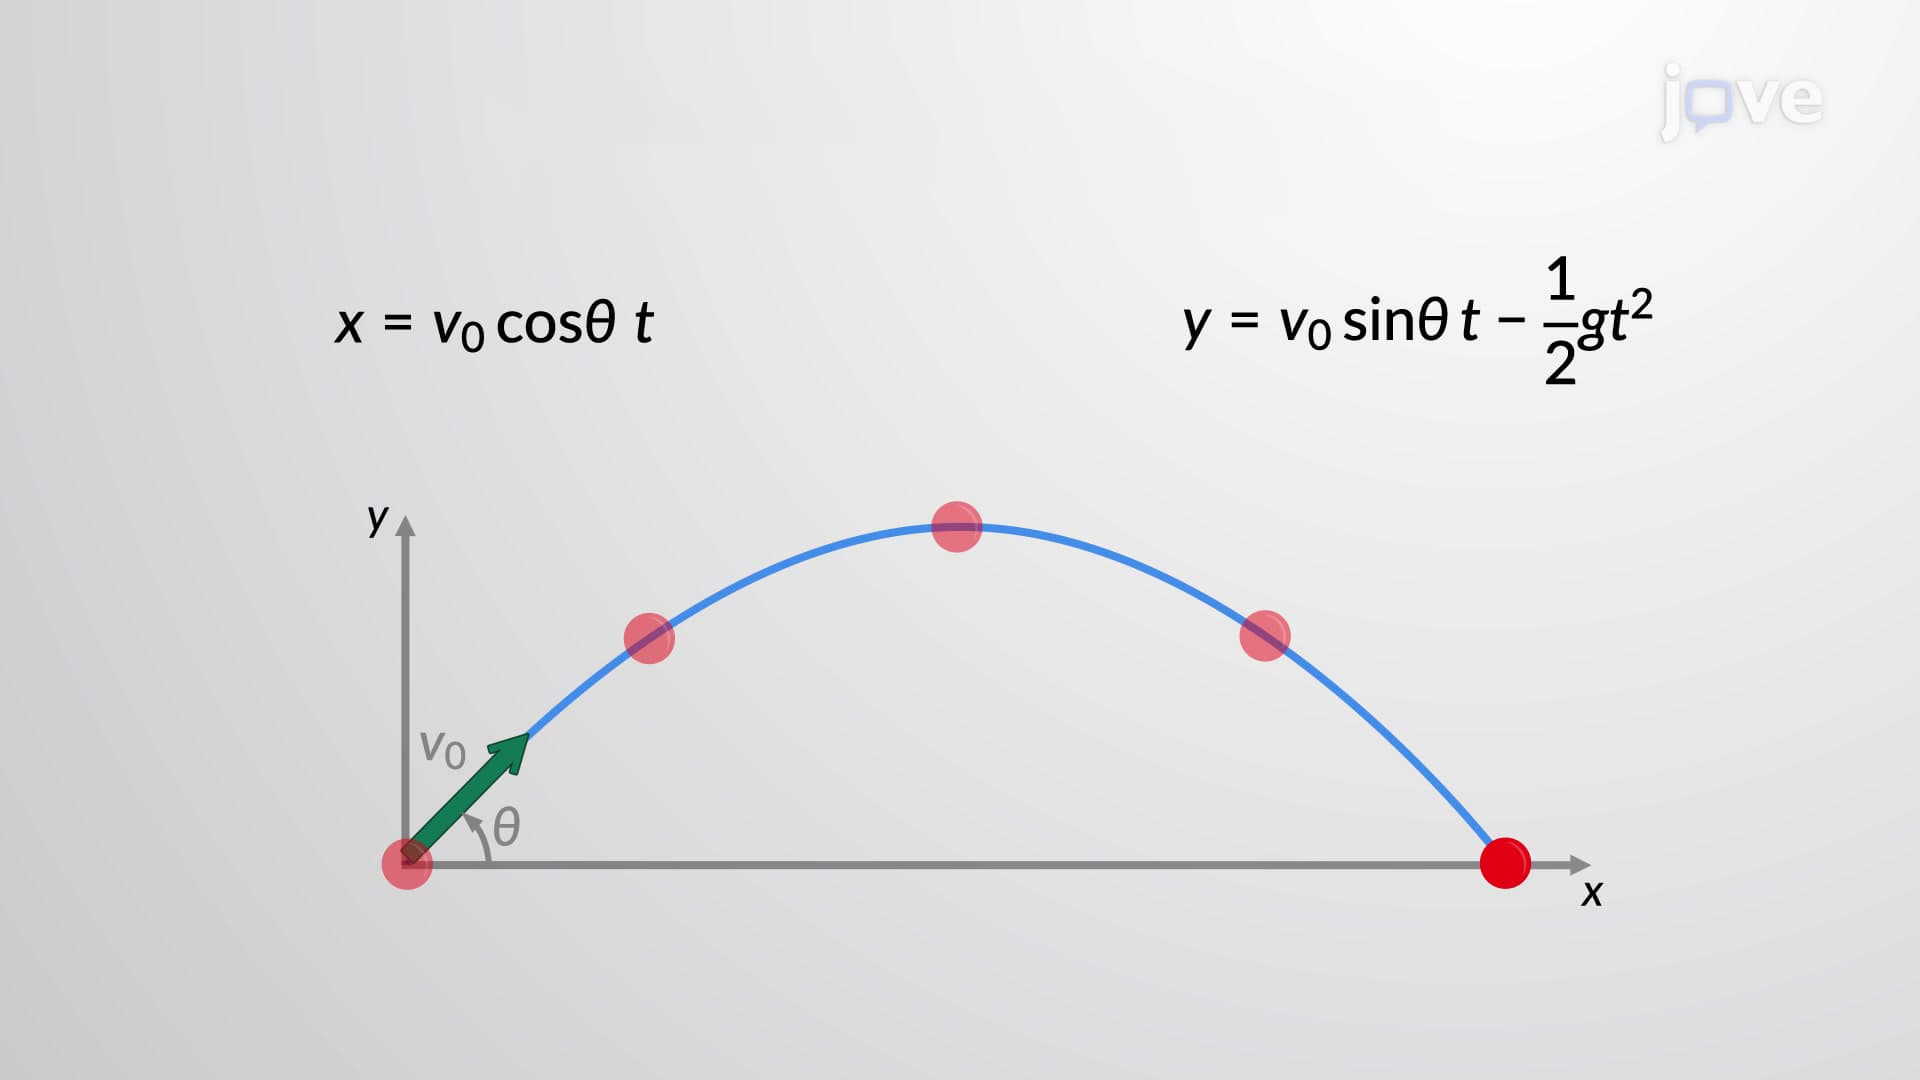
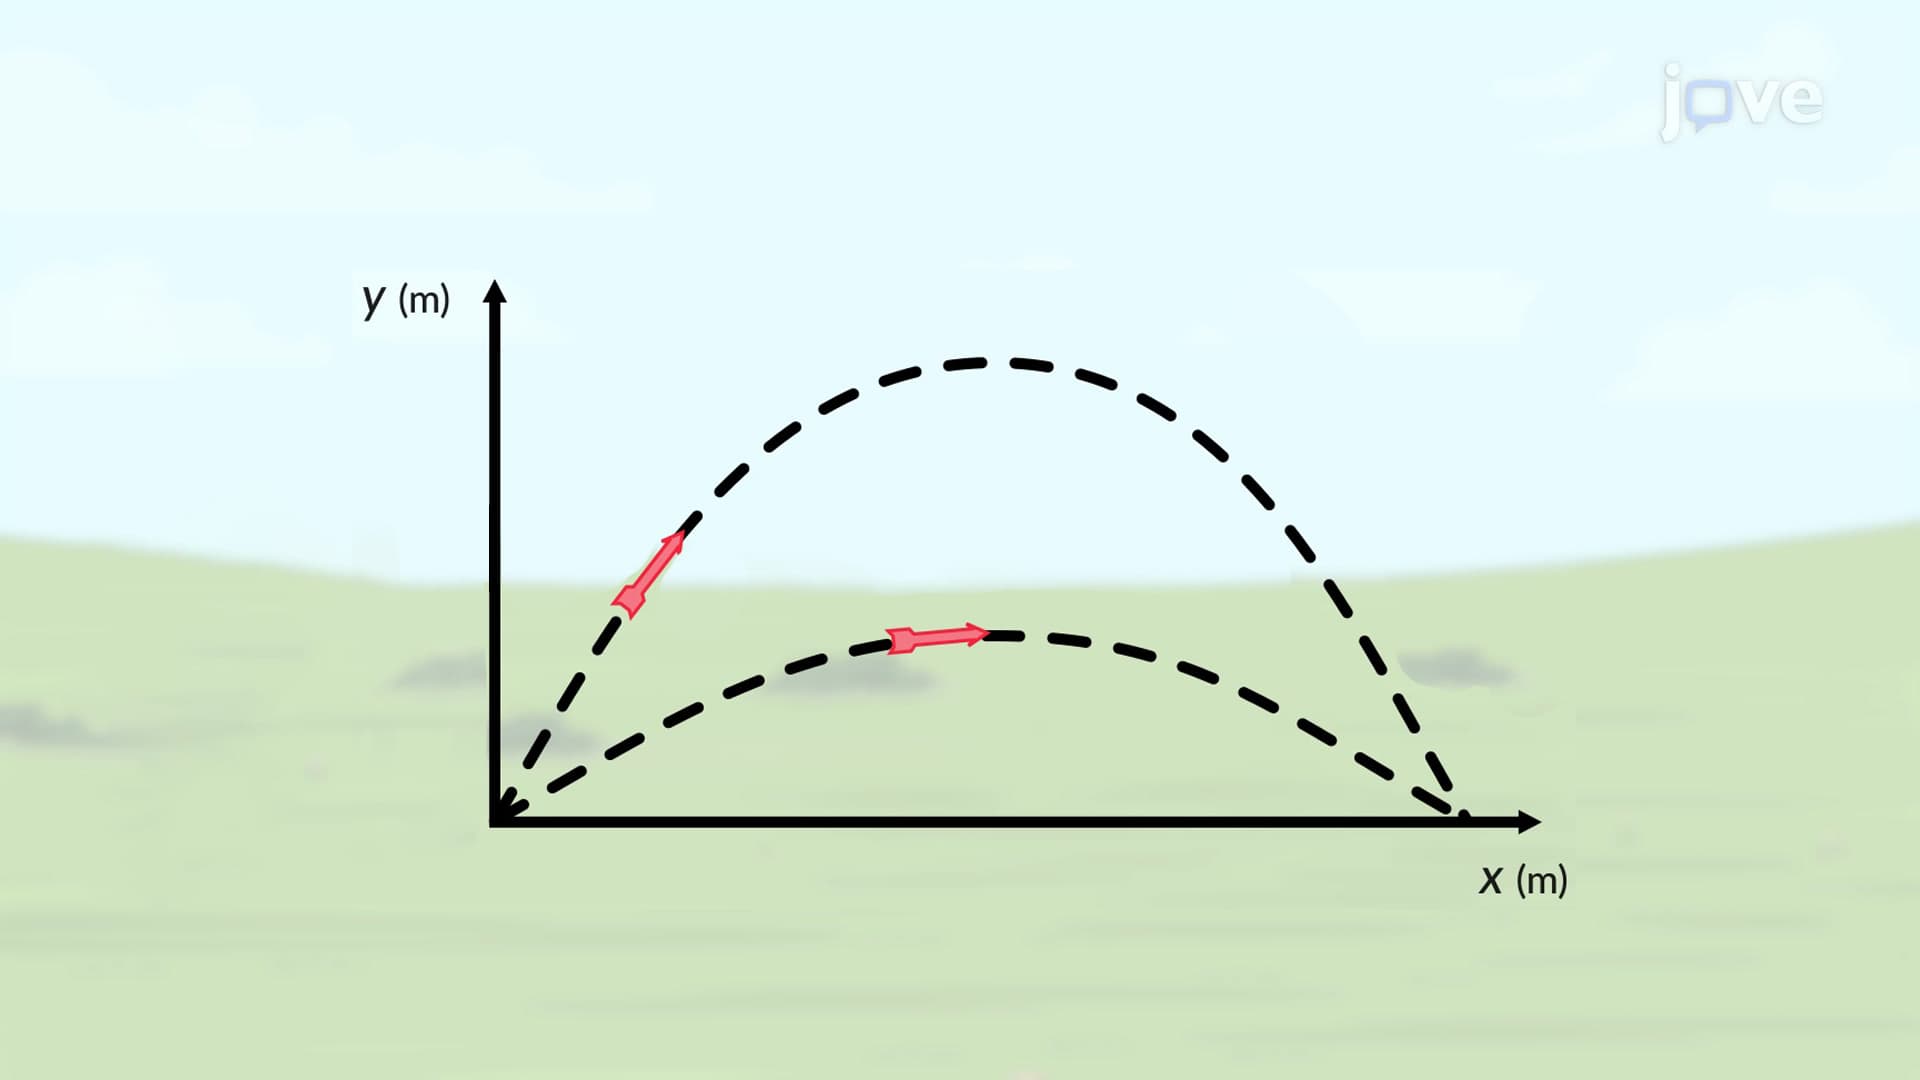
Projectile Motion: Equations
Any projectile motion problem can be solved by using the following strategy:
 01:18
Projectile Motion: Example
When we speak of the range (R) of a projectile on level...
 01:30
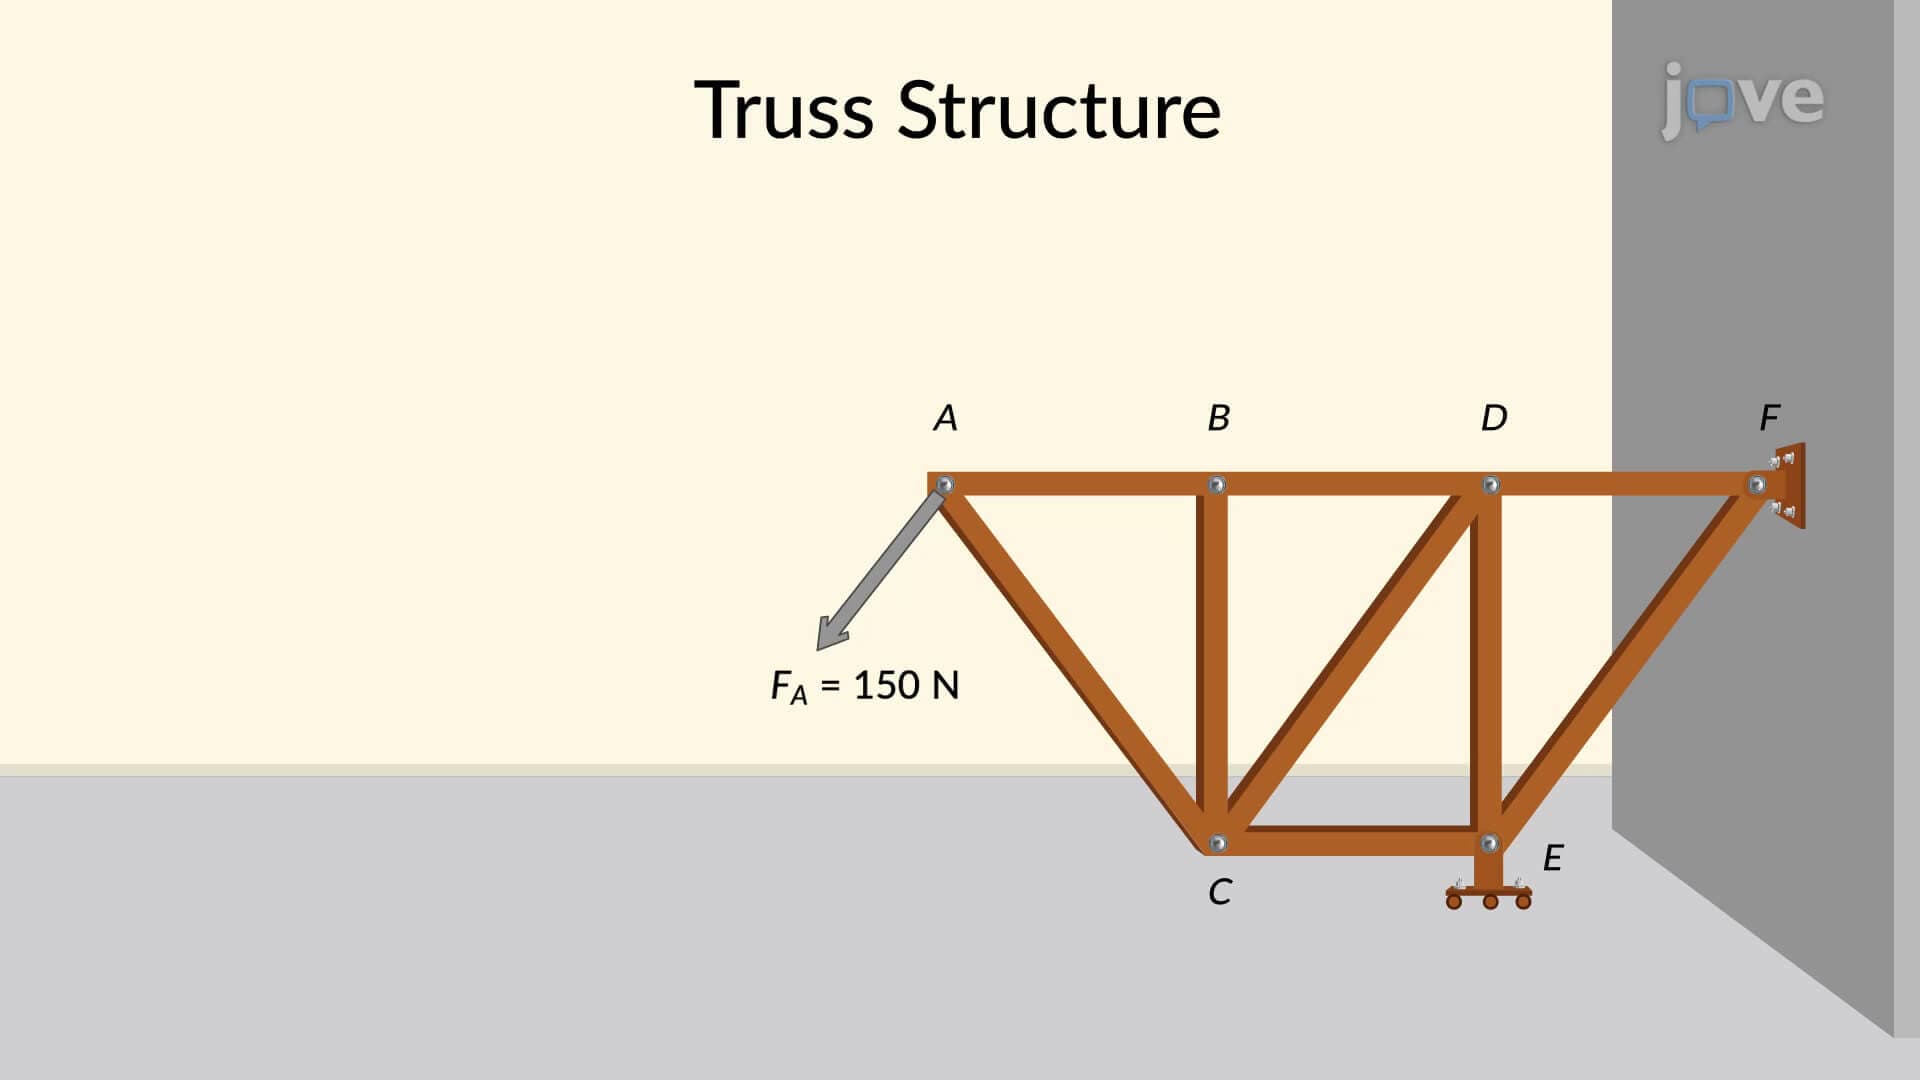
Method of Joints: Problem Solving II
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:30
Machines: Problem Solving II
 01:26
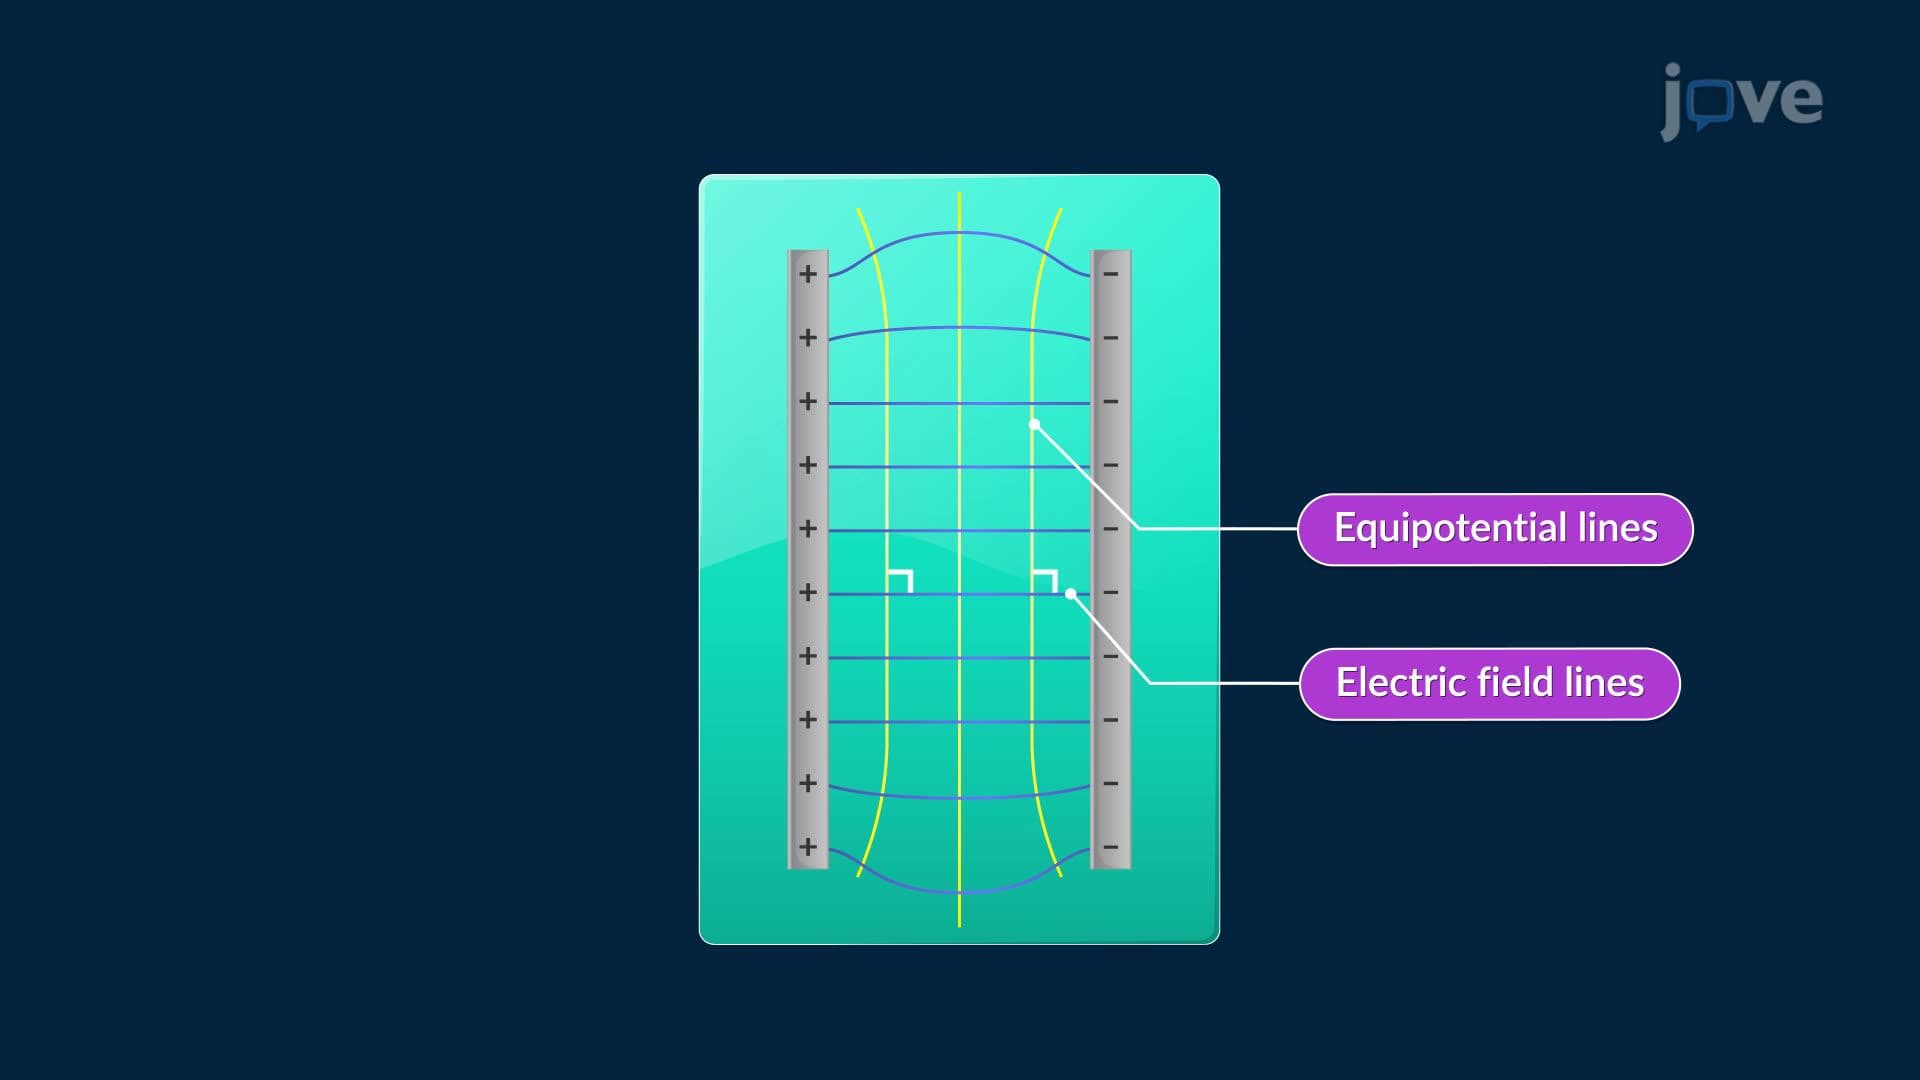
Orthogonal Trajectories