Six degree-of-freedom haptic rendering using spatialized normal cone search
Related Experiment Video
Updated: Aug 15, 2026
3D-Neuronavigation In Vivo Through a Patient's Brain During a Spontaneous Migraine Headache
Published on: June 2, 2014
David E Johnson1, Peter Willemsen, Elaine Cohen
1School of Computing, 50 S. Central Campus Drive, MEB 3190, University of Utah, Salt Lake City, UT 84112, USA. dejohnso@cs.utah.edu

Abstract:
This paper describes a haptic rendering algorithm for arbitrary polygonal models using a six degree-of-freedom haptic interface. The algorithm supports activities such as virtual prototyping of complex polygonal models and adding haptic interaction to virtual environments. The underlying collision system computes local extrema in distance between the model controlled by the haptic device and the rest of the scene. The haptic rendering computes forces and torques on the moving model based on these local extrema. The system is demonstrated on models with tens of thousands of triangles and developed in an accessibility application for finding collision-free paths.

Related Concept Videos
 01:30
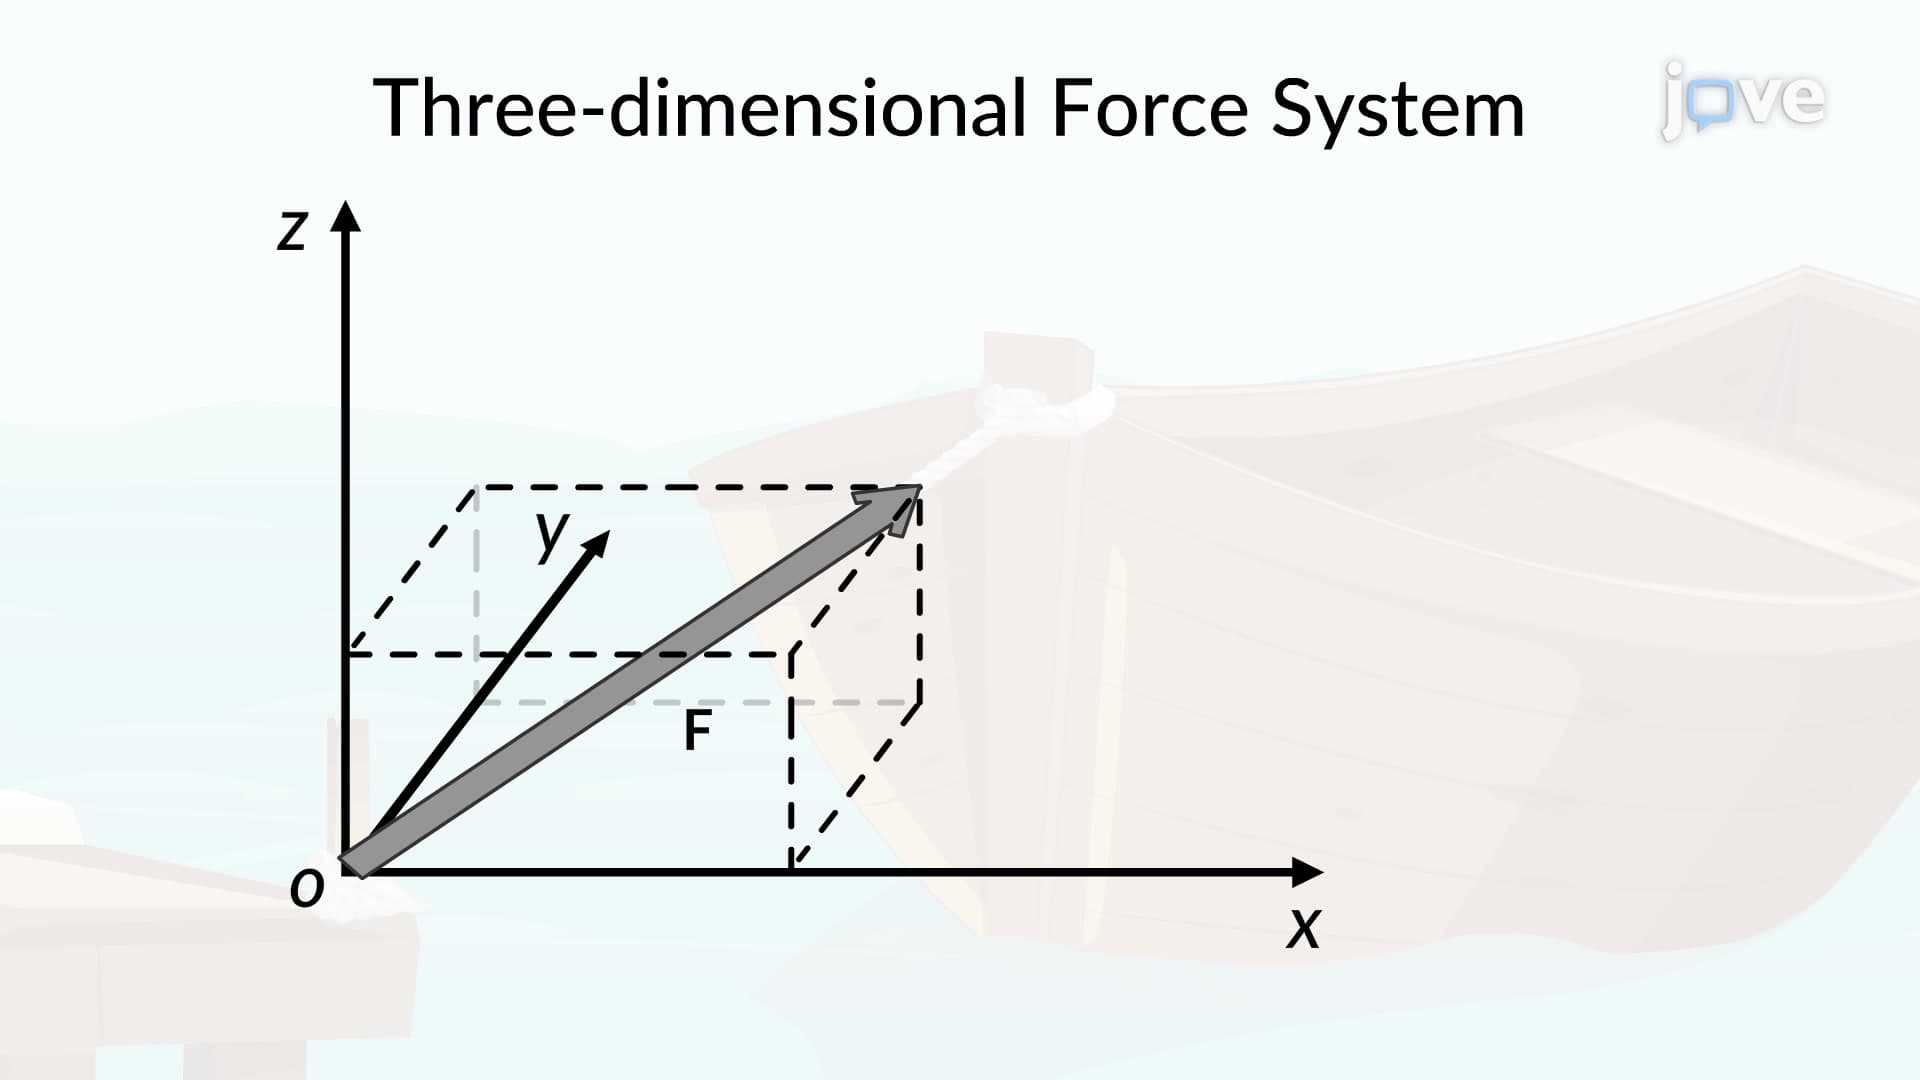
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:28
Cylinders in Three-Dimensional Space
 01:27
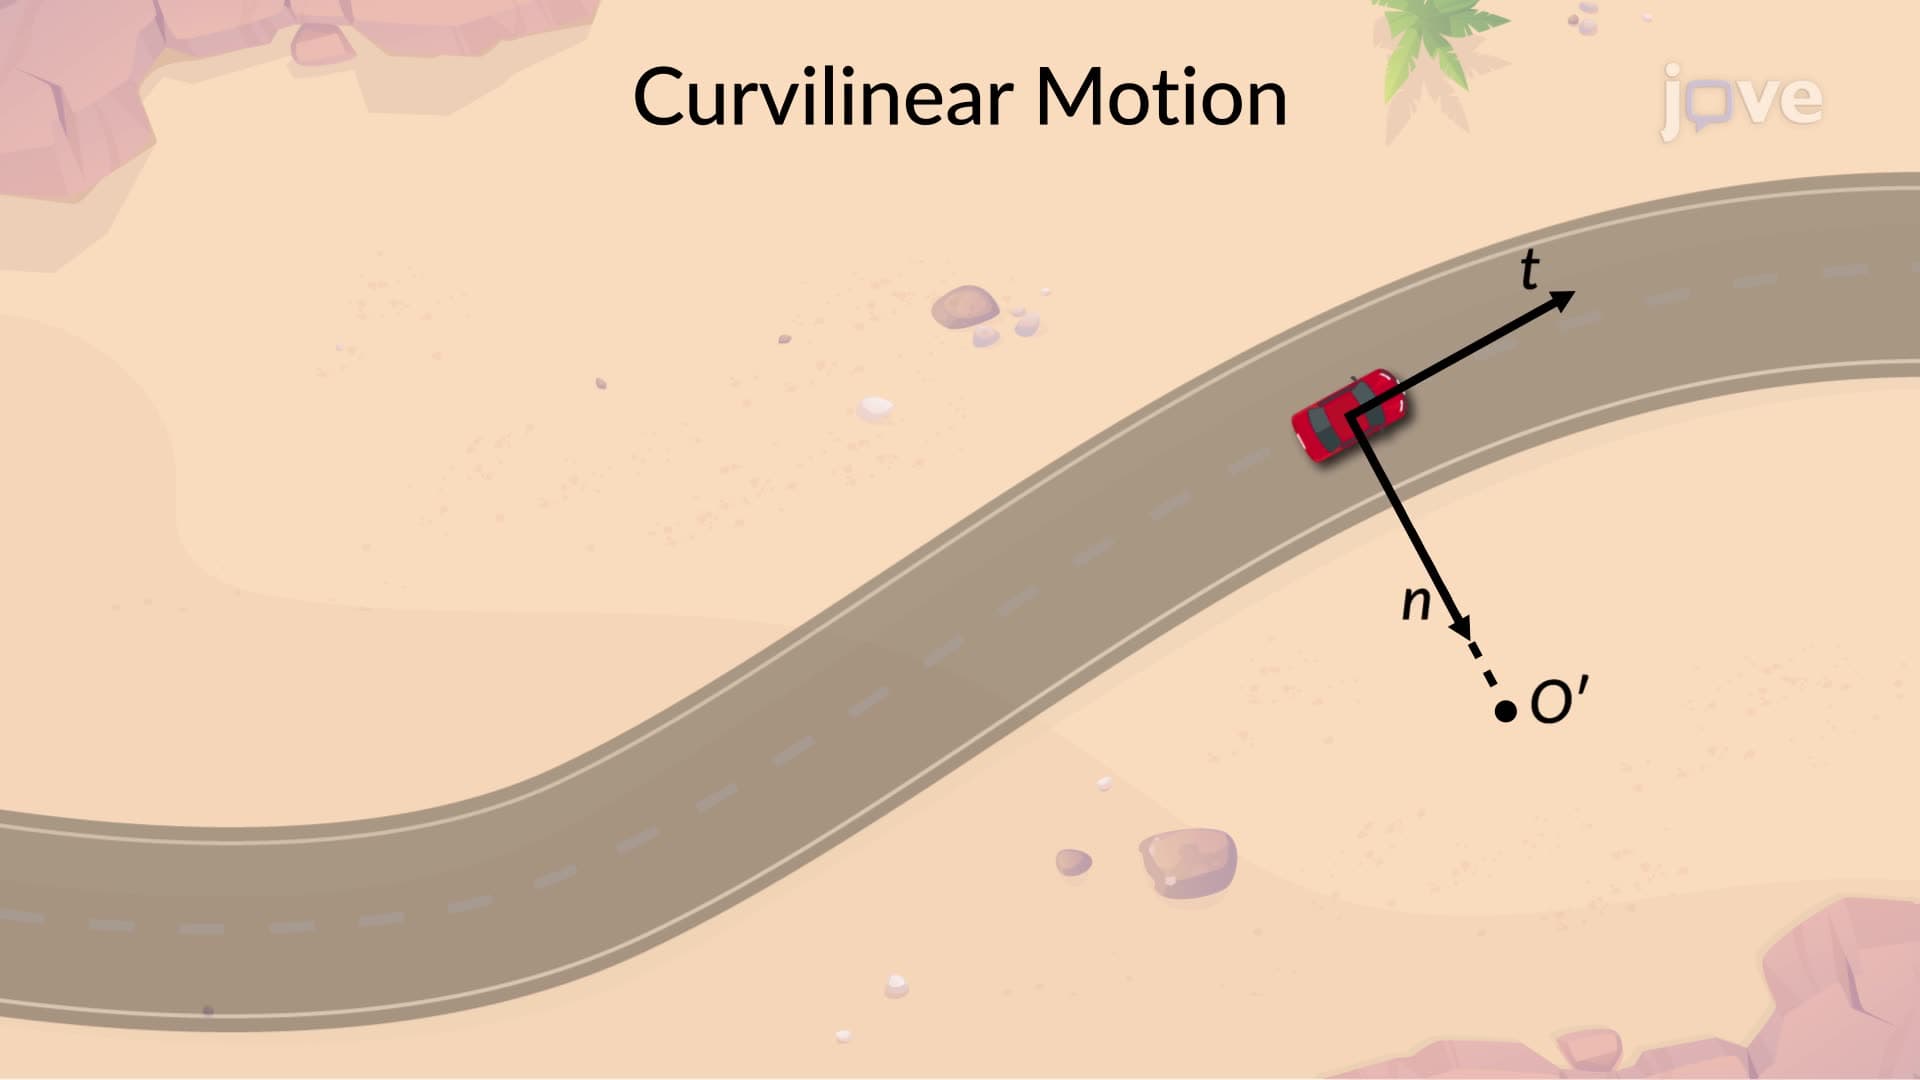
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:30
Three-Dimensional Force System
 01:20
Divergence Theorem in 3D Space