Related Experiment Video
Updated: Aug 14, 2026

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Deliberate control of continuous motor performance
Jurjen Bosga1, Ruud G J Meulenbroek, David A Rosenbaum
1Department of Cognitive Psychology, Nimegen Institue for Cognition and Information, De Beaufortweg 18, 3941 PB, Doorn, The Netherlands. bosga@xs4all.nl

Abstract:
The authors examined the means by which people vary movement parameters to satisfy more than 1 constraint at a time in a repetitive motor task. The authors expected that when participants (N = 12) were simultaneously confronted with spatial and temporal constraints in an ellipse-drawing task, they would either exploit the intrinsic amplitude-frequency relationships or activate less natural control regimes to prioritize their movement goals. By focusing on local amplitude and frequency errors and parameter changes from 1 movement to the next, the authors distinguished parameter changes that reflected exploitation of biomechanics from those that required deliberate control. The findings demonstrated that at low movement speeds, participants can pursue multiple movement goals simultaneously; at higher speeds, their capacity to satisfy multiple task goals is reduced. The authors used a new method of inferring deliberate control from movement kinematics in the present study.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:11
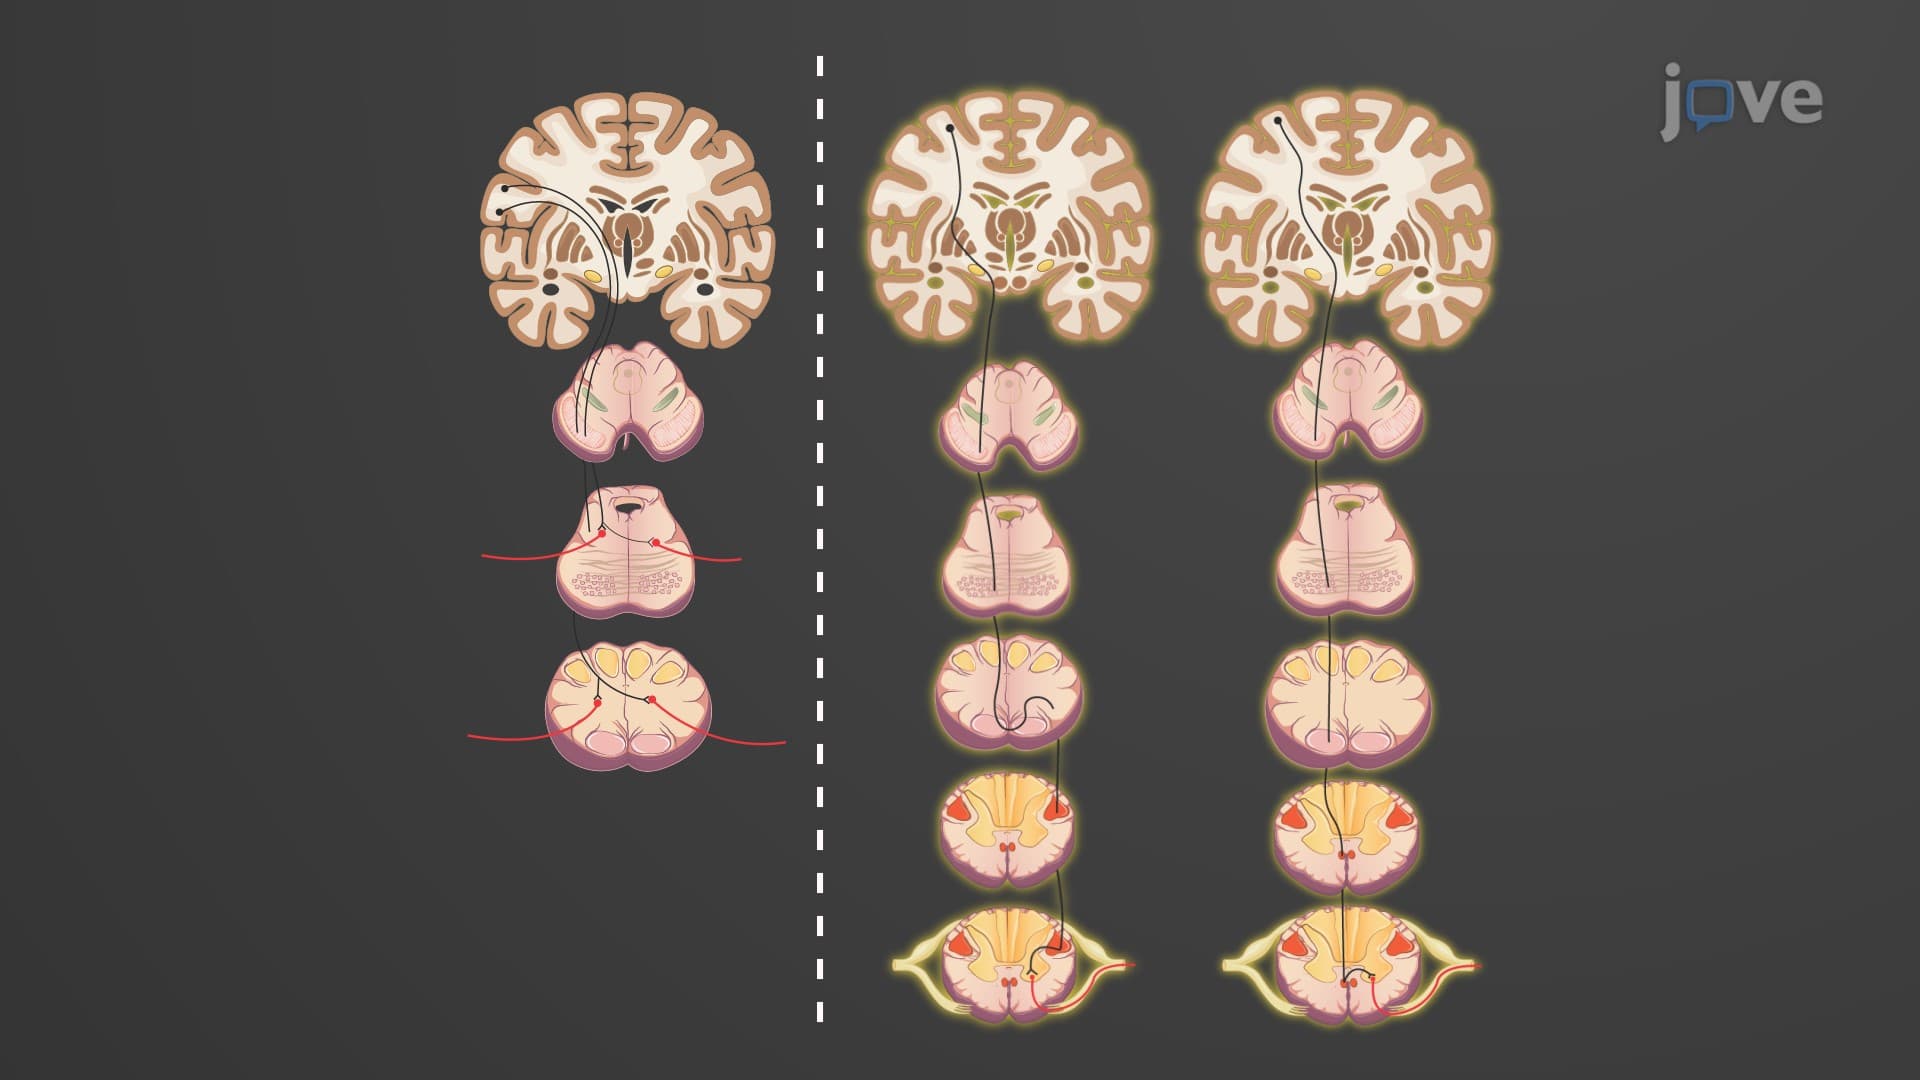
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...