The relation between force and movement when grasping an object with a precision grip
Related Experiment Video
Updated: Aug 8, 2026
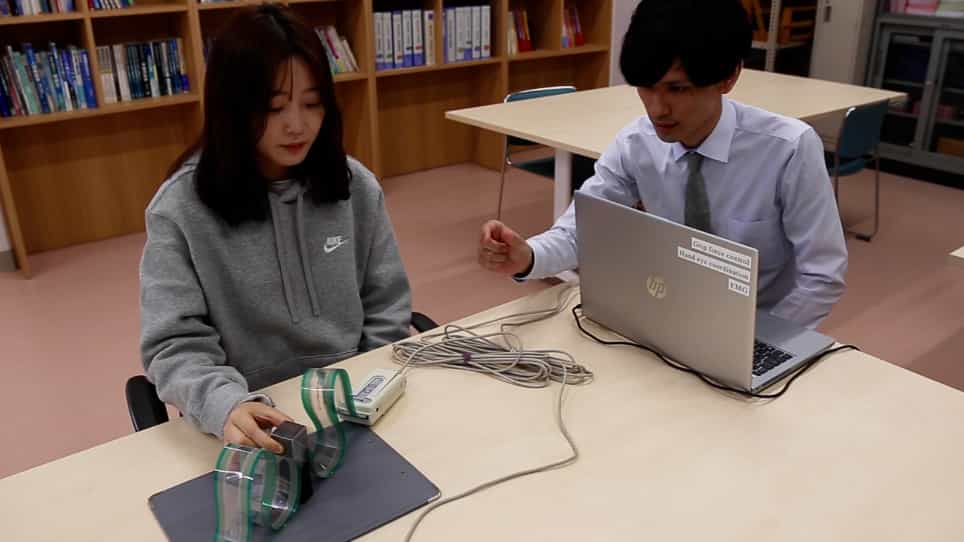
Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
Published on: January 15, 2018
Marianne Biegstraaten1, Jeroen B J Smeets, Eli Brenner
1Department of Neuroscience, ErasmusMC, Postbus 1738, 3000 DR, Rotterdam, The Netherlands. biegstraaten-meeuws@wanadoo.nl

Abstract:
When reaching out for objects, the digits' paths curve so that they approach their positions of contact moving more or less perpendicularly to the local surface orientation. This increases the accuracy of positioning the digits and ensures that any forces exerted at contact are nearly perpendicular to the surface, so that friction will prevent the digits from slipping along the surface. When lifting the object a similar force perpendicular to the surface is needed to prevent the object from slipping from one's fingers. In order to determine whether these two issues are dealt with simultaneously we let subjects pick up a cube from three different starting positions and measured the digits' movements and forces from before contact until the moment the cube started moving. The impact force was low. After impact, the digits spent about 200 ms in contact with the surface of the cube before the latter started to move. The digits first decelerated, and then they gradually built up the grip- and lift forces to move the cube upwards. We found no direct relationship between the control of the reaching movement towards the object and the force applied at the surface of the object to pick it up. We conclude that the reaching and lifting movements are quite independent.

Related Concept Videos
 01:06
Force
The study of motion is called kinematics, but kinematics only describes the way...
 01:07
Frictional Force
 01:10
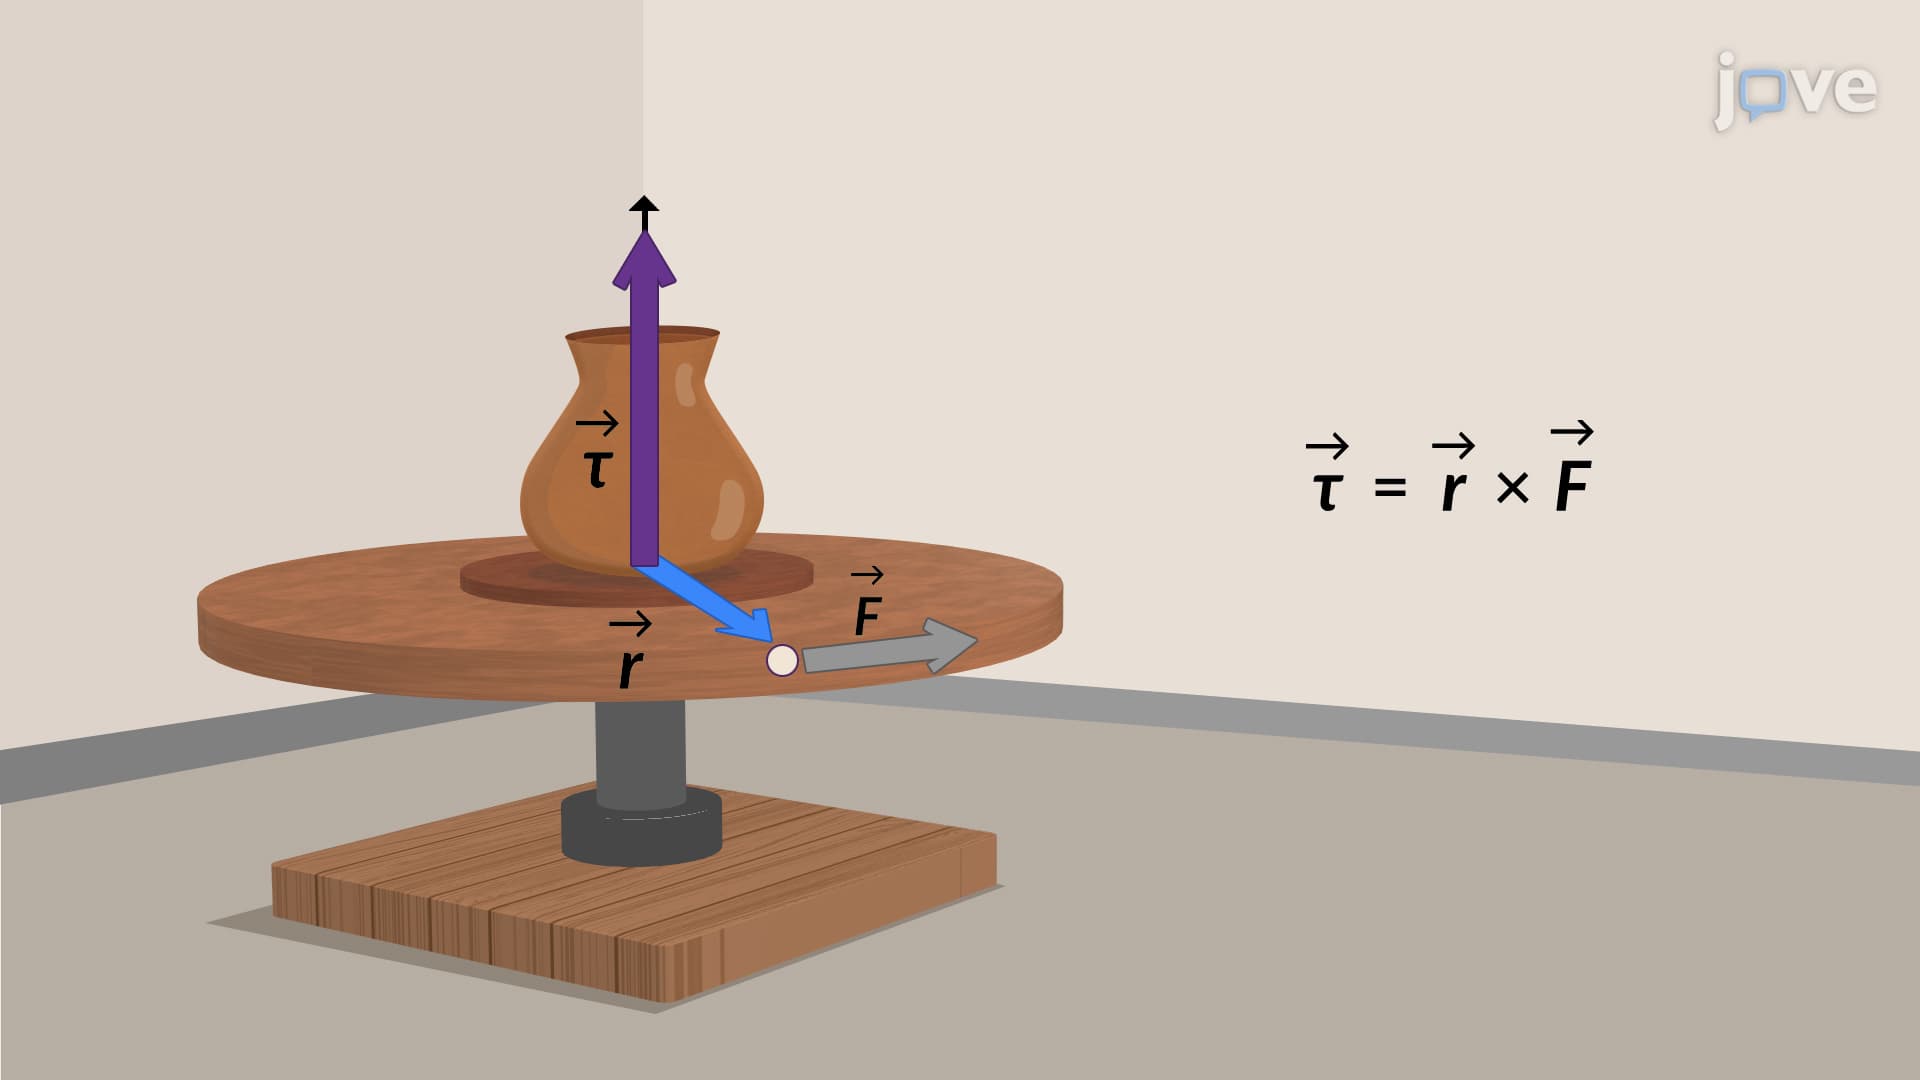
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:25
Introduction to force
 01:29
Moment of a Force: Problem Solving
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...