Related Experiment Video
Updated: Aug 14, 2026

Measurement of Dynamic Force Acted on Water Strider Leg Jumping Upward by the PVDF Film Sensor
Published on: August 3, 2018
Take-off and landing forces in jumping frogs
Sandra Nauwelaerts1, Peter Aerts
1Department of Biology, University of Antwerp (UIA), Universiteitsplein 1, B-2610 Wilrijk, Antwerpen, Belgium.

Abstract:
Anurans use a saltatorial (jumping) mode of locomotion. A jumping cycle can be divided into four subphases: propulsion, flight, landing and recovery. We studied the landing phase during locomotion in Rana esculenta by measuring the ground reaction forces during propulsion and landing over a range of distances. Landing performance affects locomotor ability in jumping frogs. Landing and recovery together take up one third of the locomotor cycle. Peak landing forces are on average almost three times larger than propulsive forces. The forelimbs appear to be fully extended when they make contact with the substrate and absorb the first impact peak. The height of this peak varies depending on arm positioning and jumping distance. Since the stiffness of the arms stays constant over the full jumping range, it is possible that this is a limiting factor in the ability of the forelimbs to work as dampers. A spring-dashpot model is used to model the effect of arm angle at touch down. Damping during landing is performed by placing the forelimbs at an optimal angle to cancel frictional forces effectively.
Related Concept Videos
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short circuit,...
 01:29
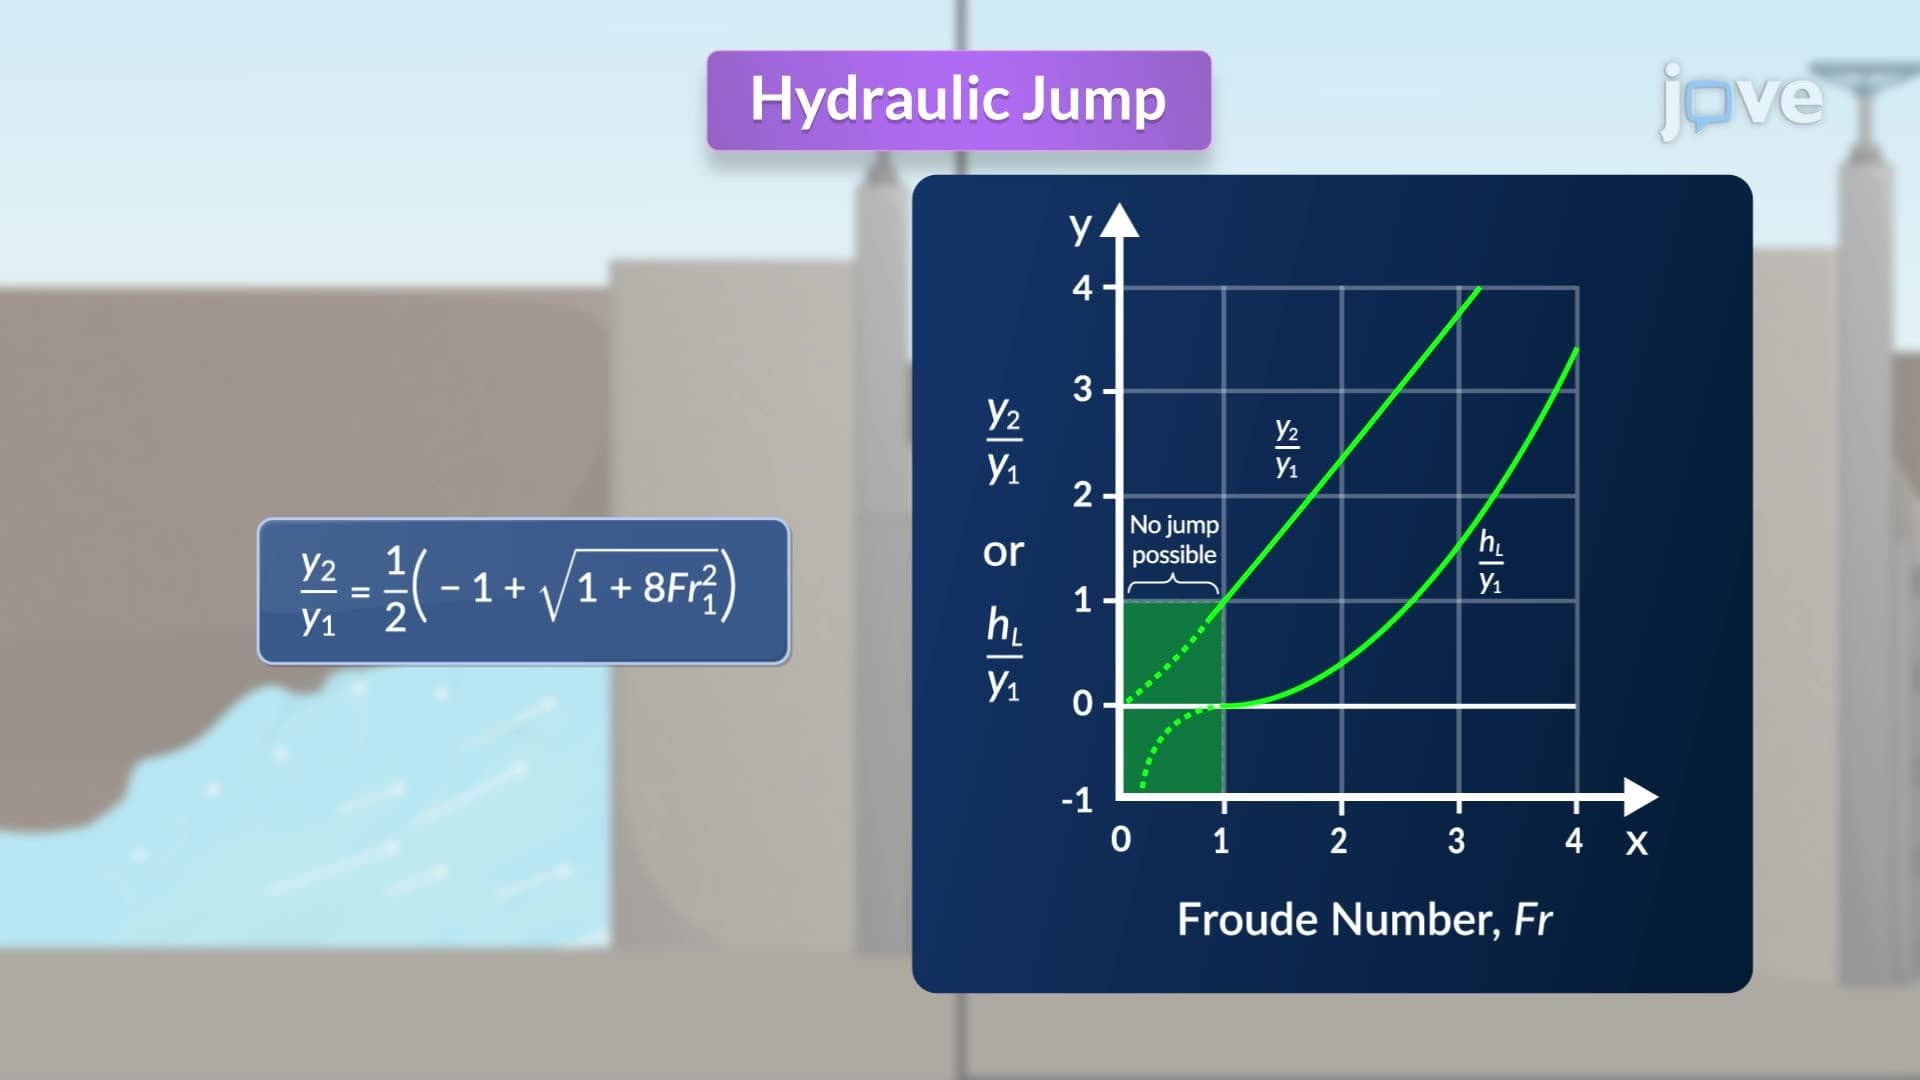
Hydraulic Jump
 01:05
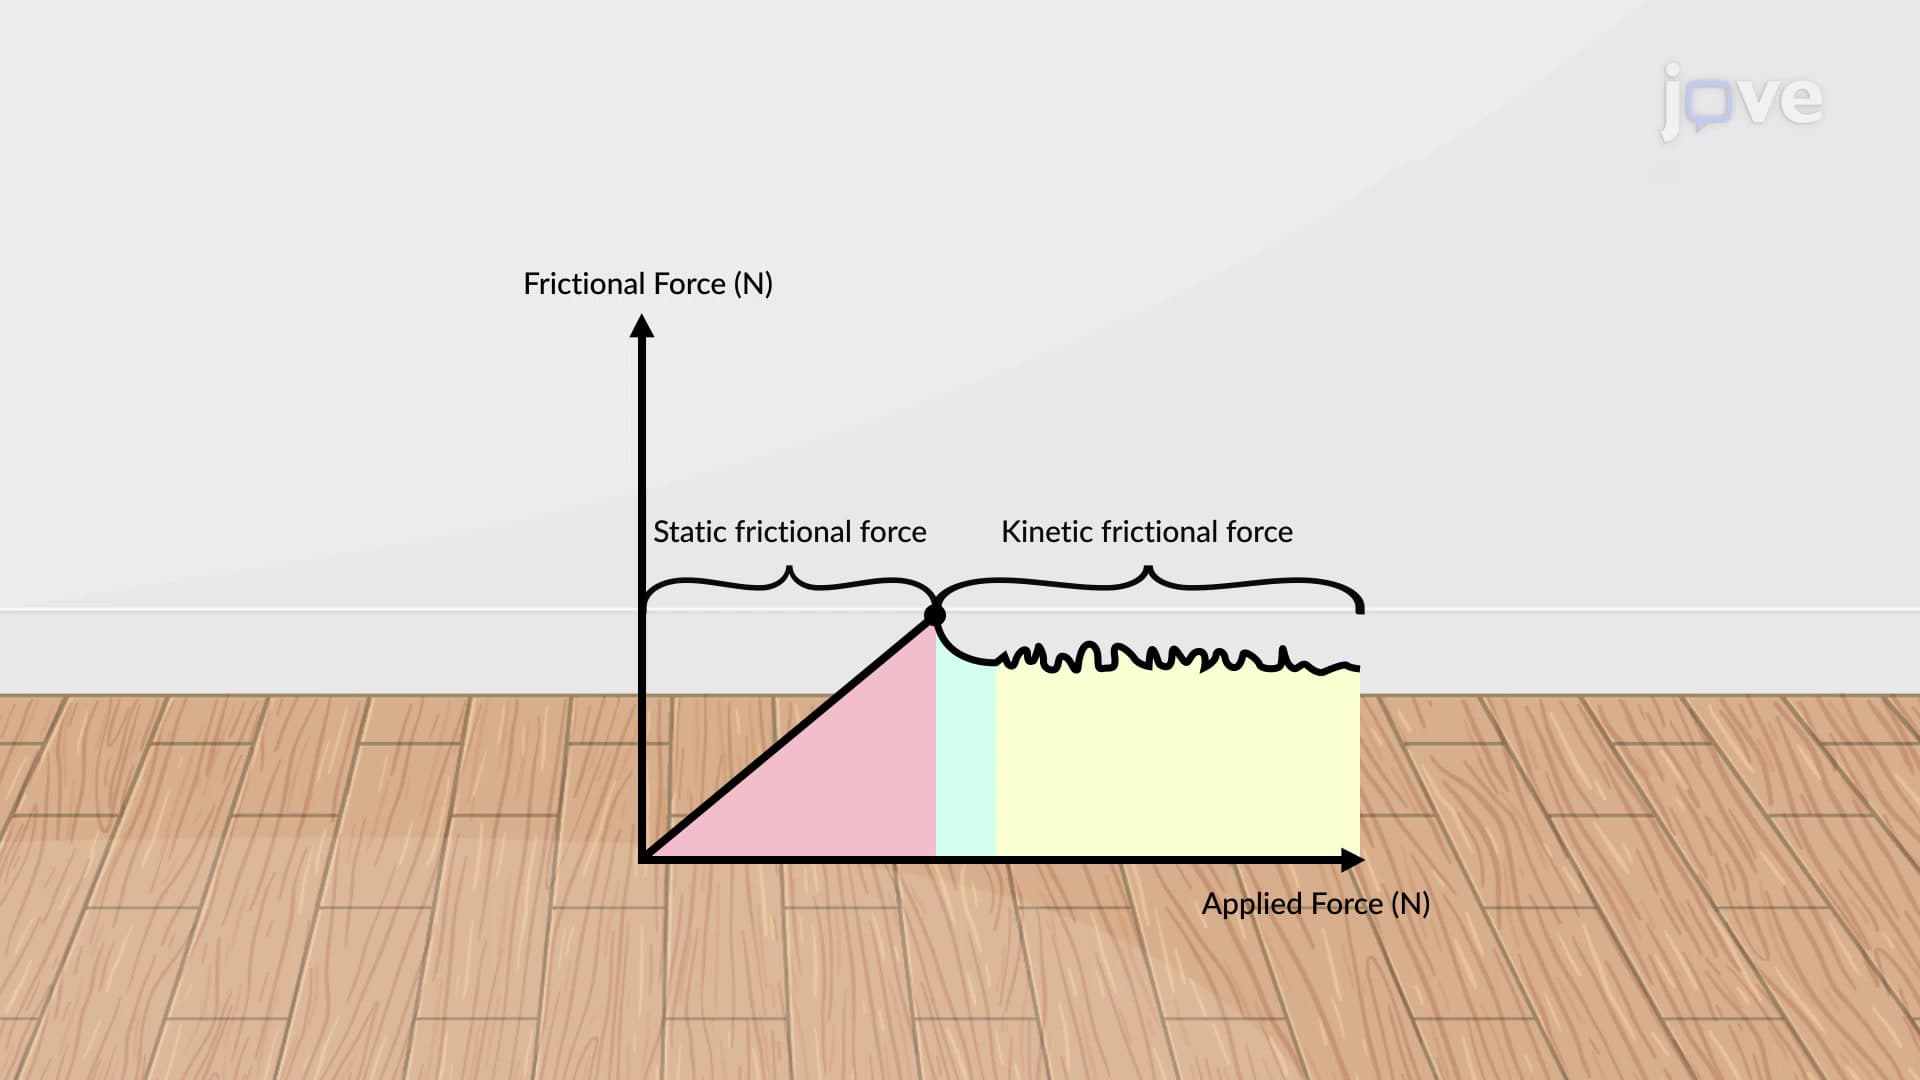
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:16
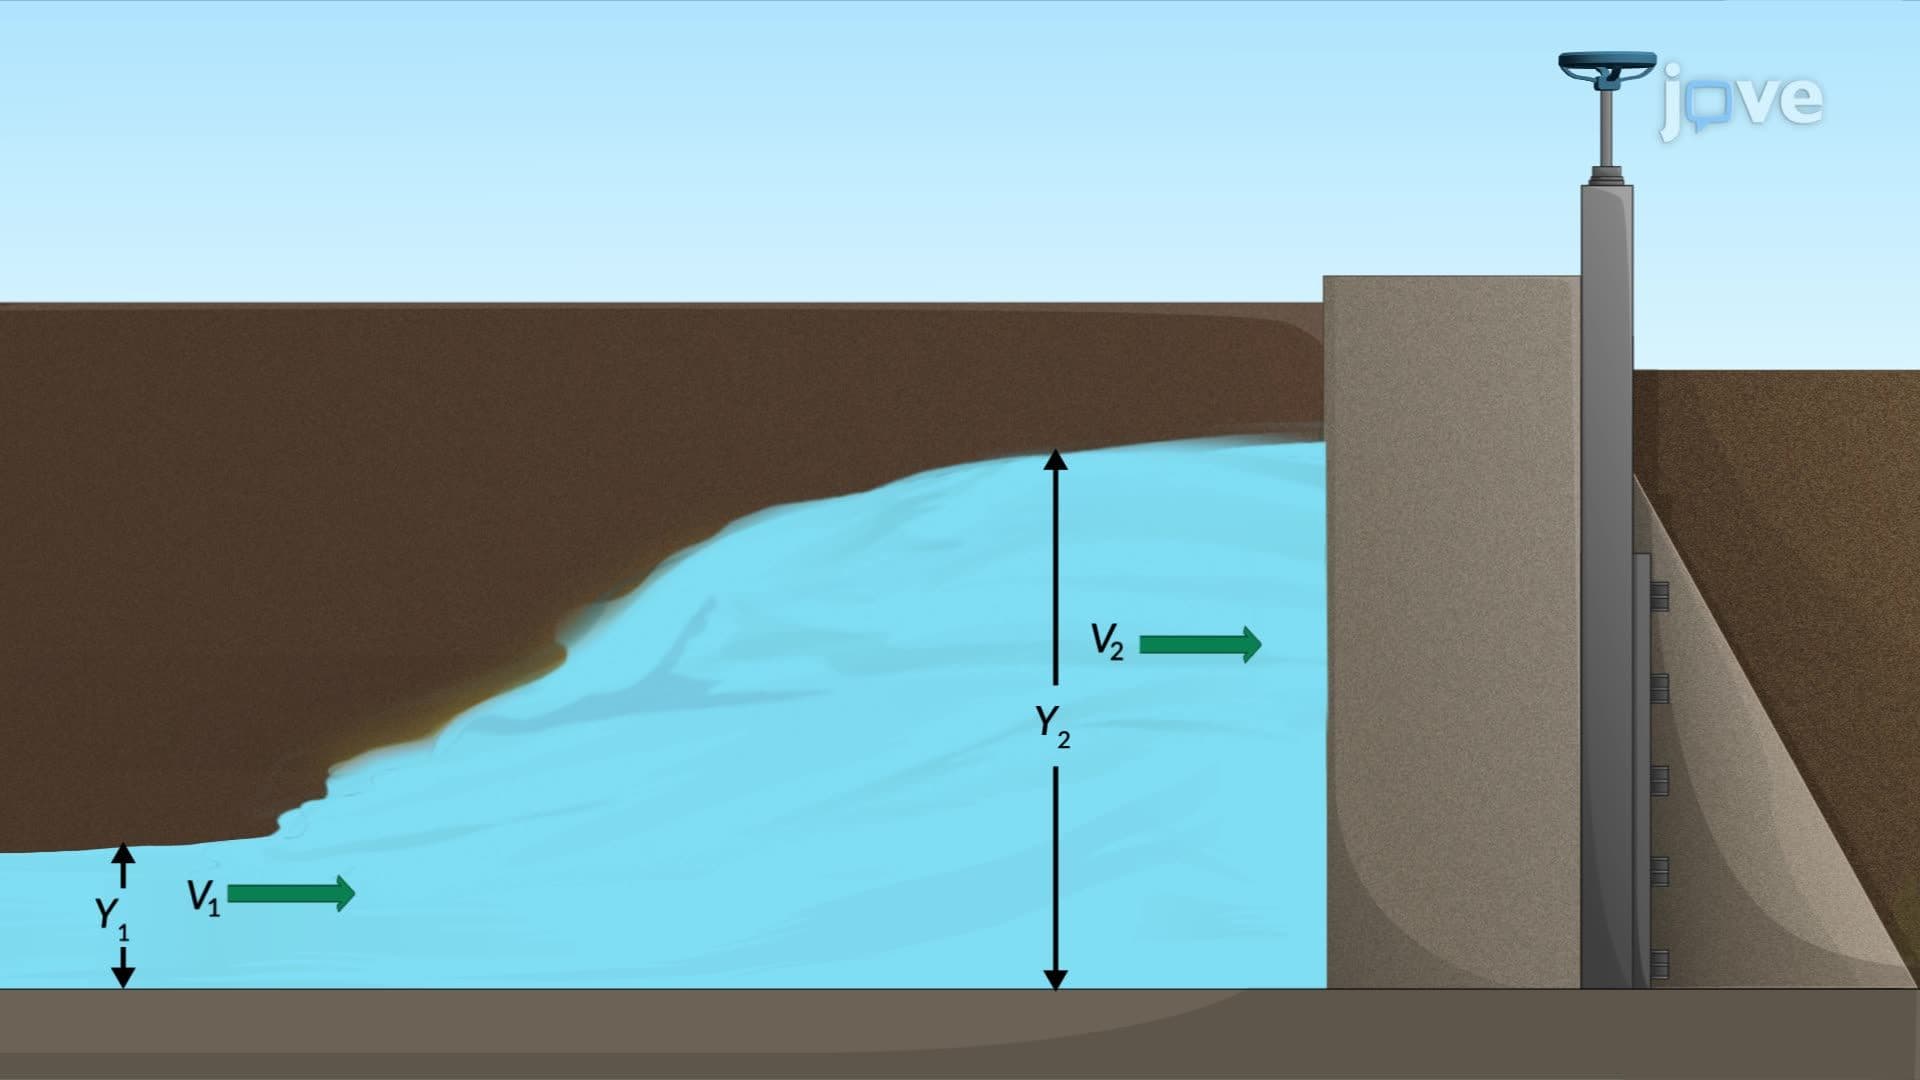
Hydraulic Jump: Problem Solving
 01:28
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.
 01:20
Two-Dimensional Force System