Related Experiment Video
Updated: Aug 14, 2026
Motion-Acuity Test for Visual Field Acuity Measurement with Motion-Defined Shapes
Published on: February 23, 2024
Integration of geometric elements, Euclidean relations, and motion curves for parametric shape and motion estimation
Pierre-Louis Bazin1, Jean-Marc Vézien
1Laboratory for Medical Image Computing, Neuroradiology Division, Phipps B100, Johns Hopkins Hospital, 600 North Wolfe Street, Baltimore, MD 21287, USA. bbazin1@jhmi.edu

Abstract:
This paper presents an approach to shape and motion estimation that integrates heterogeneous knowledge into a unique model-based framework. We describe the observed scenes in terms of structured geometric elements (points, line segments, rectangles, 3D corners) sharing explicitly Euclidean relationships (orthogonality, parallelism, colinearity, coplanarity). Camera trajectories are represented with adaptative models which account for the regularity of usual camera motions. Two different strategies of automatic model building lead us to reduced models for shape and motion estimation with a minimal number of parameters. These models increase the robustness to noise and occlusions, improve the reconstruction, and provide a high-level representation of the observed scene. The parameters are optimally computed within a sequential Bayesian estimation procedure that gives accurate and reliable results on synthetic and real video imagery.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:21
Curves Defined by Parametric Equations
 01:29
Real-World Applications of Space Curves
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:27
Curvilinear Motion: Normal and Tangential Components
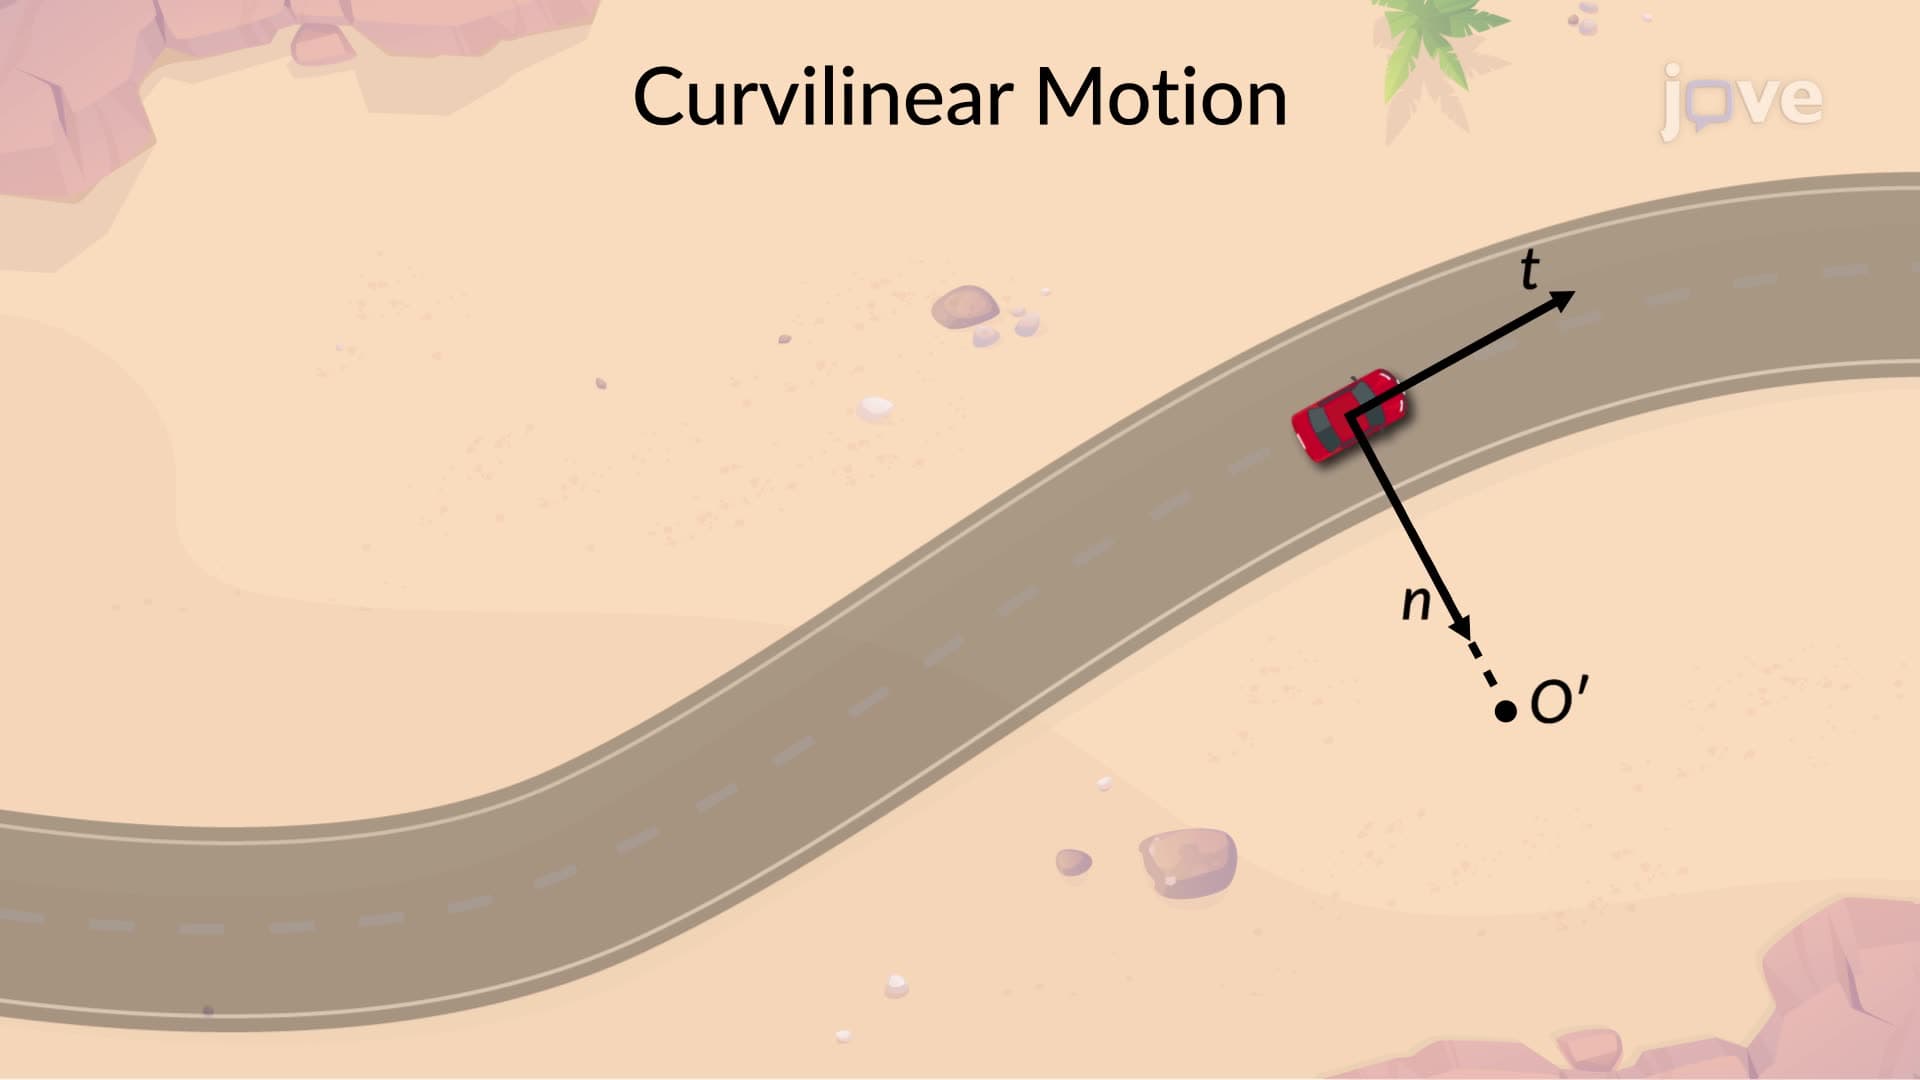
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:30
Parametric Surfaces