Realistic haptic rendering of interacting deformable objects in virtual environments
Related Experiment Video
Updated: Aug 14, 2026
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
Christian Duriez1, Frédéric Dubois, Abderrahmane Kheddar
1CIMIT Simulation Group, Cambridge, MA 02139, USA. christian.duriez@gmail.com

Abstract:
A new computer haptics algorithm to be used in general interactive manipulations of deformable virtual objects is presented. In multimodal interactive simulations, haptic feedback computation often comes from contact forces. Subsequently, the fidelity of haptic rendering depends significantly on contact space modeling. Contact and friction laws between deformable models are often simplified in up to date methods. They do not allow a "realistic" rendering of the subtleties of contact space physical phenomena (such as slip and stick effects due to friction or mechanical coupling between contacts). In this paper, we use Signorini's contact law and Coulomb's friction law as a computer haptics basis. Real-time performance is made possible thanks to a linearization of the behavior in the contact space, formulated as the so-called Delassus operator, and iteratively solved by a Gauss-Seidel type algorithm. Dynamic deformation uses corotational global formulation to obtain the Delassus operator in which the mass and stiffness ratio are dissociated from the simulation time step. This last point is crucial to keep stable haptic feedback. This global approach has been packaged, implemented, and tested. Stable and realistic 6D haptic feedback is demonstrated through a clipping task experiment.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:30
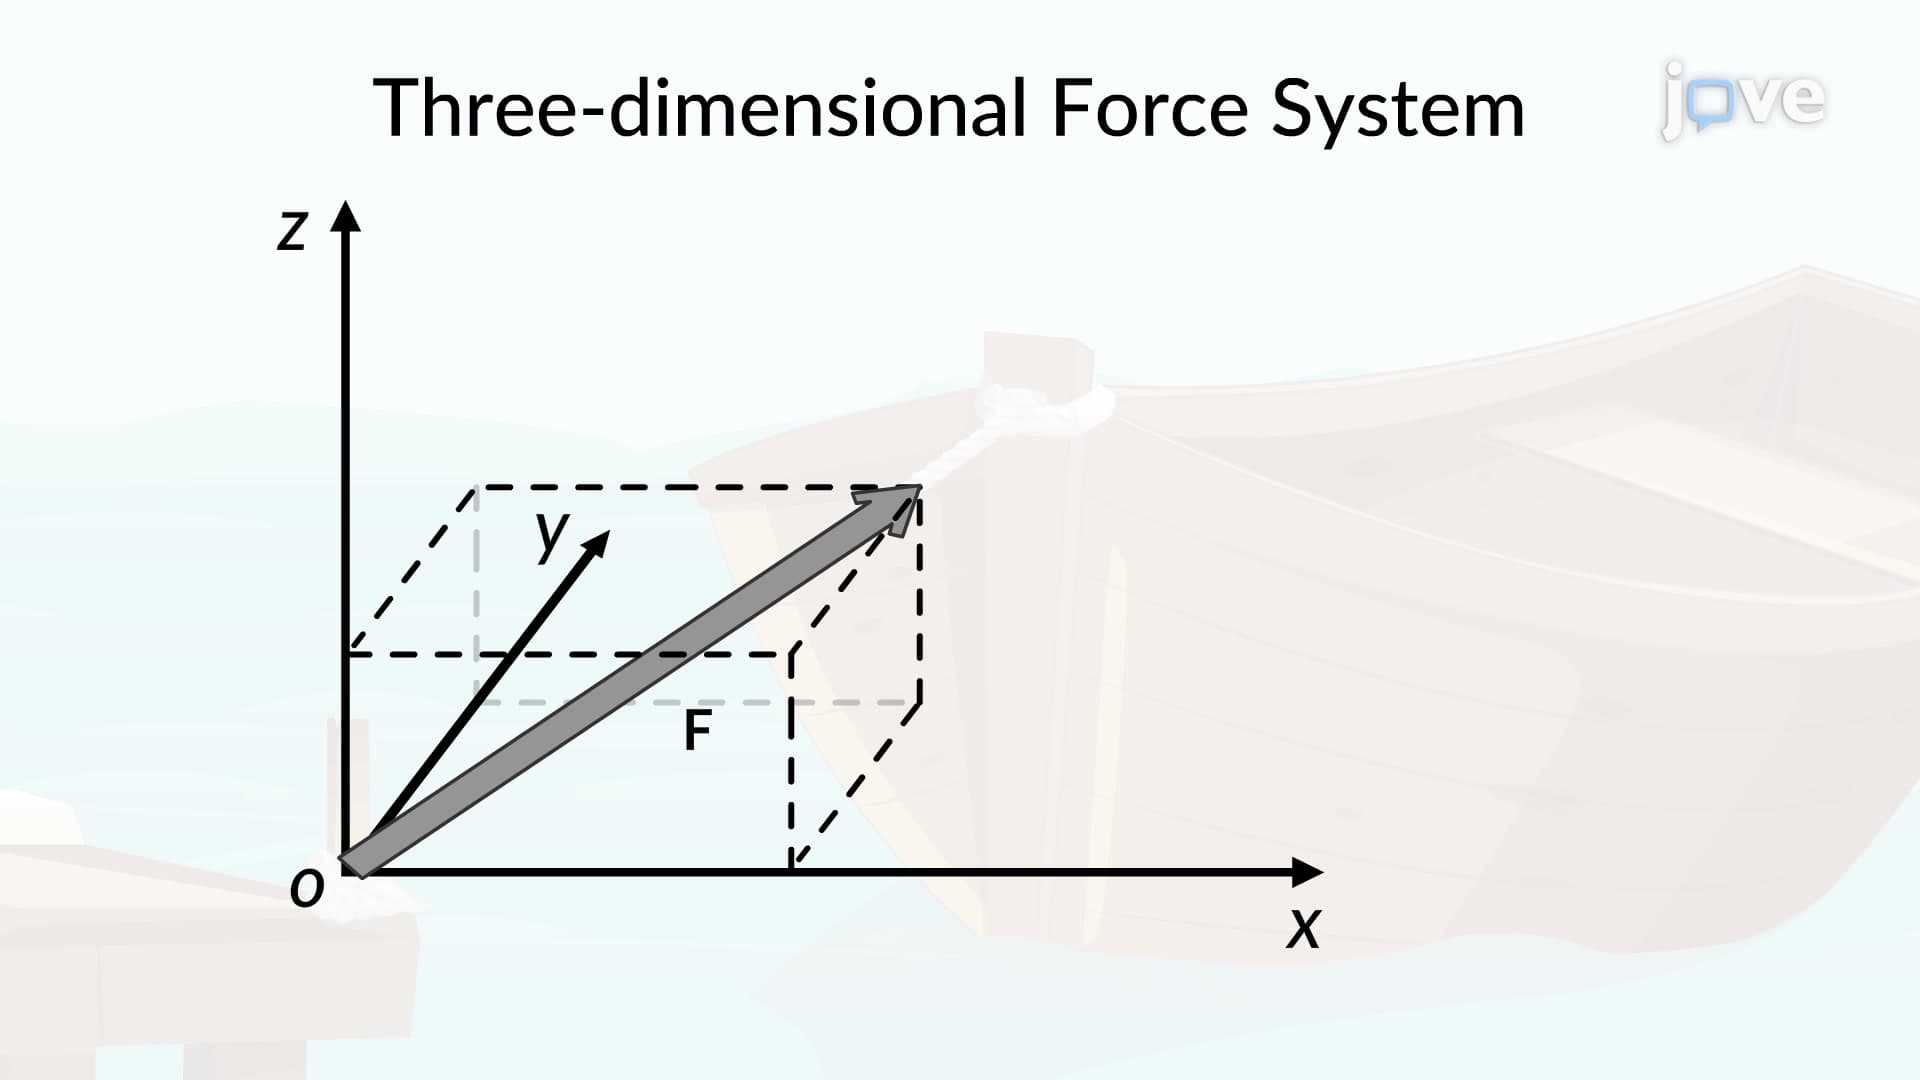
Three-Dimensional Force System
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:10
Deformation in a Circular Shaft
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?