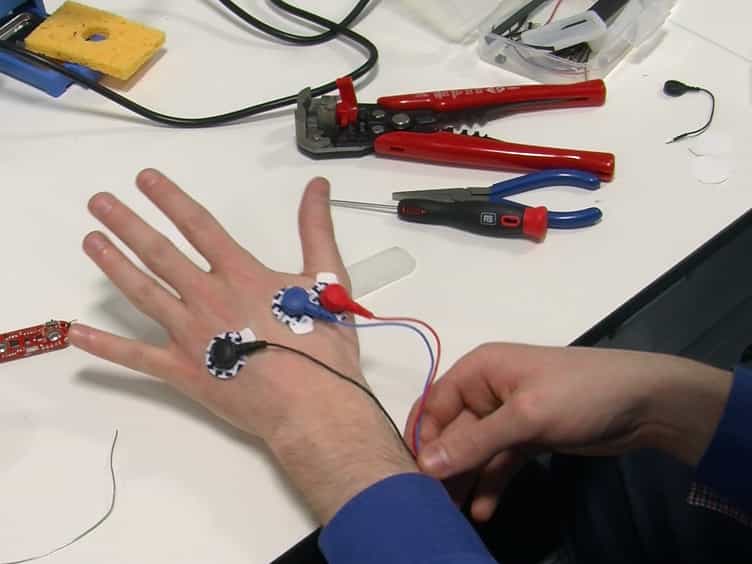
Related Experiment Video
Updated: Aug 13, 2026
Capturing Dynamic Finger Gesturing with High-resolution Surface Electromyography and Computer Vision
Published on: March 28, 2025
Myoelectric control of a computer animated hand: a new concept based on the combined use of a tree-structured
F Sebelius1, L Eriksson, C Balkenius
1Department of Electrical Measurements, Lund Institute of Technology, PO Box 118, SE-221 00, Lund, Sweden. fredrik.sebelius@elmat.lth.se

Abstract:
This paper proposes a new learning set-up in the field of control systems for multifunctional hand prostheses. Two male subjects with a traumatic one-hand amputation performed simultaneous symmetric movements with the healthy and the phantom hand. A data glove on the healthy hand was used as a reference to train the system to perform natural movements. Instead of a physical prosthesis with limited degrees of freedom, a virtual (computer-animated) hand was used as the target tool. Both subjects successfully performed seven different motoric actions with the fingers and wrist. To reduce the training time for the system, a tree-structured, self-organizing, artificial neural network was designed. The training time never exceeded 30 seconds for any of the configurations used, which is three to four times faster than most currently used artificial neural network (ANN) architectures.