Multibody grouping by inference of multiple subspaces from high-dimensional data using oriented-frames
Related Experiment Video
Updated: Jun 9, 2026

Basics of Multivariate Analysis in Neuroimaging Data
Published on: July 24, 2010
Zhimin Fan1, Jie Zhou, Ying Wu
1Department of Automation, Tsinghua University, Beijing, 100084, China. z-fan@northwestern.edu

Abstract:
Recently, subspace constraints have been widely exploited in many computer vision problems such as multibody grouping. Under linear projection models, feature points associated with multiple bodies reside in multiple subspaces. Most existing factorization-based algorithms can segment objects undergoing independent motions. However, intersections among the correlated motion subspaces will lead most previous factorization-based algorithms to erroneous segmentation. To overcome this limitation, in this paper, we formulate the problem of multibody grouping as inference of multiple subspaces from a high-dimensional data space. A novel and robust algorithm is proposed to capture the configuration of the multiple subspace structure and to find the segmentation of objects by clustering the feature points into these inferred subspaces, no matter whether they are independent or correlated. In the proposed method, an Oriented-Frame (OF), which is a multidimensional coordinate frame, is associated with each data point indicating the point's preferred subspace configuration. Based on the similarity between the subspaces, novel mechanisms of subspace evolution and voting are developed. By filtering the outliers due to their structural incompatibility, the subspace configurations will emerge. Compared with most existing factorization-based algorithms that cannot correctly segment correlated motions, such as motions of articulated objects, the proposed method has a robust performance in both independent and correlated motion segmentation. A number of controlled and real experiments show the effectiveness of the proposed method. However, the current approach does not deal with transparent motions and motion subspaces of different dimensions.

Related Concept Videos
 01:03
Inertial Frames of Reference
 01:27
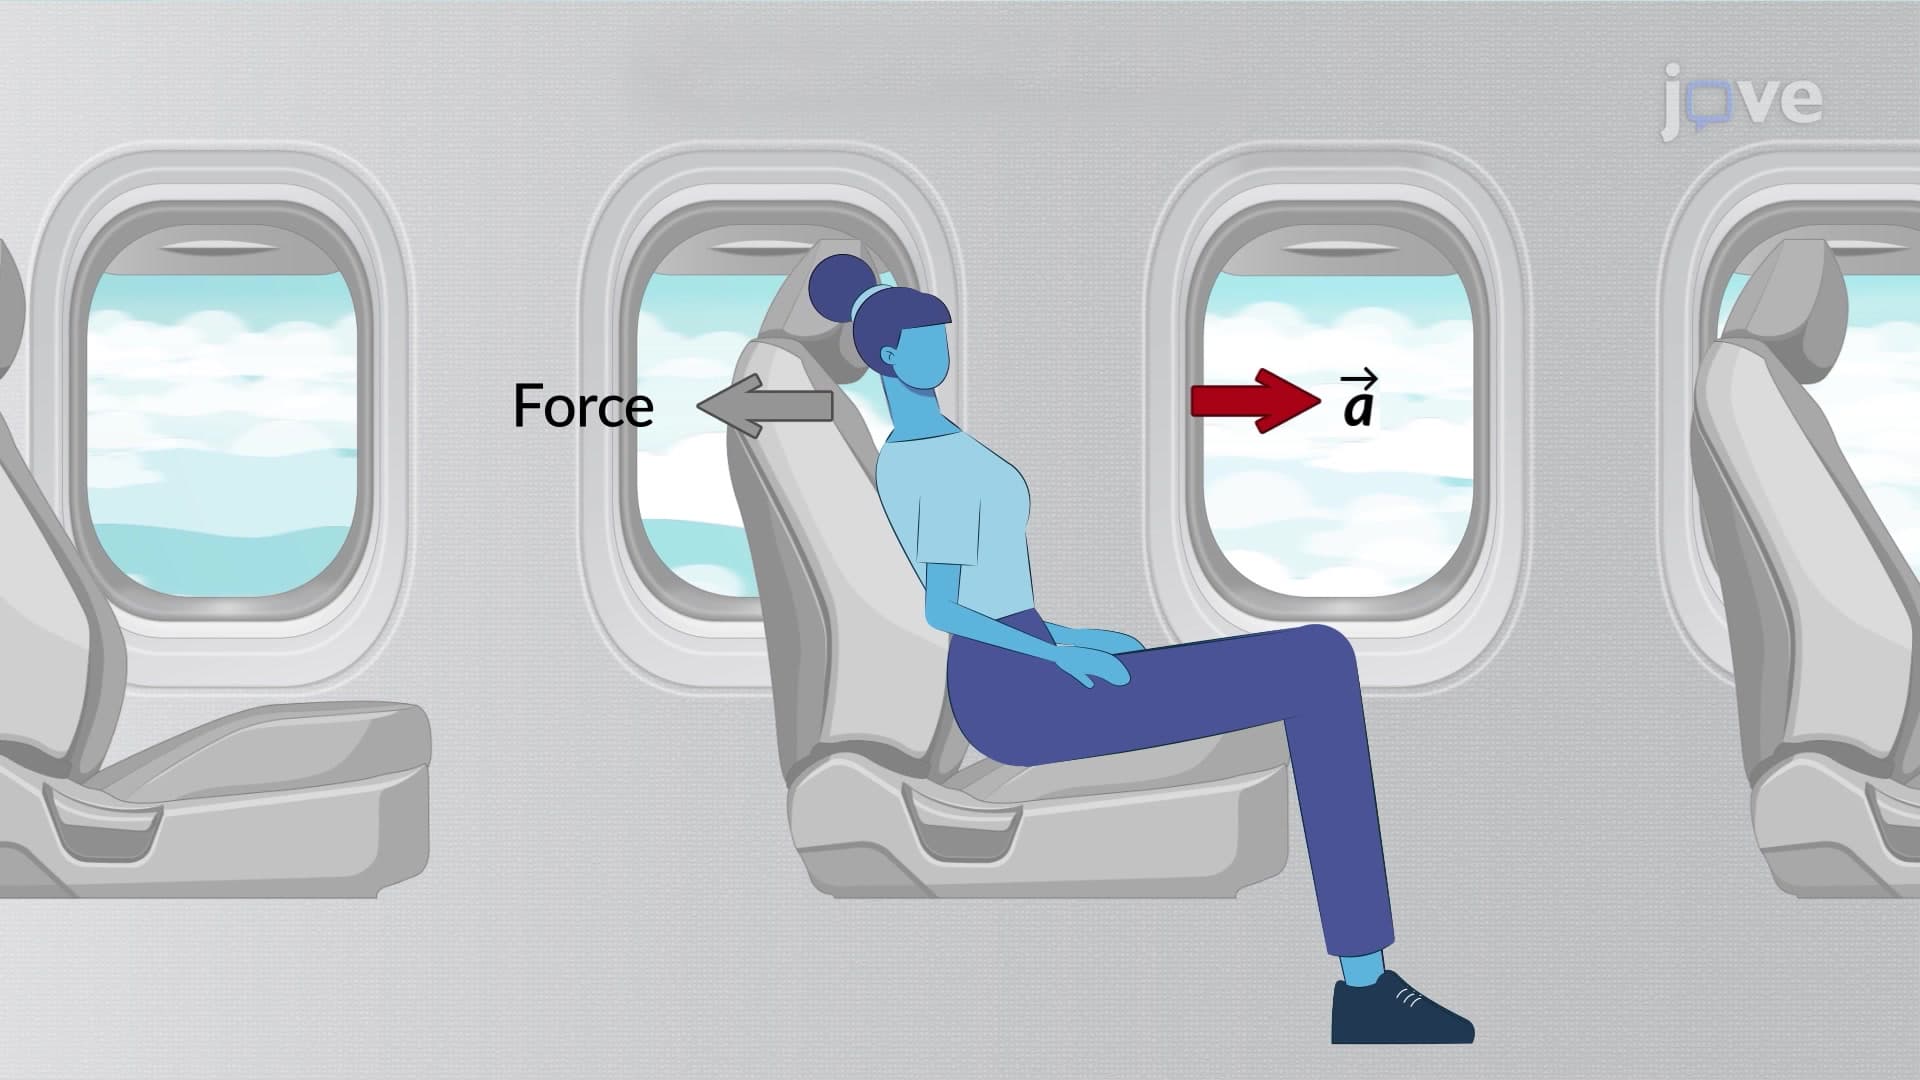
Non-inertial Frames of Reference
 01:05
Collisions in Multiple Dimensions: Introduction
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:28
Cylinders in Three-Dimensional Space
 01:30
Oriented Surfaces