Related Experiment Video
Updated: Aug 13, 2026

Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design of a torque-controlled manipulator to analyse the admittance of the wrist joint
Alfred C Schouten1, Erwin de Vlugt, J J Bob van Hilten
1Delft University of Technology, Department of Mechanical Engineering, Biomechanical Engineering, The Netherlands. a.c.schouten@3me.tudelft.nl

Abstract:
This paper describes the design of a torque-controlled manipulator to identify the dynamics of the wrist joint. With torque disturbances, the subject can actively control the joint angle, giving a natural task. The application of a hybrid haptic controller guarantees linearity over a large bandwidth and adjustable virtual dynamics. The haptic controller has a bandwidth of 50 Hz, meaning that the virtual dynamics are realistically felt at up to 50 Hz. To let the subject 'feel' the torque, disturbances as well as possible the apparent, or virtual, dynamics of the device must be small. The minimal apparent inertia of the device is 1.6 g m(2), which is of the same order as for a normal wrist, and the minimal damping and stiffness are negligible. To judge the accuracy of the manipulator, loads of known physical properties were attached and their parameters were quantified. The parameters of the loads were estimated with a maximum error of 5%. As the eigenfrequency of a (co)-contracted human wrist is approximately 15 Hz, the 50-Hz bandwidth of the haptic device is sufficient to measure all relevant dynamics of the human wrist. With this device, the dynamics of the human wrist joint can be measured under varying virtual dynamics, as well as the effect of neurological dysfunction on human motor control, for example.

Related Concept Videos
 01:19
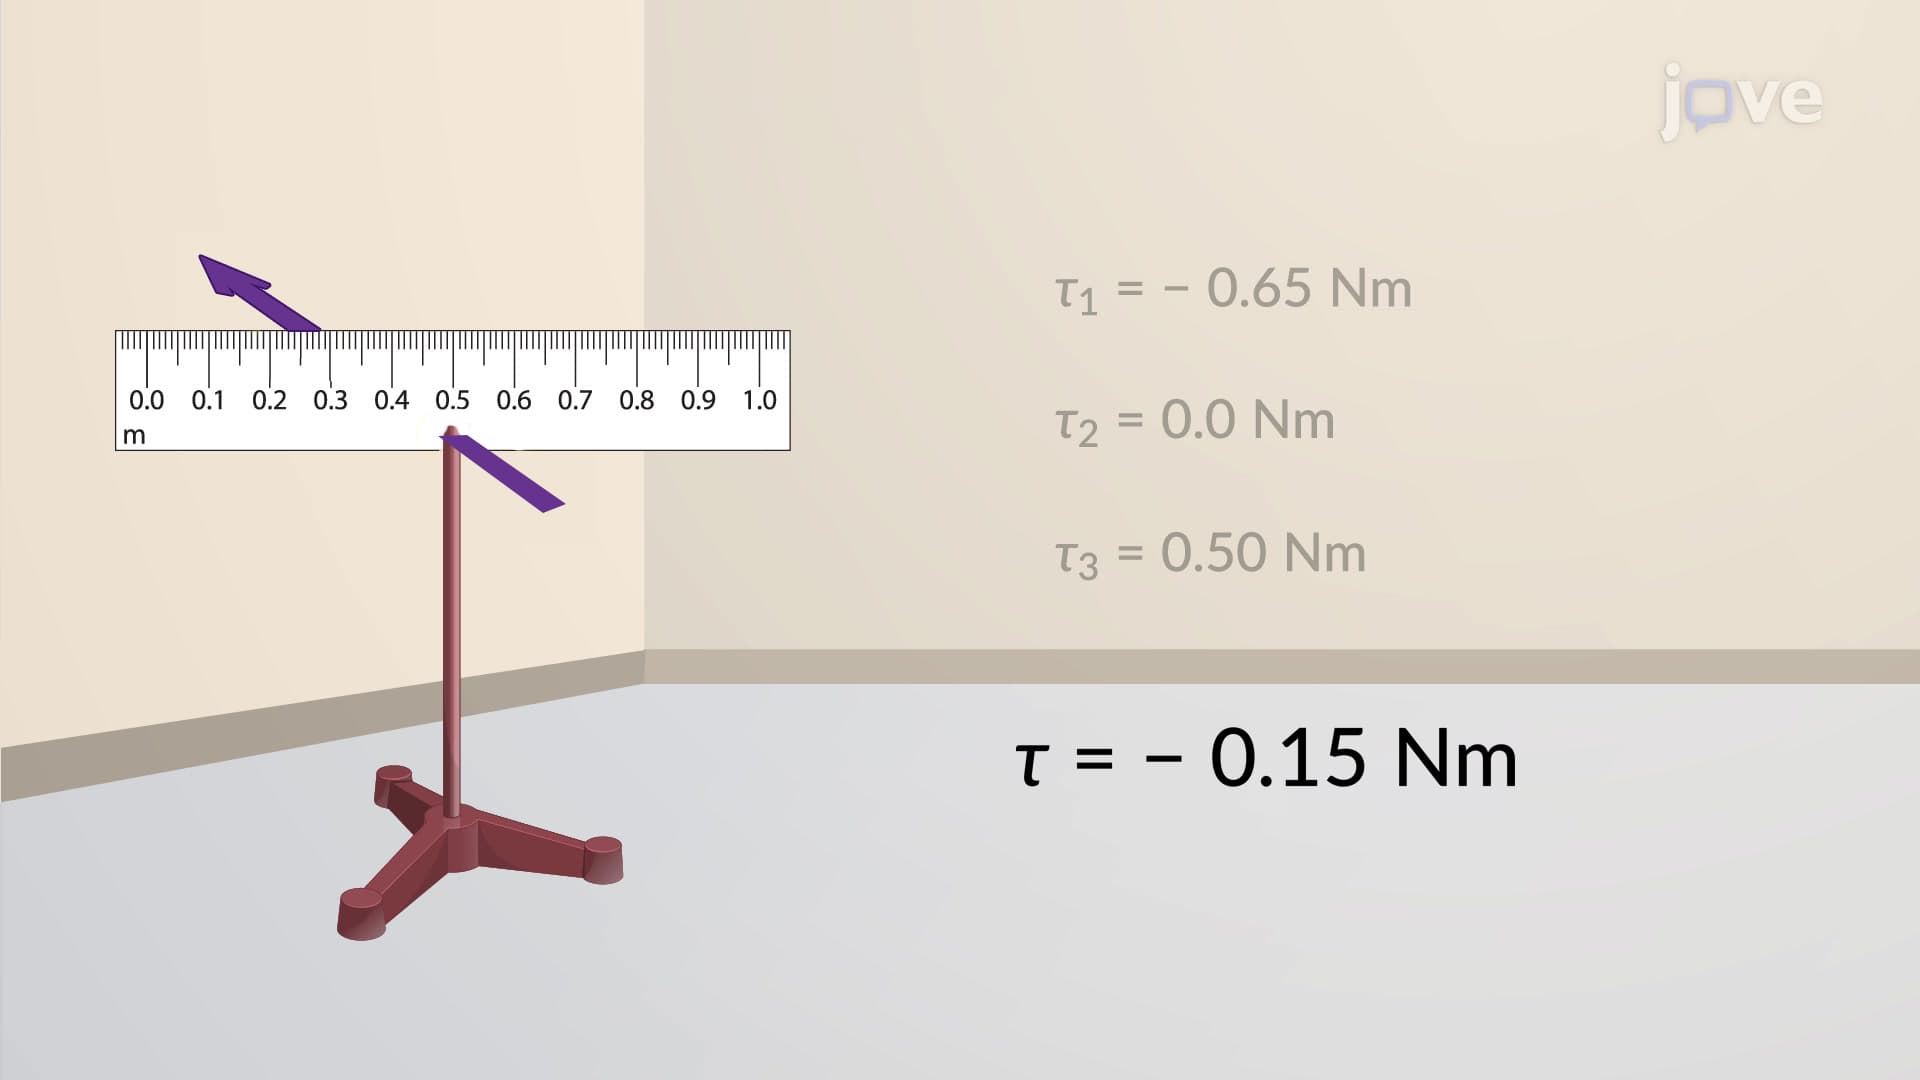
Net Torque Calculations
 01:10
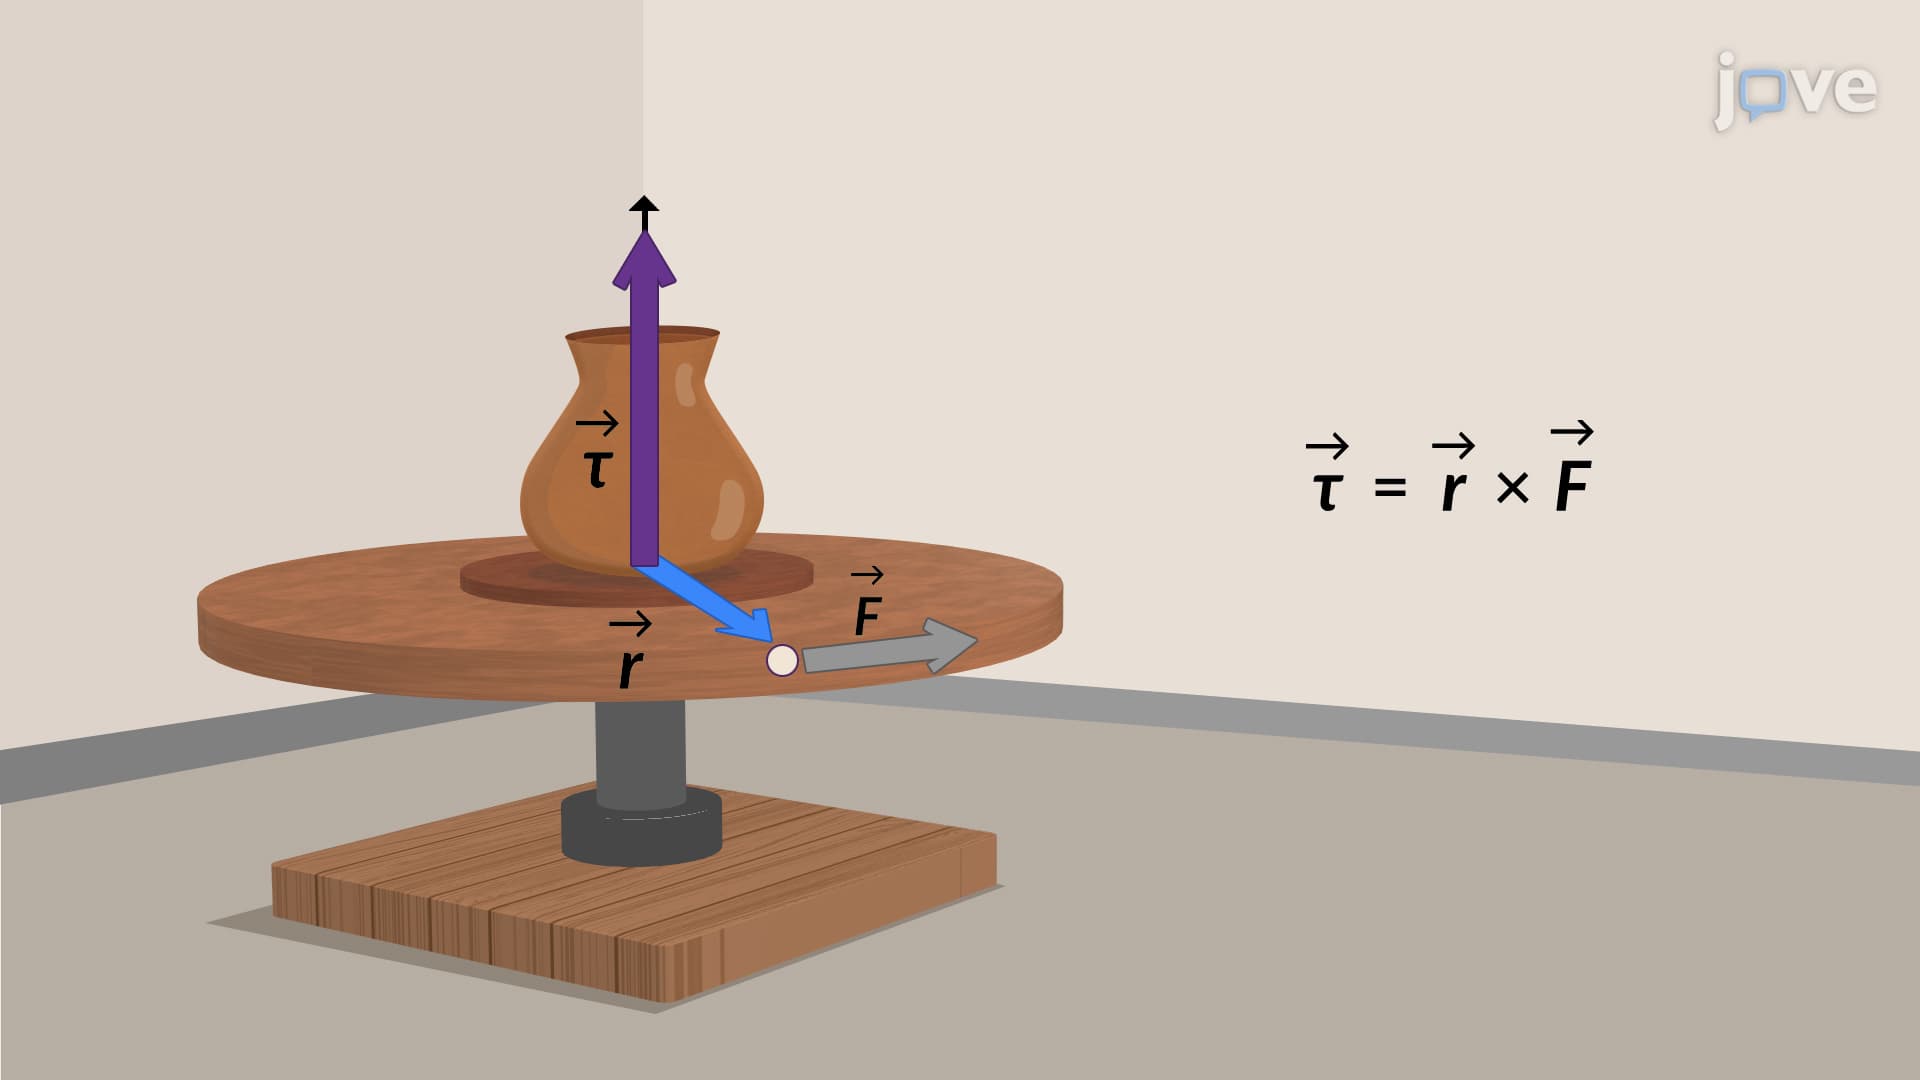
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:13
Angle of Twist: Problem Solving
 01:23
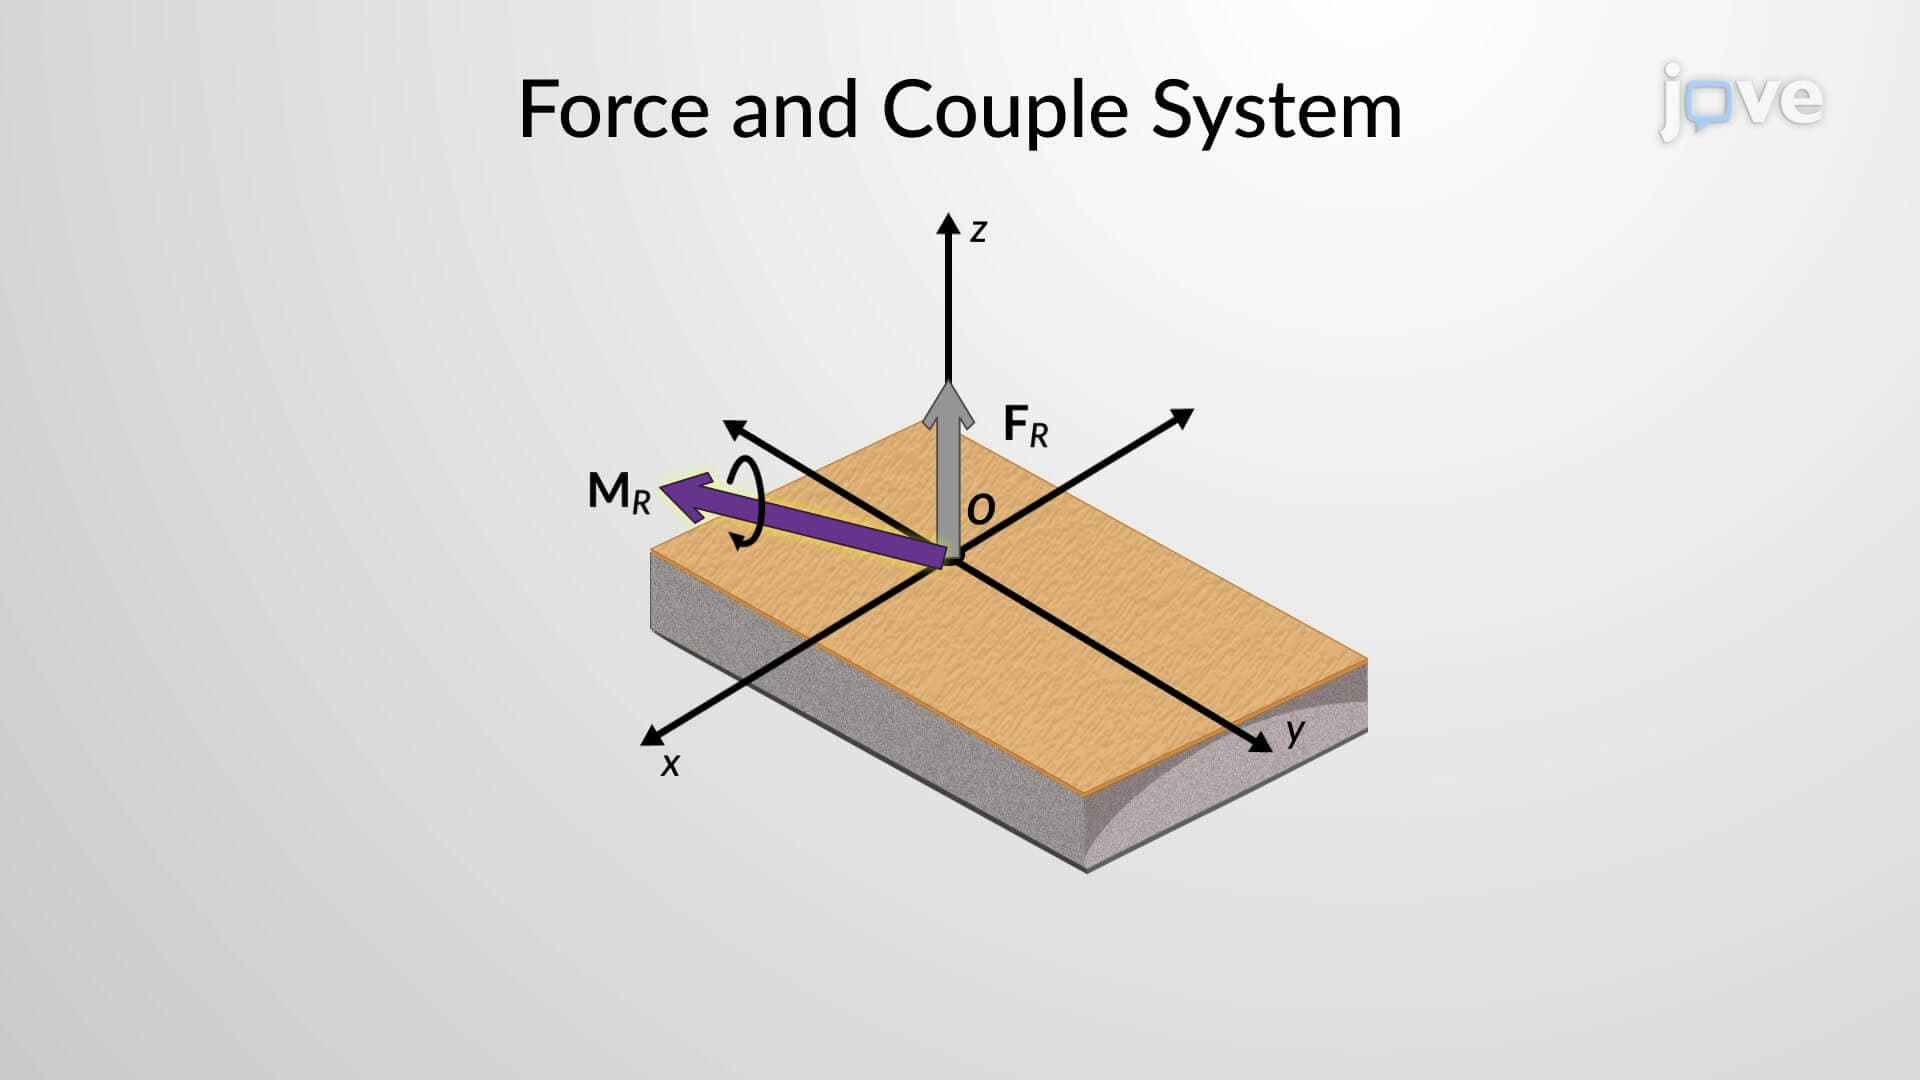
Simplification of a Force and Couple System: II
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:15
Torque Free Motion