Is equilibrium point control feasible for fast goal-directed single-joint movements?
Related Experiment Video
Updated: Aug 13, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Dinant A Kistemaker1, Arthur J Van Soest, Maarten F Bobbert
1Institute for Fundamental and Clinical Human Movement Sciences, Vrije Universiteit, van der Boechorststraat 9, 1081 BT Amsterdam, The Netherlands. d.kistemaker@fbw.vu.nl

Abstract:
Several types of equilibrium point (EP) controllers have been proposed for the control of posture and movement. EP controllers are appealing from a computational perspective because they do not require solving the "inverse dynamic problem" (i.e., computation of the torques required to move a system along a desired trajectory). It has been argued that EP controllers are not capable of controlling fast single-joint movements. To refute this statement, several extensions have been proposed, although these have been tested using models in which only the tendon compliance, force-length-velocity relation, and mechanical interaction between tendon and contractile element were not adequately represented. In the present study, fast elbow-joint movements were measured and an attempt was made to reproduce these using a realistic musculoskeletal model of the human arm. Three types of EP controllers were evaluated: an open-loop alpha-controller, a closed-loop lambda-controller, and a hybrid open- and closed-loop controller. For each controller we considered a continuous version and a version in which the control signals were sent out intermittently. Only the intermittent hybrid EP controller was capable of generating movements that were as fast as those of the subjects. As a result of the nonlinear muscle properties, the hybrid EP controller requires a more detailed representation of static muscle properties than generally assumed in the context of EP control. In sum, this study shows that fast single-joint movements can be realized without explicitly solving the inverse dynamics problem, but in a less straightforward manner than implied by proponents of conventional EP controllers.


Related Concept Videos
 00:49
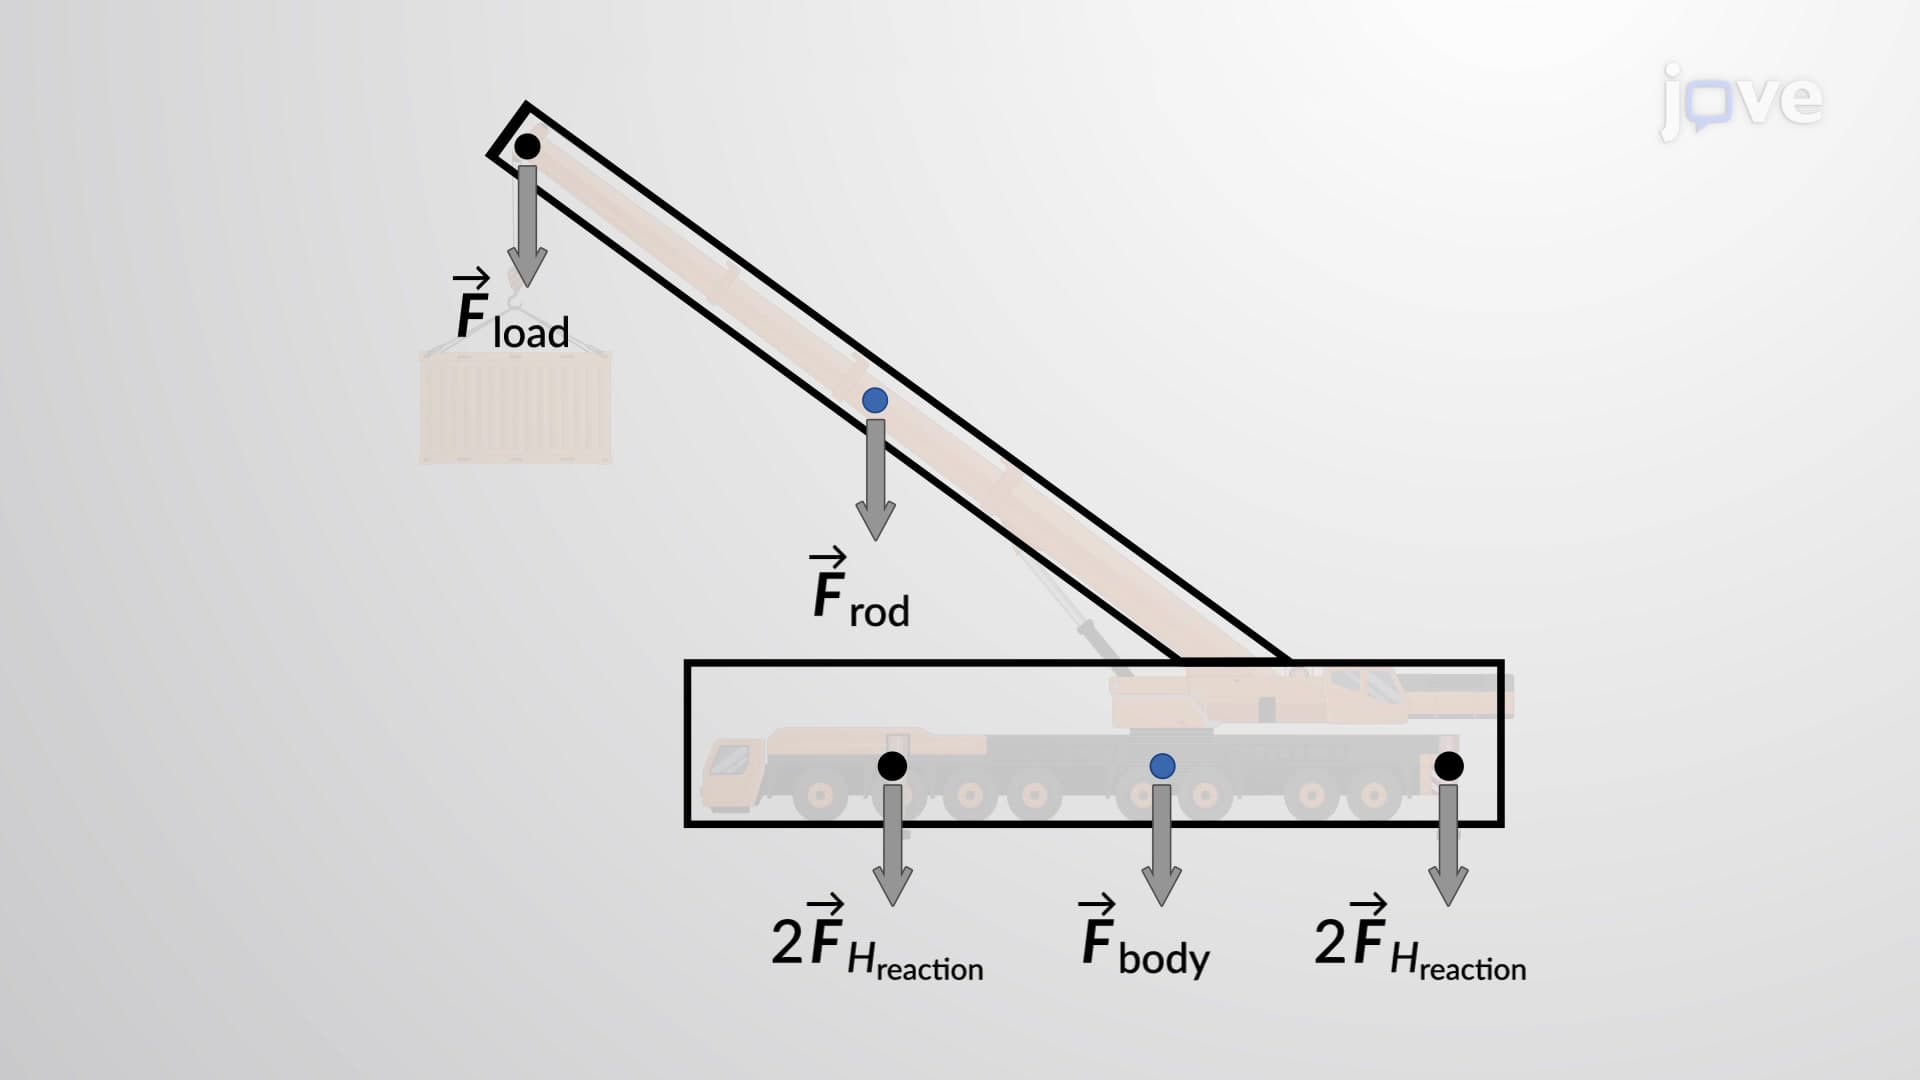
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:15
Kinematic Equations: Problem Solving
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
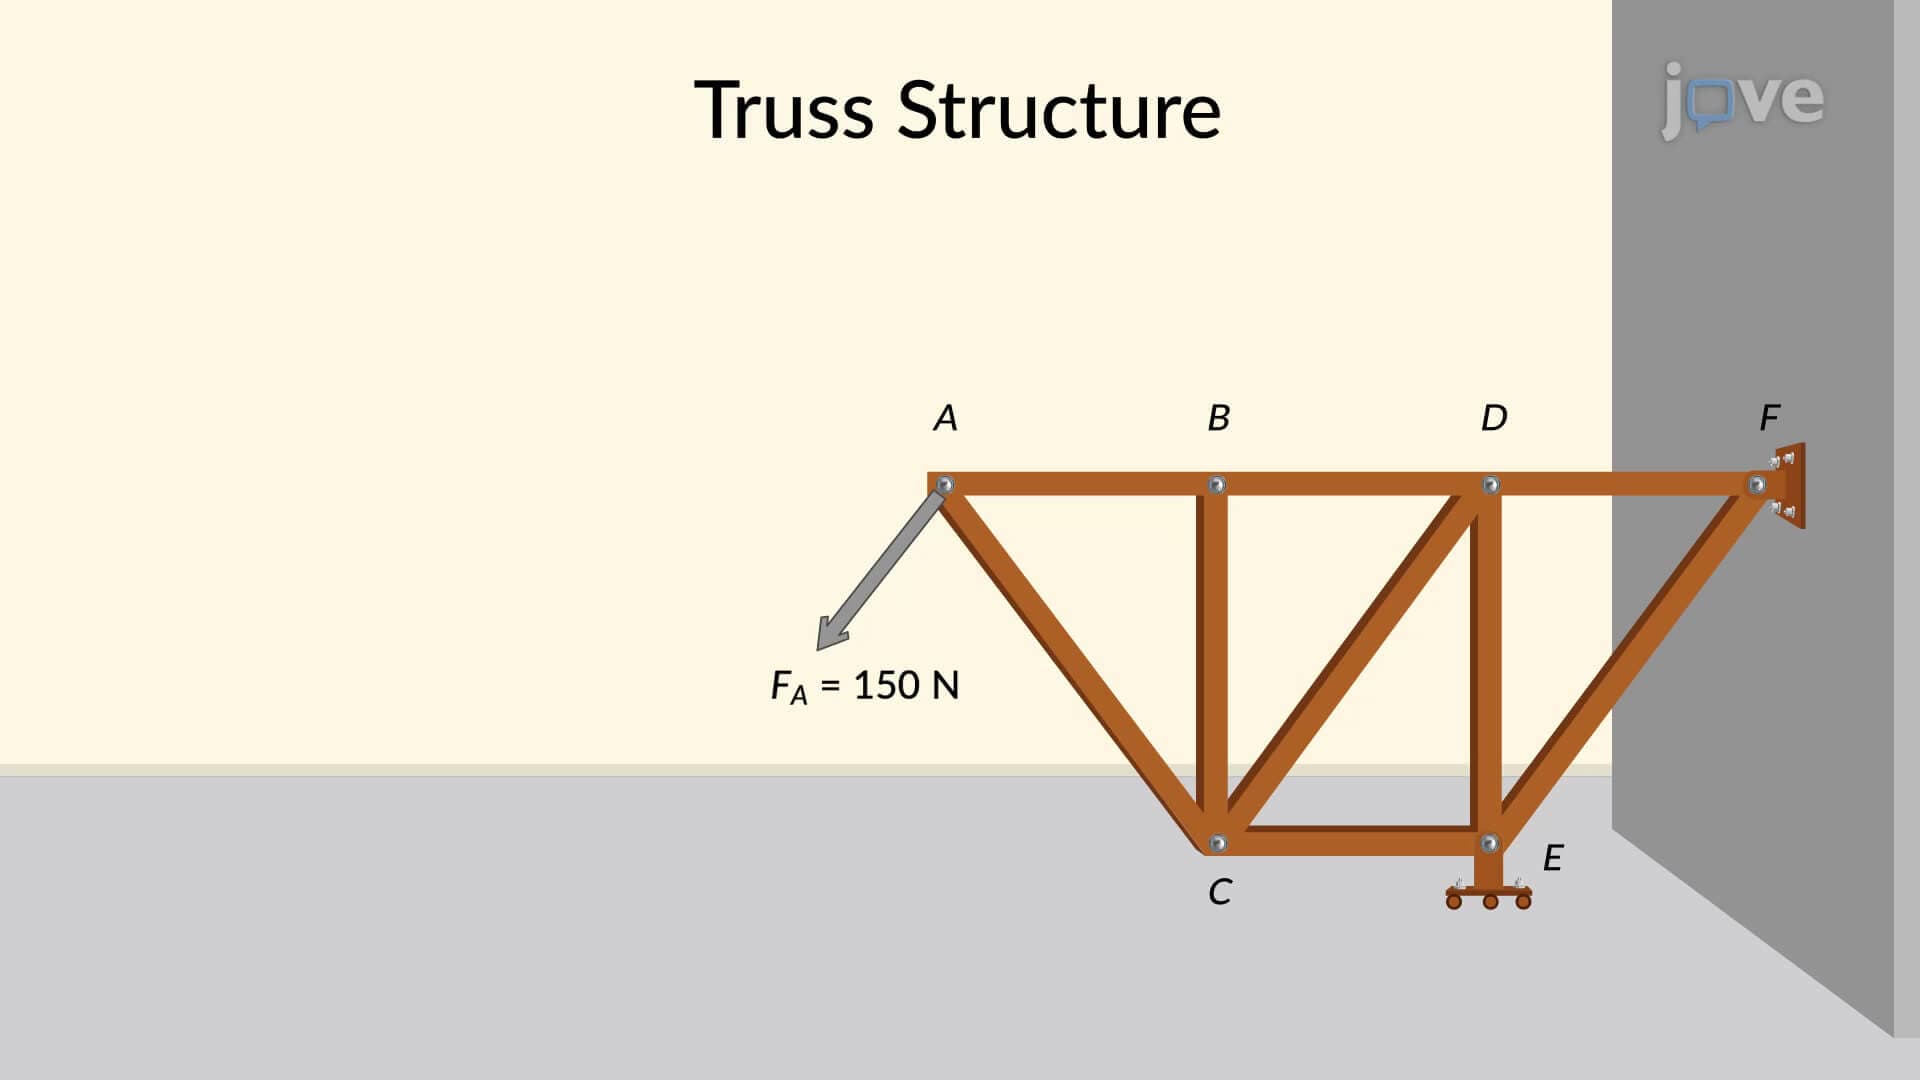
Method of Joints: Problem Solving II