Related Experiment Video
Updated: Aug 13, 2026
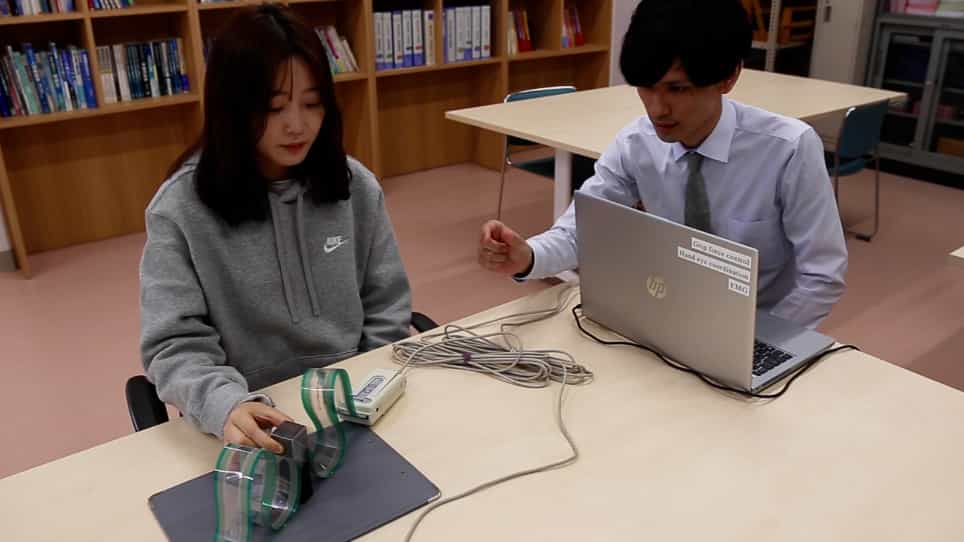
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Predictive control of grip force when moving object with an elastic load applied on the arm
Médéric Descoins1, Frédéric Danion, Reinoud J Bootsma
1UMR 6152 Mouvement et Perception, Université de la Méditerranée, CNRS, Faculté des Sciences du Sport, 163 Avenue de Luminy, 13288 Marseille Cedex 09, France.

Abstract:
Skilled object manipulation relies on the capability to adjust the grip force according to the consequences of our movements in terms of the resulting load force of the object. Such predictive grip force control requires (at least) two neural processes: (1) predicting the kinematic characteristics of the unfolding arm trajectory and (2) predicting the load force on the object resulting, among other factors, from the arm movement. The goal of this study was to examine whether subjects can still anticipate the resulting load force on the object when the moving arm is submitted to a type of load that does not contribute to the object load. To this end, 12 subjects were asked to rhythmically move a 0.4 kg object under three different conditions. In the first condition (ARM), an elastic cord was attached to the upper arm. In the second condition, the elastic cord was attached to the object (OBJECT). In the third condition, the elastic cord was absent (NO ELAST). At the kinematic level, results showed no influence of the elastic cord on the pattern of movement of the object. At the kinetic level, cross-correlation analyses between grip force and load force acting on the object revealed significant correlations with minimal delays. In addition, grip force profiles were similar under the ARM and NO ELAST conditions, both differing from the OBJECT condition. Overall, we interpret these results as evidence that the neural processes involved in the prediction of the arm trajectory and those involved in the prediction of the load on the object held can take into account different external force fields, thereby preserving the functionality of the behaviour.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
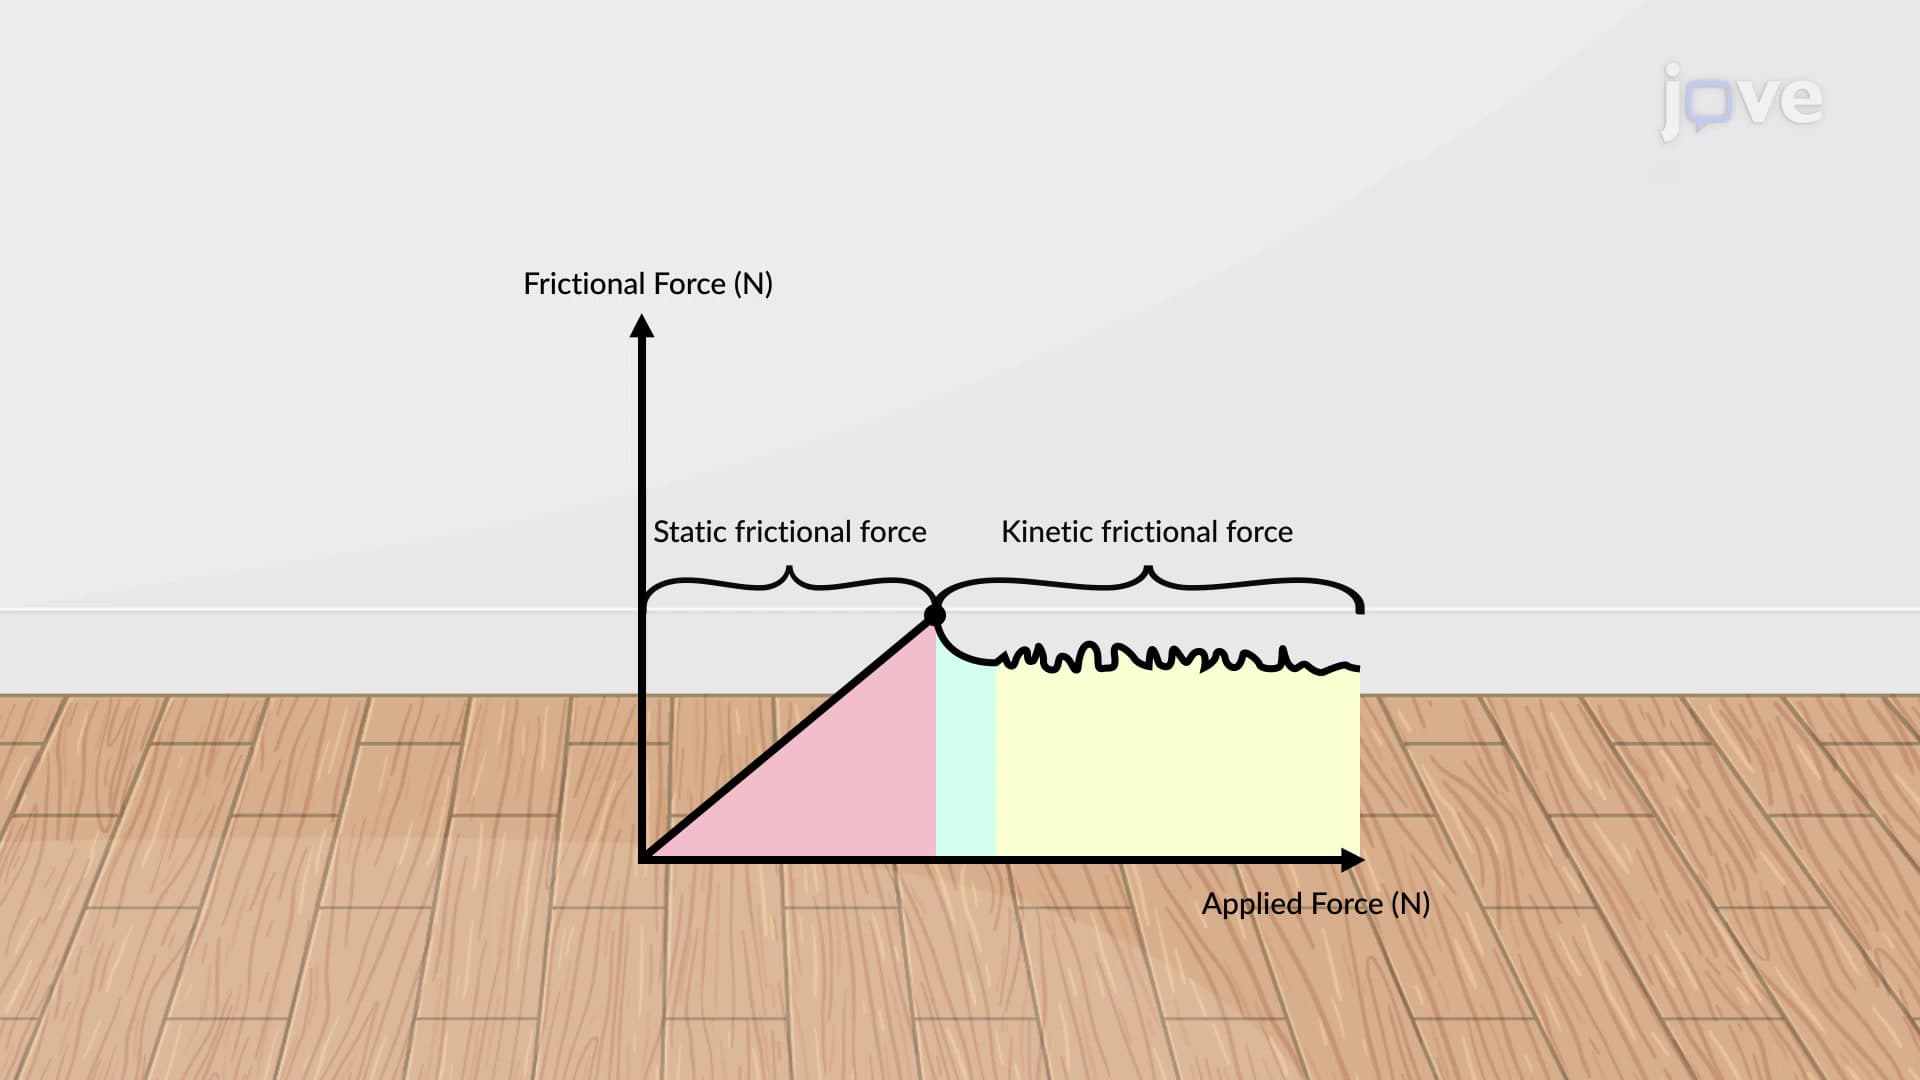 01:05
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:21
Upward Impending Motion
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...
 00:57
Power Expended by a Constant Force
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...