Related Experiment Video
Updated: Aug 11, 2026
Uncoupling Coriolis Force and Rotating Buoyancy Effects on Full-Field Heat Transfer Properties of a Rotating Channel
Published on: October 5, 2018
An extended hindered-rotor model with incorporation of Coriolis and vibrational-rotational coupling for calculating
P Vansteenkiste1, D Van Neck, V Van Speybroeck
1Laboratory of Theoretical Physics, Center for Molecular Modeling, Ghent University, Proeftuinstraat 86, B-9000 Gent, Belgium. peter.vansteenkiste@ugent.be

Abstract:
Large-amplitude motions, particularly internal rotations, are known to affect substantially thermodynamic functions and rate constants of reactions in which flexible molecules are involved. Up to now all methods for computing the partition functions of these motions rely on the Pitzer approximation of more than 50 years ago, in which the large-amplitude motion is treated in complete independence of the other (vibrational) degrees of freedom. In this paper an extended hindered-rotor model (EHR) is developed in which the vibrational modes, treated harmonically, are correctly separated from the large-amplitude motion and in which relaxation effects (the changes in the kinetic-energy matrix and potential curvature) are taken into account as one moves along the large-amplitude path. The model also relies on a specific coordinate system in which the Coriolis terms vanish at all times in the Hamiltonian. In this way an increased level of consistency between the various internal modes is achieved, as compared with the more usual hindered-rotor (HR) description. The method is illustrated by calculating the entropies and heat capacities on 1,3-butadiene and 1-butene (with, respectively, one and two internal rotors) and the rate constant for the addition reaction of a vinyl radical to ethene. We also discuss various variants of the one-dimensional hindered-rotor scheme existing in the literature and its relation with the EHR model. It is argued why in most cases the HR approach is already quite successful.
Related Concept Videos
 01:08
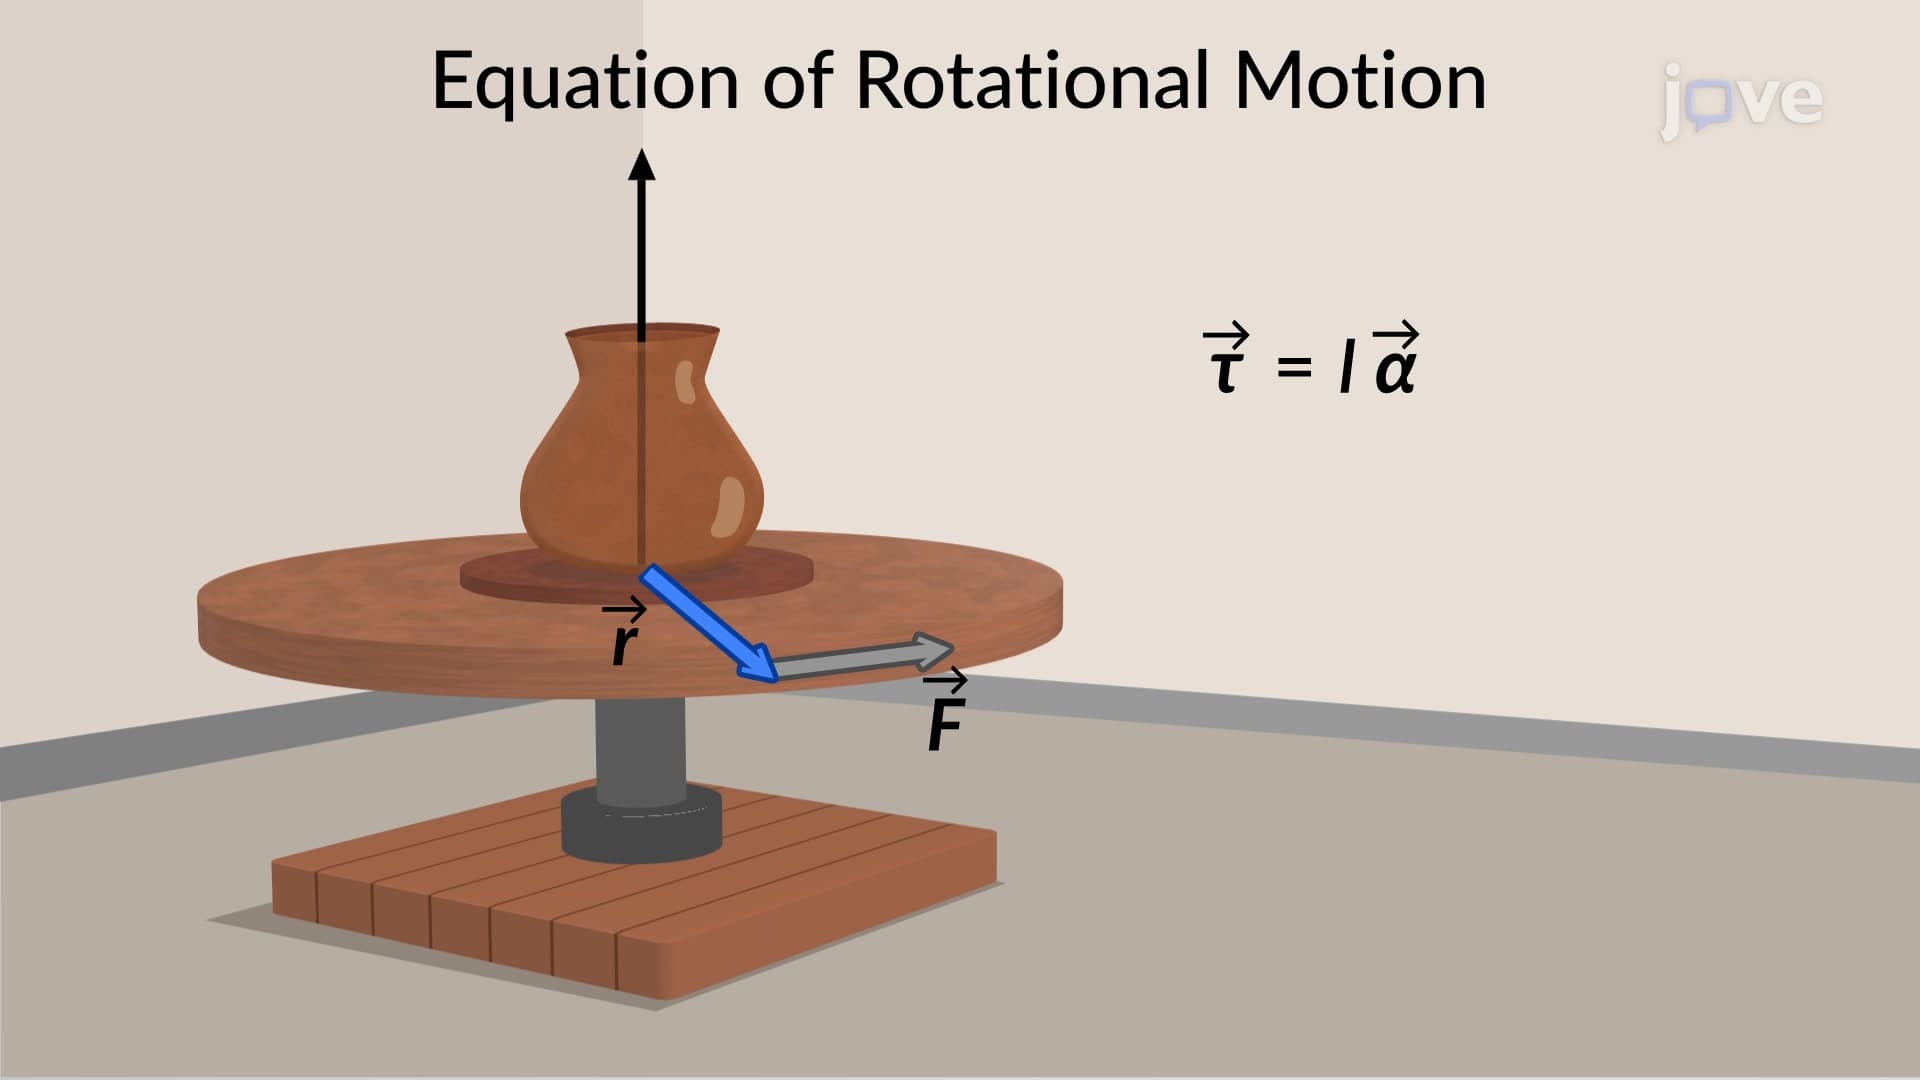
Equation of Rotational Dynamics
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:26
Rotational Motion about a Fixed Axis
 01:19
Euler Equations of Motion
 01:27
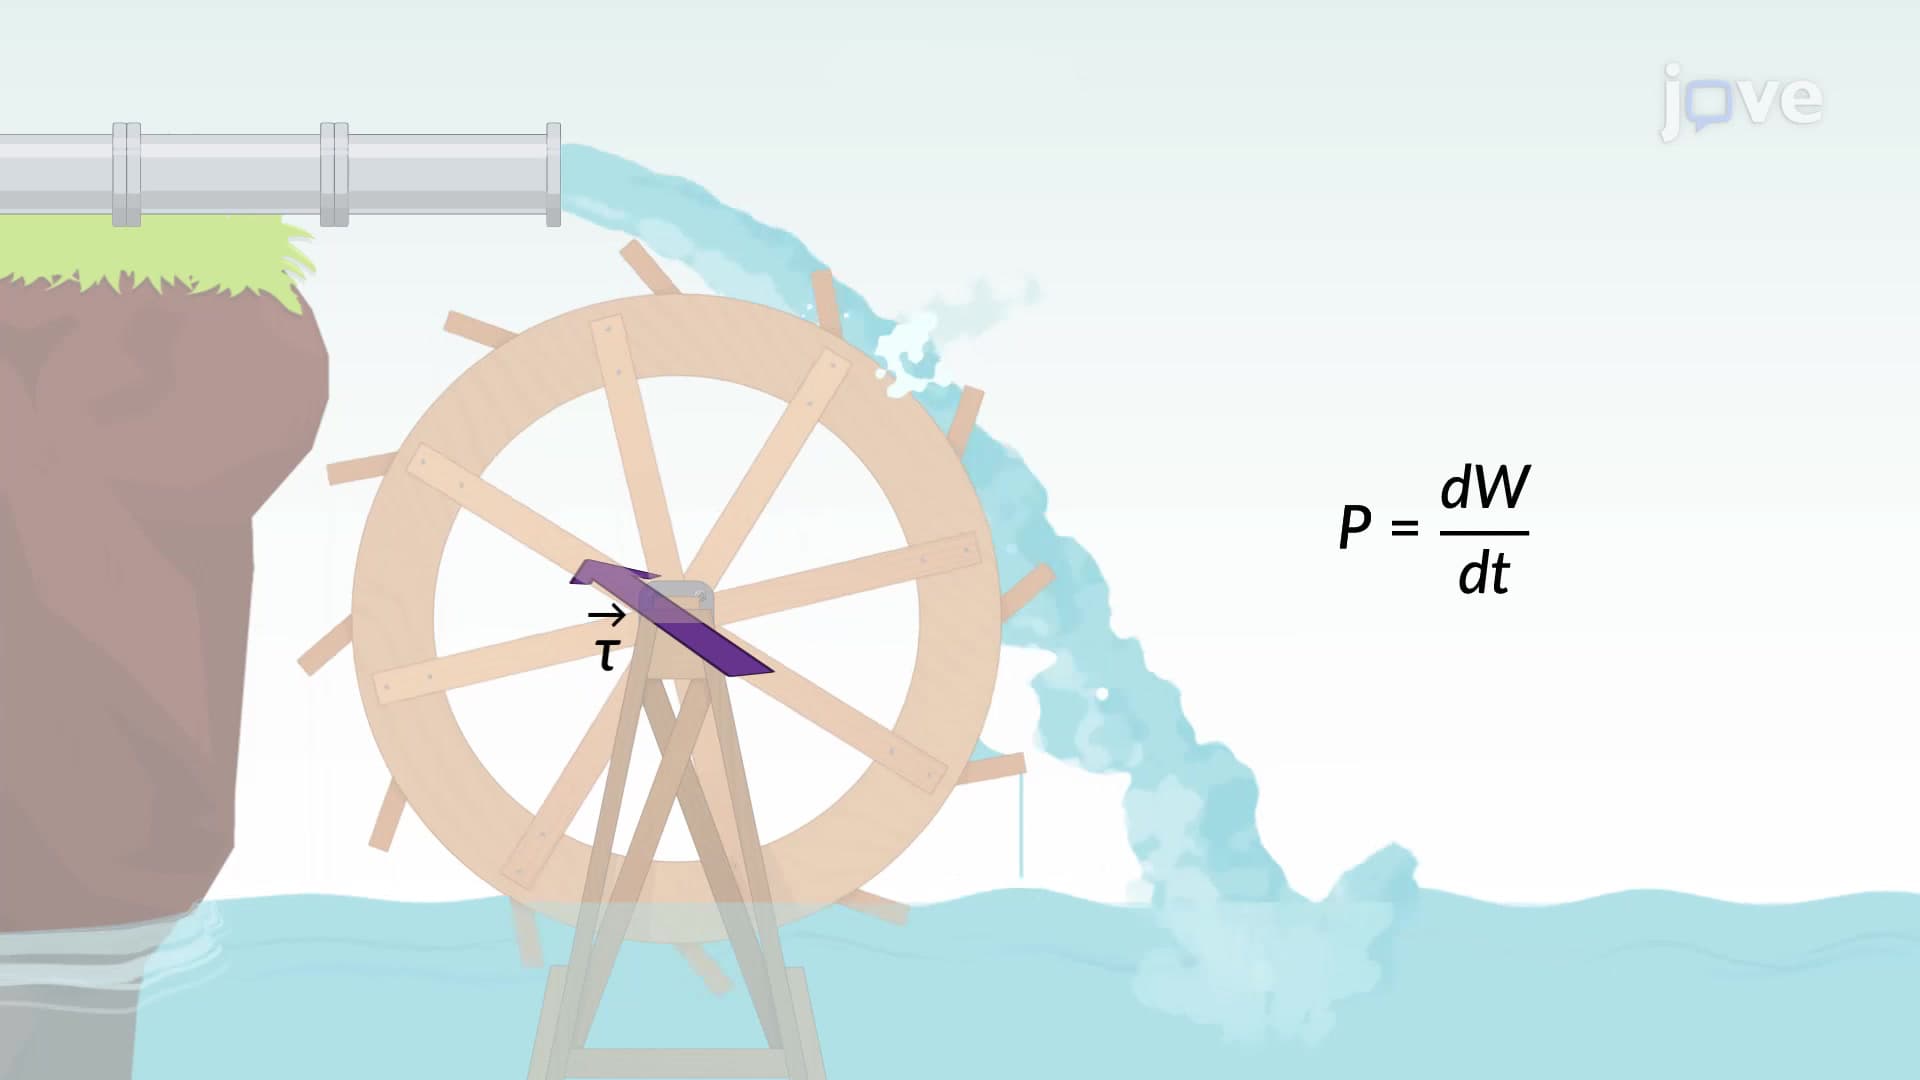
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis is given by the...
 00:52
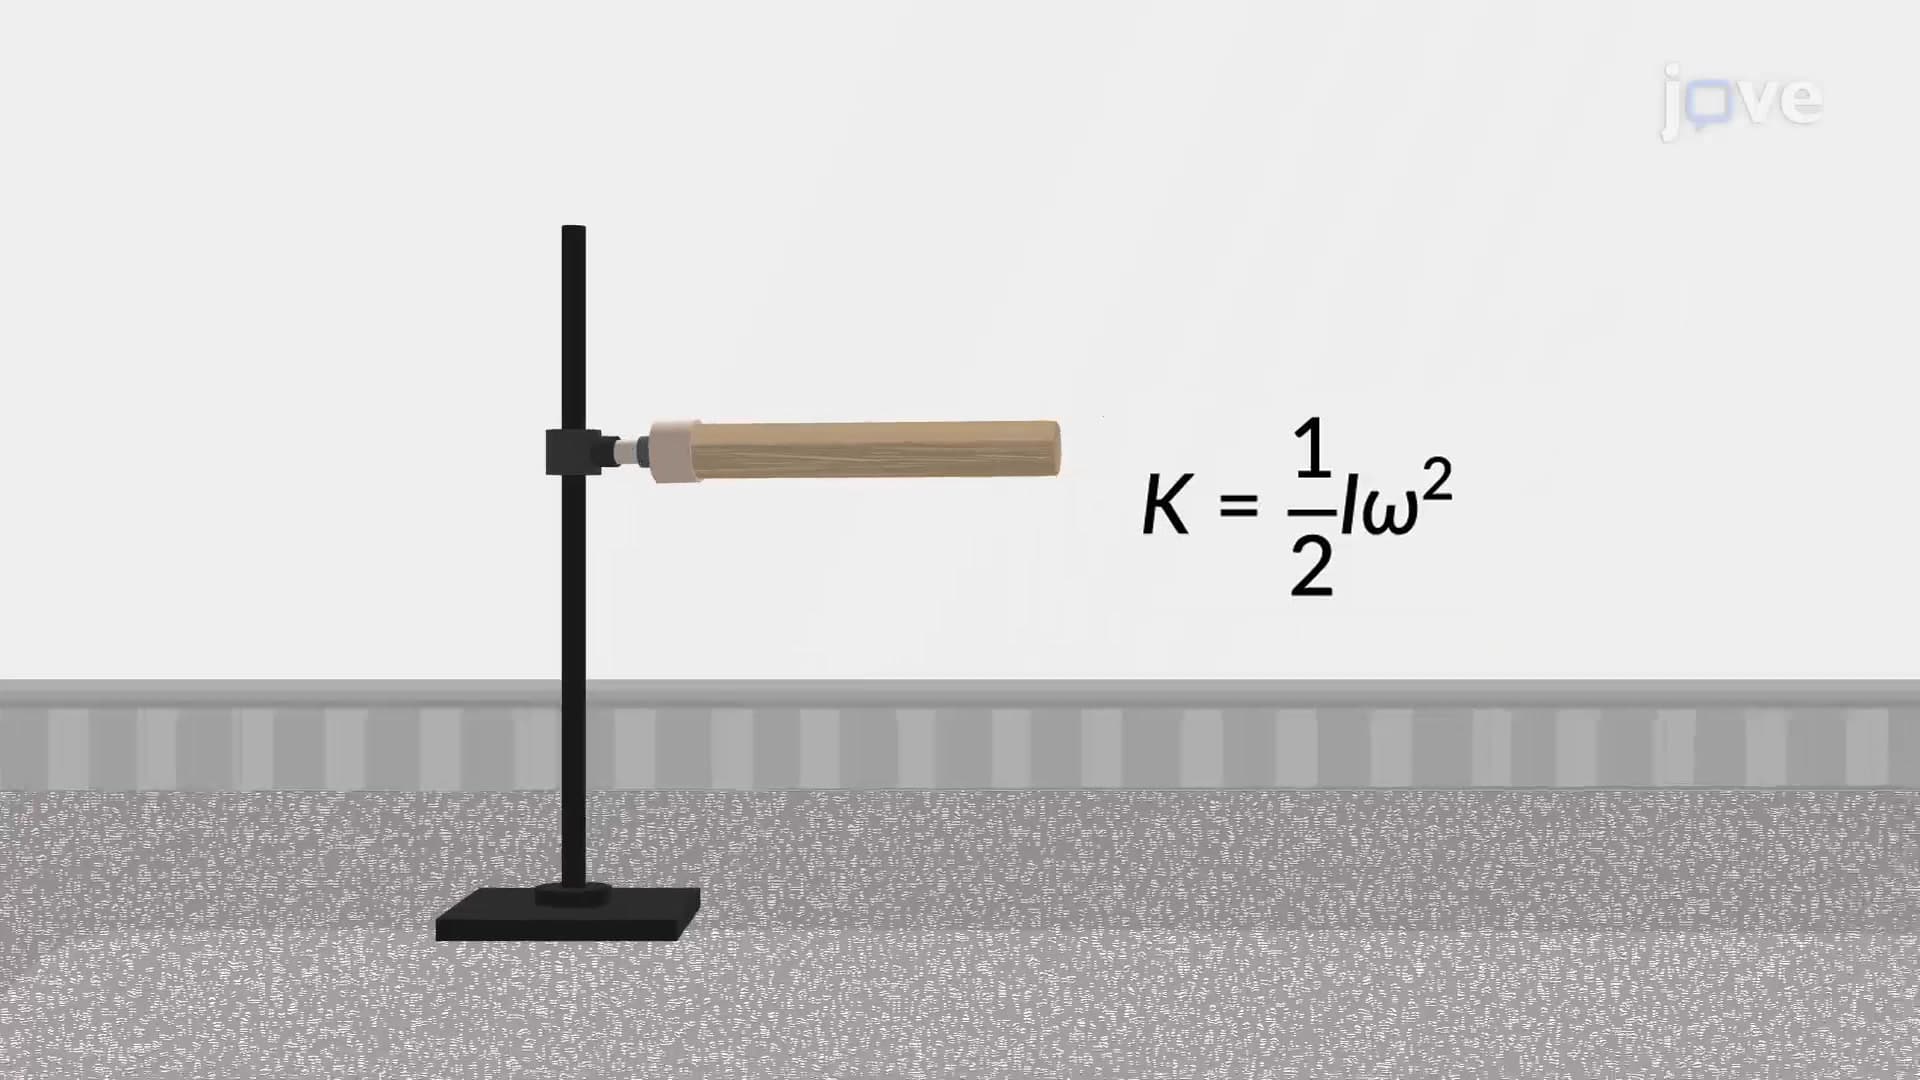
Moment of Inertia and Rotational Kinetic Energy
This relationship between the rotational kinetic energy of a body and its angular speed implies that for the same angular speed, the rotational kinetic energy is greater if its moment of inertia is greater. Thus, more work needs to be done on the body to change its rotational kinetic energy and rotate it at a specific angular speed. Hence, the moment of inertia quantifies the...