Related Experiment Videos
Robust and nominal stability conditions for a simplified model predictive controller
Jonathan R Webber1, Yash P Gupta
1Department of Chemical Engineering, Dalhousie University, Halifax, Nova Scotia, Canada.

Abstract:
A new condition is derived that guarantees robust stability for a set of stable, linear time-invariant plants controlled by using a simplified model predictive control algorithm (SMPC). Discrete single-input-single-output control systems are considered in this paper. Uncertainty is treated in the time domain by considering the stabilization of a set of pulse response functions. The method presented is suitable for stabilizing a set of plants that are not necessarily related. Central to this method is a bounding function, which is a function of the model and controller parameters. The bounding function is designed to have a larger magnitude than all of the pulse response functions in the set of plants to be stabilized. Using this method, it was found that the bounding function is monotonically decreasing when a first-order plus dead-time model is used to design the controller. This allows the coincidence point used in SMPC to be employed directly as a tuning "knob" for robustness, and also simplifies the analysis for dead-time uncertainty. In addition, a comparison of two nominal stability conditions is provided.
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:19
Routh-Hurwitz Criterion II
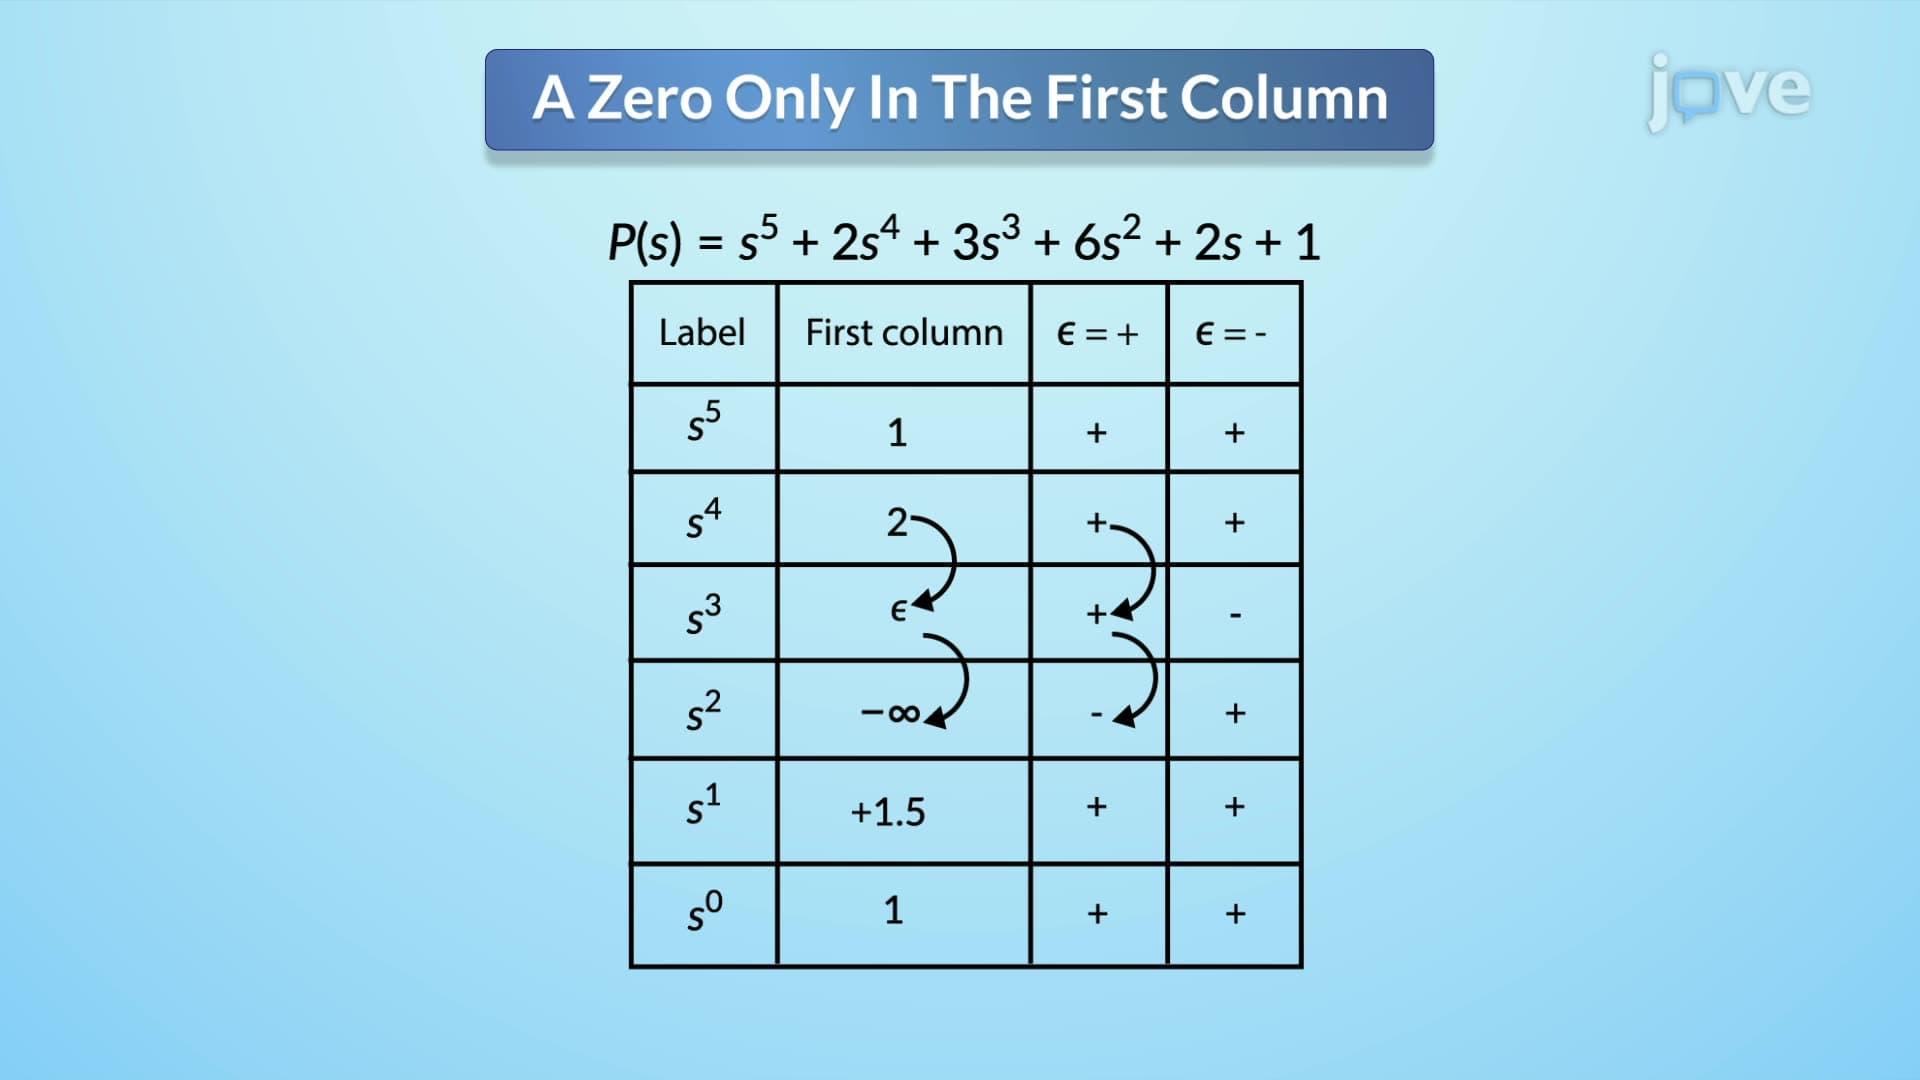
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...