Related Experiment Video
Updated: Jul 31, 2026


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Multijoint control strategies transfer between tasks
J L McNitt-Gray1, Philip S Requejo, Henryk Flashner
1Biomechanics Research Laboratory, University of Southern California, Los Angeles, CA 90089-0652, USA. mcnitt@usc.edu

Abstract:
In this paper, the hypothesis that multijoint control strategies are transferred between similar tasks was tested. To test this hypothesis, we studied the take-off phase of two types of backward somersault dives: one while translating backwards (Back), the other while translating forward (Reverse). An experimentally based dynamic model of the musculoskeletal system was employed to simulate the measured kinematics and reaction force data and to study the sensitivity of take-off performance to initial kinematic conditions. It was found that the horizontal velocity of the total body center of mass (CM) was most sensitive to modifications in the initial shank conditions. Consequently, the initial shank kinematics of the Back dive was modified in the optimization procedure while maintaining the joint coordination of the Back in order to generate the CM trajectory and reaction forces of a Reverse. Similarly, the initial shank kinematics of the Reverse dive was modified to simulate the CM trajectory and reaction force of the Back. It was found that small modifications in the initial shank kinematics led to change in direction of horizontal CM velocity at take-off; resulting in a switch from Back to Reverse and vice versa. In both cases, the simulated momentum conditions at departure and the bimodal shape of the reaction force-time curve were consistent with those experimentally observed. The results of this study support the hypothesis that transfer of control strategies between similar tasks is a viable option in multijoint control. This transfer of control strategy is explained using a hierarchical model of the motion control system.
Related Concept Videos
 01:30
Method of Joints: Problem Solving I
 01:30
Method of Joints: Problem Solving II
 01:18
Hierarchy of Motor Control
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:21
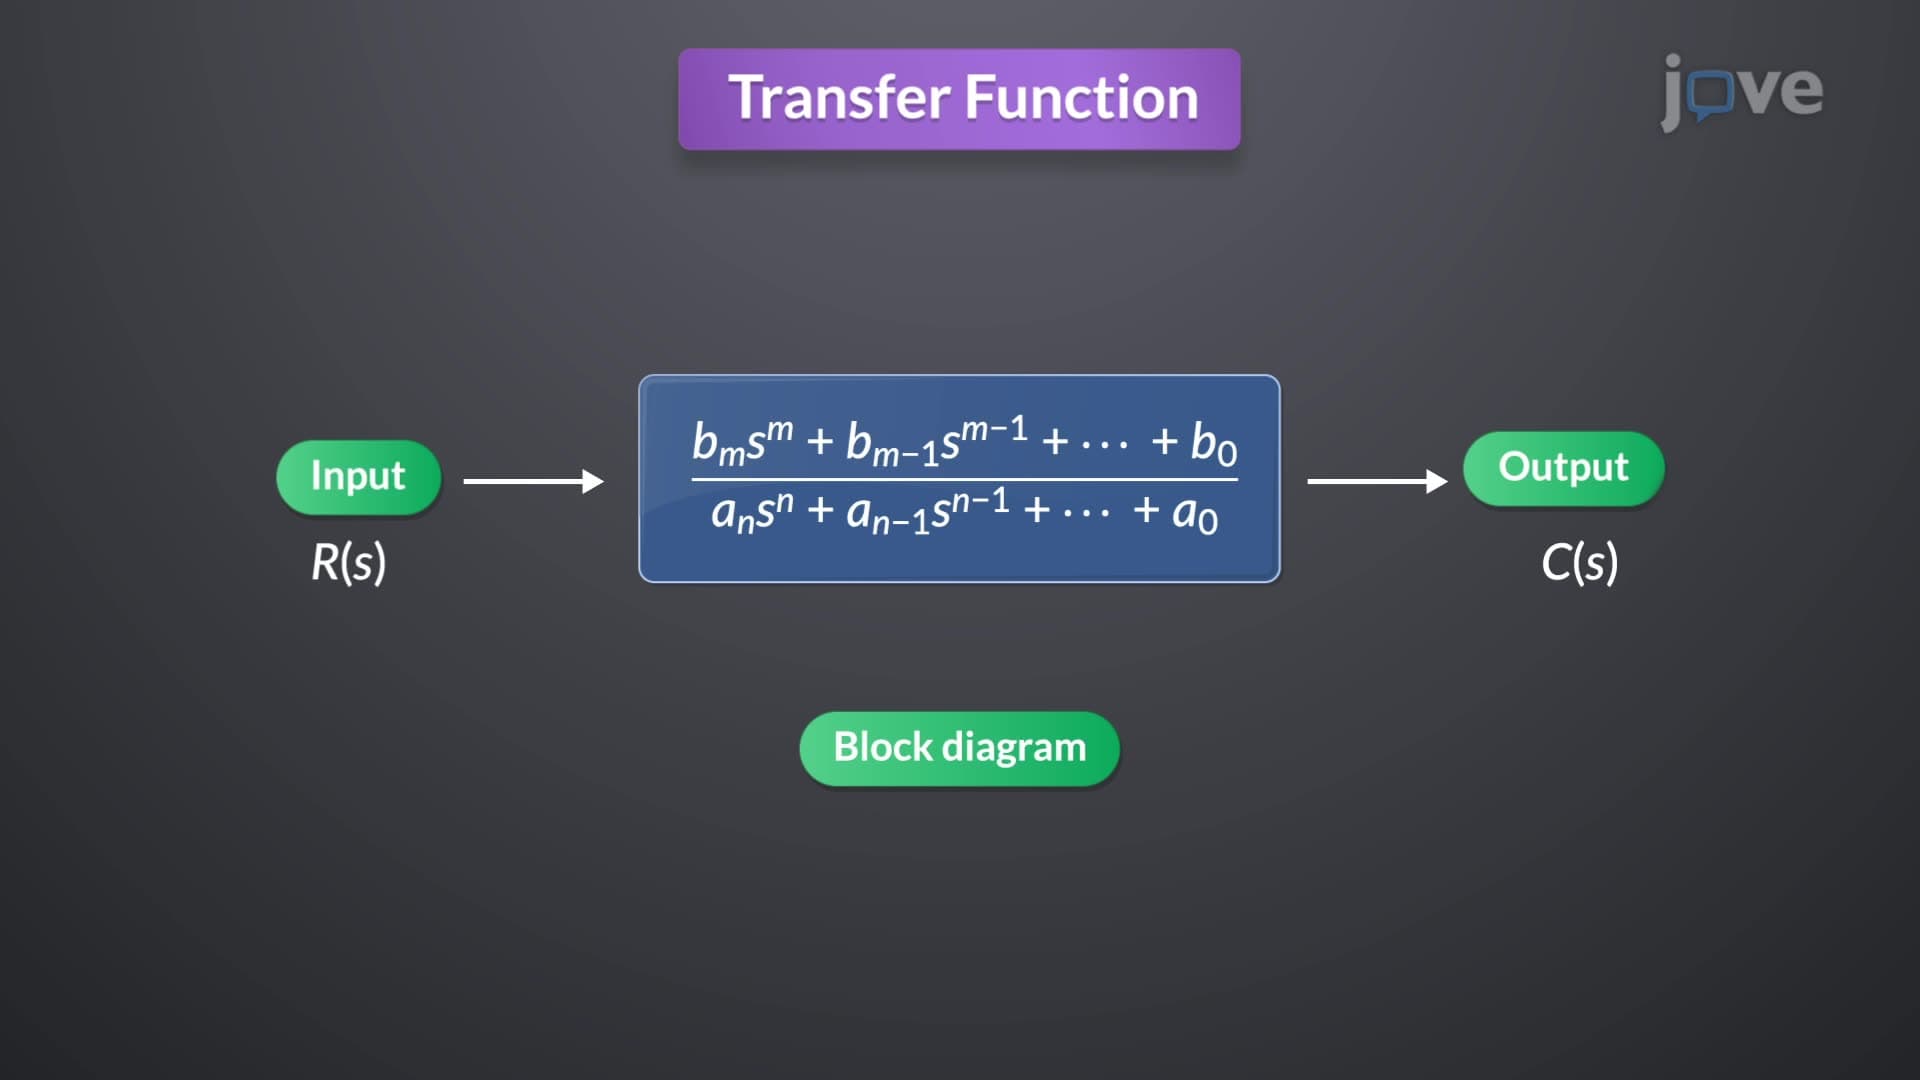
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:22
Multi-input and Multi-variable systems
In the absence of...