Related Experiment Video
Updated: Aug 9, 2026
10:52
Reconstitution of Basic Mitotic Spindles in Spherical Emulsion Droplets
Published on: August 13, 2016
On the construction of nonequatorial minimal hyperspheres in S(1) with stable cones in R
1Department of Mathematics, University of California, Berkeley, CA 94720.

Abstract:
Within the framework of equivariant differential geometry, we outline the construction of some imbedded minimal hyperspheres of S(n)(1) and show that many of them have a stable cone in R(n+1). The statement of these and related results are given.
Related Concept Videos
 01:28
Quadric Surfaces
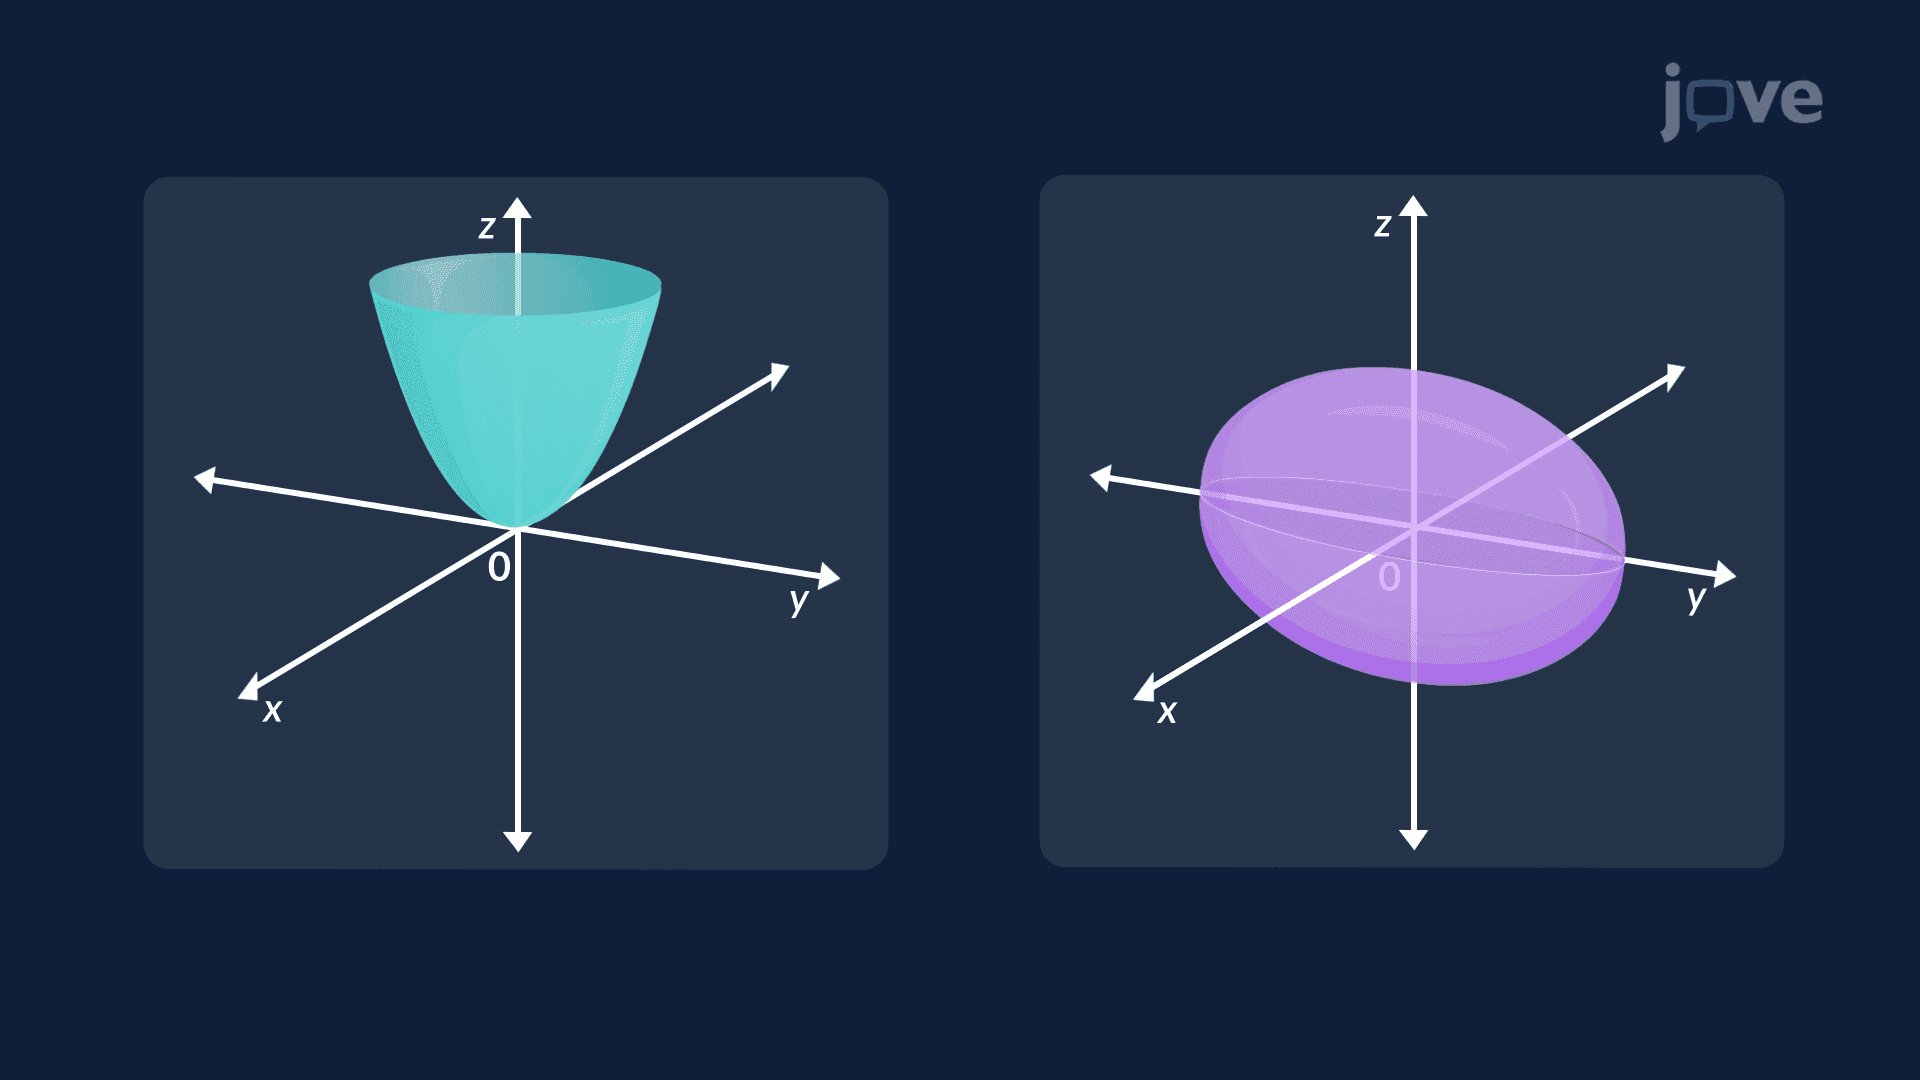
Quadric surfaces are three-dimensional surfaces characterized by second-degree equations in the variables x, y, and z. These surfaces are smooth and continuous, and specific combinations of squared and linear terms define their shapes. The main types of quadric surfaces include ellipsoids, cones, paraboloids, and hyperboloids. Each type exhibits distinct geometric features depending on how the variables are arranged and related within the equation.Ellipsoids are closed surfaces formed when all...
 01:30
Hyperbolas
A hyperbola is a conic section produced when a double-napped cone is intersected by a plane at an angle steeper than the slope of the cone, such that it cuts through both nappes. This intersection yields two separate, mirror-image curves known as branches, which open away from each other along the transverse axis. The nearest points on each branch to the hyperbola’s center are termed vertices, and the distance from the center to a vertex is denoted by a. Perpendicular to the transverse axis is...
 01:23
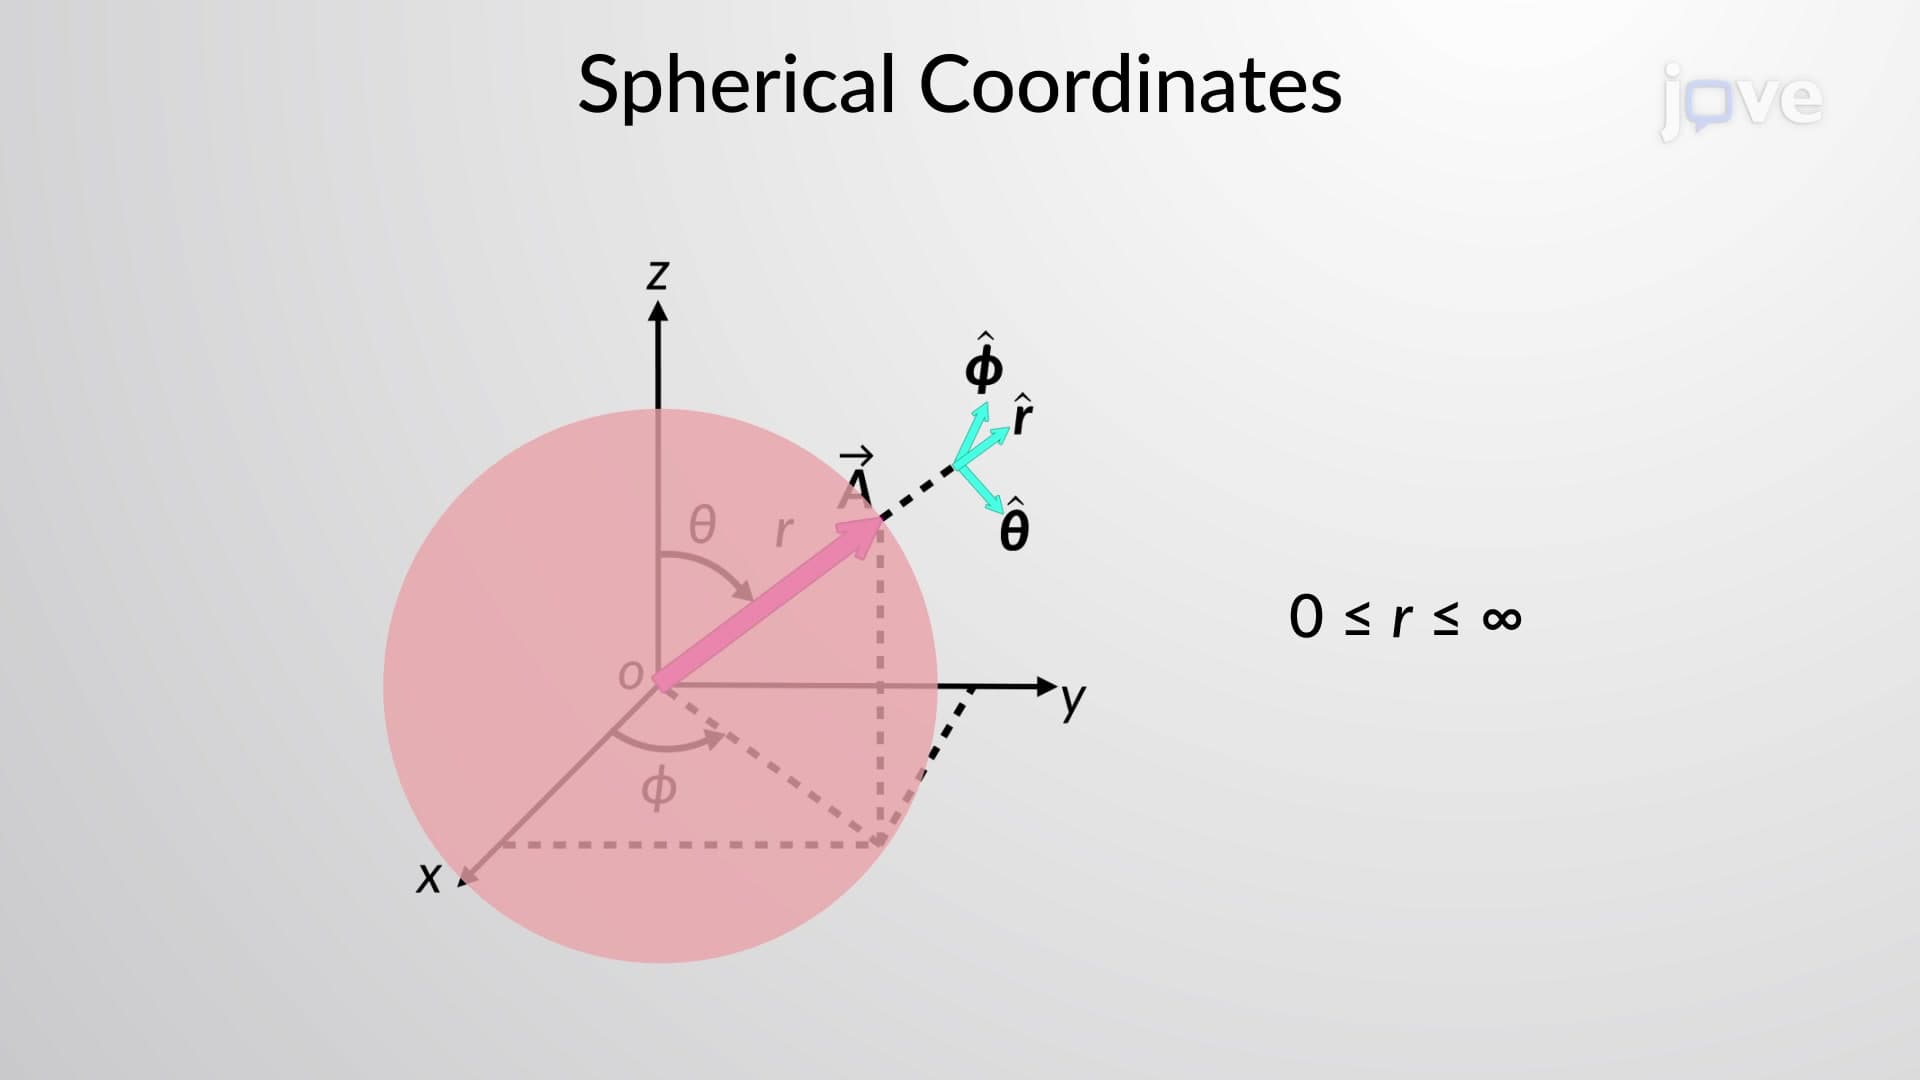
Spherical Coordinates
Spherical coordinate systems are preferred over Cartesian, polar, or cylindrical coordinates for systems with spherical symmetry. For example, to describe the surface of a sphere, Cartesian coordinates require all three coordinates. On the other hand, the spherical coordinate system requires only one parameter: the sphere's radius. As a result, the complicated mathematical calculations become simple. Spherical coordinates are used in science and engineering applications like electric and...
 01:29
Polar Equations of Conics
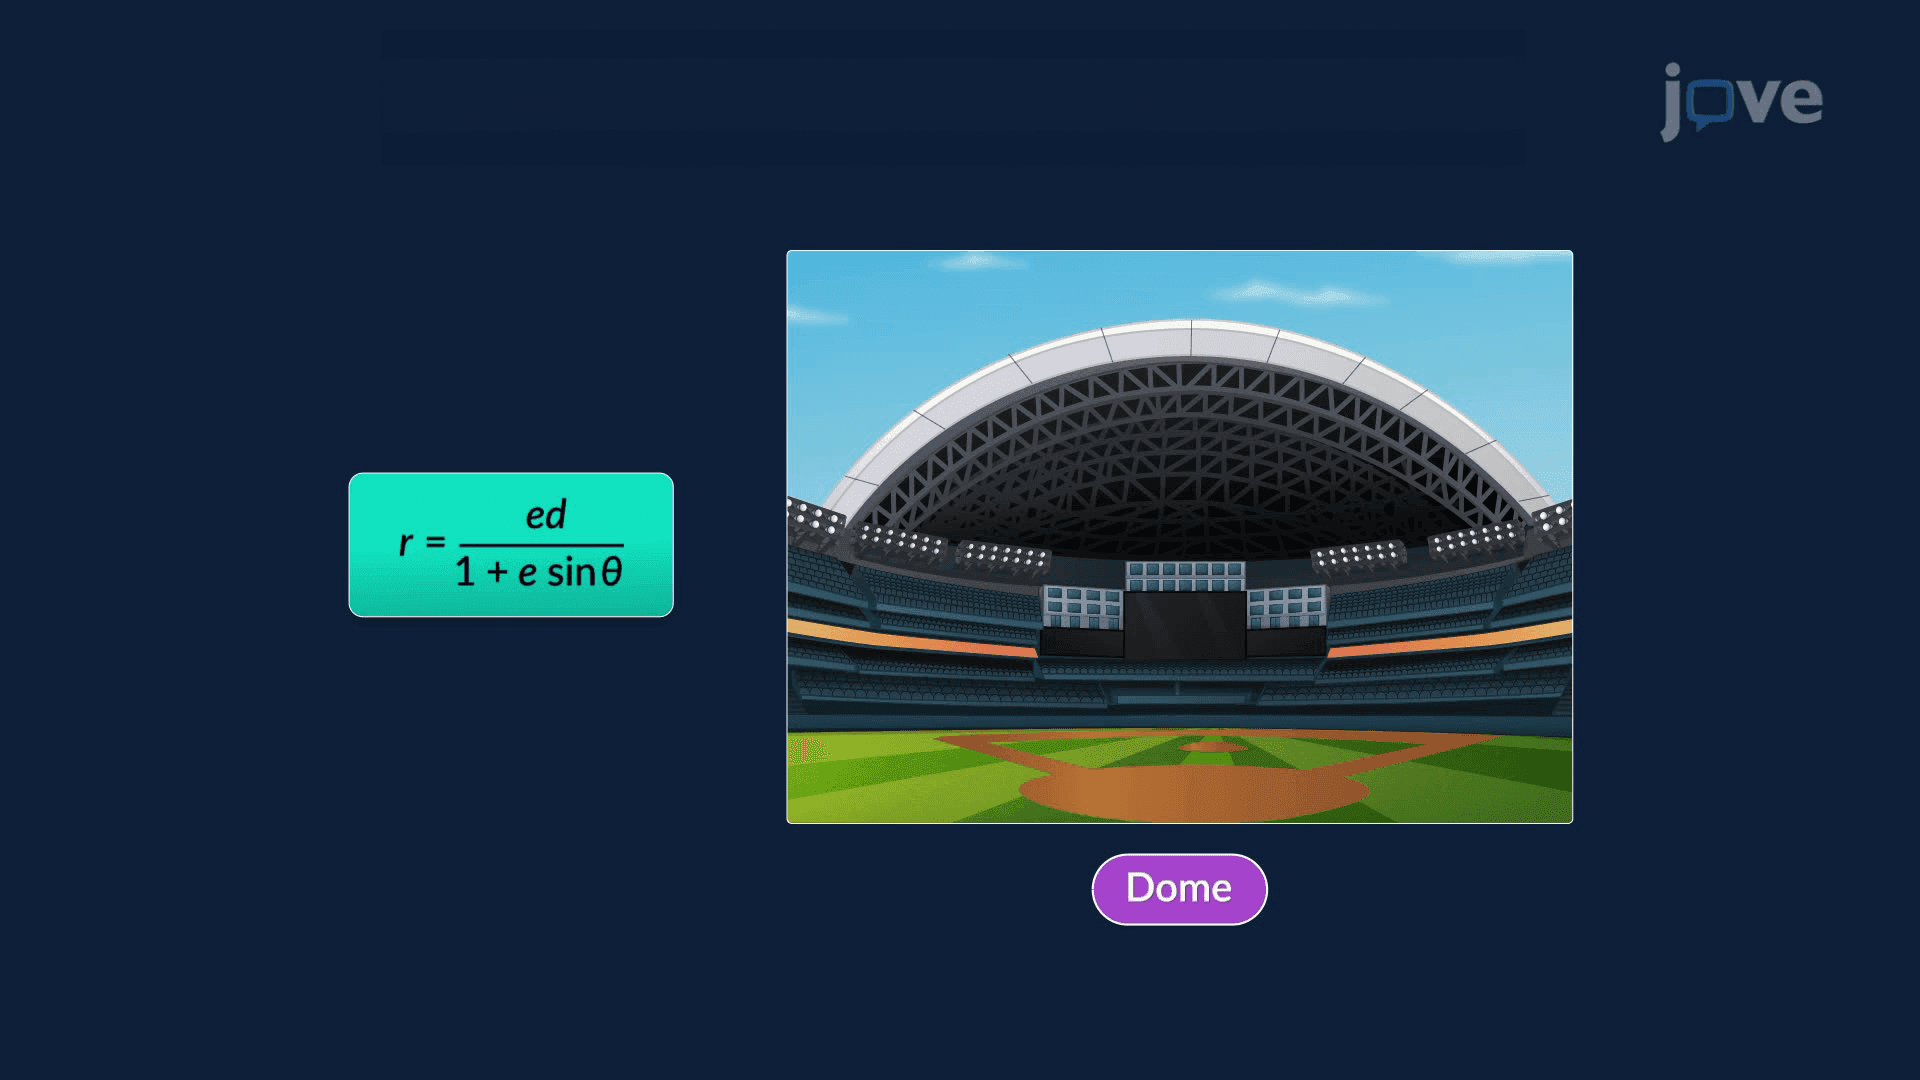
A conic section can be defined in polar coordinates as the set of all points whose distance from a fixed point, known as the focus, bears a constant ratio to their distance from a fixed line, known as the directrix. This constant ratio is called the eccentricity. This definition unifies all types of conic sections—ellipses, parabolas, and hyperbolas—under a single framework. When the focus is positioned at the origin of the polar coordinate system, a single polar equation can describe any conic...
 01:15
Construction of Root Locus
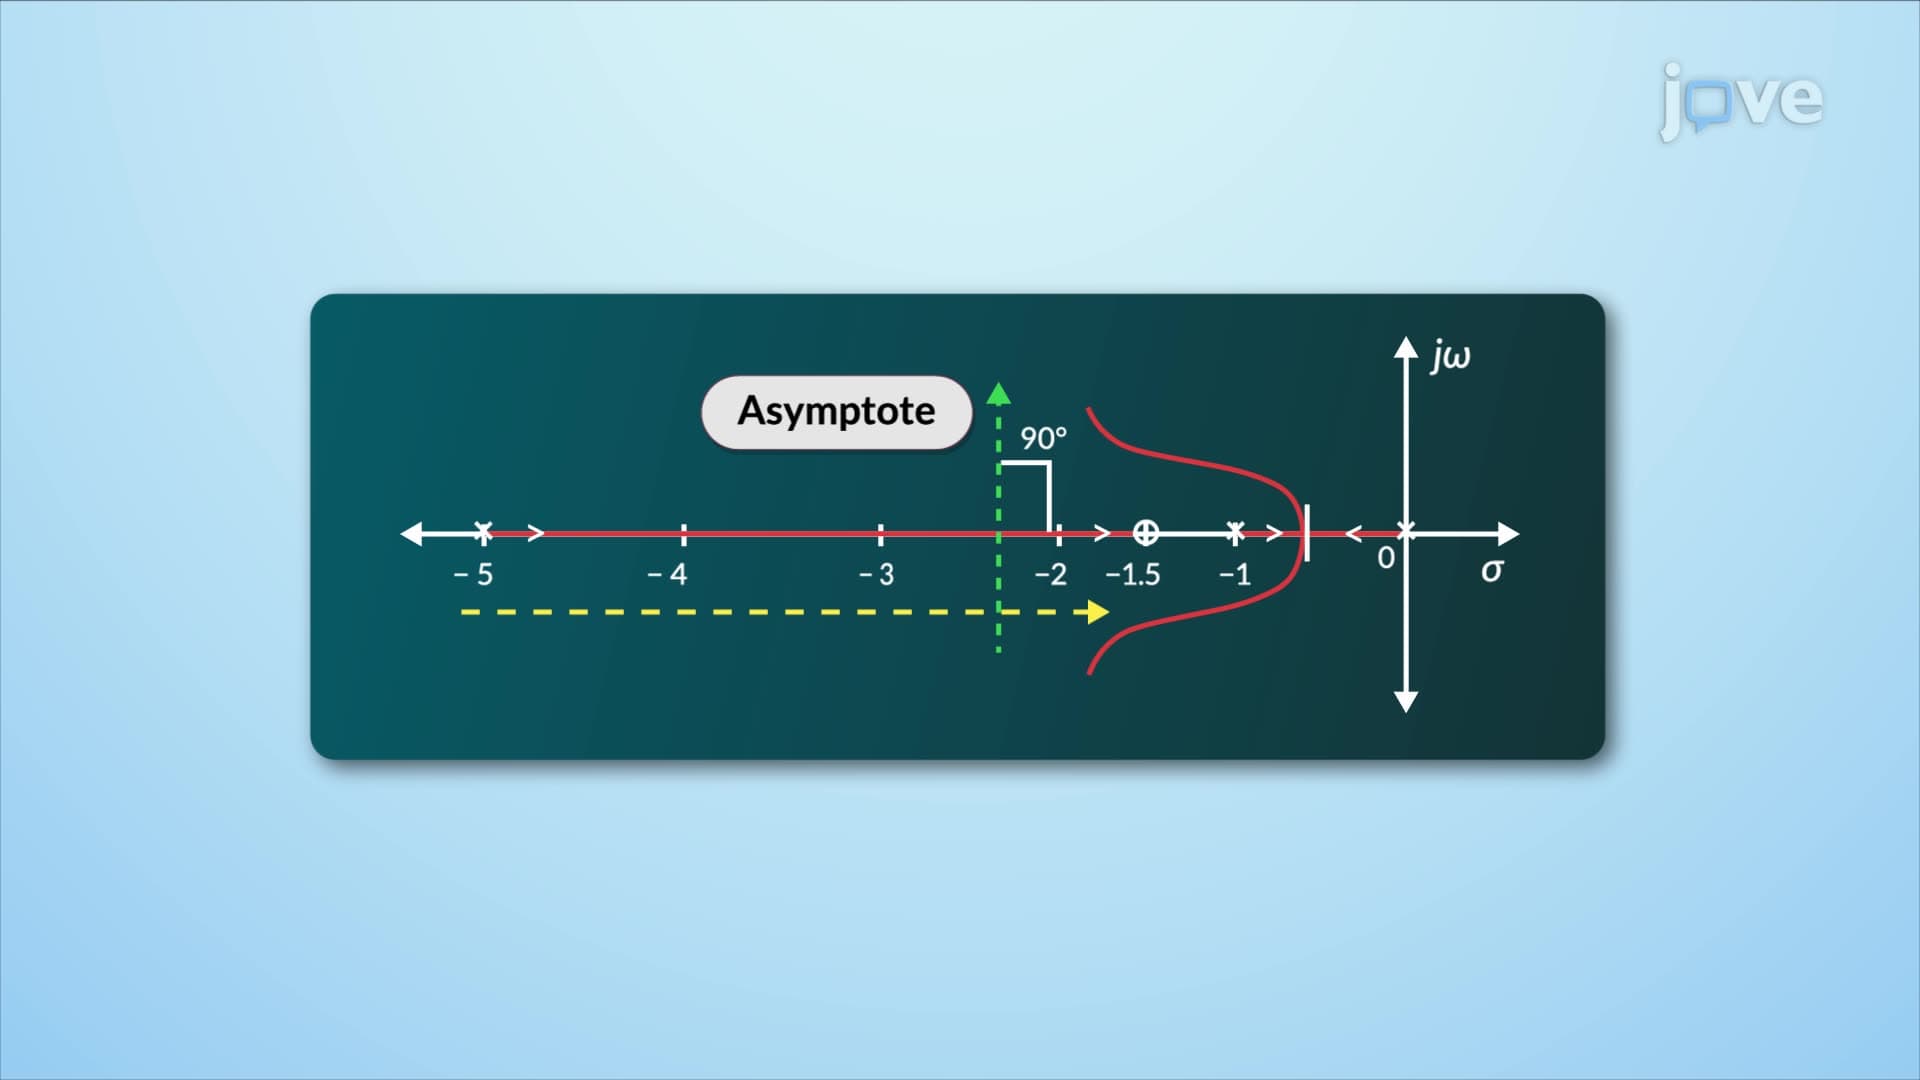
The construction of a root locus involves several key steps to analyze and visualize the behavior of a system's poles with varying gain. The number of branches in the root locus equals the number of closed-loop poles and is symmetrical about the real axis.
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain increases.
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain increases.
 01:30
Geometry of Hyperbolas
A hyperbola consists of all points where the absolute difference of distances to two fixed points, called foci, remains constant. The standard equation isEach branch extends infinitely and approaches two asymptotes, which guide the curve’s behavior. The parameters a and b define key features: a measures the distance from the center to each vertex along the transverse axis, while b influences the slopes of the asymptotes. The asymptotes have equationsA rectangle centered at the origin with...