Related Experiment Video
Updated: Aug 9, 2026
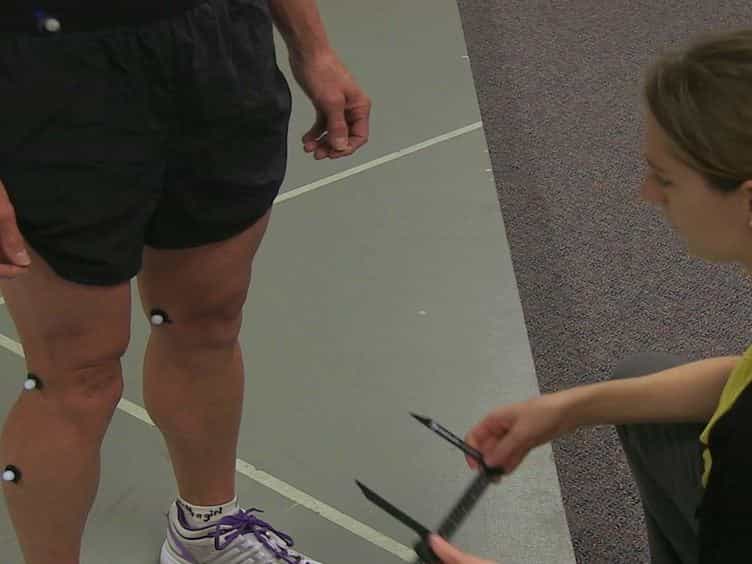

Movement Retraining using Real-time Feedback of Performance
Published on: January 17, 2013
Accuracy of an optical active-marker system to track the relative motion of rigid bodies
Lorin P Maletsky1, Junyi Sun, Nicholas A Morton
1Department of Mechanical Engineering, University of Kansas, 1530 W 15th St., Learned Hall, rm 3138, Lawrence, KS 66045, USA. maletsky@ku.edu

Abstract:
The measurement of relative motion between two moving bones is commonly accomplished for in vitro studies by attaching to each bone a series of either passive or active markers in a fixed orientation to create a rigid body (RB). This work determined the accuracy of motion between two RBs using an Optotrak optical motion capture system with active infrared LEDs. The stationary noise in the system was quantified by recording the apparent change in position with the RBs stationary and found to be 0.04 degrees and 0.03 mm. Incremental 10 degrees rotations and 10-mm translations were made using a more precise tool than the Optotrak. Increasing camera distance decreased the precision or increased the range of values observed for a set motion and increased the error in rotation or bias between the measured and actual rotation. The relative positions of the RBs with respect to the camera-viewing plane had a minimal effect on the kinematics and, therefore, for a given distance in the volume less than or close to the precalibrated camera distance, any motion was similarly reliable. For a typical operating set-up, a 10 degrees rotation showed a bias of 0.05 degrees and a 95% repeatability limit of 0.67 degrees. A 10-mm translation showed a bias of 0.03 mm and a 95% repeatability limit of 0.29 mm. To achieve a high level of accuracy it is important to keep the distance between the cameras and the markers near the distance the cameras are focused to during calibration.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:10
Relative Motion Analysis - Acceleration