Joint multiregion segmentation and parametric estimation of image motion by basis function representation and level set evolution
Related Experiment Video
Updated: Aug 2, 2026
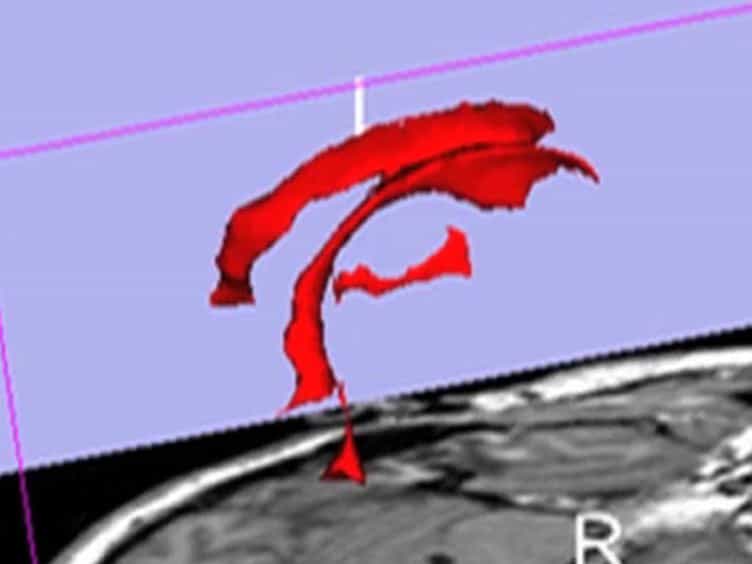
Automated Midline Shift and Intracranial Pressure Estimation based on Brain CT Images
Published on: April 13, 2013
Carlos Vázquez1, Amar Mitiche, Robert Laganière
1Advanced Video Systems, Communication Research Centre, Ottawa, Ontario, Canada. carlos.vazquez@crc.ca

Abstract:
The purpose of this study is to investigate a variational method for joint segmentation and parametric estimation of image motion by basis function representation of motion and level set evolution. The functional contains three terms. One term is of classic regularization to bias the solution toward a segmentation with smooth boundaries. A second term biases the solution toward a segmentation with boundaries which coincide with motion discontinuities, following a description of motion discontinuities by a function of the image spatio-temporal variations. The third term refers to region information and measures conformity of the parametric representation of the motion of each region of segmentation to the image spatio-temporal variations. The components of motion in each region of segmentation are represented as functions in a space generated by a set of basis functions. The coefficients of the motion components considered combinations of the basis functions are the parameters of representation. The necessary conditions for a minimum of the functional, which are derived taking into consideration the dependence of the motion parameters on segmentation, lead to an algorithm which condenses to concurrent curve evolution, implemented via level sets, and estimation of the parameters by least squares within each region of segmentation. The algorithm and its implementation are verified on synthetic and real images using a basis of cosine transforms.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...