Smooth pursuit of nonvisual motion
Related Experiment Video
Updated: Aug 8, 2026
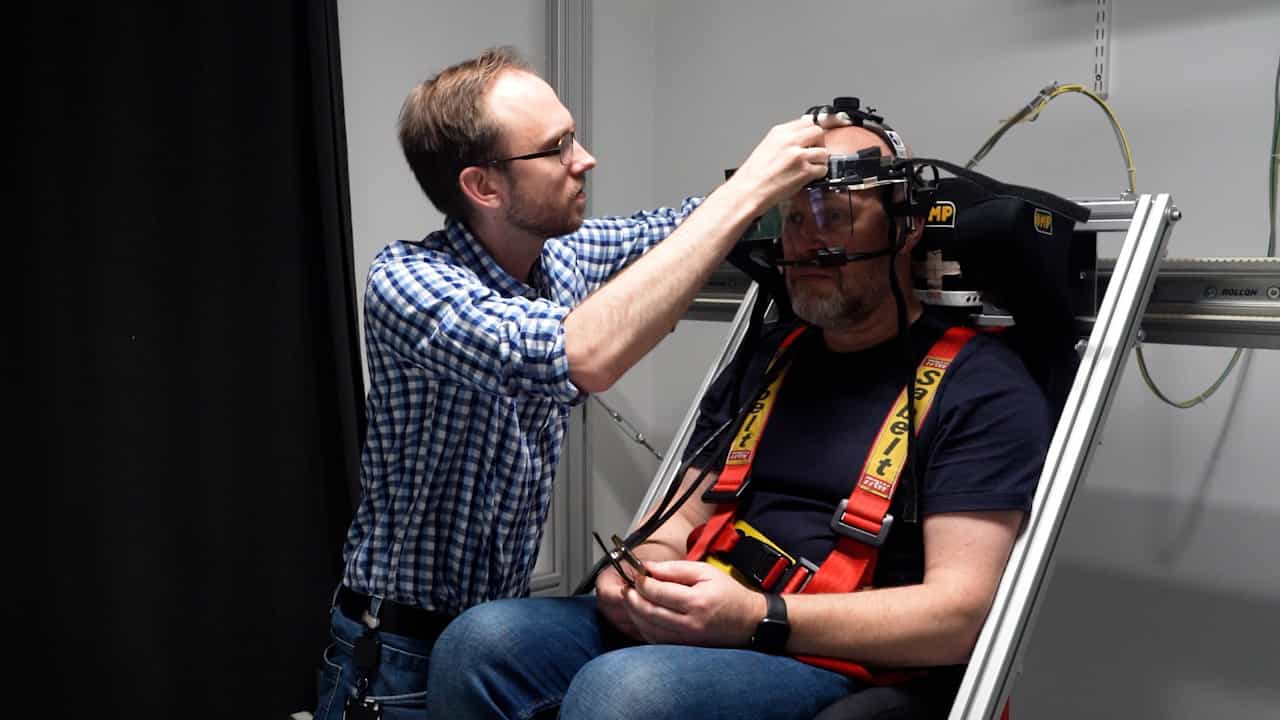
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Marian E Berryhill1, Tanya Chiu, Howard C Hughes
1Department of Psychological and Brain Sciences, Dartmouth College, Hanover, NH 03755, USA.

Abstract:
Unlike saccades, smooth pursuit eye movements (SPEMs) are not under voluntary control and their initiation generally requires a moving visual target. However, there are various reports of limited smooth pursuit of the motion of a subject's own finger in total darkness (pursuit based on proprioceptive feedback) and to the combination of proprioception and tactile motion as an unseen finger was moved voluntarily over a smooth surface. In contrast, SPEMs to auditory motion are not distinguishable from pursuit of imagined motion. These reports of smooth pursuit of nonvisual motion cues used a variety of paradigms and different stimuli. In addition, the results have often relied primarily on qualitative descriptions of the smooth pursuit. Here, we directly compare measurements of smooth pursuit gain (eye velocity/stimulus velocity) to visual, auditory, proprioceptive, tactile, and combined tactile + proprioceptive motion stimuli. The results demonstrate high gains for visual pursuit, low gains for auditory pursuit, and intermediate, statistically indistinguishable gains for tactile, proprioceptive, and proprioceptive + tactile pursuit.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Non-uniform Circular Motion
For example, such accelerations...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:31
Motion in Space: Velocity and Acceleration
 01:27
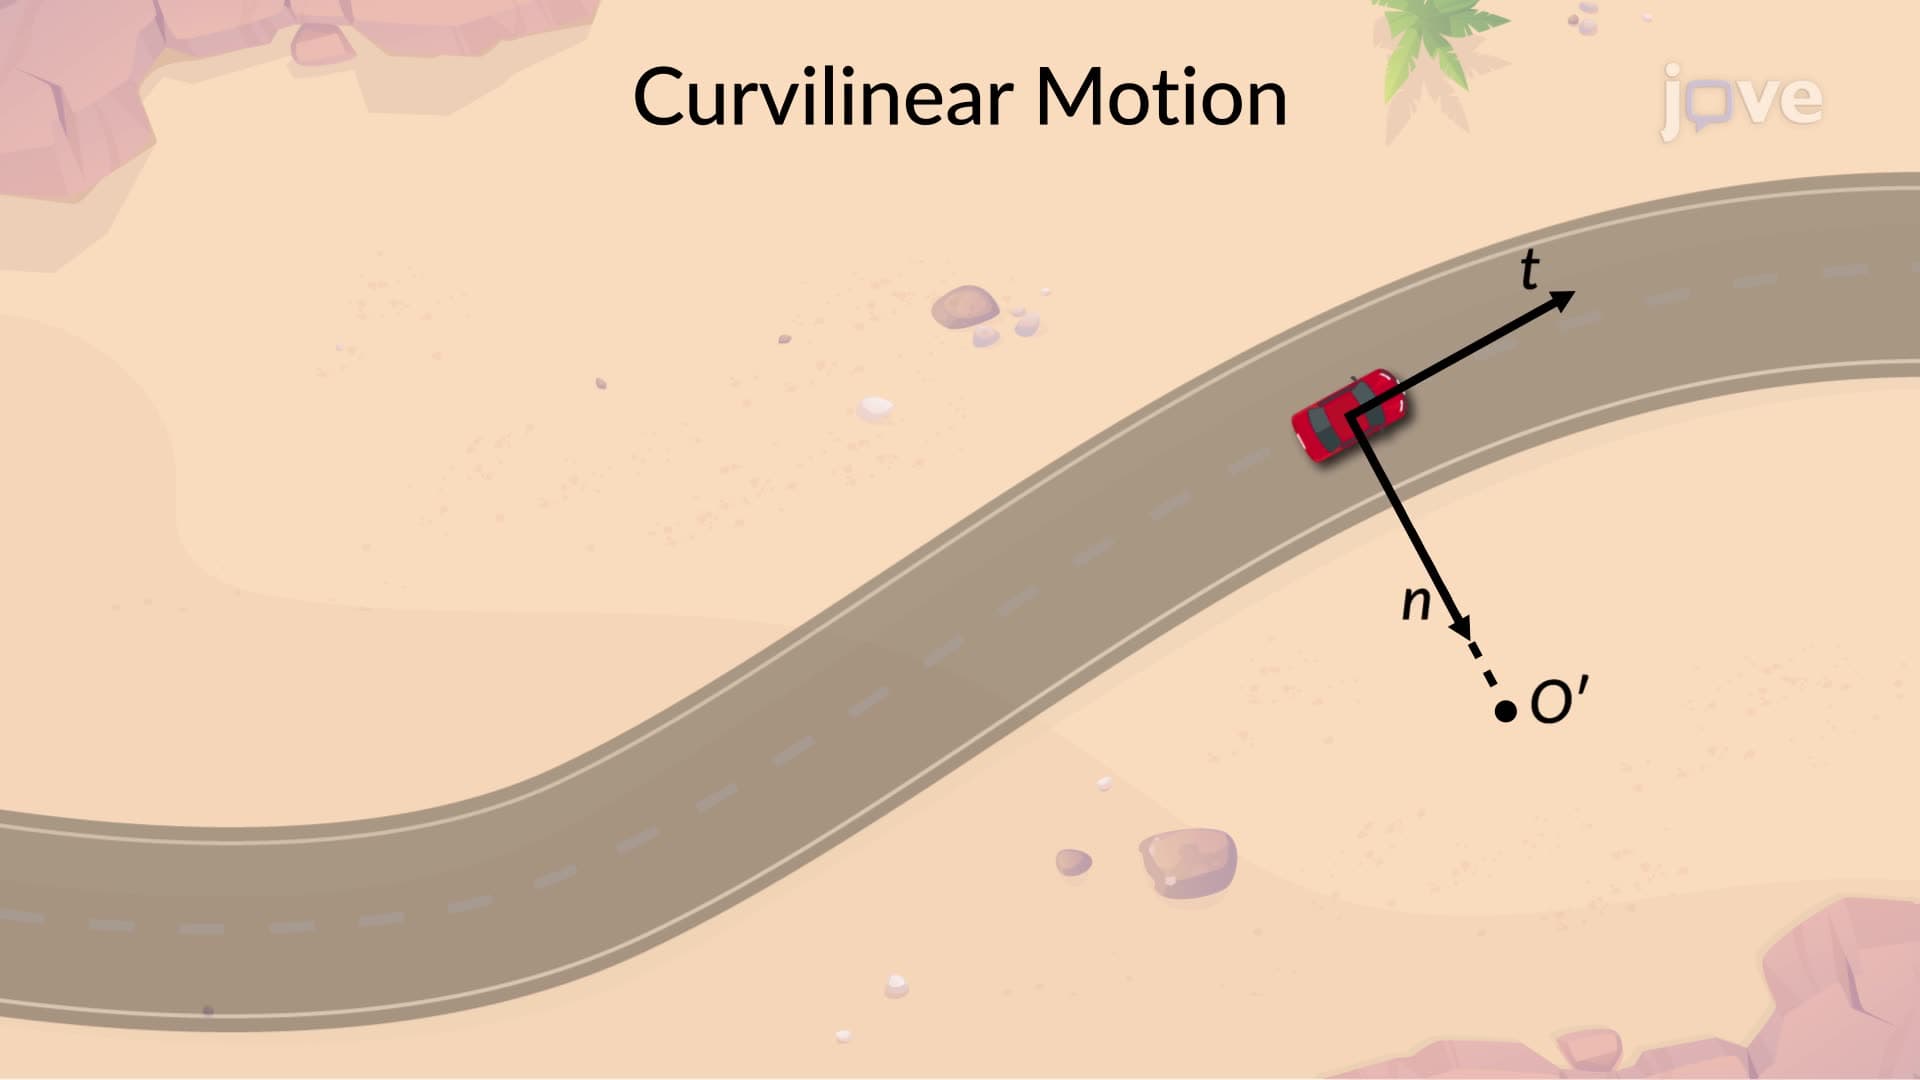
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...