Related Experiment Video
Updated: Aug 8, 2026

Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Discovery of the pendulum and spring dynamics in the early stages of walking
Kenneth G Holt1, Elliot Saltzman, Chia-Ling Ho
1Department of Physical Therapy and Athletic Training, Sargent College of Health and Rehabilitation Sciences, Boston University, 635 Commonwealth Avenue, Boston, MA 02215, USA. kgholt@bu.edu

Insights
Newly walking children rapidly develop efficient gait patterns. Within months, their walking speed, stride length, and frequency improve, demonstrating early mastery of complex biomechanics for stable locomotion.
Area of Science:
- Biomechanics
- Developmental Motor Control
- Pediatric Gait Analysis
Background:
- Early childhood walking development is crucial for motor milestones.
- Understanding the initial phases of gait acquisition informs developmental assessments.
- Limited research exists on the rapid kinematic changes in the first six months of independent walking.
Purpose of the Study:
- To analyze the evolution of self-selected overground walking patterns in infants.
- To quantify changes in gait parameters during the initial six months of walking.
- To investigate the development of propulsive mechanisms and body segment coordination.
Main Methods:
- Longitudinal study tracking 7 infants (11 months to 1 year, 5 months) over 6 months.
- Gait analysis included measurements of walking speed, stride length, and stride frequency.
- Sagittal plane angular accelerations of the center of mass were calculated as an escapement pulse indicator.
Main Results:
- Significant increases in walking speed, stride length, and frequency were observed within the first two months.
- Gait patterns quickly shifted to positive, single-peaked acceleration profiles post-initial foot contact.
- Development showed increased sagittal hip and decreased frontal pelvic angular displacement.
Conclusions:
- Infants rapidly adapt their walking patterns, developing effective propulsive forces.
- Early walkers quickly establish biomechanical strategies for efficient gait, resembling those of older children.
- These findings highlight the dynamic and adaptive nature of infant motor learning in gait acquisition.
Abstract:
The authors investigated the self-selected, overground walking patterns of 7 children (aged 11 months to 1 year, 5 months) at the initiation of walking (brand-new walkers [BNWs]) and for the next 6 months at 1-month intervals. Walking speed, stride length, and stride frequency increased significantly between the first 2 visits without significant changes in height and weight. The authors calculated sagittal plane angular accelerations of the center of mass over the foot for each step as an indicator of the escapement pulse. Results for the acceleration profiles changed after the 1st visit to positive, single-peaked accelerations that occurred < 0.20 s after initial foot contact. Increases in sagittal plane hip angular displacement and decreases in frontal plane pelvic angular displacement were observed. The pattern changes suggest that children quickly discover appropriately timed and directed escapements that initiate and support the conservative sagittal plane pendulum and spring dynamics observed in older children.
Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
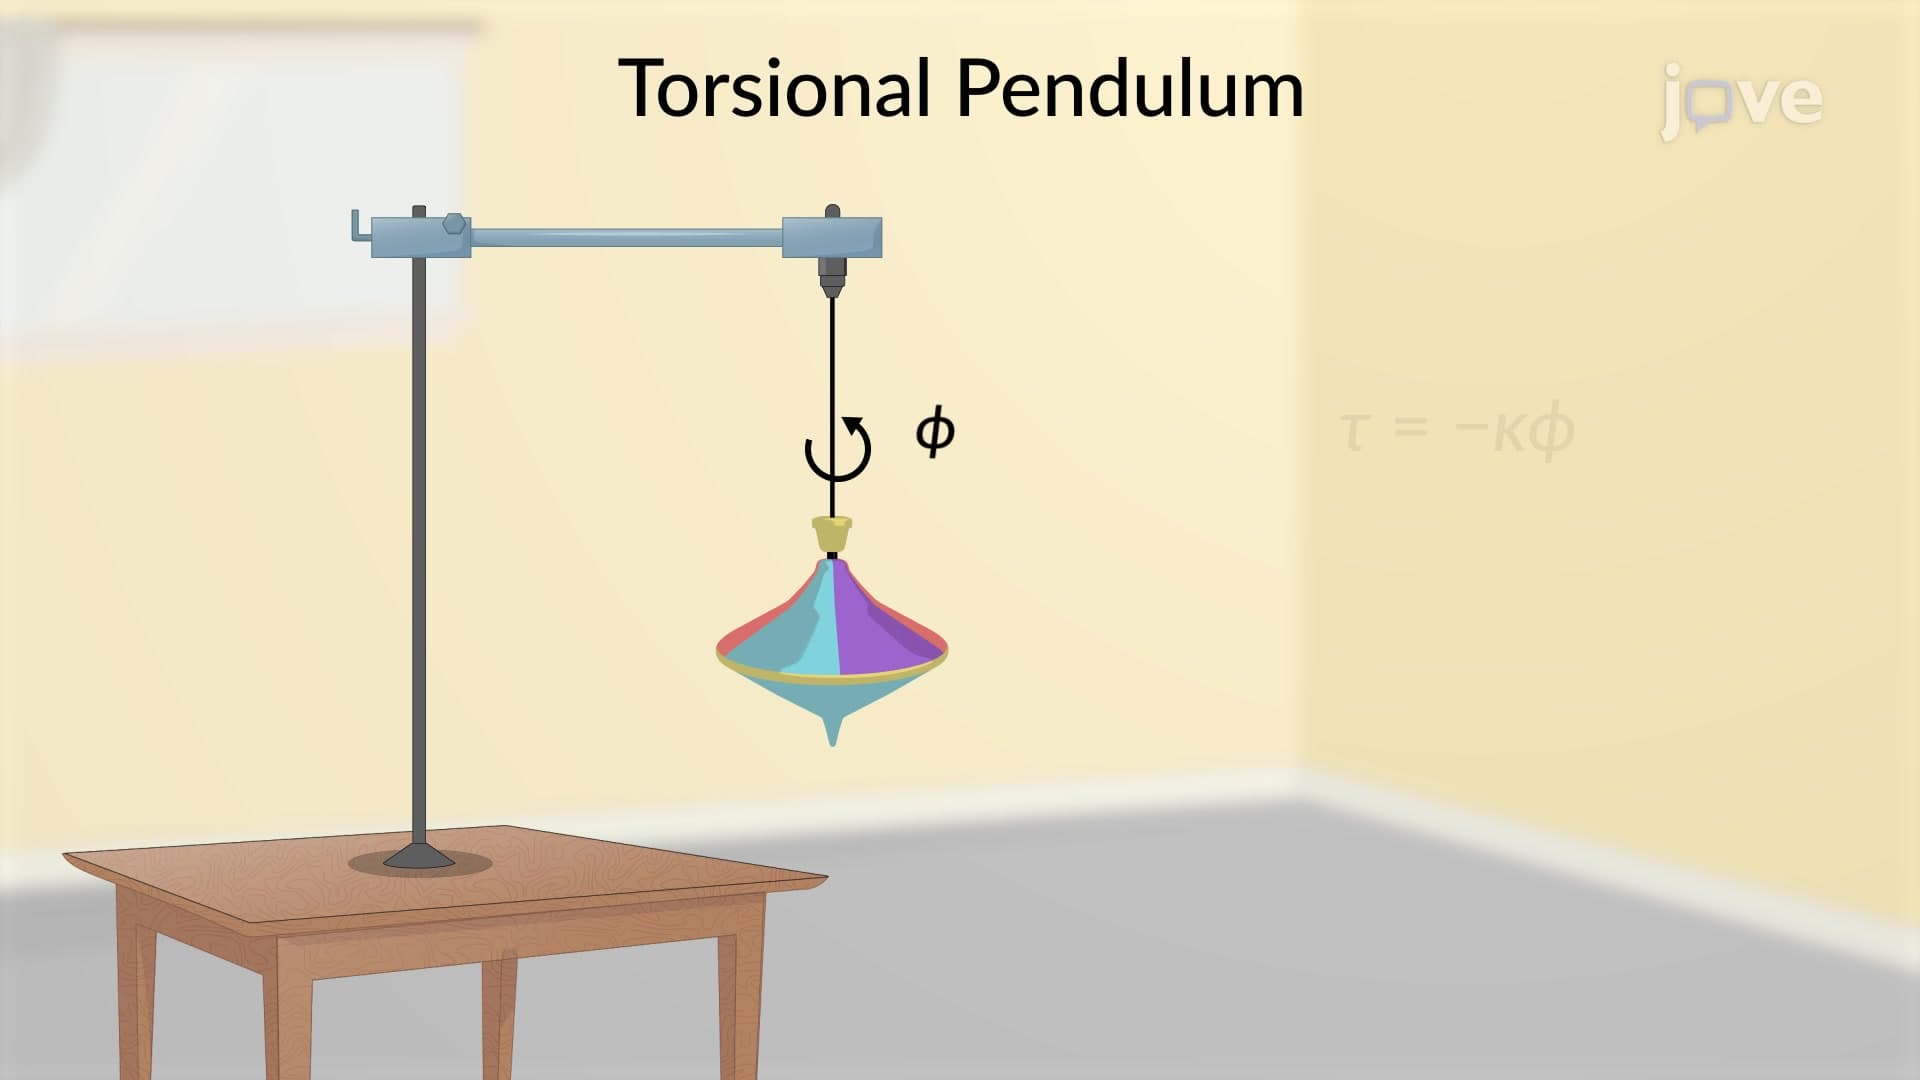
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:27
Real-World Applications of Power Series
 01:06
Forced Oscillations