Related Experiment Video
Updated: Aug 7, 2026
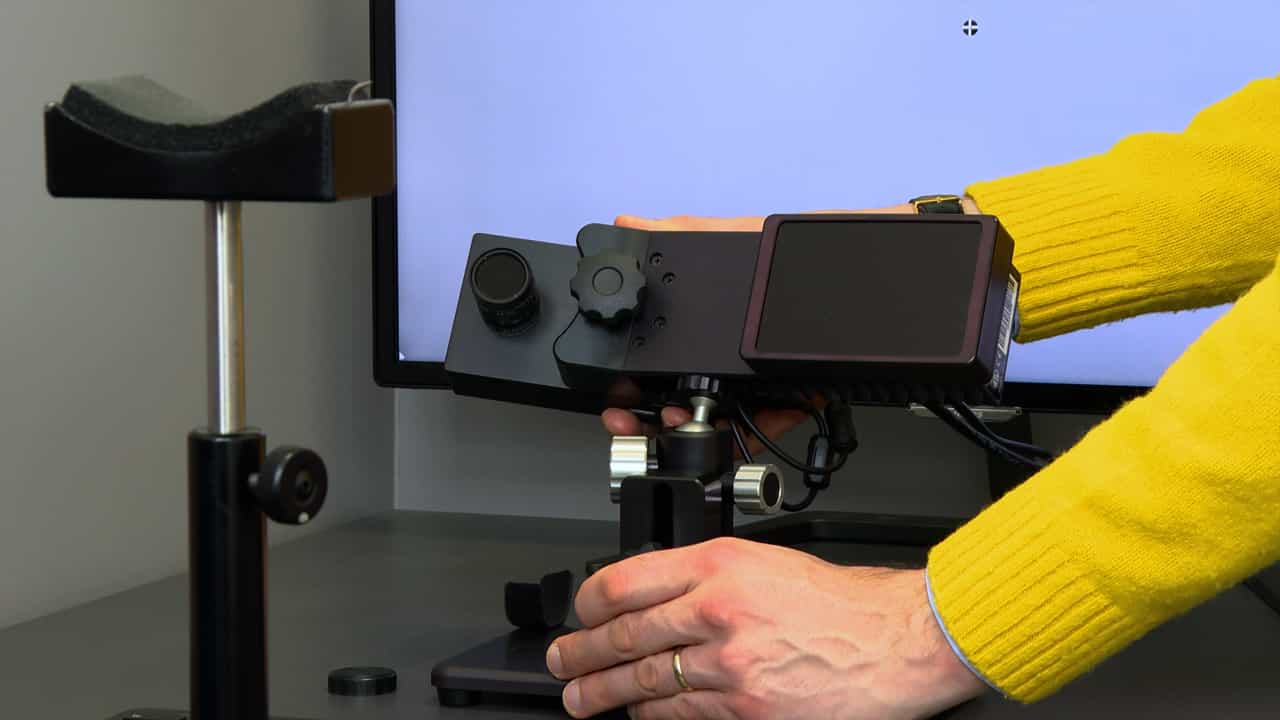
Motion-Acuity Test for Visual Field Acuity Measurement with Motion-Defined Shapes
Published on: February 23, 2024
Temporal shape error concealment by global motion compensation with local refinement
Luis Ducla Soares1, Fernando Pereira
1Instituto Superior Técnico-Instituto de Telecomunicações, 1049-001 Lisboa, Portugal. lds@lx.it.pt

Abstract:
This paper presents an original temporal shape error concealment technique based on a combination of global and local motion compensation. For this technique, which is especially useful for object-based video applications in error-prone environments (e.g., mobile networks), it is assumed that the shape of the corrupted object at hand is in the form of a binary alpha plane and some of the shape data is missing due to channel errors. To conceal the corrupted shape, the decoder first assumes that a global motion model can describe the shape changes in consecutive time instants. This way, based on locally estimated global motion parameters, the decoder attempts to conceal the corrupted alpha plane by global motion compensating the shape data from the previous time instant. Afterwards, since a global motion model cannot perfectly describe all alpha plane changes, a local motion refinement is applied to improve the concealment in areas of the object with significant local motion.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
Distance Corrections
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...