Related Experiment Video
Updated: Aug 7, 2026
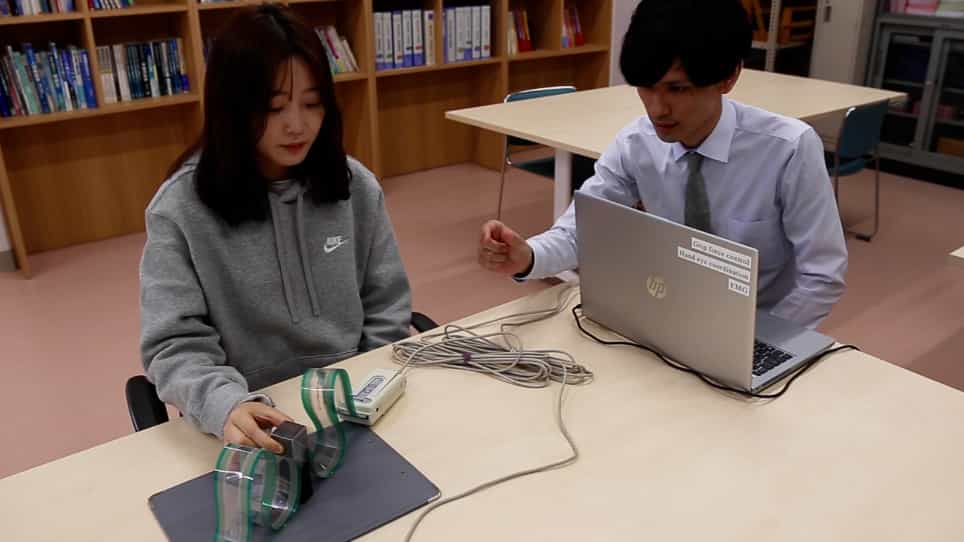

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Distribution of grip force in three different functional prehension patterns
C Pylatiuk1, A Kargov, S Schulz
1Institute for Applied Computer Science, Forschungszentrum Karlsruhe GmbH, PO Box 3640, D-76021, Karlsruhe, Germany. pylatiuk@iai.fzk.de

Abstract:
Normative data of the grip force distribution necessary to complete functional tasks are limited. Small force sensors have been specially designed for accurate measurement of the dynamic handgrip force distribution by attaching them to the palmar surface of the hand. Seventeen healthy participants performed three different tasks, each requiring a different functional prehension pattern. When cylindrical objects were manipulated, the highest average grip forces were found at the fingertips and the thumb, followed by the middle finger. In a spherical grasp pattern, the contributions by the thumb, ring and small fingers always exceeded 71% of the total grip force. The highest local forces of 9.9 N were measured when a zip was closed with a tip pinch. Individual finger forces were found to differ by gender, but not by hand dimension and age. The results are useful for biomechanical modelling of the hand, for designing ergonomic tool grips, and for evaluating hand function.

Related Concept Videos
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:16
Muscles that Move the Forearm
Forearm Flexors
The biceps brachii, brachialis, and brachioradialis are forearm flexors. The biceps brachii is made up of two heads. Its long head originates at the supraglenoid tubercle of the scapula, whereas that of the short head is...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:27
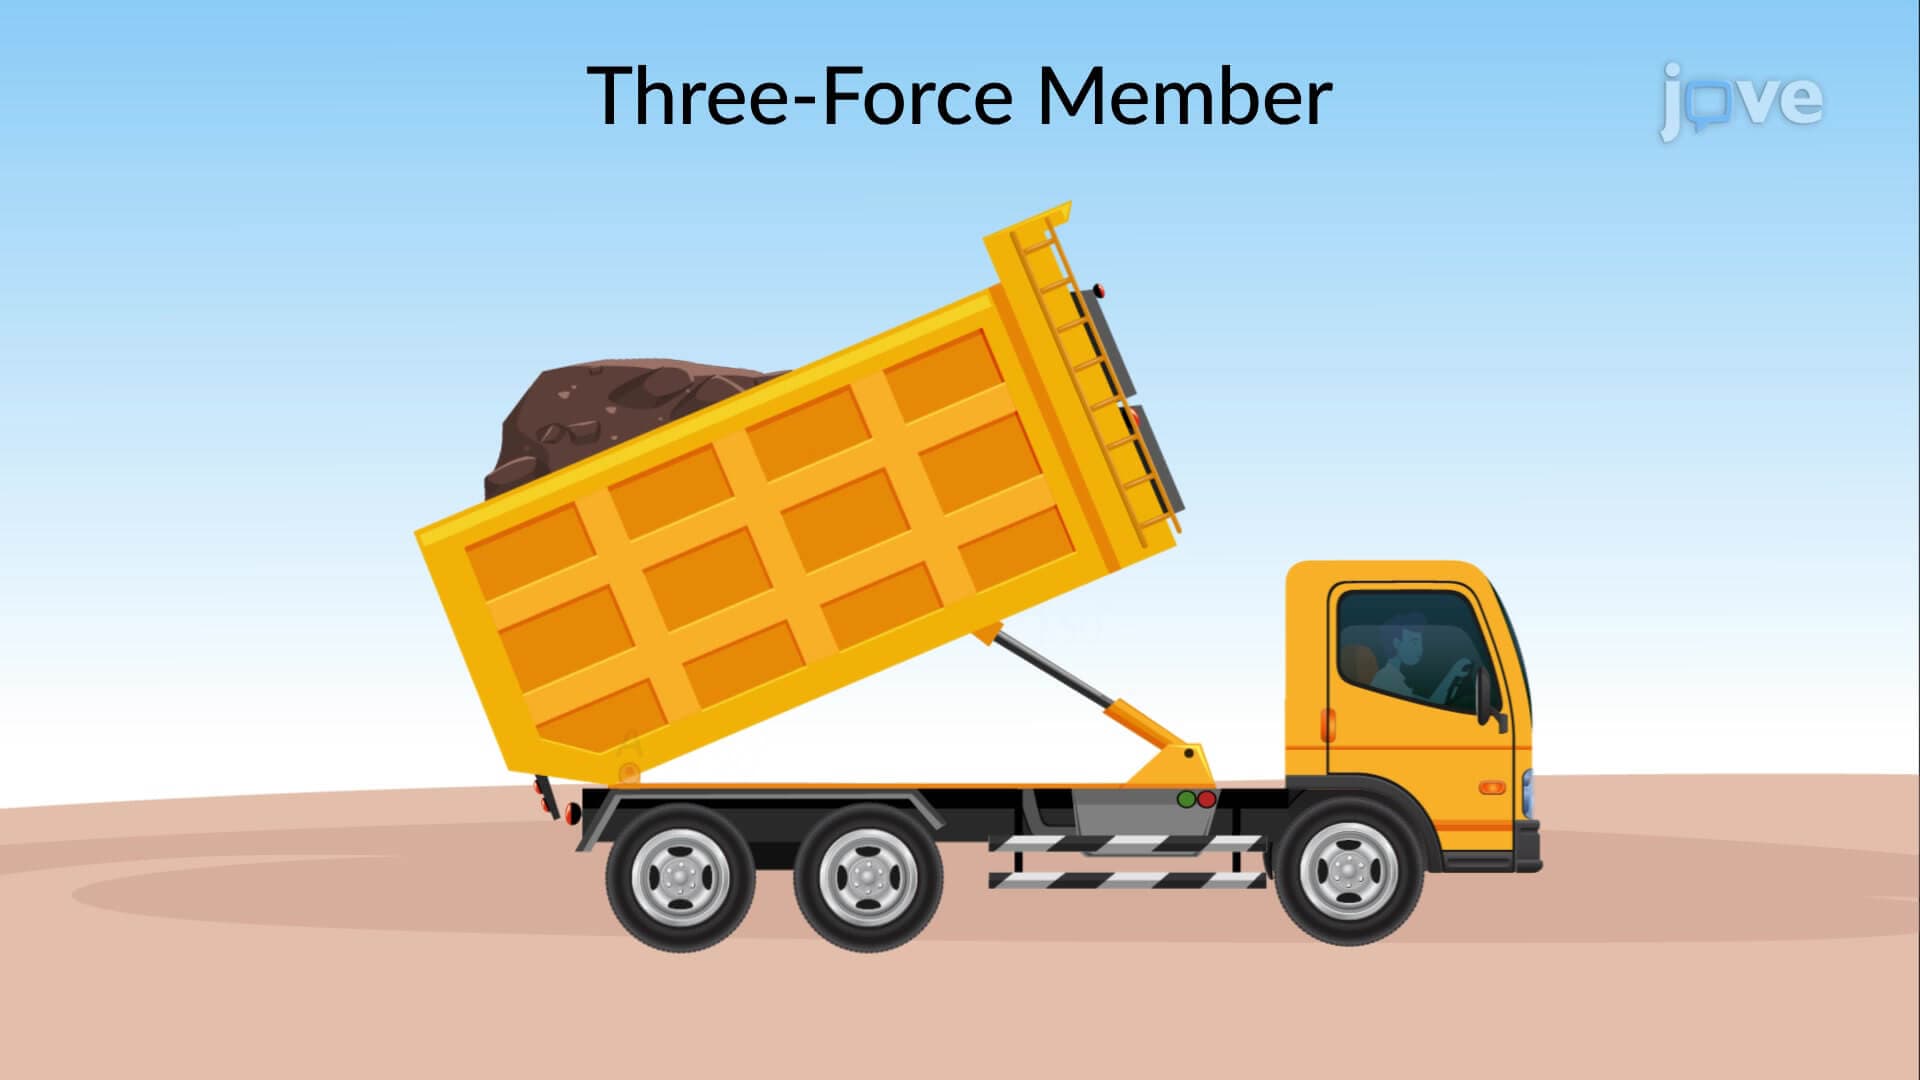
Three Force Member
For example, consider a dumpster connected to a pin support at point A and a pin attached to a hydraulic cylinder at point B.
 01:09
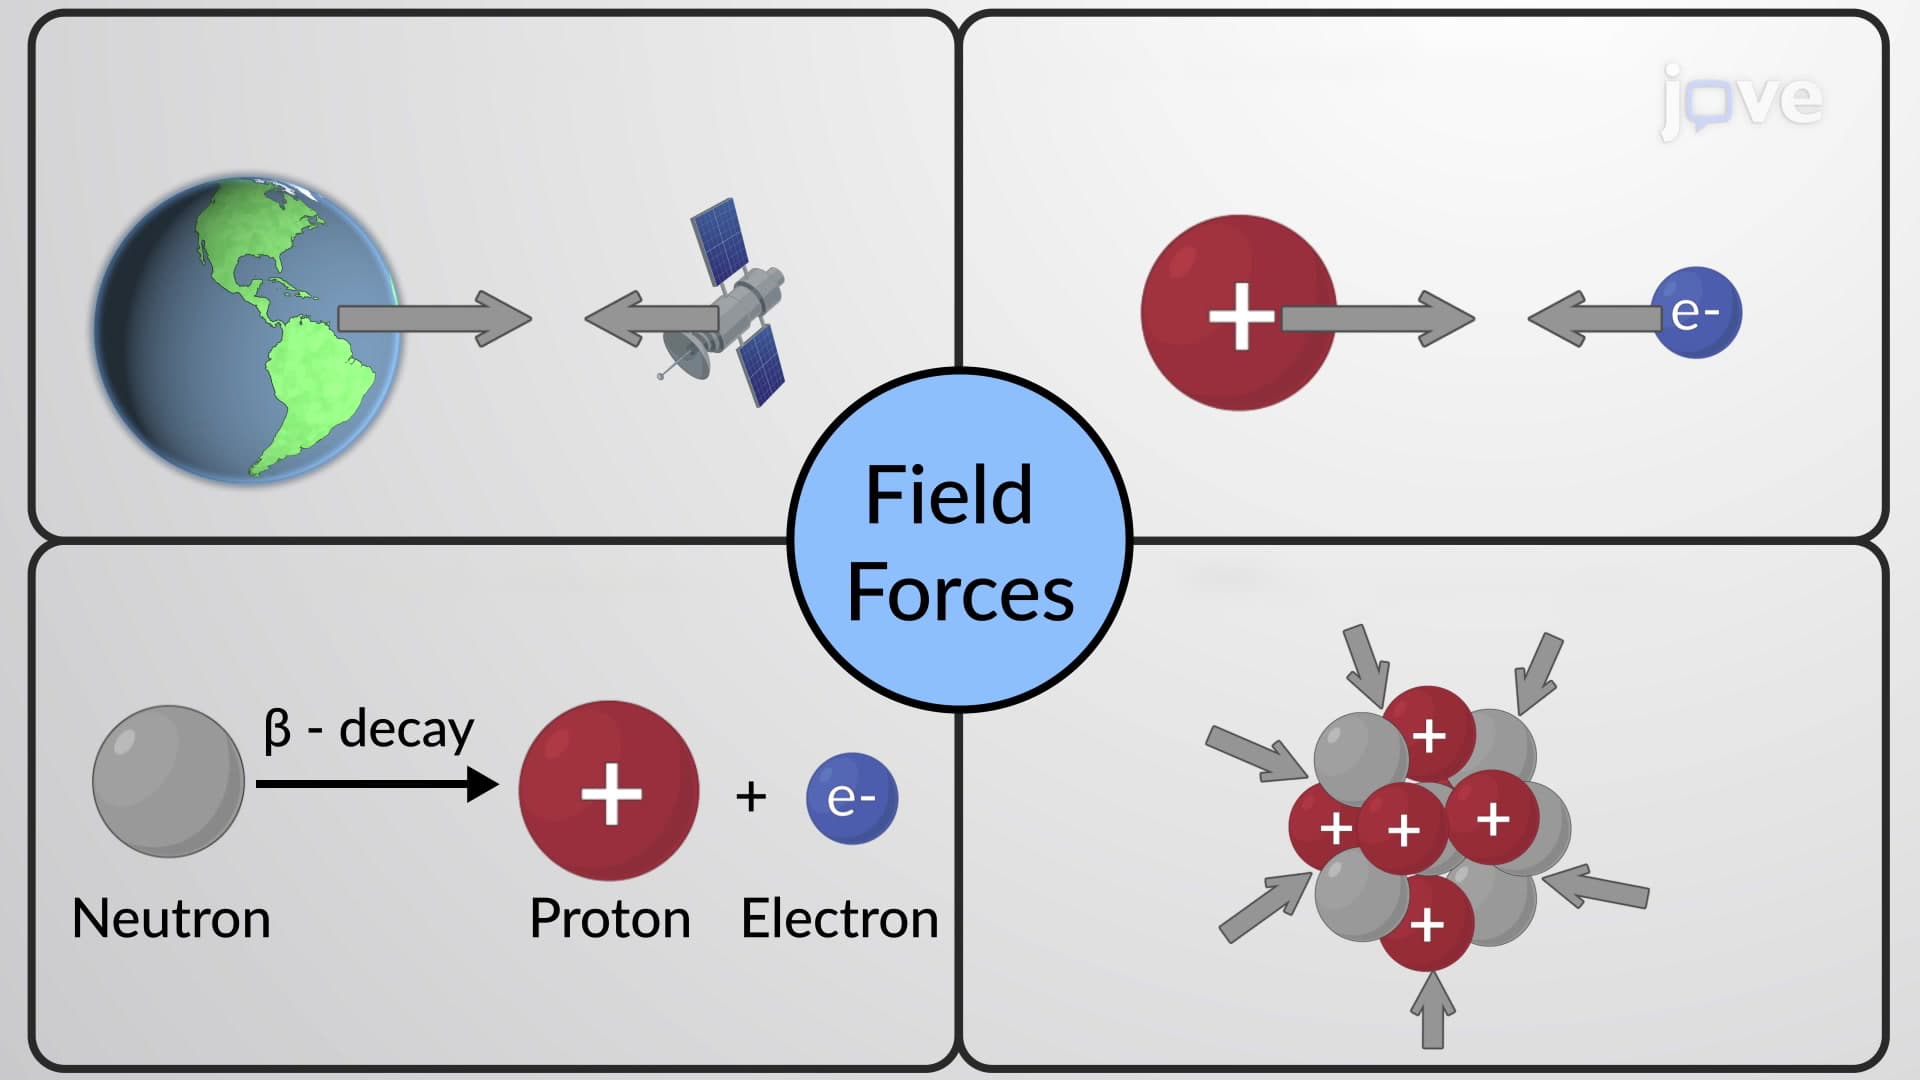
Types of Forces
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion.