Intersegmental coordination during human locomotion: does planar covariation of elevation angles reflect central constraints?
Related Experiment Video
Updated: Aug 7, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Halim Hicheur1, Alexander V Terekhov, Alain Berthoz
1Laboratoire de Physiologie de la Perception et de l'Action, Collège de France, Paris, France. halim.hicheur@college-de-france.fr

Abstract:
To study intersegmental coordination in humans performing different locomotor tasks (backward, normal, fast walking, and running), we analyzed the spatiotemporal patterns of both elevation and joint angles bilaterally in the sagittal plane. In particular, we determined the origins of the planar covariation of foot, shank, and thigh elevation angles. This planar constraint is observable in the three-dimensional space defined by these three angles and corresponds to the plane described by the three time-varying elevation angle variables over each step cycle. Previous studies showed that this relation between elevation angles constrains lower limb coordination in various experimental situations. We demonstrate here that this planar covariation mainly arises from the strong correlation between foot and shank elevation angles, with thigh angle independently contributing to the pattern of intersegmental covariation. We conclude that the planar covariation of elevation angles does not reflect central constraints, as previously suggested. An alternative approach for analyzing the patterns of coordination of both elevation and joint (hip, knee, and ankle) angles is used, based on temporal cross-correlation and phase relationships between pairs of kinematic variables. We describe the changes in the pattern of intersegmental coordination that are associated with the changes of locomotor modes and locomotor speeds. We provide some evidence for a distinct control of thigh motion and discuss the respective contributions of passive mechanical factors and of active (arising from neural control) factors to the formation and the regulation of the locomotor pattern throughout the gait cycle.

Related Concept Videos
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:18
Hierarchy of Motor Control
 01:25
Coplanar Forces
 01:27
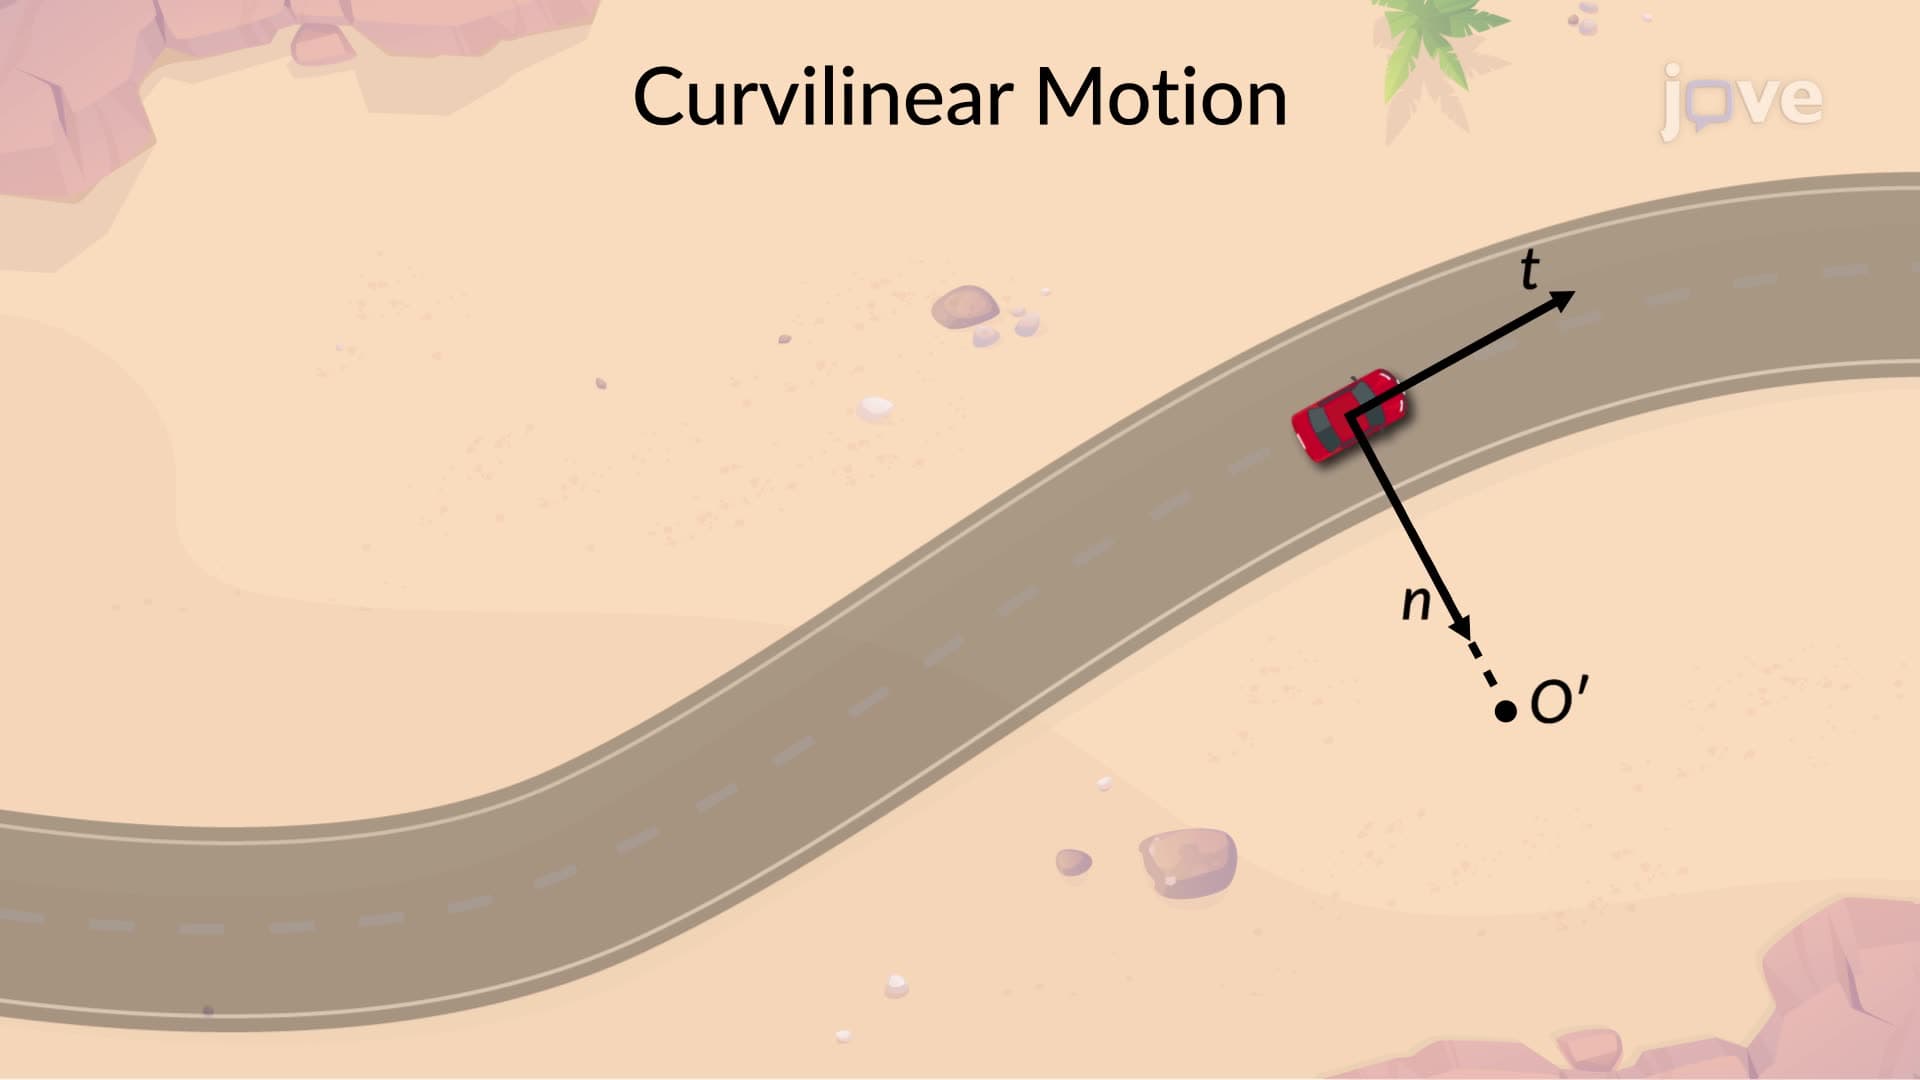
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:16
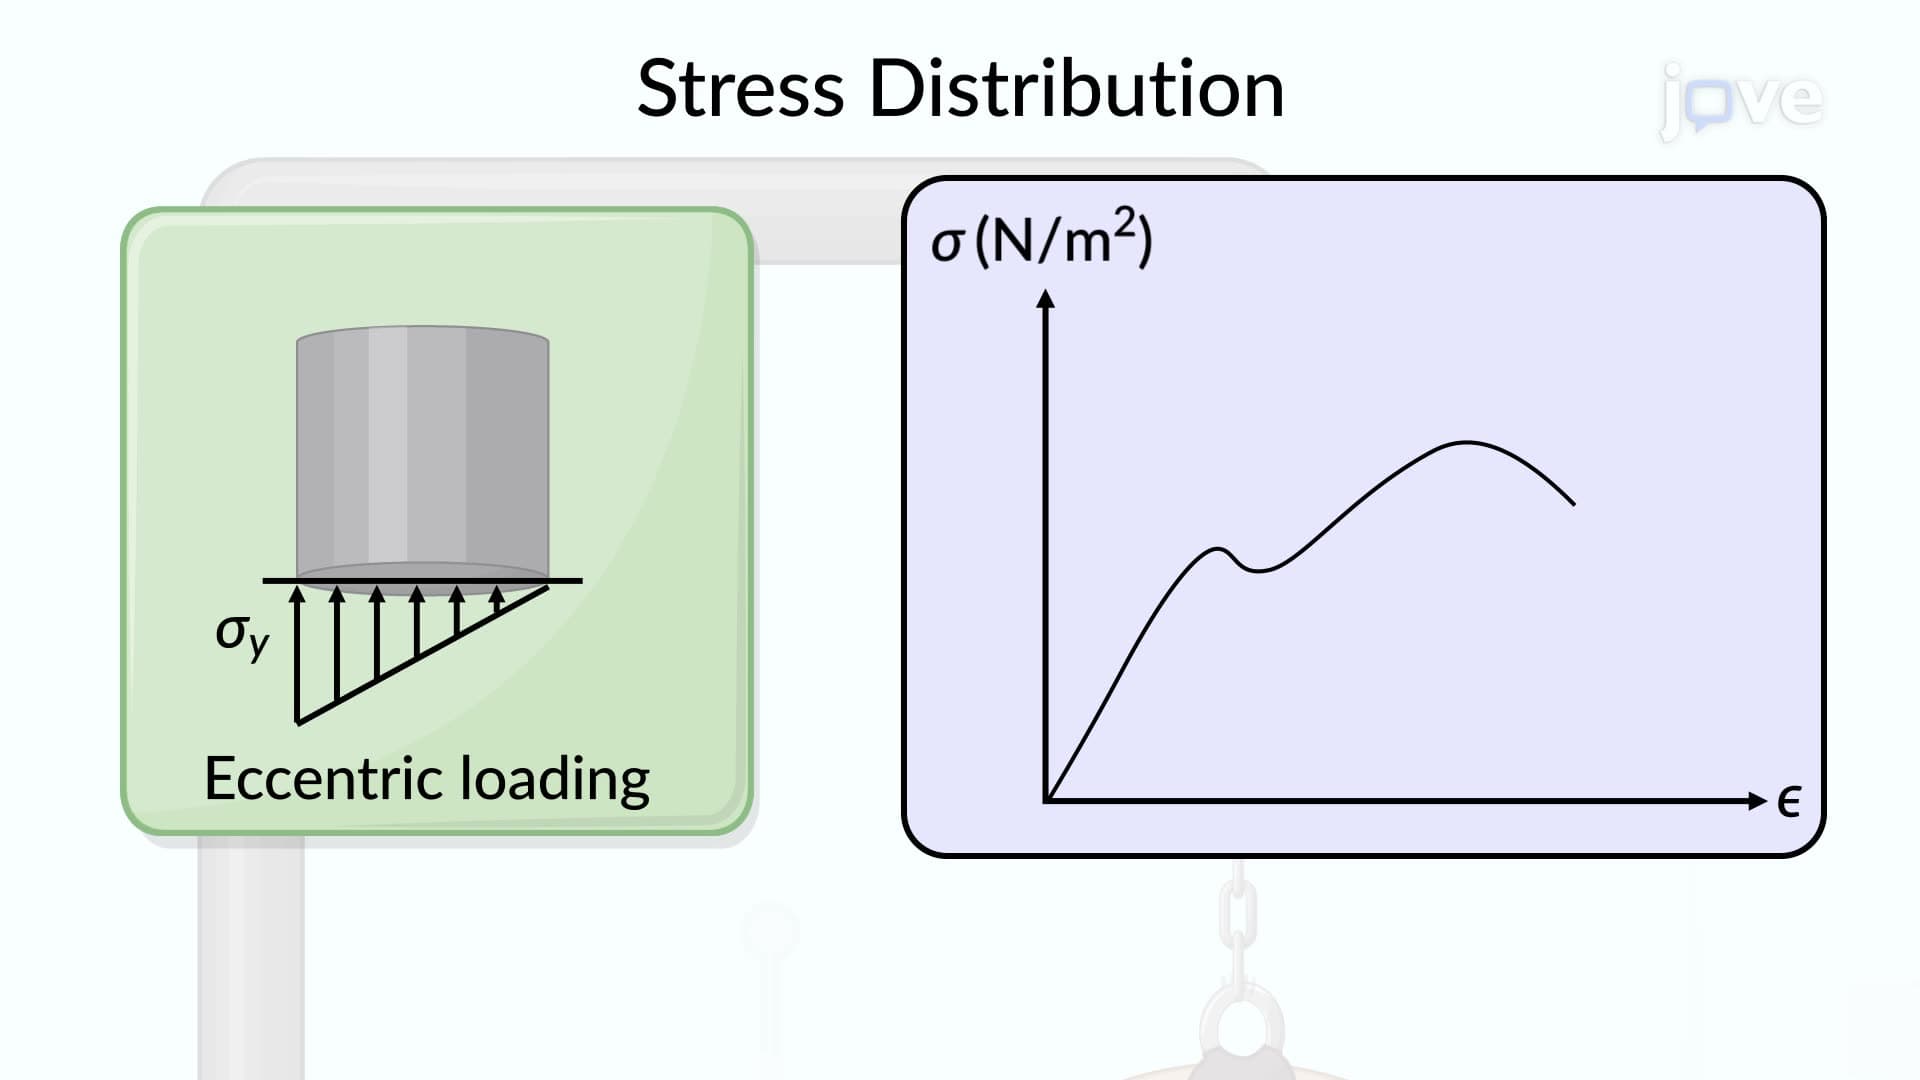
Eccentric Axial Loading in a Plane of Symmetry
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...