Related Experiment Video
Updated: Aug 7, 2026


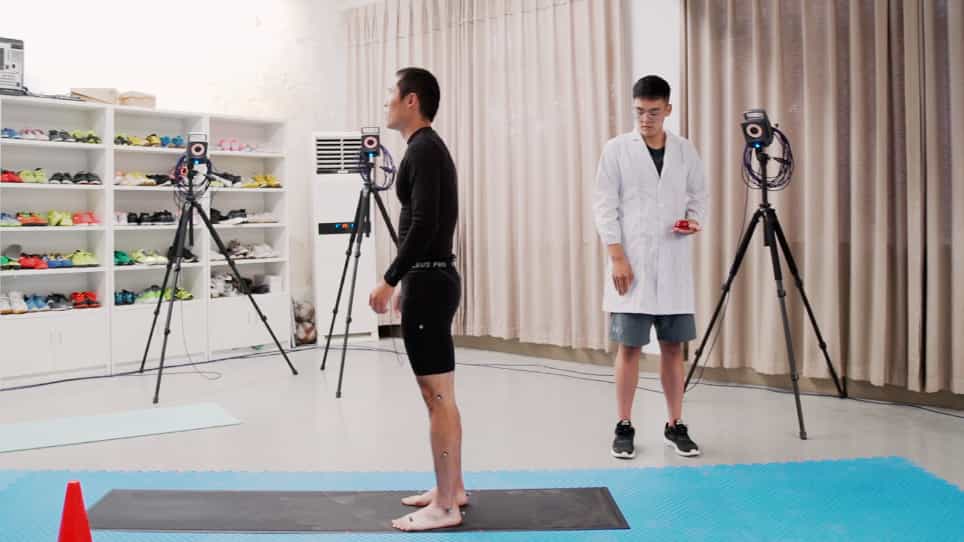
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Estimation and visualization of sagittal kinematics of lower limbs orientation using body-fixed sensors
Hooman Dejnabadi1, Brigitte M Jolles, Emilio Casanova
1Ecole Polytechnique Fédérale de Lausanne (EPFL), Laboratory of Movement Analysis and Measurement, 1015 Lausanne, Switzerland. hooman.dejnabadi@epfl.ch

Abstract:
A new method of estimating lower limbs orientations using a combination of accelerometers and gyroscopes is presented. The model is based on estimating the accelerations of ankle and knee joints by placing virtual sensors at the centers of rotation. The proposed technique considers human locomotion and biomechanical constraints, and provides a solution to fusing the data of gyroscopes and accelerometers that yields stable and drift-free estimates of segment orientation. The method was validated by measuring lower limb motions of eight subjects, walking at three different speeds, and comparing the results with a reference motion measurement system. The results are very close to those of the reference system presenting very small errors (Shank: rms = 1.0, Thigh: rms = 1.6 degrees) and excellent correlation coefficients (Shank: r = 0.999, Thigh: r = 0.998). Technically, the proposed ambulatory system is portable, easily mountable, and can be used for long-term monitoring without hindrance to natural activities. Finally, a gait analysis tool was designed to visualize the motion data as synthetic skeletons performing the same actions as the subjects.
More Related Videos
 05:52
Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
 06:52
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026