Related Experiment Video
Updated: Aug 7, 2026
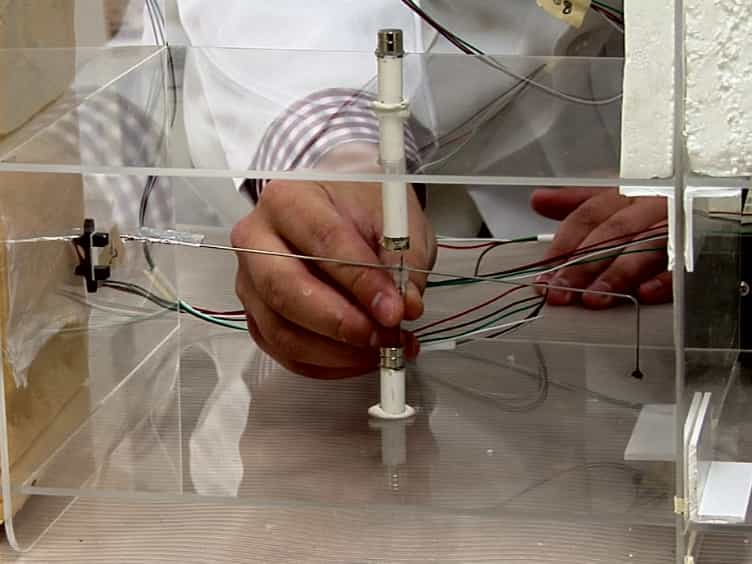
A Simple Flight Mill for the Study of Tethered Flight in Insects
Published on: December 10, 2015
Nonlinear time-periodic models of the longitudinal flight dynamics of desert locusts Schistocerca gregaria
Graham K Taylor1, Rafał Zbikowski
1Department of Zoology, University of Oxford, Tinbergen Building, South Parks Road, Oxford OX1 3PS, UK.

Abstract:
Previous studies of insect flight control have been statistical in approach, simply correlating wing kinematics with body kinematics or force production. Kinematics and forces are linked by Newtonian mechanics, so adopting a dynamics-based approach is necessary if we are to place the study of insect flight on its proper physical footing. Here we develop semi-empirical models of the longitudinal flight dynamics of desert locusts Schistocerca gregaria. We use instantaneous force-moment measurements from individual locusts to parametrize the nonlinear rigid body equations of motion. Since the instantaneous forces are approximately periodic, we represent them using Fourier series, which are embedded in the equations of motion to give a nonlinear time-periodic (NLTP) model. This is a proper mathematical generalization of an earlier linear-time invariant (LTI) model of locust flight dynamics, developed using previously published time-averaged versions of the instantaneous force recordings. We perform various numerical simulations, within the fitted range of the model, and across the range of body angles used by free-flying locusts, to explore the likely behaviour of the locusts upon release from the tether. Solutions of the NLTP models are compared with solutions of the nonlinear time-invariant (NLTI) models to which they reduce when the periodic terms are dropped. Both sets of models are unstable and therefore fail to explain locust flight stability fully. Nevertheless, whereas the measured forces include statistically significant harmonic content up to about the eighth harmonic, the simulated flight trajectories display no harmonic content above the fundamental forcing frequency. Hence, manoeuvre control in locusts will not directly reflect subtle changes in the higher harmonics of the wing beat, but must operate on a coarser time-scale. A state-space analysis of the NLTP models reveals orbital trajectories that are impossible to capture in the LTI and NLTI models, and inspires the hypothesis that asymptotic orbital stability is the proper definition of stability in flapping flight. Manoeuvre control on the scale of more than one wing beat would then consist in exciting transients from one asymptotically stable orbit to another. We summarize these hypotheses by proposing a limit-cycle analogy for flapping flight control and suggest experiments for verification of the limit-cycle control analogy hypothesis.
Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...