The control system for the Honda humanoid robot
Related Experiment Video
Updated: Jul 20, 2026

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
1Wako Research Centre, Honda R&D Co., Ltd, 8-1 Honcho, Wako-shi, Saitama Prefecture 351-0114, Japan. toru_takenaka@n.f.rd.honda.co.jp

Abstract:
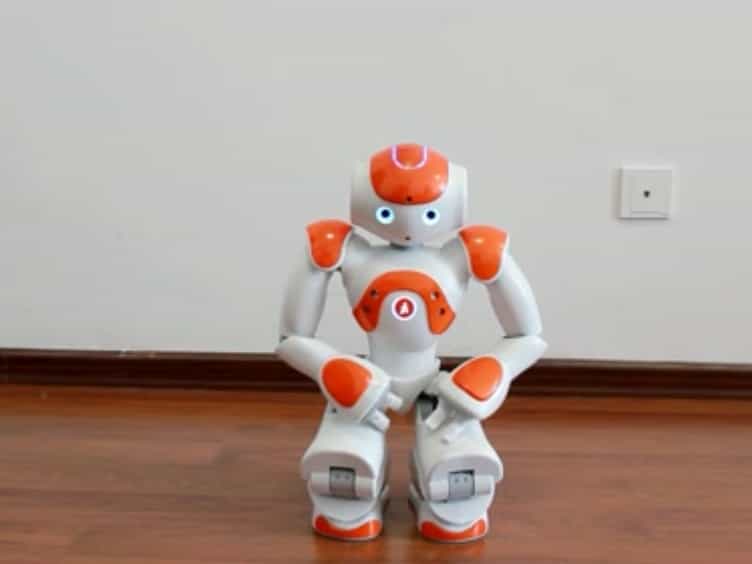
To avoid tipping over either during walking or on standing up, humans will first push down hard on the ground with a part of the sole of the foot. Then, when the tipping force can no longer be resisted, a change in body position or an extra step (stepping out) may be required to stabilise the posture. Our biped robot's control system attempts to reproduce and execute the same postural control operations carried out by humans. In this article, we present the history of robot development at Honda, fundamental dynamics for robots and the principles of posture control.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...