Related Experiment Video
Updated: Jul 20, 2026
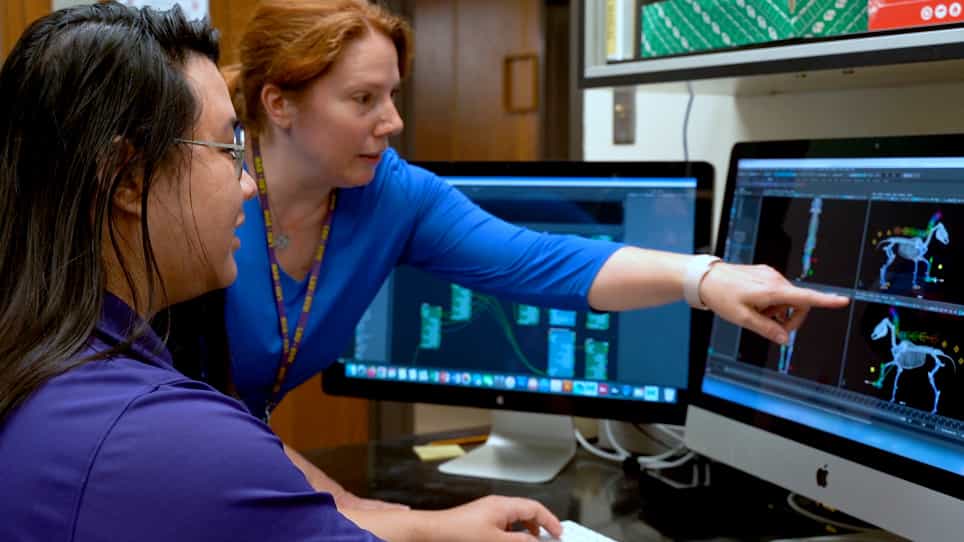

Construction of a Realistic, Whole-Body, Three-Dimensional Equine Skeletal Model using Computed Tomography Data
Published on: February 25, 2021
Locomotor mechanics of the tölt in Icelandic horses
Audrone R Biknevicius1, David R Mullineaux, Hilary M Clayton
1Department of Biomedical Sciences, Ohio University College of Osteopathic Medicine, Athens, OH 45701-2979, USA.

Objective:
To evaluate the locomotor mechanics of the tölt in Icelandic horses.
Animals:
10 adult Icelandic horses with no history of lameness.
Procedures:
Force platform data were captured for 27 trials for horses ridden at a tölt in a lateral sequence single-foot gait at a steady speed from 0.89 to 5.98 m/s. Simultaneous kinematic data were obtained by tracking retroflective markers overlying the right fore- and hind limbs. These kinetic and kinematic data were combined to evaluate 3 mechanical approaches, duty factor, Froude number, and center of mass (COM) mechanics, and to evaluate the capacity to recover mechanical energies during tölting via inverse pendulum and spring-mass (bouncing) mechanics.
Results:
Tölting horses had in-phase fluctuations of gravitational potential and kinetic energies of their COM and a capacity to recover mechanical energy through elastic recoil of spring elements in their limbs. These characteristics, along with Froude numbers exceeding values expected for the walk-run transition, are indicative of bouncing mechanics and, hence, most strongly ally tölting with running. Only the footfall pattern of a lateral sequence single-foot gait and low vertical excursions of the COM are more commonly associated with walking.
Conclusions And Clinical Relevance:
At the tölt, horses have unique mechanical characteristics that should be understood for veterinary care. Differences in interlimb coordination between tölting and trotting mask the overall similarities in most other aspects of their locomotor dynamics.
More Related Videos
 10:28
Kinematics and Ground Reaction Force Determination: A Demonstration Quantifying Locomotor Abilities of Young Adult, Middle-aged, and Geriatric Rats
Published on: February 22, 2011
 07:03
"Avatar", a Modified Ex vivo Work Loop Experiments Using In vivo Strain and Activation
Published on: August 18, 2023
Related Concept Videos
 01:16
Eccentric Loading
 01:15
Torque Free Motion
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
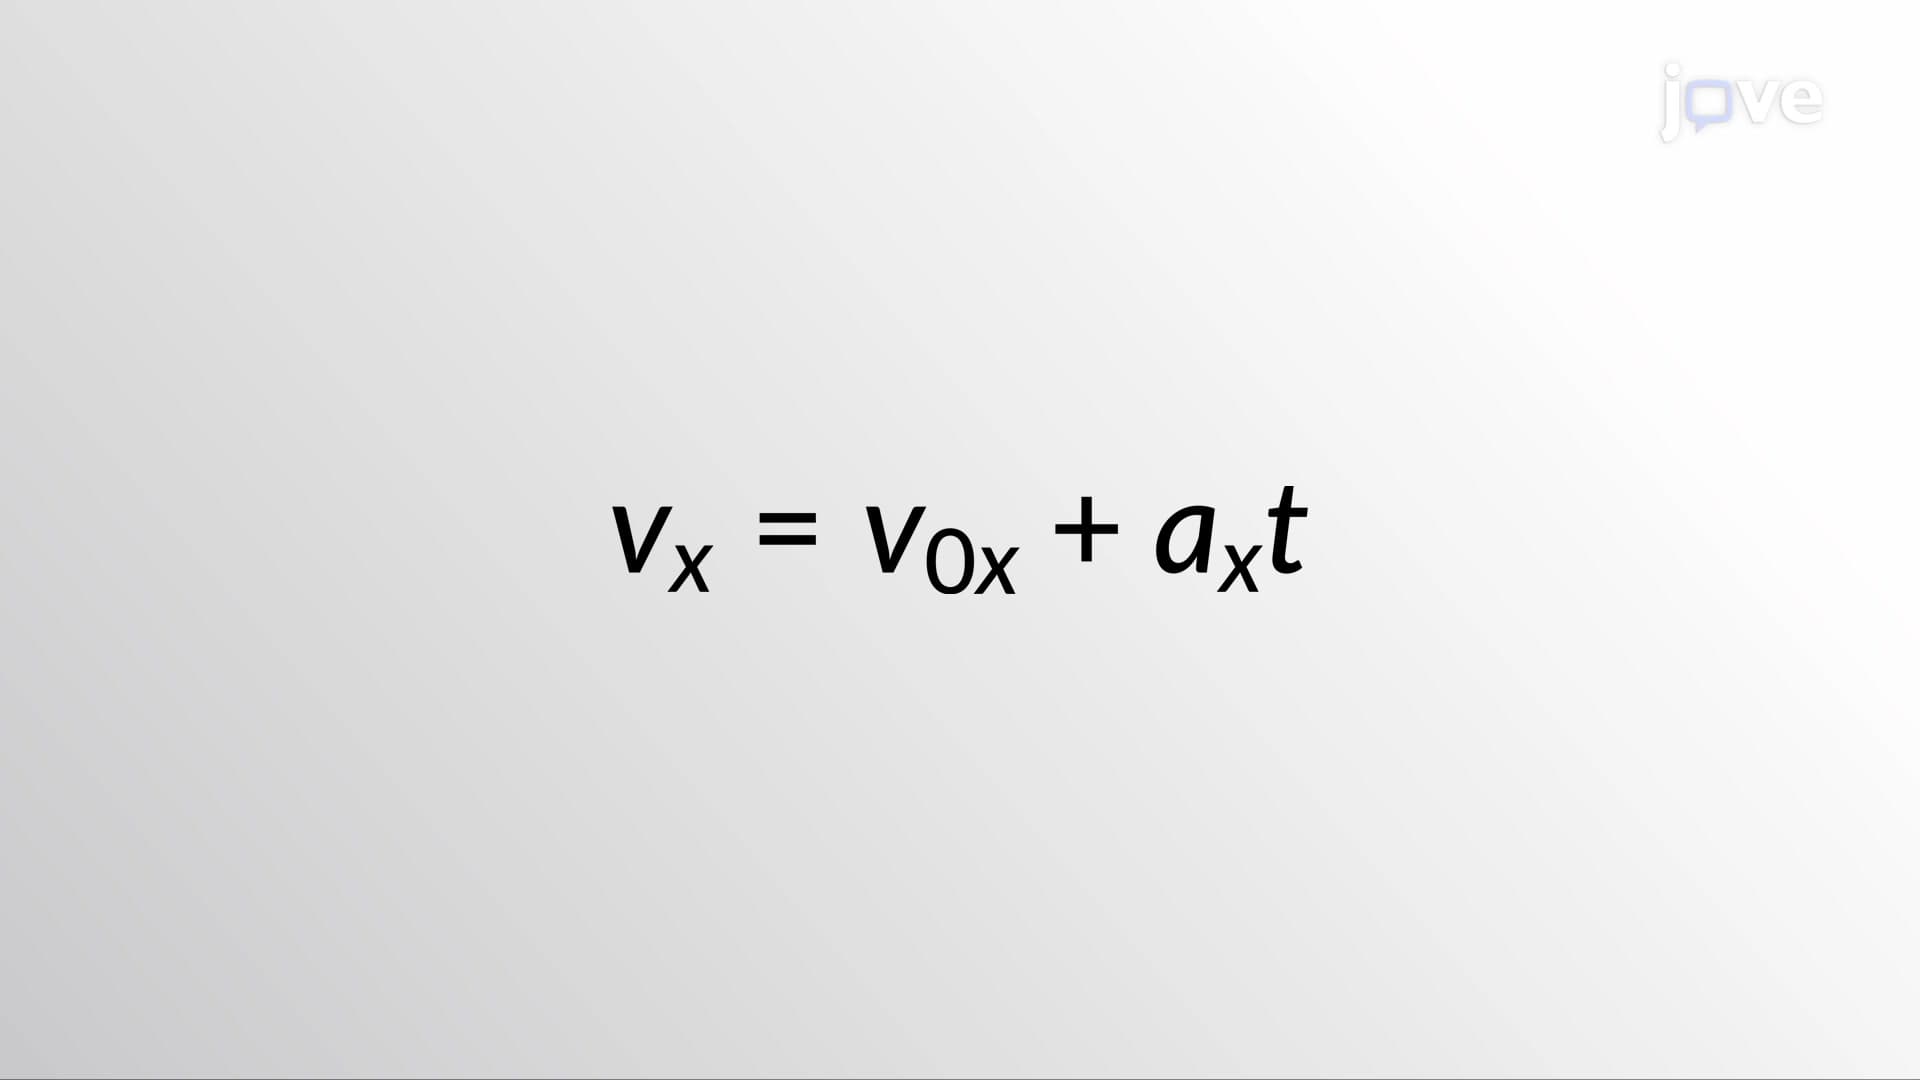 01:26
Kinematic Equations - I
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...