Related Experiment Video
Updated: Jul 20, 2026
A Tactile Automated Passive-Finger Stimulator (TAPS)
Published on: June 3, 2009
Initial development of a device for controlling manually applied forces
Gordon S Waddington1, Roger D Adams
1Physiotherapy, School of Health Sciences, University of Canberra, ACT 2601, Australia. gordon.waddington@canberra.edu.au

Unlabelled:
In both simulation and manual therapy studies, substantial variability has been shown when therapists attempt to replicate an applied force. Knowledge about the forces employed during treatment could reduce this variability. In the current project, a prototype for a mobilizing device incorporating a dynamometer was constructed. The prototype device was built around a conventional "hand-grip" dynamometer to give dial visibility during application of mobilizing forces and a moulded handle was used to increase the hand contact surface during force application. The variability of the mobilization forces produced was measured, and ratings of comfort during a simulated spinal mobilization technique were obtained from therapists.
Method:
Thirty physiotherapists were randomly allocated to apply either: (i) their own estimate of a grade III mobilization force using their hands in a pisiform grip or (ii) a 100N force with the manual therapy dynamometer, and to rate comfort during the performance of both techniques on a 100mm visual analogue scale.
Results:
Variance in dynamometer-dial-guided force application was always significantly less than the variance in therapist-concept-guided force application. Repeated-measures tests showed that the mean force produced at grade III was not significantly different from 100N, but physiotherapist comfort ratings were found to be significantly greater (P<0.01) when the manual therapy dynamometer was used.
Conclusion:
Manually applied force variability was significantly less and therapist comfort greater when using a device with visual access to a dial giving immediate force readout.
Related Concept Videos
 01:19
Machines
A free-body diagram of the...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:22
Mechanical Systems
 01:23
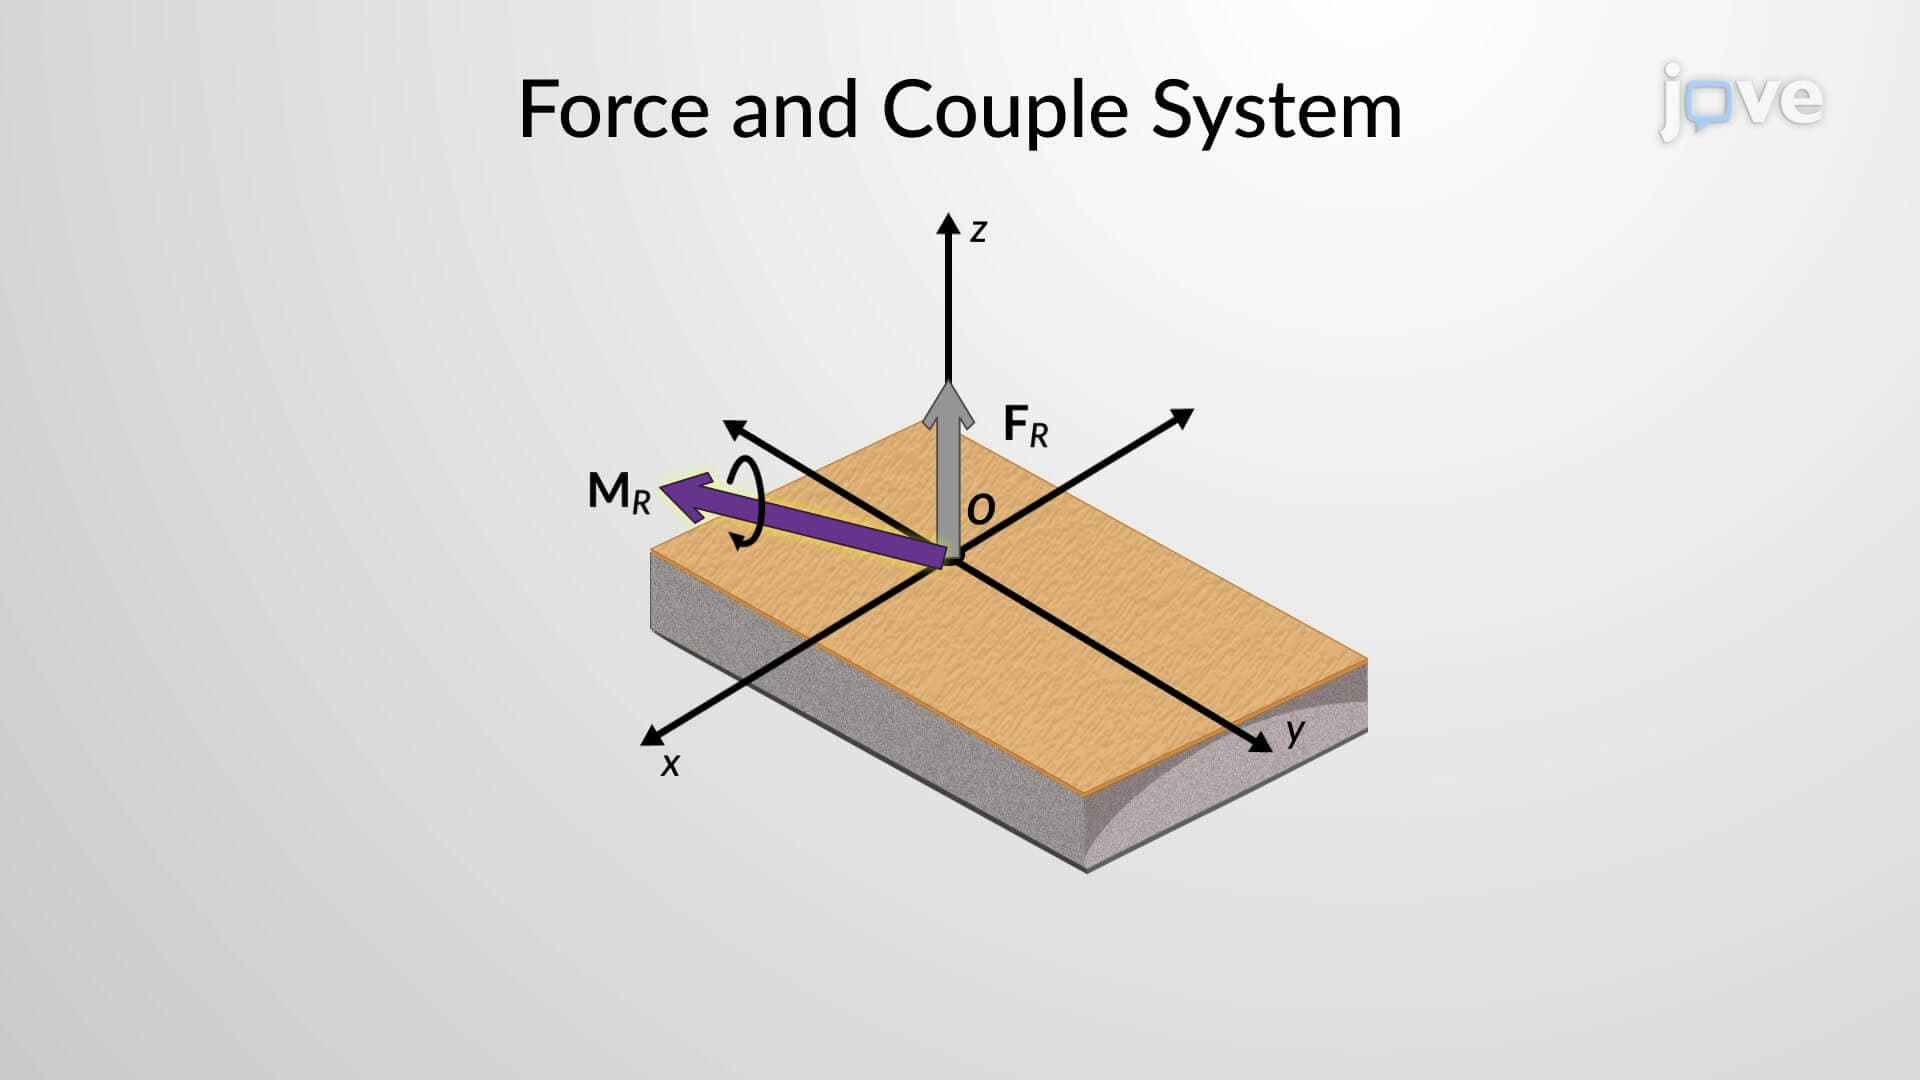
Simplification of a Force and Couple System: II
 01:09
Types of Forces