Related Experiment Video
Updated: Jul 18, 2026


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Dynamic control of the central pattern generator for locomotion
R Jacob Vogelstein1, Francesco Tenore, Ralph Etienne-Cummings
1Department of Biomedical Engineering, Johns Hopkins University, Baltimore, MD 21218, USA. jvogelst@bme.jhu.edu

Abstract:
We show that an ongoing locomotor pattern can be dynamically controlled by applying discrete pulses of electrical stimulation to the central pattern generator (CPG) for locomotion. Data are presented from a pair of experiments on biological (wetware) and electrical (hardware) models of the CPG demonstrating that stimulation causes brief deviations from the CPG's limit cycle activity. The exact characteristics of the deviation depend strongly on the phase of stimulation. Applications of this work are illustrated by examples showing how locomotion can be controlled by using a feedback loop to monitor CPG activity and applying stimuli at the appropriate times to modulate motor output. Eventually, this approach could lead to development of a neuroprosthetic device for restoring locomotion after paralysis.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:11
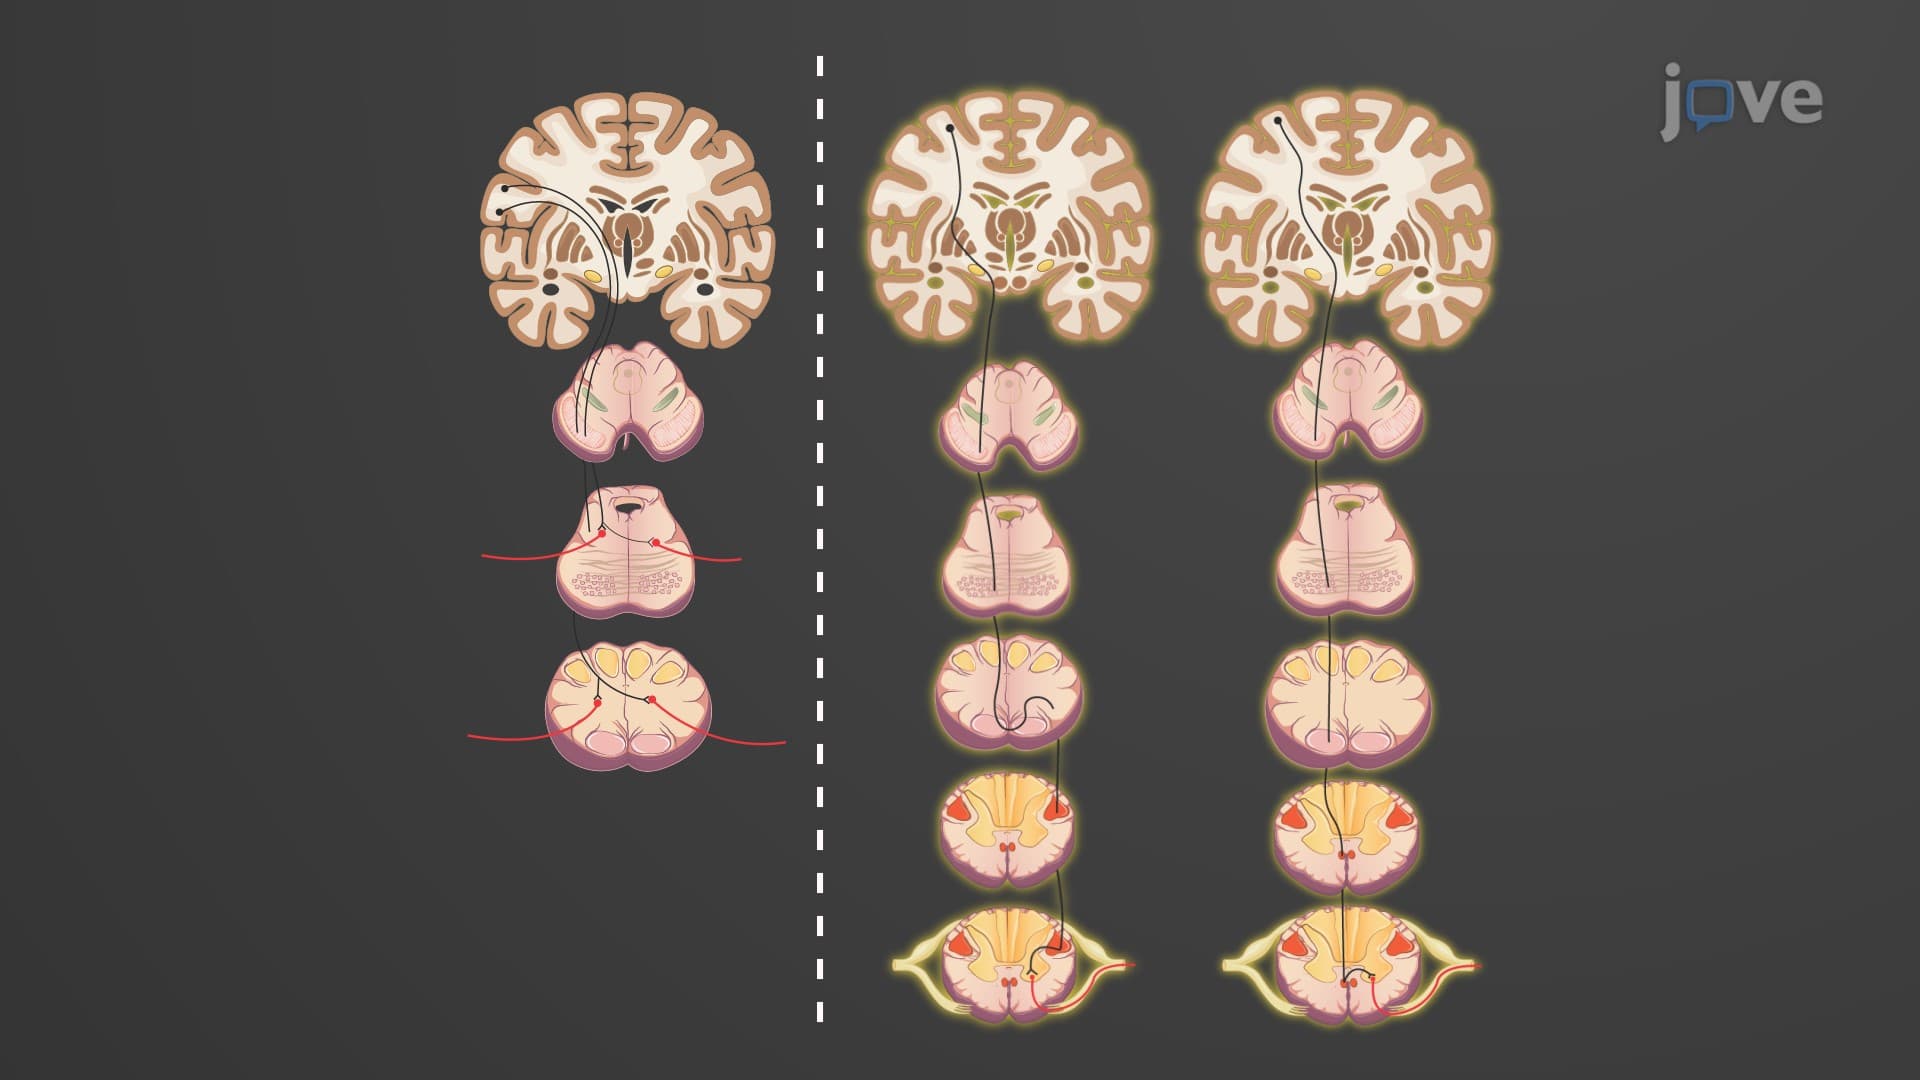
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...
 01:22
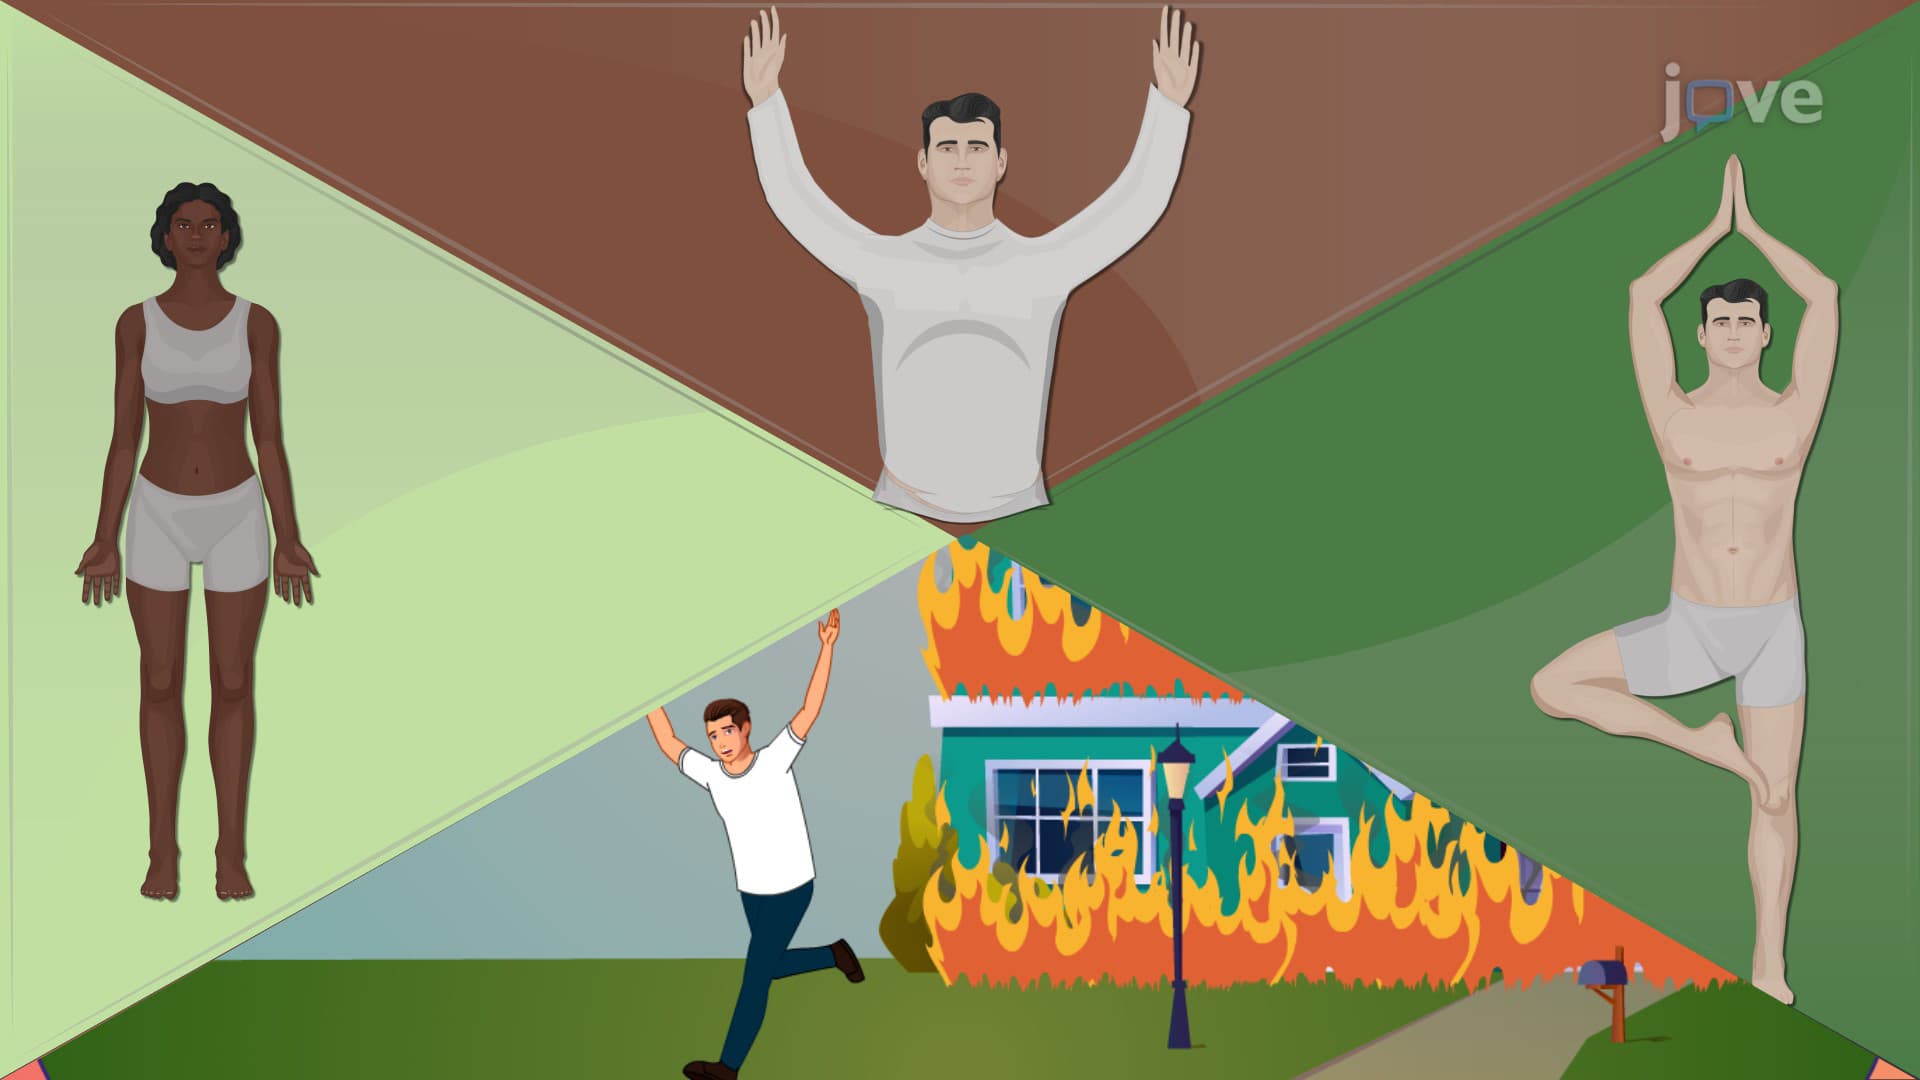
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:17
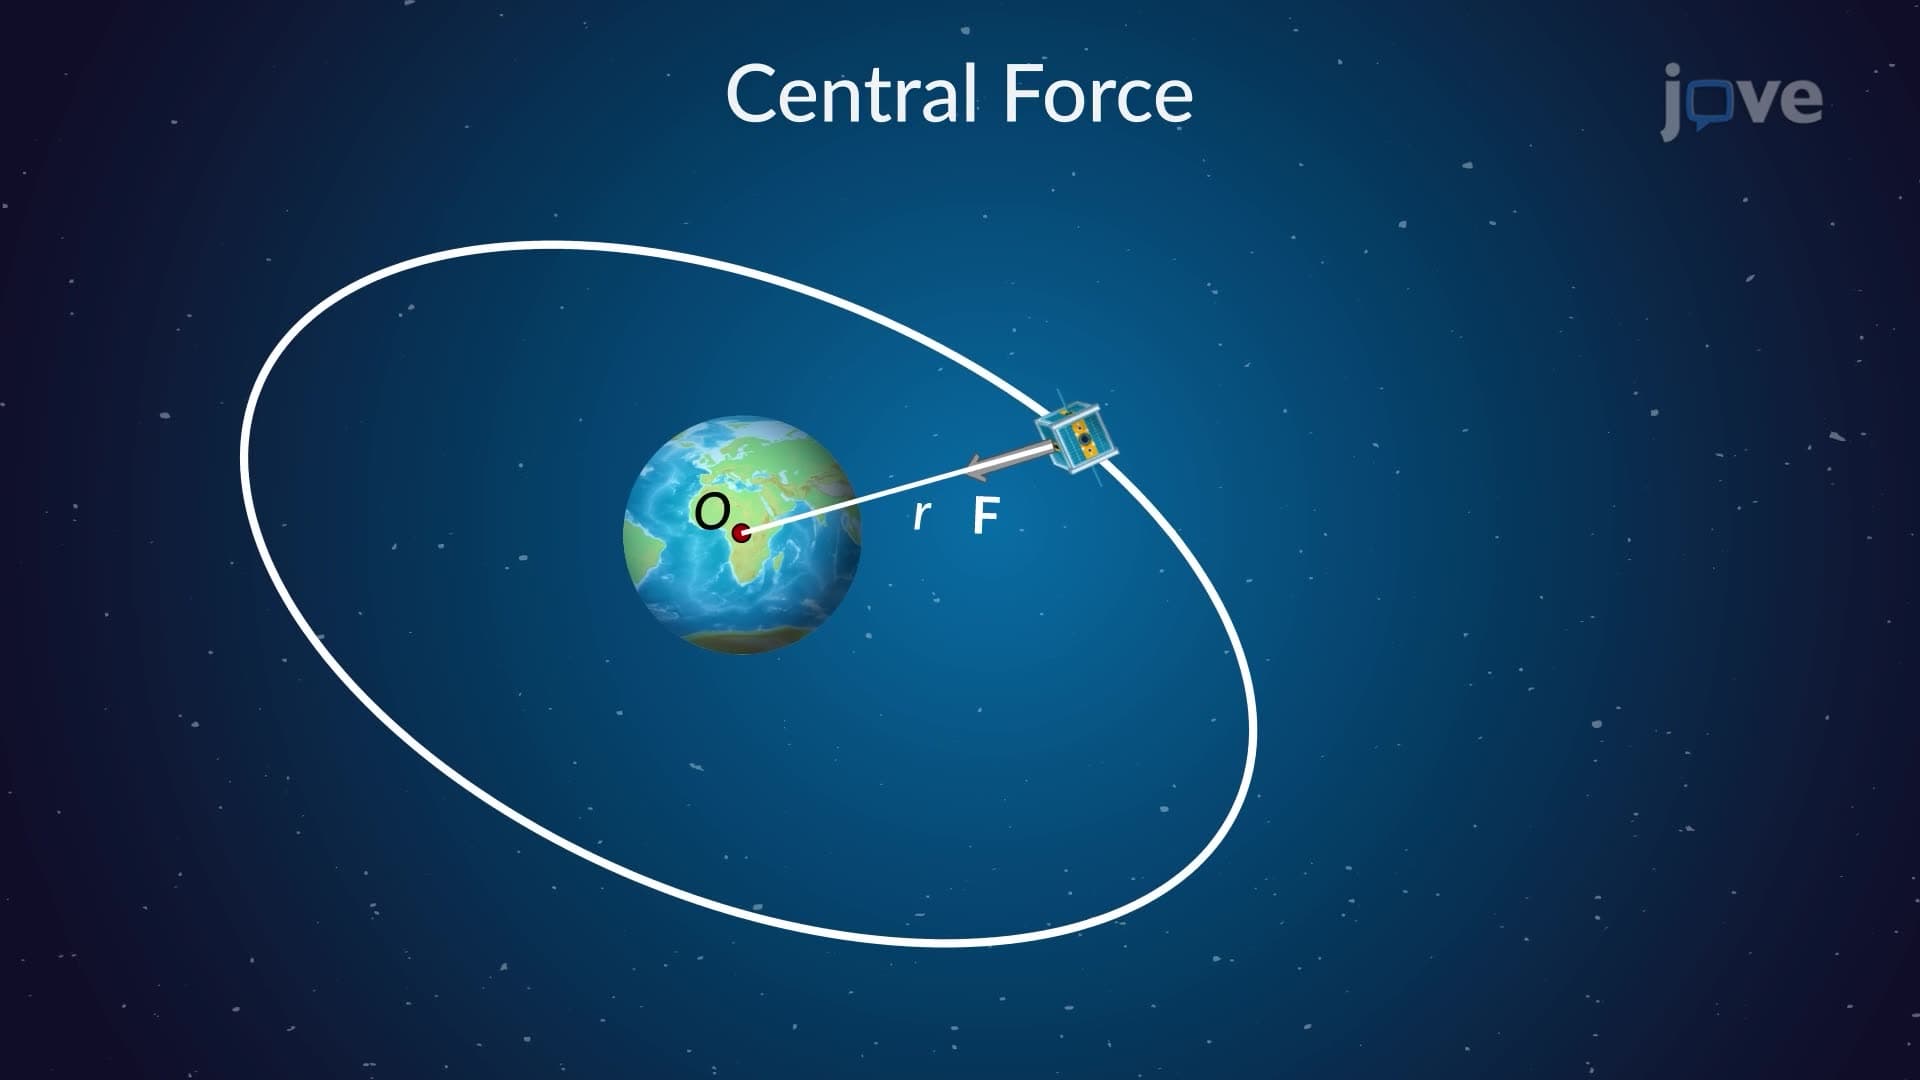
Central-Force Motion
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...