Related Experiment Video
Updated: Jul 18, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A model of open-loop control of equilibrium position and stiffness of the human elbow joint
Dinant A Kistemaker1, Arthur J Van Soest, Maarten F Bobbert
1Institute for Fundamental and Clinical Human Movement Sciences, IFKB, Vrije Universiteit, Van der Boechorststraat 9, 1081 BT Amsterdam, The Netherlands. d.kistemaker@fbw.vu.nl

Abstract:
According to the equilibrium point theory, the control of posture and movement involves the setting of equilibrium joint positions (EP) and the independent modulation of stiffness. One model of EP control, the alpha-model, posits that stable EPs and stiffness are set open-loop, i.e. without the aid of feedback. The purpose of the present study was to explore for the elbow joint the range over which stable EPs can be set open-loop and to investigate the effect of co-contraction on intrinsic low-frequency elbow joint stiffness (K (ilf)). For this purpose, a model of the upper and lower arm was constructed, equipped with Hill-type muscles. At a constant neural input, the isometric force of the contractile element of the muscles depended on both the myofilamentary overlap and the effect of sarcomere length on the sensitivity of myofilaments to [Ca2+] (LDCS). The musculoskeletal model, for which the parameters were chosen carefully on the basis of physiological literature, captured the salient isometric properties of the muscles spanning the elbow joint. It was found that stable open-loop EPs could be achieved over the whole range of motion of the elbow joint and that K (ilf), which ranged from 18 to 42 N m.rad(-1), could be independently controlled. In the model, LDCS contributed substantially to K (ilf) (up to 25 N m.rad(-1)) and caused K (ilf) to peak at a sub-maximal level of co-contraction.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:13
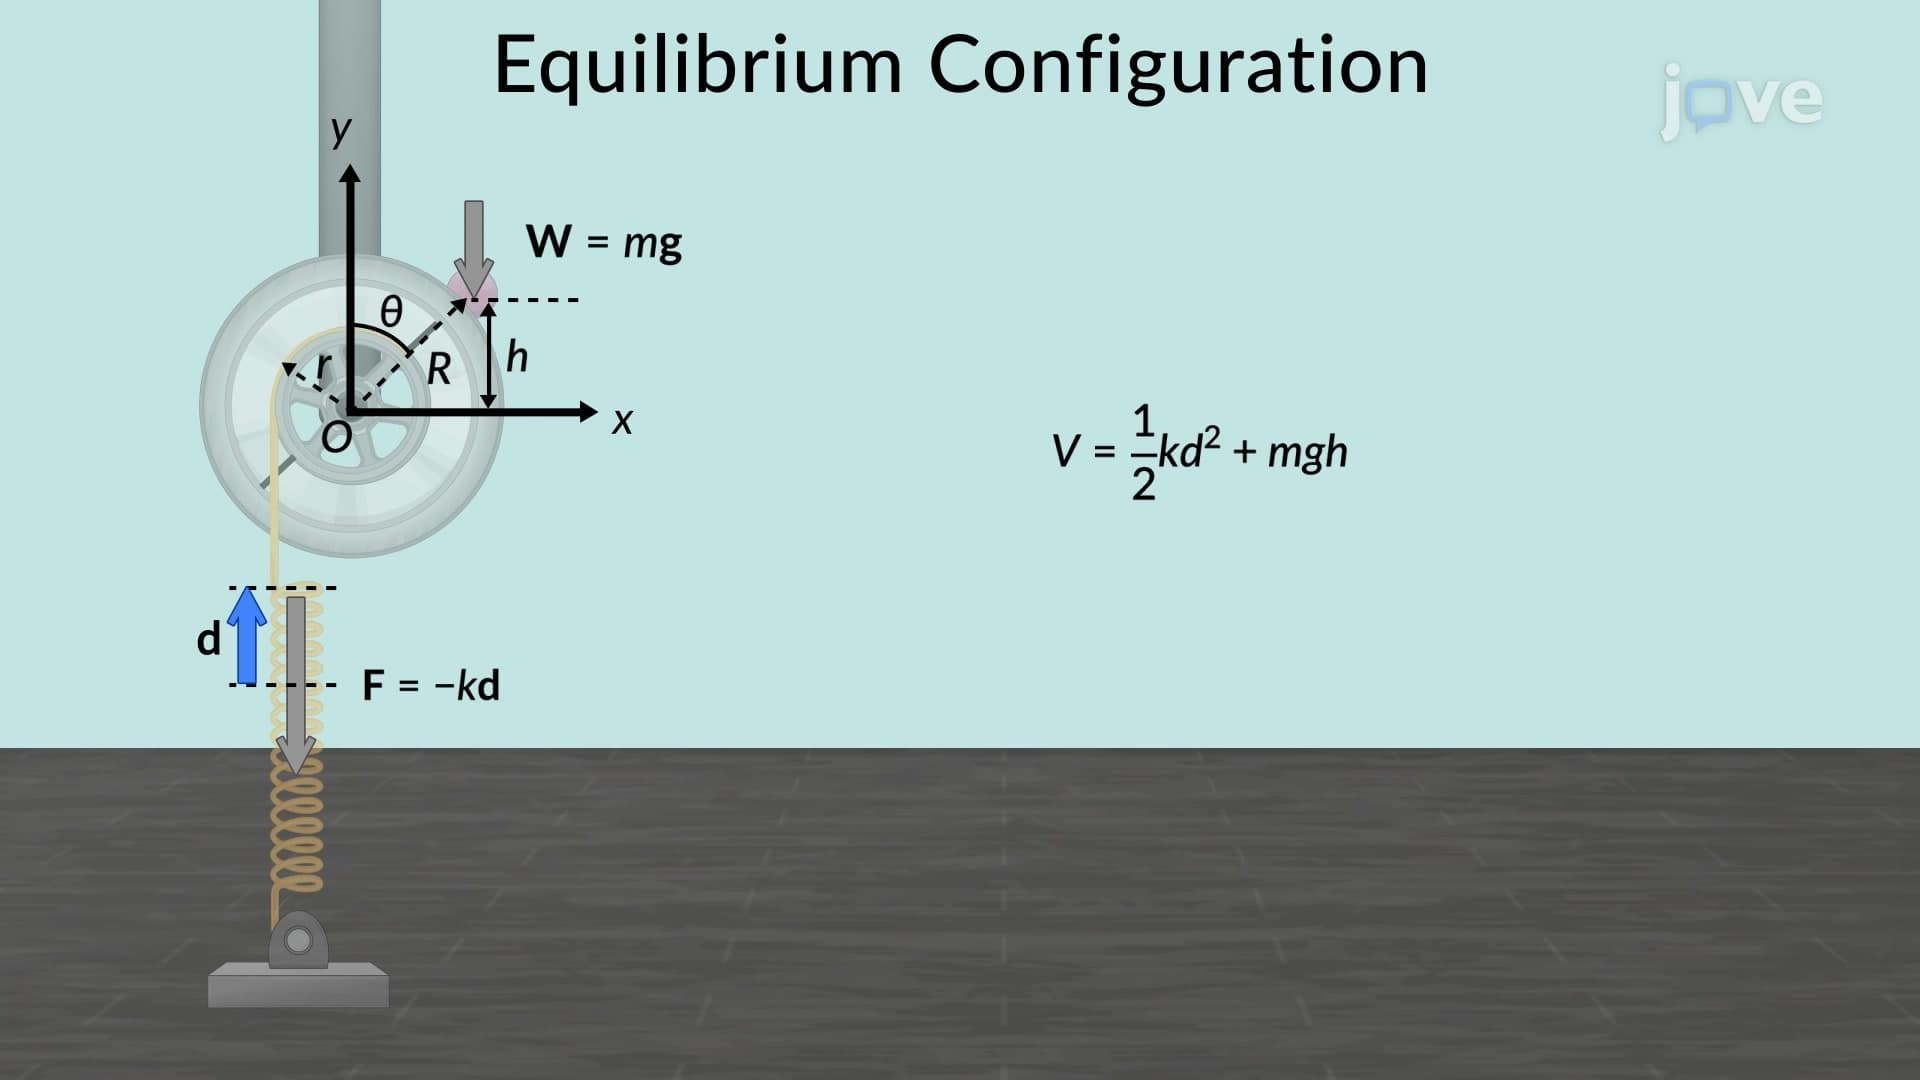
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:04
Oscillations about an Equilibrium Position
 00:49
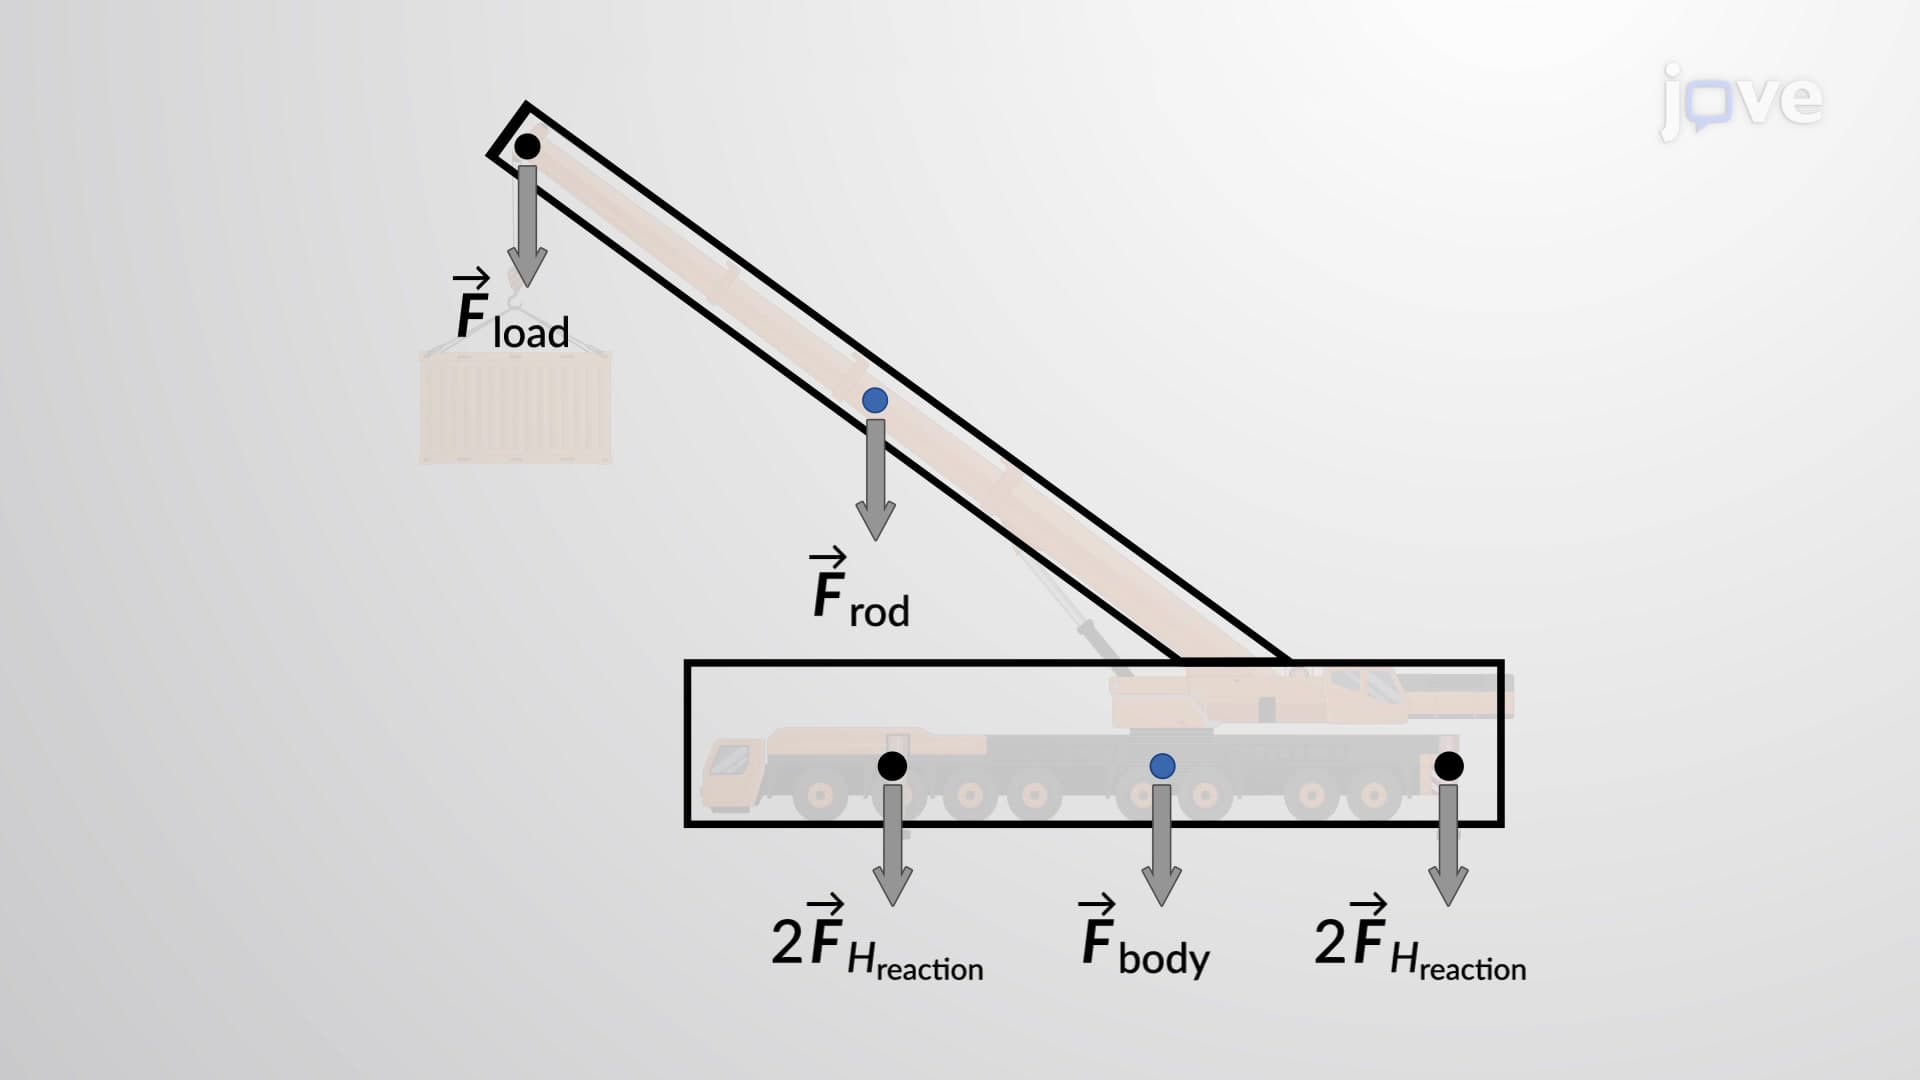
Rigid Body Equilibrium Problems - I
 01:14
Stability of structures
 01:21
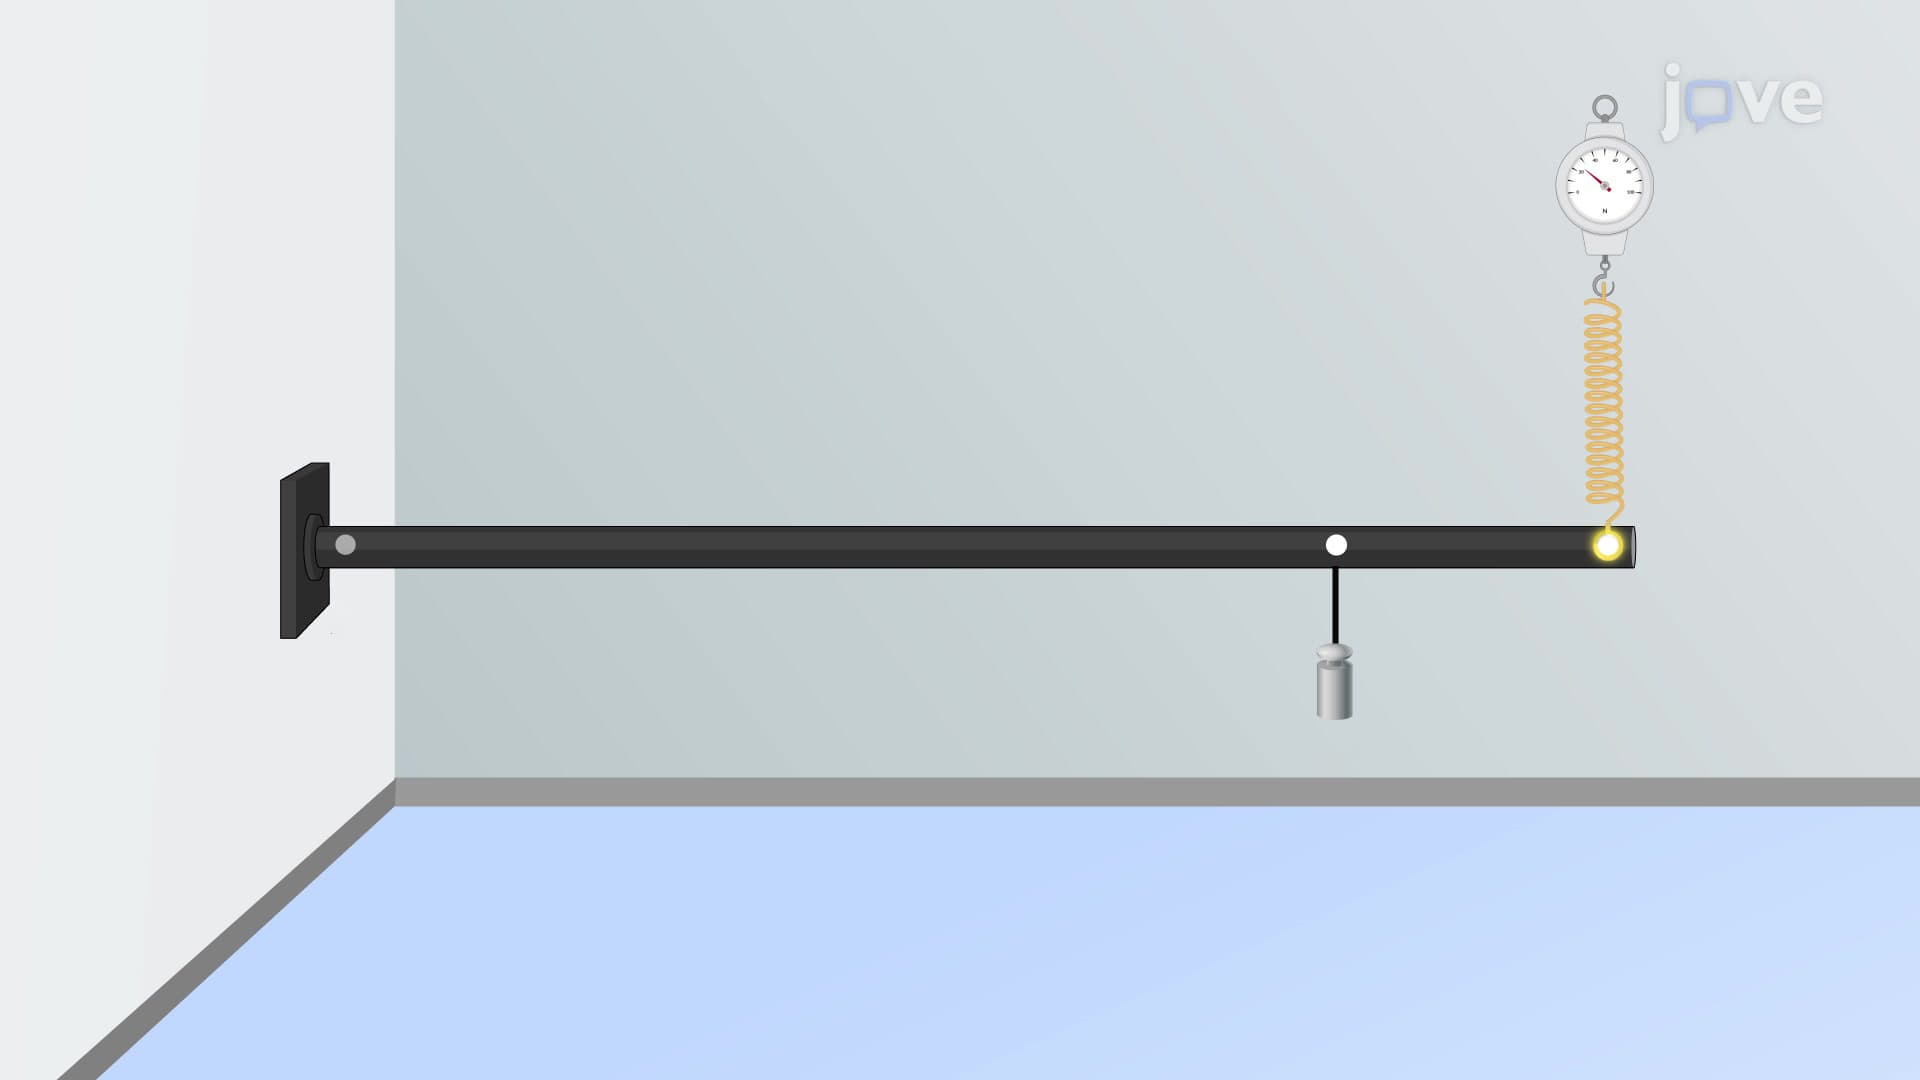
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?